Welcome to USB Industrial Grade AI Vision Camera repository
2.Attitude detection
Attitude detection
1. Introduction
MediaPipe is an open source data stream processing machine learning application development framework developed by Google. It is a graph-based data processing pipeline for building and using multiple forms of data sources, such as video, audio, sensor data, and any time series data. MediaPipe is cross-platform and can run on embedded platforms (Raspberry Pi, etc.), mobile devices (iOS and Android), workstations and servers, and supports mobile GPU acceleration. MediaPipe provides cross-platform, customizable ML solutions for real-time and streaming media.
The core framework of MediaPipe is implemented in C++ and provides support for languages such as Java and Objective C. The main concepts of MediaPipe include Packet, Stream, Calculator, Graph and Subgraph.
Features of MediaPipe:
- End-to-end acceleration: Built-in fast ML inference and processing accelerates even on commodity hardware.
- Build once, deploy anywhere: Unified solution for Android, iOS, desktop/cloud, web and IoT.
- Ready-to-use solutions: cutting-edge ML solutions that showcase the full capabilities of the framework.
- Free and open source: frameworks and solutions under Apache2.0, fully extensible and customizable.
2. MediaPipe Pose
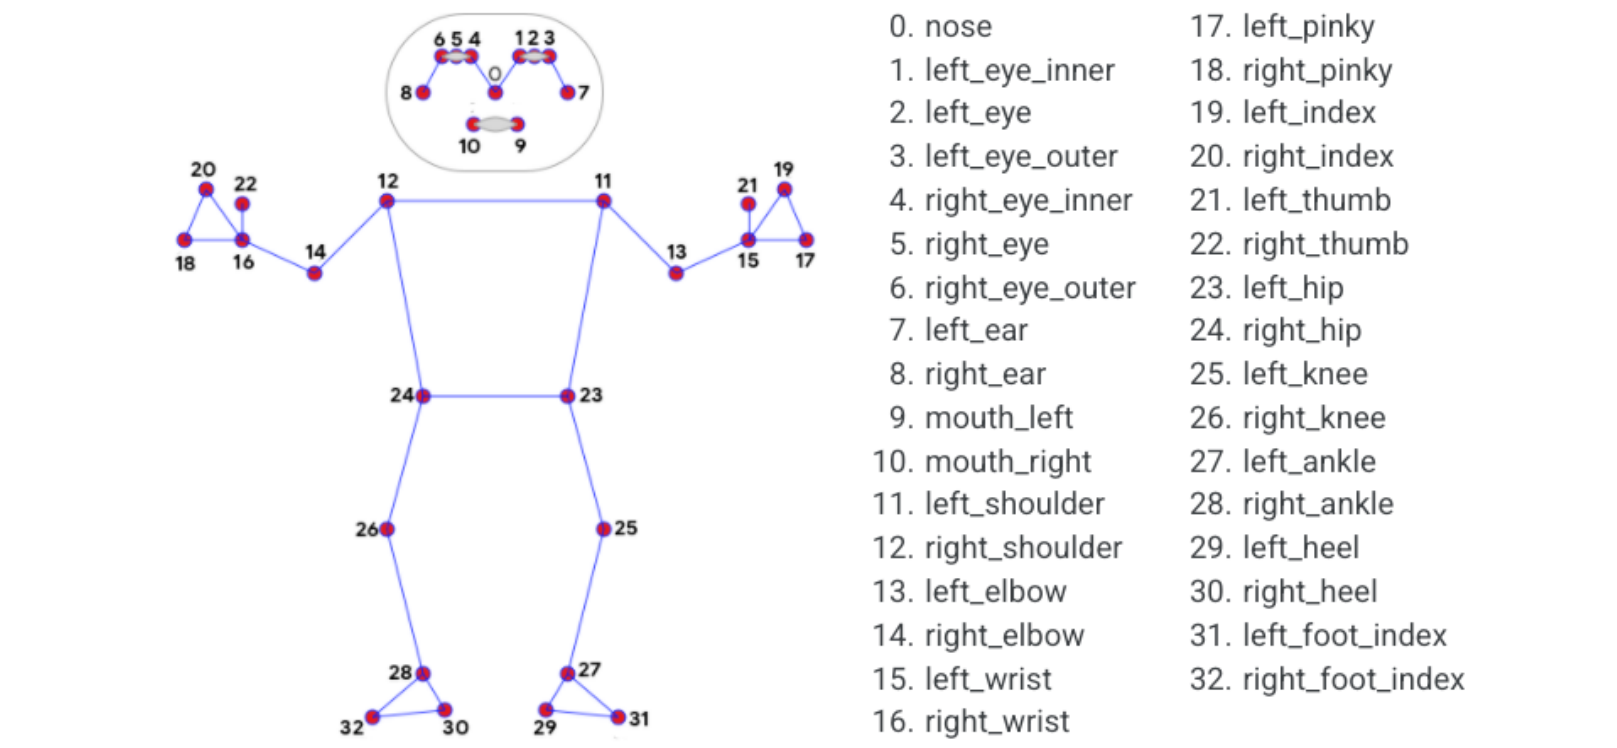
MediaPipe Pose is an ML solution for high-fidelity body pose tracking,Using BlazePose research, 33 3D coordinates and full background segmentation masks are inferred from RGB video frames. This research also provides motivation for the ML Kit pose detection API.
The landmark model in MediaPipe poses predicts the positions of 33 pose coordinates (see figure below).
3. Posture detection
3.1 Start up
Input command:
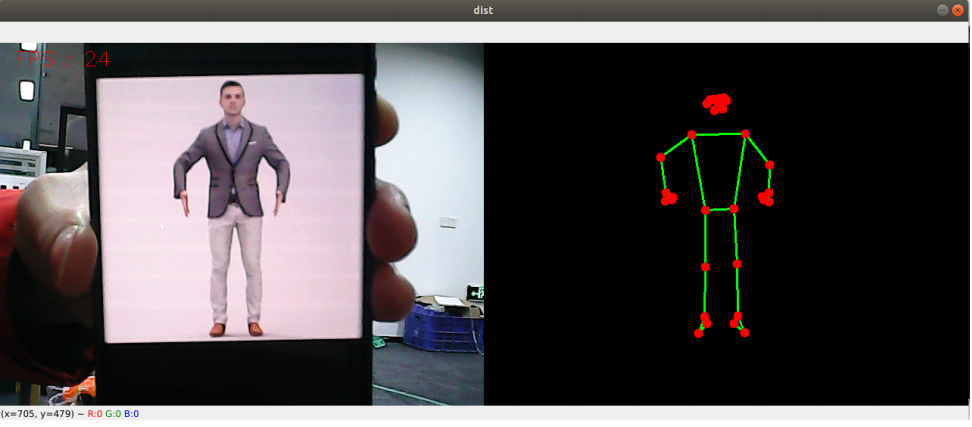
roscorerosrun yahboomcar_mediapipe 02_PoseDetector.py
3.2 Source code
Code path:~/yahboomcar_ws/src/yahboomcar_mediapipe/scripts
x#!/usr/bin/env python3# encoding: utf-8import timeimport rospyimport cv2 as cvimport numpy as npimport mediapipe as mpfrom geometry_msgs.msg import Pointfrom yahboomcar_msgs.msg import PointArray
class PoseDetector: def __init__(self, mode=False, smooth=True, detectionCon=0.5, trackCon=0.5): self.mpPose = mp.solutions.pose self.mpDraw = mp.solutions.drawing_utils self.pose = self.mpPose.Pose( static_image_mode=mode, smooth_landmarks=smooth, min_detection_confidence=detectionCon, min_tracking_confidence=trackCon ) self.pub_point = rospy.Publisher('/mediapipe/points', PointArray, queue_size=1000) self.lmDrawSpec = mp.solutions.drawing_utils.DrawingSpec(color=(0, 0, 255), thickness=-1, circle_radius=6) self.drawSpec = mp.solutions.drawing_utils.DrawingSpec(color=(0, 255, 0), thickness=2, circle_radius=2)
def pubPosePoint(self, frame, draw=True): pointArray = PointArray() img = np.zeros(frame.shape, np.uint8) img_RGB = cv.cvtColor(frame, cv.COLOR_BGR2RGB) self.results = self.pose.process(img_RGB) if self.results.pose_landmarks: if draw: self.mpDraw.draw_landmarks(frame, self.results.pose_landmarks, self.mpPose.POSE_CONNECTIONS, self.lmDrawSpec, self.drawSpec) self.mpDraw.draw_landmarks(img, self.results.pose_landmarks, self.mpPose.POSE_CONNECTIONS, self.lmDrawSpec, self.drawSpec) for id, lm in enumerate(self.results.pose_landmarks.landmark): point = Point() point.x, point.y, point.z = lm.x, lm.y, lm.z pointArray.points.append(point) self.pub_point.publish(pointArray) return frame, img
def frame_combine(slef,frame, src): if len(frame.shape) == 3: frameH, frameW = frame.shape[:2] srcH, srcW = src.shape[:2] dst = np.zeros((max(frameH, srcH), frameW + srcW, 3), np.uint8) dst[:, :frameW] = frame[:, :] dst[:, frameW:] = src[:, :] else: src = cv.cvtColor(src, cv.COLOR_BGR2GRAY) frameH, frameW = frame.shape[:2] imgH, imgW = src.shape[:2] dst = np.zeros((frameH, frameW + imgW), np.uint8) dst[:, :frameW] = frame[:, :] dst[:, frameW:] = src[:, :] return dst
if __name__ == '__main__': rospy.init_node('PoseDetector', anonymous=True) capture = cv.VideoCapture(0) capture.set(6, cv.VideoWriter.fourcc('M', 'J', 'P', 'G')) capture.set(cv.CAP_PROP_FRAME_WIDTH, 640) capture.set(cv.CAP_PROP_FRAME_HEIGHT, 480) print("capture get FPS : ", capture.get(cv.CAP_PROP_FPS)) pTime = cTime = 0 pose_detector = PoseDetector() index = 3 while capture.isOpened(): ret, frame = capture.read() # frame = cv.flip(frame, 1) frame, img = pose_detector.pubPosePoint(frame,draw=False) if cv.waitKey(1) & 0xFF == ord('q'): break cTime = time.time() fps = 1 / (cTime - pTime) pTime = cTime text = "FPS : " + str(int(fps)) cv.putText(frame, text, (20, 30), cv.FONT_HERSHEY_SIMPLEX, 0.9, (0, 0, 255), 1) dist = pose_detector.frame_combine(frame, img) cv.imshow('dist', dist) # cv.imshow('frame', frame) # cv.imshow('img', img) capture.release() cv.destroyAllWindows()