Welcome to USB Industrial Grade AI Vision Camera repository
10.Gesture recognition
Gesture recognition
1. Introduction
MediaPipe is an open source data stream processing machine learning application development framework developed by Google. It is a graph-based data processing pipeline for building and using multiple forms of data sources, such as video, audio, sensor data, and any time series data.
MediaPipe is cross-platform and can run on embedded platforms (Raspberry Pi, etc.), mobile devices (iOS and Android), workstations and servers, and supports mobile GPU acceleration. MediaPipe provides cross-platform, customizable ML solutions for real-time and streaming media.
The core framework of MediaPipe is implemented in C++ and provides support for languages such as Java and Objective C. The main concepts of MediaPipe include Packet, Stream, Calculator, Graph and Subgraph.
Features of MediaPipe:
- End-to-end acceleration: Built-in fast ML inference and processing accelerates even on commodity hardware.
- Build once, deploy anywhere: Unified solution for Android, iOS, desktop/cloud, web and IoT.
- Ready-to-use solutions: cutting-edge ML solutions that showcase the full capabilities of the framework.
- Free and open source: frameworks and solutions under Apache2.0, fully extensible and customizable.
2. Gesture recognition
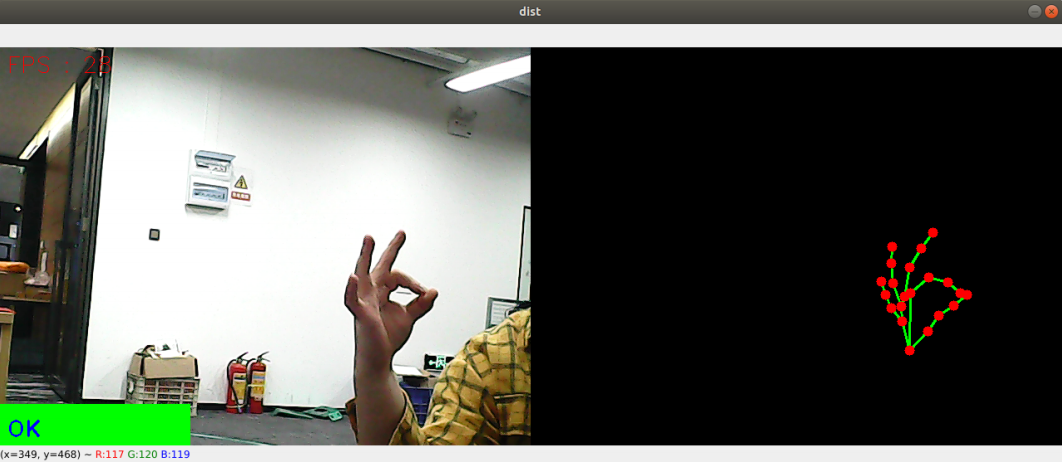
Gesture recognition designed with the right hand in mind can be accurately recognized when certain conditions are met. The recognized gestures are: [Zero, One, Two, Three, Four, Five, Six, Seven, Eight, Ok, Rock, Thumb_up (like), Thumb_down (thumb down), Heart_single (one-handed heart) 】, 14 categories in total.
2.1.Startup
Input command:
cd ~/yahboomcar_ws/src/yahboomcar_mediapipe/scriptspython3 11_GestureRecognition.py
2.2 Source code
Code path:~/yahboomcar_ws/src/yahboomcar_mediapipe/scripts
x#!/usr/bin/env python3# encoding: utf-8import mathimport timeimport cv2 as cvimport numpy as npimport mediapipe as mp
class handDetector: def __init__(self, mode=False, maxHands=2, detectorCon=0.5, trackCon=0.5): self.tipIds = [4, 8, 12, 16, 20] self.mpHand = mp.solutions.hands self.mpDraw = mp.solutions.drawing_utils self.hands = self.mpHand.Hands( static_image_mode=mode, max_num_hands=maxHands, min_detection_confidence=detectorCon, min_tracking_confidence=trackCon ) self.lmList = [] self.lmDrawSpec = mp.solutions.drawing_utils.DrawingSpec(color=(0, 0, 255), thickness=-1, circle_radius=6) self.drawSpec = mp.solutions.drawing_utils.DrawingSpec(color=(0, 255, 0), thickness=2, circle_radius=2)
def get_dist(self, point1, point2): x1, y1 = point1 x2, y2 = point2 return abs(math.sqrt(math.pow(abs(y1 - y2), 2) + math.pow(abs(x1 - x2), 2)))
def calc_angle(self, pt1, pt2, pt3): point1 = self.lmList[pt1][1], self.lmList[pt1][2] point2 = self.lmList[pt2][1], self.lmList[pt2][2] point3 = self.lmList[pt3][1], self.lmList[pt3][2] a = self.get_dist(point1, point2) b = self.get_dist(point2, point3) c = self.get_dist(point1, point3) try: radian = math.acos((math.pow(a, 2) + math.pow(b, 2) - math.pow(c, 2)) / (2 * a * b)) angle = radian / math.pi * 180 except: angle = 0 return abs(angle)
def findHands(self, frame, draw=True): self.lmList = [] img = np.zeros(frame.shape, np.uint8) img_RGB = cv.cvtColor(frame, cv.COLOR_BGR2RGB) self.results = self.hands.process(img_RGB) if self.results.multi_hand_landmarks: for i in range(len(self.results.multi_hand_landmarks)): if draw: self.mpDraw.draw_landmarks(frame, self.results.multi_hand_landmarks[i], self.mpHand.HAND_CONNECTIONS, self.lmDrawSpec, self.drawSpec) self.mpDraw.draw_landmarks(img, self.results.multi_hand_landmarks[i], self.mpHand.HAND_CONNECTIONS, self.lmDrawSpec, self.drawSpec) for id, lm in enumerate(self.results.multi_hand_landmarks[i].landmark): h, w, c = frame.shape cx, cy = int(lm.x * w), int(lm.y * h) self.lmList.append([id, cx, cy]) return frame, img
def frame_combine(slef,frame, src): if len(frame.shape) == 3: frameH, frameW = frame.shape[:2] srcH, srcW = src.shape[:2] dst = np.zeros((max(frameH, srcH), frameW + srcW, 3), np.uint8) dst[:, :frameW] = frame[:, :] dst[:, frameW:] = src[:, :] else: src = cv.cvtColor(src, cv.COLOR_BGR2GRAY) frameH, frameW = frame.shape[:2] imgH, imgW = src.shape[:2] dst = np.zeros((frameH, frameW + imgW), np.uint8) dst[:, :frameW] = frame[:, :] dst[:, frameW:] = src[:, :] return dst
def fingersUp(self): fingers=[] # Thumb if (self.calc_angle(self.tipIds[0], self.tipIds[0] - 1, self.tipIds[0] - 2) > 150.0) and ( self.calc_angle( self.tipIds[0] - 1, self.tipIds[0] - 2, self.tipIds[0] - 3) > 150.0): fingers.append(1) else: fingers.append(0) # 4 finger for id in range(1, 5): if self.lmList[self.tipIds[id]][2] < self.lmList[self.tipIds[id] - 2][2]: fingers.append(1) else: fingers.append(0) return fingers
def get_gesture(self): gesture = "" fingers = self.fingersUp() if self.lmList[self.tipIds[0]][2] > self.lmList[self.tipIds[1]][2] and \ self.lmList[self.tipIds[0]][2] > self.lmList[self.tipIds[2]][2] and \ self.lmList[self.tipIds[0]][2] > self.lmList[self.tipIds[3]][2] and \ self.lmList[self.tipIds[0]][2] > self.lmList[self.tipIds[4]][2] : gesture = "Thumb_down"
elif self.lmList[self.tipIds[0]][2] < self.lmList[self.tipIds[1]][2] and \ self.lmList[self.tipIds[0]][2] < self.lmList[self.tipIds[2]][2] and \ self.lmList[self.tipIds[0]][2] < self.lmList[self.tipIds[3]][2] and \ self.lmList[self.tipIds[0]][2] < self.lmList[self.tipIds[4]][2] and \ self.calc_angle(self.tipIds[1] - 1, self.tipIds[1] - 2, self.tipIds[1] - 3) < 150.0 : gesture = "Thumb_up" if fingers.count(1) == 3 or fingers.count(1) == 4: if fingers[0] == 1 and ( self.get_dist(self.lmList[4][1:], self.lmList[8][1:])<self.get_dist(self.lmList[4][1:], self.lmList[5][1:]) ): gesture = "OK" elif fingers[2] == fingers[3] == 0: gesture = "Rock" elif fingers.count(1) == 3: gesture = "Three" else: gesture = "Four" elif fingers.count(1) == 0: gesture = "Zero" elif fingers.count(1) == 1: gesture = "One" elif fingers.count(1) == 2: if fingers[0] == 1 and fingers[4] == 1: gesture = "Six" elif fingers[0] == 1 and self.calc_angle(4, 5, 8) > 90: gesture = "Eight" elif fingers[0] == fingers[1] == 1 and self.get_dist(self.lmList[4][1:], self.lmList[8][1:]) < 50: gesture = "Heart_single" else: gesture = "Two" elif fingers.count(1)==5:gesture = "Five" if self.get_dist(self.lmList[4][1:], self.lmList[8][1:]) < 60 and \ self.get_dist(self.lmList[4][1:], self.lmList[12][1:]) < 60 and \ self.get_dist(self.lmList[4][1:], self.lmList[16][1:]) < 60 and \ self.get_dist(self.lmList[4][1:], self.lmList[20][1:]) < 60 : gesture = "Seven" if self.lmList[self.tipIds[0]][2] < self.lmList[self.tipIds[1]][2] and \ self.lmList[self.tipIds[0]][2] < self.lmList[self.tipIds[2]][2] and \ self.lmList[self.tipIds[0]][2] < self.lmList[self.tipIds[3]][2] and \ self.lmList[self.tipIds[0]][2] < self.lmList[self.tipIds[4]][2] and \ self.calc_angle(self.tipIds[1] - 1, self.tipIds[1] - 2, self.tipIds[1] - 3) > 150.0 : gesture = "Eight" return gesture
'''Zero One Two Three Four Five Six Seven EightOk: OKRock: rockThumb_up : 点赞Thumb_down: 拇指向下Heart_single: 单手比心'''
if __name__ == '__main__': capture = cv.VideoCapture(0) capture.set(6, cv.VideoWriter.fourcc('M', 'J', 'P', 'G')) capture.set(cv.CAP_PROP_FRAME_WIDTH, 640) capture.set(cv.CAP_PROP_FRAME_HEIGHT, 480) print("capture get FPS : ", capture.get(cv.CAP_PROP_FPS)) pTime = cTime = 0 hand_detector = handDetector(detectorCon=0.75) while capture.isOpened(): ret, frame = capture.read() # frame = cv.flip(frame, 1) frame, img = hand_detector.findHands(frame, draw=False) if len(hand_detector.lmList) != 0: totalFingers = hand_detector.get_gesture() cv.rectangle(frame, (0, 430), (230, 480), (0, 255, 0), cv.FILLED) cv.putText(frame, str(totalFingers), (10, 470), cv.FONT_HERSHEY_PLAIN, 2, (255, 0, 0), 2) if cv.waitKey(1) & 0xFF == ord('q'): break cTime = time.time() fps = 1 / (cTime - pTime) pTime = cTime text = "FPS : " + str(int(fps)) cv.putText(frame, text, (10, 30), cv.FONT_HERSHEY_SIMPLEX, 0.9, (0, 0, 255), 1) dist = hand_detector.frame_combine(frame, img) cv.imshow('dist', dist) # cv.imshow('frame', frame) # cv.imshow('img', img) capture.release() cv.destroyAllWindows()