Welcome to TinyF Laser Ranging Module repository
1. Introduction to TinyF laser ranging module
TinyF laser ranging module
TinyF laser ranging module1. Product Parameters2. Appearance Design Drawing3. Communication interface4. Data Protocol5. Notes
The TinyF laser ranging module is based on a D-TOF single-point laser sensor, an onboard MCU, and a housing. It features built-in sunlight rejection and anti-cover contamination algorithms, enabling accurate and rapid distance measurement. Even in extremely bright ambient light (100-190K Lux), it can accurately measure even the smallest objects, unaffected by variations in reflectivity, achieving precise ranging of 2m to 4m.
1. Product Parameters
| name | TinyF laser ranging module |
|---|---|
| model | DVP0501C1 |
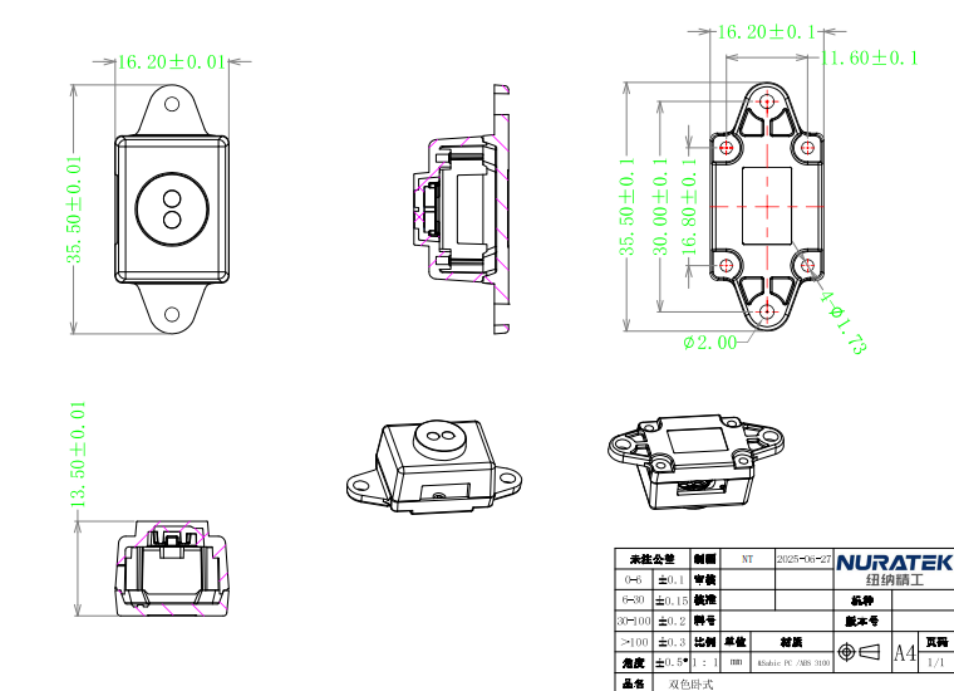
| Positioning hole distance | Outer hole distance 30.00mm |
| Dimensions | Length 21.00; Width 16.5; Height 13.50mm |
| Detection distance | 20mm-4000mm |
| Detecting objects | Opaque objects (reflectivity 18% to 88%) |
| Measurement accuracy | Within ±3% |
| FOV | 3±0.5° |
| Frame rate | 30Hz ~ 90Hz |
| Ambient light resistance | 0 ~ 190KLux |
| Spot diameter | At 4m: about 21cm *13cm |
| Power supply voltage | 5.0V |
| Current consumption | 35mA or less |
| Emission wavelength | 940nm |
| Laser Safety | LASER CLASS 1 (IEC 60825-1: 2014) |
| Operating temperature | -20 ~+70℃ |
| Operating humidity | 35 ~ 80%RH |
| Storage temperature | -40 ~+80℃ |
| weight | About 3.6g |
| Material | Shell: PC; Optical lens: PMMA |
2. Appearance Design Drawing
3. Communication interface
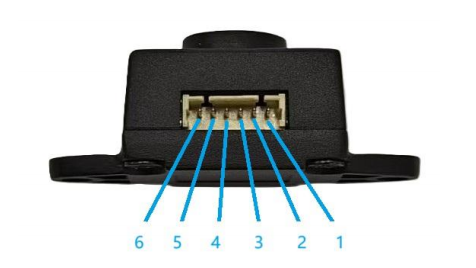
| Line Sequence | Pin Name |
|---|---|
| 1 | VDD 5V |
| 2 | RX |
| 3 | TX |
| 4 | GND |
| 5 | NA |
| 6 | NA |
Note: Pin 5 and Pin 6 are not required to be used by users.
4. Data Protocol
This protocol specifies that TOF outputs distance data in ASCII format via UART. To ensure data reliability and parsing consistency, an ASCII format description is provided.
Related parameter description
| name | value |
|---|---|
| Baud rate | 115200 |
| Effective minimum distance (theoretical value) | 20,unit:mm |
| Effective maximum distance (theoretical value) | 4000,unit:mm |
| Confidence | 0~62,The larger the value, the higher the distance reliability. |
Data format
Data frame structure: 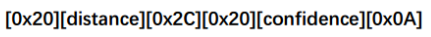
Example: 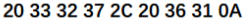
| Field | Number of bytes | Example(Hex) | ASCII characters |
|---|---|---|---|
| Frame header (fixed value) | 1 | 20 | space |
| Distance value(distance) | 1~5 | 33 32 37 | 327 |
| Delimiter (fixed value) | 2 | 2C 20 | ,space |
| Confidence(confidence) | 1~2 | 36 31 | 61 |
| Frame tail (fixed value) | 1 | 0A | \n |
5. Notes
The test frame rate is 30Hz, with the FOV facing a standard reflector and no obstructions in front.
Refer to the above test conditions. Changes in test conditions may cause variations in measurement results.
The module's factory default frame rate is 30Hz; a firmware update is required to adjust to 90Hz.
Due to continuous product updates and improvements, this specification is subject to change. Please refer to the latest version for accuracy.