Welcome to WLR722 LiDAR repository
12.ROS2 meta-function package
12.ROS2 meta-function package
1. Introduction to Metapackages
Completing a systemic function may involve multiple packages. For example, implementing a robot navigation module might include sub-packages such as mapping, positioning, and path planning. So, when installing this module, does the user need to install each package individually?
Obviously, installing packages one by one is inefficient. ROS2 provides a way to bundle different packages into a single package. When installing a module, the packaged package, also known as a metapackage, can be directly invoked.
A metapackage is a file management system concept in Linux. It's a virtual package in ROS2. It doesn't contain any substantive content, but it relies on other packages. This method allows packages to be grouped together. Think of it like a table of contents like a book, telling you which sub-packages are within a package and where to download them.
For example, the command "sudo apt install ros-humle-desktop" installs ROS 2 using a meta-package. This meta-package depends on several other ROS 2 packages, and these dependencies are installed along with the package.
A classic example of a meta-package: navigation2
- navigation2 GitHub repository: GitHub - ros-navigation/navigation2: ROS 2 Navigation Framework and System
2. Purpose
This package facilitates installation. We only need this one package to organize and install other related packages.
3. Implementation
- Create a new package
xxxxxxxxxxros2 pkg create pkg_metapackage2、Modify the package.xml file and add the packages that the execution depends on
xxxxxxxxxx <package format="3"> <name>pkg_metapackage</name> <version>0.0.0</version> <description>TODO: Package description</description> <maintainer email="1461190907@qq.com">root</maintainer> <license>TODO: License declaration</license> <buildtool_depend>ament_cmake</buildtool_depend> <exec_depend>pkg_interfaces</exec_depend> <exec_depend>pkg_helloworld_py</exec_depend> <exec_depend>pkg_topic</exec_depend> <exec_depend>pkg_service</exec_depend> <exec_depend>pkg_action</exec_depend> <exec_depend>pkg_param</exec_depend> <test_depend>ament_lint_auto</test_depend> <test_depend>ament_lint_common</test_depend> <export> <build_type>ament_cmake</build_type> </export></package>- The contents of the file CMakeLists.txt are as follows
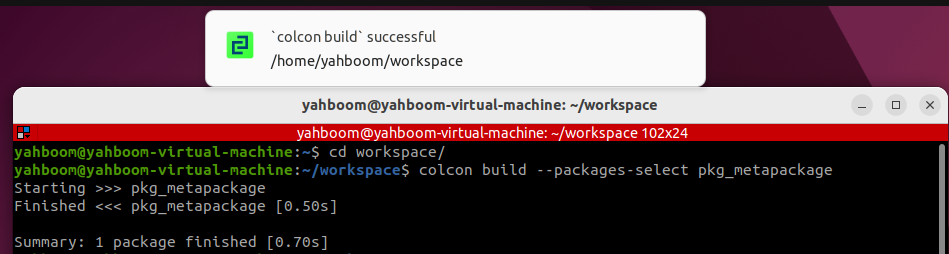
xxxxxxxxxxcmake_minimum_required(VERSION 3.5)project(pkg_metapackage)if(CMAKE_COMPILER_IS_GNUCXX OR CMAKE_CXX_COMPILER_ID MATCHES "Clang") add_compile_options(-Wall -Wextra -Wpedantic)endif()find_package(ament_cmake REQUIRED)ament_package()- Compile the meta-package
- No actual executable files will be generated
xxxxxxxxxxcolcon build --packages-select pkg_metapackage