Welcome to MSPM0G3507 Development Board repository
12.k230 gesture recognition
k230 gesture recognition
k230 gesture recognitionk230 and MSPM0 communication1. Experimental Prerequisites2. Experimental wiring3. Main code explanation4. Experimental Phenomenon
k230 and MSPM0 communication
1. Experimental Prerequisites
This tutorial uses the MSPMG3507 development board, and the corresponding routine path is [14.export\MSPM0-K230\12_k230_gesture].
K230 needs to run the [14.export\CanmvIDE-K230\12.gesture.py] program to start the experiment. It is recommended to download it as an offline program.
Things you need:
Windows computer MSPMG3507 development board K230 visual module (including TF card with image burned in) Two type-C data cables Connection cable
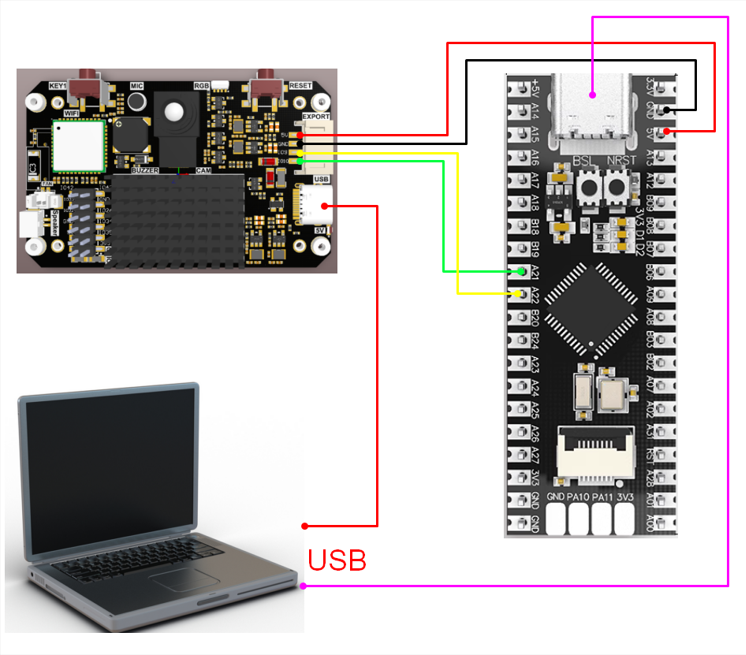
2. Experimental wiring
| k230 vision module | MSPM0 Development Board |
|---|---|
| 5V | VCC |
| GND | GND |
| TXD(IO9) | A22 |
| RXD(IO10) | A21 |
3. Main code explanation
xvoid Pto_Data_Parse(uint8_t *data_buf, uint8_t num){ uint8_t pto_head = data_buf[0]; uint8_t pto_tail = data_buf[num-1]; if (!(pto_head == PTO_HEAD && pto_tail == PTO_TAIL)) { sprintf(print_buf, "pto error:pto_head=0x%02x , pto_tail=0x%02x\n", pto_head, pto_tail); uart0_send_string(print_buf); return; } uint8_t data_index = 1; uint8_t field_index[PTO_BUF_LEN_MAX] = {0}; int i = 0; int values[PTO_BUF_LEN_MAX] = {0}; for (i = 1; i < num-1; i++) { if (data_buf[i] == ',') { data_buf[i] = 0; field_index[data_index] = i; data_index++; } } char msg[PTO_BUF_LEN_MAX] = {0}; for (i = 0; i < data_index; i++) { if (i == 2) { memcpy(msg, (char*)data_buf+field_index[i]+1, values[0]-field_index[i]-2); } else { values[i] = Pto_Char_To_Int((char*)data_buf+field_index[i]+1); } } uint8_t pto_len = values[0]; if (pto_len != num) { sprintf(print_buf, "pto_len error:%d , data_len:%d\n", pto_len, num); uart0_send_string(print_buf); return; } uint8_t pto_id = values[1]; if (pto_id != PTO_FUNC_ID) { sprintf(print_buf, "pto_id error:%d, func_id:%d\n", pto_id, PTO_FUNC_ID); uart0_send_string(print_buf); return; } sprintf(print_buf, "gesture:'%s'\n", msg); uart0_send_string(print_buf);}The above functions are for parsing K230 data. Only when they meet specific protocols can the corresponding data be parsed.
in
gesture: msg is the gesture information, 'UP', 'DOWN', 'LEFT', 'RIGHT', 'MIDDLE'
4. Experimental Phenomenon
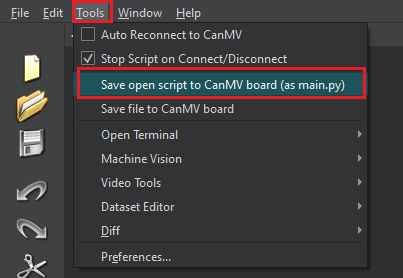
After connecting the cables, the k230 visual module runs offline. After K230 is connected to Canmv IDE, open the corresponding program, click [Save open script to CanMV board (as main.py)] on the toolbar, and then restart K230.
The hex file generated by the MSPM0 burning routine.
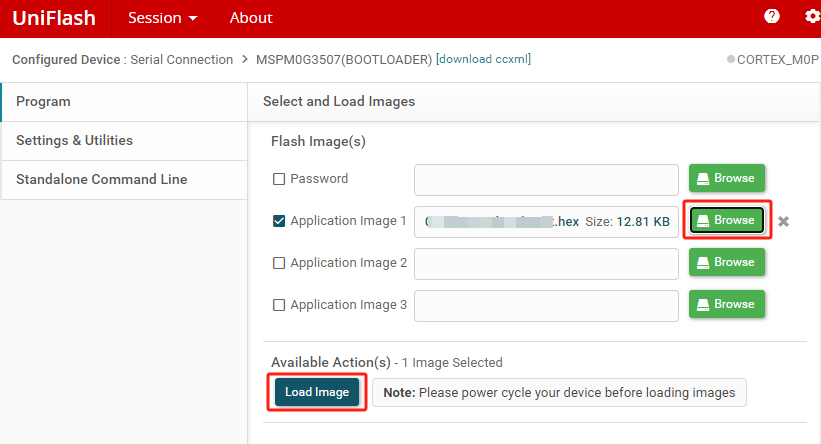
The serial port assistant is set to the interface shown in the figure
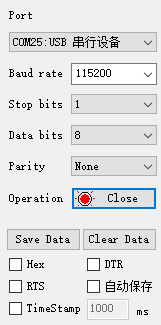
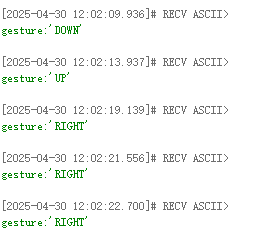
When the K230 camera recognizes a palm and the palm makes a corresponding gesture, the serial port assistant will print out the information transmitted by K230 to MSPM0.
in
- gesture: gesture information, 'UP', 'DOWN', 'LEFT', 'RIGHT', 'MIDDLE'
As shown in the figure below