Welcome to ROSMASTER X3 repository
0.How to use old voice module in new image
How to use old voice module in new image
1. Tutorial Notes
As of September 2025, all our rosmaster car images have been updated with the latest voice interaction module. If you would like to use the old secondary microphone interaction module with the new image, please refer to this tutorial.
2. New/Old Voice Interaction Module
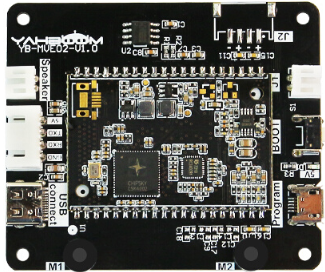
The image below shows the new voice interaction module. Be careful not to confuse them.
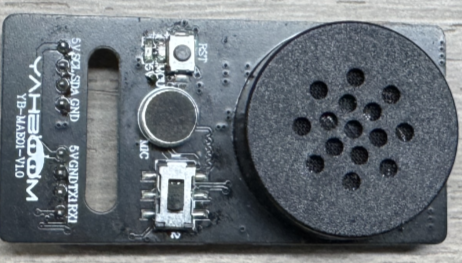
The picture below is the old two-microphone interaction module.
3. Steps to Convert Old Second Microphones to Compatible with the New Image
Note: The driver library environment for the new voice interaction module is already installed and set up at the factory. If you wish to revert to the old voice interaction module, please refer to the following tutorial
- You can find the corresponding Python driver library for the voice module in the source code summary and reinstall it.
The driver library for the old voice interaction module is py_install_V0.0.1
The driver library corresponding to the new voice interaction module is py_install_V0.0.2
- Python Driver Library Installation Steps
You can find the compressed package py_install_V0.0.1.rar in the source code section of the course materials. Place this package in the user directory of the corresponding board. Open a terminal and unzip it. (If the ROS environment is installed and running in a Docker container, you will need to place this package in the Docker container for decompression and installation.)
sudo apt install unrarunrar x py_install_V0.0.1.rar
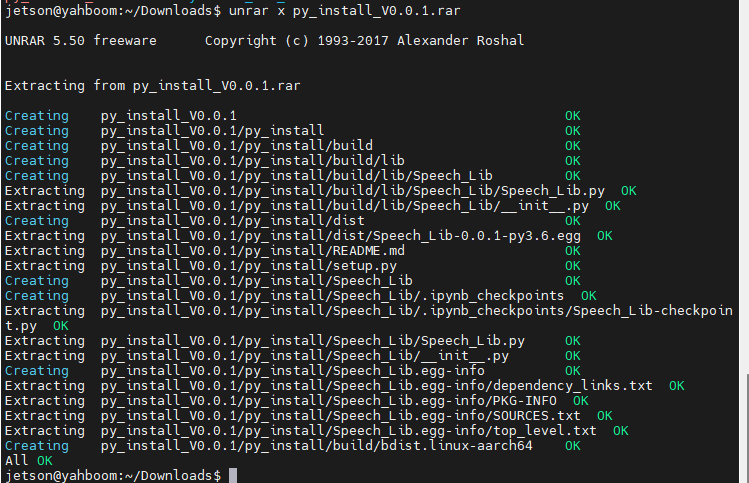
The image above shows a successful decompression.
Then install it on your system using the following command:
xxxxxxxxxxcd py_install_V0.0.1/
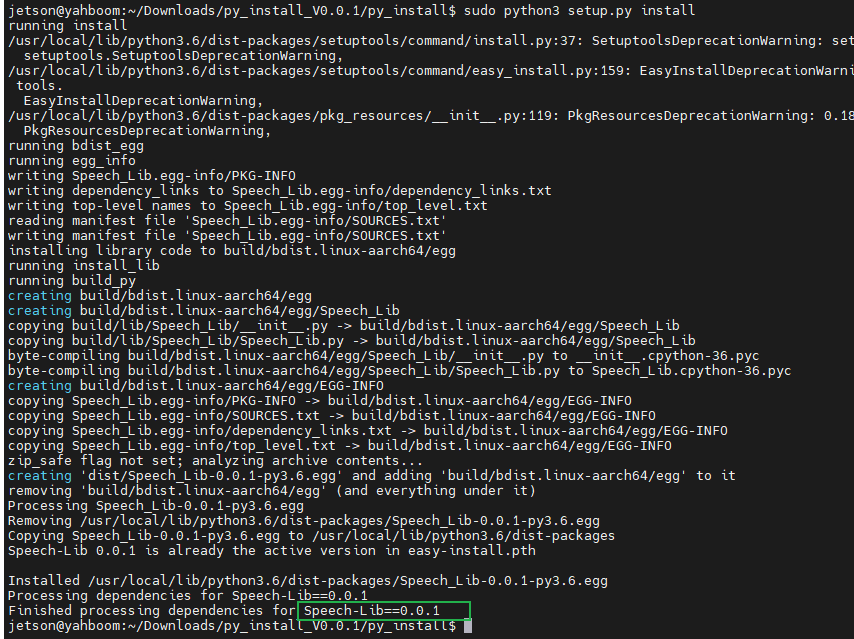
xxxxxxxxxxsudo python3 setup.py install
Enter the user password and press Enter to confirm. If you see the installation prompt Speech_Lib=x.x.x version number, it means the installation is successful.