yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
ROSMASTER X3📖
1.About ROSMASTER X3
  • 1.1 Wiring Introduction
  • 1.2 Precautions for battery
  • 1.3 First Trial
2.Assembly steps
  • Installation Video(1-10)
  • Installation Video(11-18)
  • Installation Video(20-28)
  • Installation Video(29-30)
3.ROS1-Remote control course
  • 3.1 APP remote control
  • 3.2 Model aircraft remote control
  • 3.3 Handle remote control
4.ROS1-Hardware course
  • 4.1 About expansion board_V3.0
  • 4.1 About expansion board_V1.0
  • 4.2 STM32 Development environment
  • 4.3 Button to control the buzzer to whistle
  • 4.4 FreeRTOS application
  • 4.5 Serial communication
  • 4.6 SBUS model aircraft remote control
  • 4.7 CAN bus communication
  • 4.8 RGB colorful light bar
  • 4.9 Timer interrupt to control PWM servo
  • 4.10 Control serial port servos
  • 4.11 Nine-axis attitude sensor to obtain data
  • 4.12 Control motor
  • 4.13 Timer captures the encoder data
  • 4.14.1 Kinematic Analysis of Mecanum Wheel
  • 4.14.2 Kinematics Analysis of Ackermann Car
  • 4.15 PID control robot movement
5.ROS1-Basic course
  • 5.1 Update the firmware
  • 5.2 Turn off the self-starting process at startup
  • 5.3 Install the Rosmaster driver library
  • 5.4 Buzzer whistle
  • 5.5 Control PWM servo
  • 5.6 RGB colorful light bar special effects display
  • 5.7 Control motor
  • 5.8 Control robot movement
  • 5.9 Control Serial Servo
6.ROS1-Linux operating system
  • 6.1 Virtual machine installation and use
  • 6.2 Linux basics
  • 6.3 Remote control
  • 6.4 Multi-machine communication configuration
  • 6.5 Static IP and hotspot mode
  • 6.6 Bind the device ID
  • 6.7 Web page real-time monitoring
  • 6.8 Expansion tutorial
  • 6.9.1 Jetson Nano write sytem
  • 6.9.2 Jetson Xavier NX write system
  • 6.9.3 Jetson TX2 NX write system
  • 6.9.4 Raspberry Pi write system
7.ROS1-Docker-pi5
  • 1、Docker overview and docker installation
  • 2、Common commands for docker image containers
  • 3、Docker images deeply understand and publish images
  • 4、Docker hardware interaction and data processing
  • 5、Enter the bot's docker container
  • 6、Robot development environment construction in Docker
  • 7、How customers can update docker images in the future
8.ROS1-ROS basic course
  • 1.ROS introduction
  • 2.ROS installation
  • 3.ROS common command tools
  • 4.ROS workspace
  • 5.ROS function package
  • 6.ROS node
  • 7.ROS topic publisher
  • 8.ROS topic subscribers
  • 9.ROS service client
  • 10.ROS service server
  • 11.ROS action client
  • 12.ROS action server
  • 13.ROS custom message reception
  • 14.ROS-launch file
  • 15.ROS-TF transformation
  • 16.ROS parameter service
  • 17.ROS-rviz use
  • 18.ROS-rqt tool usage
  • 19.Topic message recording and playback
  • 20.urdf model introduction
  • 21.gazebo introduction
  • 22.ROS distributed communication
9.ROS1-OpenCV courses
  • 9.1 Getting started with Open Source CV
  • 9.2 Geometric transformation
  • 9.3 Image processing and drawing text line segments
  • 9.4 Image beautification
  • 9.5 Opencv application
  • 9.6 AR vision
  • 9.7 AR QR code
  • 9.8 ROS+Opencv foundation
  • 9.9 ROS+Opencv application
  • 9.10 Data transformation and point cloud
  • 9.11 MediaPipe development
10.ROS1-Robot control course
  • 10.1 PID algorithm theory
  • 10.2 Robot PID debugging
  • 10.3 Robot information release
  • 10.4 Robot keyboard control
  • 10.5 Robot handle control
  • 10.6 Robot state estimation
  • 10.7 Robot calibration
  • 10.8 Robot URDF model
11.ROS1-Depth camera course
  • 11.1 How to use the Astra camera
  • 11.2 Astra camera calibration
  • 11.3 Astra Color Tracking
  • 11.4 Astra Object Tracking
  • 11.5 Visual tracking autopilot
  • 11.6 Pure visual 2D mapping and navigation
  • 11.7 RTAB-Map 3D mapping navigation
  • 11.8 ORB_SLAM2 basics
  • 11.9 ORB_SLAM2_Octomap
12.ROS1-Lidar course
  • 12.1 Lidar basic-SLAM
  • 12.1 Lidar basic-4ROS
  • 12.2 Lidar avoiding
  • 12.3 Lidar guard
  • 12.4 Lidar follow
  • 12.5 Patrol game
  • 12.6 gmapping mapping algorithm
  • 12.7 hector mapping algorithm
  • 12.8 karto mapping algorithm
  • 12.9 cartographer mapping algorithm
  • 12.10 rrt_exploration mapping algorithm
  • 12.11 AMCL
  • 12.12 Navigation and avoiding
  • 12.13 APP mapping and navigation
13.ROS1-Multi-robot control course
  • 13.1 Multi-machine handle control
  • 13.2 Multi-machine navigation
  • 13.3 Multi-machine formation
  • 13.4 Multi-machine surround
14.ROS1-Deep learning courses
  • 14.1 KNN recognizes handwritten digits
  • 14.2 Basic use of TensorFlow
  • 14.3 Basic use of PyTorch(jetson)
  • 14.4 yolov5 model training(jetson)
  • 14.5 yolov5+tensorrt acceleration(jetson)
  • 14.6 yolov4-tiny
15.ROS1-Voice control courses
  • 15.0 How to use old voice module in new image
  • 15.1 Introduction of voice control module-NEW
  • 15.2 Voice control module port binding-NEW
  • 15.1 Introduction of voice control module-Old
  • 15.2 Voice control module port binding-Old
  • 15.3 Voice control car movement
  • 15.4 Voice control Autopilot
  • 14.5 Voice control color recognition
  • 15.6 Voice control color tracking
  • 15.7 Voice control multi-point navigation
16.ROS1-Model training Autopilot
  • 16.0 ReadMe
  • 16.1 yolov5 to train traffic signs
  • 16.2 TensorRt acceleration identification mark
  • 16.3 Road sign indication function description
  • 16.4 Collect data
  • 16.5 Training model
  • 16.6 Model transformation and application
  • 16.7 AI Autopilot
17.ROS2- Remote control course
  • 1. APP control
  • 2. Model aircraft control
  • 3. Wireless Handle Control Tutorial
18.ROS2- Hardware course
  • 1. About expansion board_V1.0
  • 1. About expansion board_V3.0
  • 2. STM32 Development environment
  • 3. Button control
  • 4. FreeRTOS application
  • 5. Serial communication
  • 6. SBUS model aircraft remote control
  • 7. CAN bus communication
  • 8. RGB colorful light bar
  • 9. Timer interrupt to control PWM servo
  • 10. Control serial port servos
  • 11. Nine-axis attitude sensor to obtain data
  • 12. Control motor
  • 13. Timer captures the encoder data
  • 14. Robot kinematics analysis theory
  • 15. PID control robot movement
19.ROS2- ROSMASTER basic course
  • 1. Update the firmware
  • 2. Turn off the self-starting process at startup
  • 3. Install the Rosmaster driver library
  • 4. Buzzer whistle
  • 5. Control PWM servo
  • 6. RGB colorful light bar special effects display
  • 7. Control motor
  • 8. Control robot movement
  • 9. Control Serial Servo
20.ROS2- Linux operating systemnew
  • 1. Virtual machine installation and use
  • 2. Linux basics
  • 3. Remote control
  • 4. Multi-machine communication configuration
  • 5. Static IP and hotspot mode
  • 6. Bind the device ID
  • 7. Web page real-time monitoring
  • 8. Expansion tutorial
  • 9.1 Jetson Nano write sytem
  • 9.2 Raspberry Pi write system
  • 9.3 Orin series write system
  • 10.Jetpack old system upgraded to SUPER systemnew
21.ROS2- Docker(Nano Pi)
  • 1. Docker Overview and Docker Installation
  • 2.Common commands for docker image containers
  • 3.Docker images deeply understand and publish images
  • 4. Docker hardware interaction and data processing
  • 5. Entering the Docker Container of the Robot
  • 6. Building a Robot Development Environment in Docker
  • 7. Method for customers to update Docker images in the future
22.ROS2- ROS2 Basic Tutorial
  • 1.Introduction to ROS2
  • 2.ROS2 install Humble
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 Rqt Toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
23.ROS2- Robot control course
  • 1. PID Algorithm Theory
  • 2. Robot information release
  • 3. Robot control
  • 4. Robot state estimation
  • 5. Robot calibration
  • 6. URDF model
24.ROS2- Depth camera course
  • 1.Depth camera usage
  • 2. Camera internal reference calibration
  • 3. color tracking
  • 4. KCF object tracking
  • 5. ORB_SLAM2 basics
  • 6. ORB_ SLAM2 PCL mapping
  • 7. ORB_ SLAM2 Octomap mapping
  • 8. RTAB-Map 3D mapping navigation
25.ROS2- Lidar course
  • 1. Introduction and Use of Lidar
  • 2. Lidar avoiding
  • 3. Lidar follow
  • 4. Lidar guard
  • 5. Patrol game
  • 6. Gmapping mapping algorithm
  • 7. Cartographer mapping algorithm
  • 8. Navigation and obstacle avoidance
  • 9. Rosmaster_ X3 conducts mapping through the APP
  • 10. Rosmaster_ X3 Navigation through APP
26.ROS2- OpenCV courses
  • 1. OpenCV Basic Course
  • 2. ROS+opencv application
  • 3. QR code creation and recognition
  • 4. AR Vision
  • 5. Mediapipe fun gameplay
  • 6、line patrol automatic driving
27.ROS2- Voice control courses
  • 0.How to use old voice module in new image
  • 1. Introduction of voice module-new
  • 2. Voice control module port binding-new
  • 1. Introduction of voice module and port binding-old
  • 3. Voice control car movement
  • 4. Voice control Autopilot
  • 5. Voice control color recognition
  • 6. Voice control color tracking
  • 7. Voice control multi-point navigation
28.Deep learning courses(SUPER)
  • 1.KNN recognizes handwritten digitsnew
  • 2.Basic use of TensorFlownew
  • 3.Basic use of PyTorch(jetson)new
  • 4.YOLOv11Model conversion(SUPER)new
  • 5.YOLOv11Dataset annotation(SUPER)new
  • 6.YOLOv11Model conversion + tensorrt acceleration(SUPER)new
  • 7.YOLOv11Object recognition(SUPER)new
29.ROS2-Multi-robot control
  • 1. Multi-robot control
  • 2. Multi-robot navigation
LLM tutorial
1.Development environment
  • 0. Model usage instructions
  • 1.Environments deployment
  • 2.Dialogue platform installation
2.Jetson Nano B01
  • 1.Qwen2 model
  • 2.TinyLlama model
  • 3.Phi-3 model
  • 4.Gemma model
  • 5.Orca Mini model
  • 6.StarCoder2 model
  • 7.DeepSeek-R1 model
  • 8.Expand LLaVA-Phi3
3.Jetson Orin NXNANO
  • 1.Llama3 model
  • 2.Qwen2 model
  • 3.Phi-3 model
  • 4.Gemma model
  • 5.WizardLM2 model
  • 6.Codellama model
  • 7.DeepSeek-R1 model
  • 8.Orca Mini model
  • 9.StarCoder2 model
  • 10.TinyLlama model
  • 11.Expand LLaVA
  • 12.Expand LLaVA-Phi3
4.Raspberry Pi 5B
  • 1.Meta AI Llama3 model
  • 2.Qwen2 model
  • 3.Phi-3 model
  • 4.Gemma model
  • 5.WizardLM2 model
  • 6.Meta AI Codellama model
  • 7.DeepSeek-R1 model
  • 8.Expand LLaVA
FAQ
  • 1.Using your own Jetson board, ROSMASTER X3 cannot start normally
Download
  • RemoteCtrl_APP(Android/iOS)
  • Mapping_APP(iOS_Android)
  • Instruction Manual
  • SystemFile_ROS2
  • SystemFile_ROS1
  • SystemFile_ROS2_OrinNANOSUPER
  • SystemFile_ROS2_OrinNXSUPER
  • Code
  • Jetson_Boot_USB.tar.gz
  • VM software
  • Autopilot Annex
  • Other_Annex_File
  • LLM_SystemFile
  • ROS2_Basic_VM
Download ZIP
FAQ
  • 1、How to connect OLED?

Welcome to ROSMASTER X3 repository

9.9 ROS+Opencv application

9. ROS+Opencv application

9. ROS+Opencv application 9.1. Overview 9.2. Use 9.2.1. Start 9.2.2. Display method 9.2.3. Effect display 9.3. Node 9.3.1. edge detection algorithm 9.3.2. Contour moment 9.3.3. Face Recognition

9.1. Overview

wiki: http://wiki.ros.org/opencv_apps

Source code: https://github.com/ros-perception/opencv_apps.git

Most of the code was originally taken from https://github.com/Itseez/opencv/tree/master/samples/cpp

Feature pack: ~/software/library_ws/src/opencv_apps

The topic subscribed by this function package is [/image]. What we need to do is to open the camera node, write a node that converts the camera topic into a [/image] node, and publish the [/image] topic.

The path to the node that enables the camera and publishes the [/image] topic:

~/yahboomcar_ws/src/yahboomcar_visual/scripts/pub_image.py 

The opencv_apps program provides various nodes that run opencv's functions internally and publish the results to a ROS topic. When using the opencv_apps program, according to your own business needs, you only need to run a launch file, so you don't have to write program codes for these functions.

ROS Wiki has related node analysis, topic subscription and topic publishing of corresponding nodes, introduction of related parameters, etc. See the ROS WiKi for details.

image-20210903181852659

9.2. Use

xxxxxxxxxx
#Raspberry Pi 5 master needs to enter docker first, please perform this step
#If running the script into docker fails, please refer to ROS/07, Docker tutorial
~/run_docker.sh

9.2.1. Start

Step 1: Start camera

xxxxxxxxxx
roslaunch yahboomcar_visual opencv_apps.launch img_flip:=false 
  • img_flip parameter: Whether the image needs to be flipped horizontally, the default is false.

The [usb_cam-test.launch] file opens the [web_video_server] node by default, and you can directly use the [IP:8080] webpage to view the image in real time.

Step 2: Start the function of Opencv_apps

<PI5 needs to open another terminal and enter the same docker container
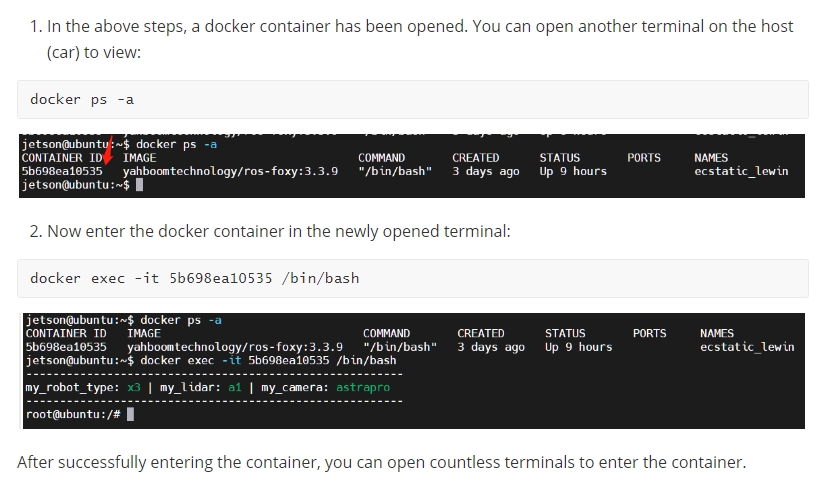
image-20240408144126098

xxxxxxxxxx
roslaunch  opencv_apps  face_recognition.launch              # face recognition 
roslaunch  opencv_apps  corner_harris.launch                 # harris corner detection 
roslaunch  opencv_apps  camshift.launch                      # target tracking algorithm 
roslaunch  opencv_apps  contour_moments.launch               # contour moments 
roslaunch  opencv_apps  convex_hull.launch                   # polygon outline 
roslaunch  opencv_apps  discrete_fourier_transform.launch    # discrete Fourier transform algorithm 
roslaunch  opencv_apps  edge_detection.launch                # edge detection algorithm 
roslaunch  opencv_apps  face_detection.launch                # face detection algorithm 
roslaunch  opencv_apps  fback_flow.launch                    # Optical flow detection algorithm 
roslaunch  opencv_apps  find_contours.launch                 # contour detection 
roslaunch  opencv_apps  general_contours.launch              # general contour detection 
roslaunch  opencv_apps  goodfeature_track.launch             # feature point tracking 
roslaunch  opencv_apps  hls_color_filter.launch              # HLS color filter 
roslaunch opencv_apps  hough_circles .launch #                 Hough circle detection 
roslaunch  opencv_apps  hough_lines.launch                   # Hough line detection 
roslaunch  opencv_apps  hsv_color_filter.launch              # HSV color filter 
roslaunch  opencv_apps  lk_flow.launch                       # LK optical flow algorithm 
roslaunch  opencv_apps  people_detect.launch                 # human detection algorithm 
roslaunch  opencv_apps  phase_corr.launch                    # Phase correlation displacement detection 
roslaunch  opencv_apps  pyramids.launch                      # Image pyramid sampling algorithm 
roslaunch  opencv_apps  rgb_color_filter.launch              # RGB color filter 
roslaunch  opencv_apps  segment_objects.launch               # clear background detection algorithm 
roslaunch  opencv_apps  simple_flow.launch                   # Simplified optical flow algorithm 
roslaunch  opencv_apps  smoothing.launch                     # simple filter 
roslaunch  opencv_apps  threshold.launch                     # threshold image processing 
roslaunch  opencv_apps  watershed_segmentation.launch        # watershed segmentation algorithm 

Almost every functional case will have a parameter [debug_view], Boolean type, whether to use Opencv to display the picture, which is displayed by default.

Set to [False] if no display is required, for example

xxxxxxxxxx
roslaunch opencv_apps contour_moments.launch  debug_view:=False 

However, after this is started, some cases cannot be displayed in other ways, because in the source code, some [debug_view] is set to [False], which will turn off image processing.

9.2.2. Display method

  • rqt_image_view

Enter the following command to select the corresponding topic

xxxxxxxxxx
rqt_image_view 
  • opencv

The system defaults to display, no need to do anything.

  • web viewing

(same as the local area network) Enter IP+port in the browser, for example:

xxxxxxxxxx
192.168.2.79:8080 

9.2.3. Effect display

  • Optical flow detection algorithm

Move the screen and observe the phenomenon.

image-20210903215736978

  • Feature point tracking

image-20210903215933659

  • Hough circle detection

image-20210903220054380

  • Hough Line Detection

The lower the threshold, the more lines, and the easier the picture gets stuck.

image-20210903220336691

  • Phase-dependent displacement detection

The faster the camera moves, the larger the radius of the circle.

image-20210903220246064

  • watershed segmentation algorithm

Use the mouse to select different objects, and the system will automatically distinguish them.

image-20210903220528108

9.3. Node

Each case in this section will have a topic of subscribing to images and publishing images.

9.3.1. edge detection algorithm

parametertypedefaultParse
~use_camera_infobooltrueSubscribe to the topic [camera_info] to get the default coordinate system ID, otherwise use the image information directly.
~debug_viewboolfalsewhether to create a window to display the node image
~edge_typeint0Specify the edge detection method: 0: Sobel operator, 1: Laplacian operator, 2: Canny edge detection
~canny_threshold1int100Specify the second canny threshold
~canny_threshold2int200Specify the first canny threshold
~apertureSizeint3The aperture size of the Sobel operator.
~apply_blur_preboolTruewhether to apply blur() to the input image
~ postBlurSizedouble3.2Enter the image aperture size
~apply_blur_postboolFalsewhether to apply GaussianBlur() to the input image
~L2gradientboolFalseParameters of canny
~queue_sizeint3queue size

image-20220219122359784

image-20210903212947694

9.3.2. Contour moment

parametertypedefaultParse
~use_camera_infobooltrueSubscribe to the topic [camera_info] to get the default coordinate system ID, otherwise use the image information directly.
~debug_viewboolfalsewhether to create a window to display the node image
~canny_low_thresholdint0Canny edge detection low threshold
~queue_sizeint3queue size

image-20220219122556604

9.3.3. Face Recognition

This case is self-training and real-time recognition through real-time collection of human images, and the steps are slightly complicated.

parametertypedefaultParse
~approximate_syncboolfalseSubscribe to the topic [camera_info] to get the default coordinate system ID, otherwise use the image information directly.
~queue_sizeint100Queue size for subscribing to topics
~model_methodstring"eigen"Methods of face recognition: "eigen", "fisher" or "LBPH"
~use_saved_databooltrueLoad training data from ~data_dir path
~save_train_databooltrueSave the training data to the ~data_dir path for retraining
~data_dirstring"~/opencv_apps/face_data"Save training data path
~face_model_widthint190width of training face images
~face_model_heightint90height of training face images
~face_paddingdouble0.1Fill ratio for each face
~model_num_componentsint0The number of components of the face recognizer model (0 is considered unlimited)
~model_thresholddouble8000.0face recognition model threshold
~lbph_radiusint1Radius parameter (only for LBPH method)
~lbph_neighborsint8Neighborhood parameter (only for LBPH method)
~lbph_grid_xint8grid x parameter (only for LBPH method)
~lbph_grid_yint8grid y parameter (only for LBPH method)
~queue_sizeint100Image subscriber queue size

Steps:

  1. First, enter the character name after the colon in the following figure: Yahboom

  2. Confirm the name: y

  3. Then place the face in the center of the image and click OK.

  4. Add a photo cyclically: y, click OK.

  5. To end the image collection, enter: n, and click OK.

  6. Close the launch file and restart.

If you need to enter the recognized recognition, cycle 1 to 5 in turn, until all recognition personnel are completed, and then perform the sixth step.

image-20210903213928003

Step 3: To ensure that the face can be recognized

image-20210906103107655

The final recognition effect

image-20210906103143423

ROS+Opencv foundation
Data transformation and point cloud

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文