yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
L-Type Motor📖
1.About motor
  • About motor
2.ROS robot control board drive
  • 0. Notes (Must read!!)
  • 1. Control motor
  • 2. Timer captures encoder data
  • 3. PID control robot car
  • 4. Kinematic Analysis-Mecanum wheel structure
  • 5. Kinematic Analysis-Ackerman structure
  • 6. Kinematic Analysis-4WD structure
3.STM32 board car tutorials
0. Notes (Must read!!)
  • Notes
1. Get started quickly
  • 0. Installation Instructions
  • 1. Version configuration
  • 2. Smart car installation video
  • 3. Precautions for use
2. Introduction to STM32 development board
  • 0. Notes (must read)
  • 1. Learn about STM32
  • 2. Introduction to STM32 development board
  • 3. Development board pin assignment
  • 4. Introduction to HAL library and LL library
3. Setting up and using the development environment
  • 1. Common development tools
  • 2. STM32CubeMX Install - Use
  • 3. STM32CubeIDE Install - Use
  • 4. Common Driver Installation
  • 5. Program download and simulation
  • 6. Engineering experience and migration
4. Car expansion tutorial
  • 1. Servo control
  • 2. Basic use of ultrasonic steering gear gimbal
  • 3. Motor control
  • 4. OLED display light sensitivity value
  • 5. Infrared sensor
  • 6. Four-way tracking module
  • 7. Infrared remote control
  • 8. Ultrasonic ranging
  • 9. PS2 controller test
  • 10. Car line patrol
  • 11. Ultrasonic follow
  • 12. Ultrasonic obstacle avoidance
  • 13. Ultrasonic obstacle avoidance (servo gimbal version)
  • 14. Infrared sensor obstacle avoidance
  • 15. Infrared remote control
  • 16. PS2 handle remote control
4. 2-channel motor drive module
For MSPM0G3507
  • 1.AT8236 drive tutorials
  • 2.TB6612 drive tutorials
For MSPM0G3519
  • 1.AT8236 drive tutorialsnew
  • 2.TB6612 drive tutorialsnew
5. 4-channel motor drive module
Introduction and Debug
  • 1.Introduction to 4-channel motor drive board
  • 2. Control command
  • 3. 520 motor introduction and usage
  • 4. PC host
IIC communication
  • For MSPM0G3507
  • For MSPM0G3519new
  • For STM32
  • For ESP32
  • For Arduino
  • For PICO2
  • For Jetson NANO
  • For RPi5
  • For RDK X5
USART communication
  • For MSPM0G3507
  • For MSPM0G3519new
  • For STM32
  • For ESP32
  • For Arduino
  • For PICO2
  • For Jetson NANO
  • For RPi5
  • For RDK X5
Download
  • 3D-Model-File
  • Code
Download ZIP

Welcome to L-Type Motor repository

1.AT8236 drive tutorials

AT8236 drive tutorials

1. Learning objectives

Use AT8236 motor driver module to drive the motor.

2. Hardware connection

Connect the pins of MSPM0G3507 and AT8236
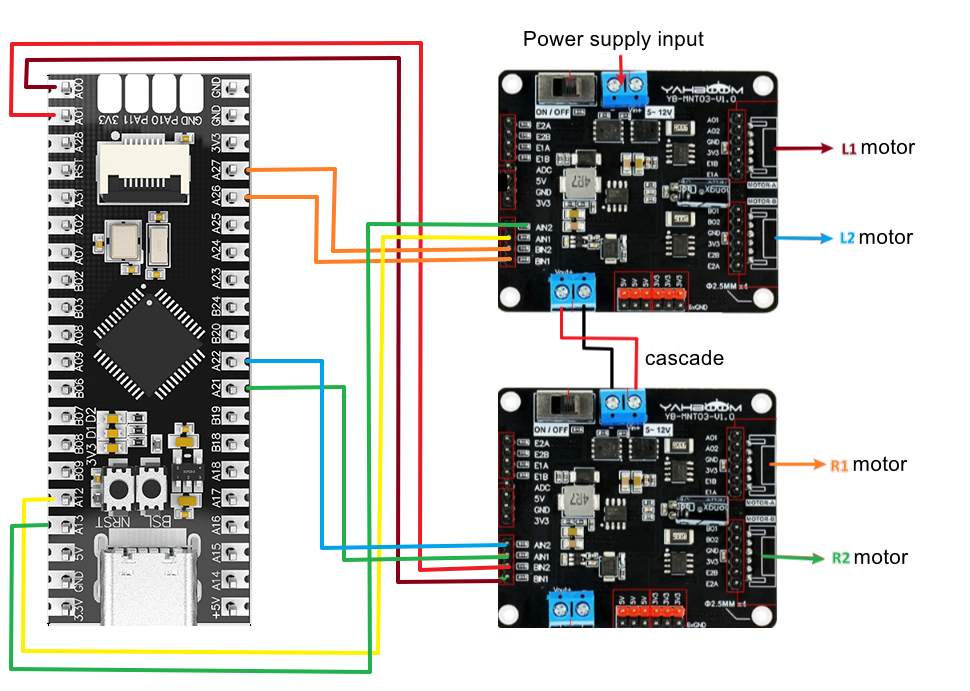
image-20241210105955329

L1 motor:

MSPM0G3507AT8236
PA12AIN1
PA13AIN2

L2 motor:

MSPM0G3507AT8236
PA26BIN1
PA27BIN2

R1 motor:

MSPM0G3507AT8236
PA21AIN1
PA22AIN2

R2 motor:

MSPM0G3507AT8236
PA0BIN1
PA1BIN2

Motor and voltage regulator board pin connection.

AT8236Motor
AO1Motor+
AO2Motor-

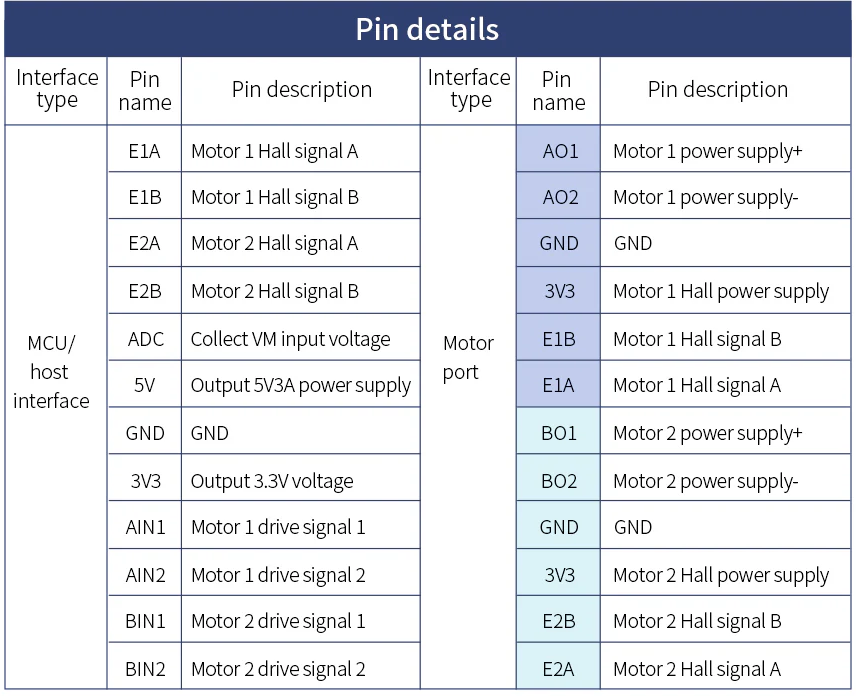
AT8236 motor driver module voltage standard version pin description.
2

3. Code analysis

  • bsp_at8236.h
​x
#ifndef __BSP_TB6612_H_
#define __BSP_TB6612_H_

#include "ti_msp_dl_config.h"


void init_motor(void);

void L1_control(uint16_t motor_speed,uint8_t dir);
void L2_control(uint16_t motor_speed,uint8_t dir);
void R1_control(uint16_t motor_speed,uint8_t dir);
void R2_control(uint16_t motor_speed,uint8_t dir);

#endif

Define four motor control functions.

  • bsp_at8236.c
xxxxxxxxxx
void L1_control(uint16_t motor_speed,uint8_t dir)
{
    if(dir)
    {
            DL_TimerA_setCaptureCompareValue(PWM_L1_INST, motor_speed, DL_TIMER_CC_0_INDEX);
            DL_TimerA_setCaptureCompareValue(PWM_L1_INST, 0, DL_TIMER_CC_1_INDEX);
    }
    else
    {
            DL_TimerA_setCaptureCompareValue(PWM_L1_INST, 0, DL_TIMER_CC_0_INDEX);
            DL_TimerA_setCaptureCompareValue(PWM_L1_INST, motor_speed, DL_TIMER_CC_1_INDEX);
    }

}

The L1_control function is used to control the speed and direction of the L1 motor by adjusting the duty cycle of the PWM signal.

motor_speed and dir represent the motor speed and motor direction of the motor respectively.

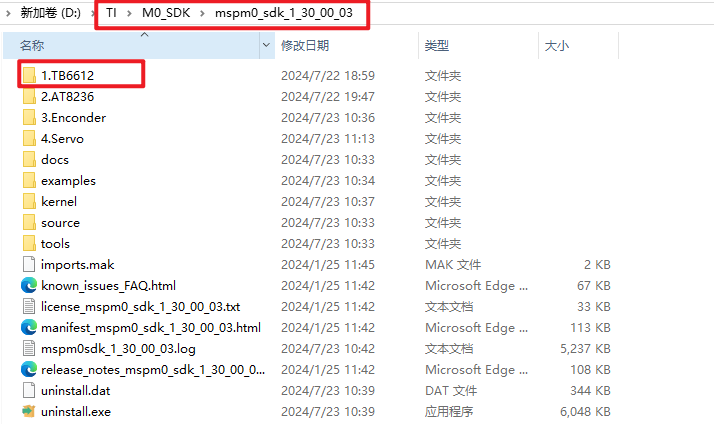
Note: The project source code must be placed in the SDK path for compilation,

For example, path: D:\TI\M0_SDK\mspm0_sdk_1_30_00_03\TB6612
4


PS2 handle remote control
TB6612 drive tutorials

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文