Welcome to ROS Robot Expansion Board repository
1.1 Expansion Board Introduction_V3.0
1、Expansion Board Introduction
1、Expansion Board Introduction1.1、Schematic diagram of front component distribution of expansion board1.2、Schematic diagram of component distribution on the back of expansion board1.3、Analysis of common Problems on expansion modules
1.1、Schematic diagram of front component distribution of expansion board
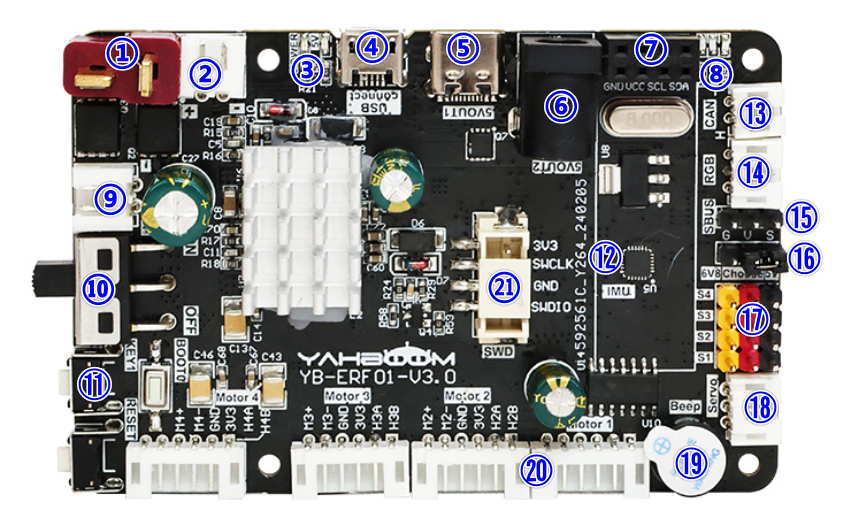
① T DC 12V power input port: Serves as the main power input for the expansion module and connects to the DC 12V power supply or 12V battery.
②⑨ DC 12V power output: provides 12V DC power.
③ Power indicator:indicates whether the power supply is normal.
④ Micro USB data interface: connect the host communication and burning program.
⑤ Type-c interface: provides DC 5V , supports Raspberry Pi 5 power supply protocol, providing 5.1V/5A power supply for Raspberry Pi 5. cannot communicate only with power supply.
⑥ DC 5V output interface: power Jetson Nano.
⑦ I2C interface: Connects to external I2C devices, such as OLED screens.
⑧Indicators: data indicator and 6.8V voltage indicator.
⑩ DC 12V power switch: main power switch.
⑪ Key: KEY1: user function key, which can be customized by programming. RESET: RESET button for the onboard microcontroller. Button BOOT0: BOOT0 button for the onboard microcontroller to enter the burning mode.
⑫ Nine-axis attitude sensor: Provides the current attitude of the expansion board.
⑬ CAN interface: Connects to a CAN device.
⑭ RGB bright light bar interface: connect RGB bright light bar.
⑮ SBUS interface: connect the receiver of remote control of model airplane.
⑯ PWM steering gear voltage switching: change the position of jumper cap can choose 6.8V or 5V voltage for PWM steering gear power supply.
⑰ PWM steering gear interface: can connect to 6.8V or 5V voltage PWM steering gear, select the corresponding voltage on ⑯ persons according to the steering gear voltage.
⑱ Serial actuator interface: connects to the serial actuator arm.
⑲ Buzzer: Used for whistling alarm.
⑳ Four-way motor connection port: connect four motors. Please refer to the corresponding course documents according to the connection mode of different models.
㉑ SWD debugging interface: Connect to the SW interface on ST-Link or J-Link, used to debug the microcontroller or download the microcontroller firmware.
1.2、Schematic diagram of component distribution on the back of expansion board
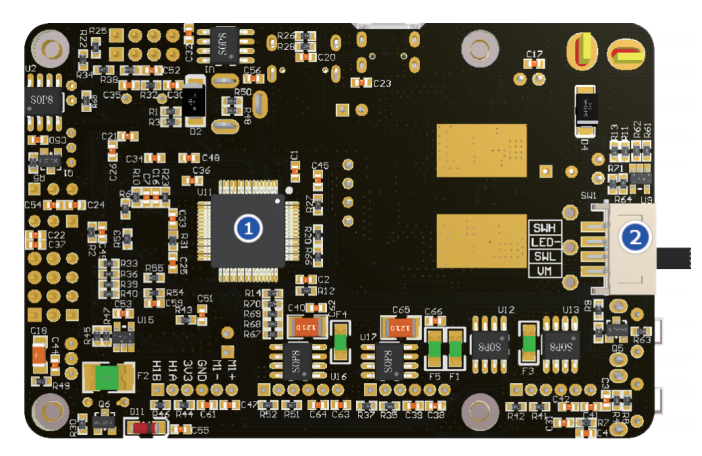
① Onboard microcontroller: mainly responsible for the control of peripherals on the expansion board, such as buzzer, motor drive, etc.
②Metal key switch PH2.0 interface: An external metal switch can be connected in parallel with the onboard power switch. You only need to turn on one of the switches to turn on the power.
1.3、Analysis of common Problems on expansion modules
Q : Analysis of common Problems on expansion modules
A:The Jetson Nano sends serial port data to the expansion board via the USB port. The expansion board integrates a single chip microcomputer to receive and parse the serial port data, and then processes the specific commands to be executed.。
Q : How does the robot power? Will the Jetson Nano need additional power??
A:The car is equipped with a battery pack before delivery. Plug the battery pack into the T-type interface of DC 12V power supply on the expansion board and turn on the main power switch. The expansion board integrates a voltage conversion chip to provide DC 5V power supply and transmits power to Jetson Nano through the DC 5V power cord.
Q : Which functions on the expansion board are managed by the microcontroller?
A:The SCM management on the expansion board includes: mechanical arm, active buzzer, attitude sensor, PWM steering gear head, motor, RGB bright lights, KEY1, RESET, SBUS interface, CAN interface, etc.
Q : How to update SCM firmware on expansion module? Why to update the MCU firmware?
A:The microcontroller integrated with the expansion module has burned its firmware before delivery. Do not update the firmware if it is not necessary. If you need to update the firmware, please refer to the firmware update tutorial to update the MCU firmware.
Q: What is the difference between expansion board hardware versions V1.0 and V3.0?
A:The hardware version V3.0 mainly upgrades the IMU chip to ICM20948, adds a SWD debugging interface and an external switch interface, supports the Raspberry Pi 5 power supply protocol, and can provide 5.1V/5A power supply for the Raspberry Pi 5. Some circuits have been modified and optimized. etc. Version V3.0 requires the use of Python library V3.3.X or above.