Welcome to MicroROS Robot repository
4. FAQ
Why does the robot need to configure parameters?
Answer: Since each user's WiFi environment and IP address are different, parameters need to be configured according to the actual situation.
Regarding the microROS control board car type, what is the difference between the Raspberry Pi version and the virtual machine/computer version?
Answer: The Raspberry Pi version and the virtual machine/computer version use the same factory firmware. The versions are distinguished by configuration parameters. The Raspberry Pi version uses serial port communication, and the virtual machine/computer uses WiFi-UDP communication.
What should I do if I cannot read and write the configuration parameters after configuring the Raspberry Pi version?
Answer: Please press the reset button of the robot. It will be in the configuration state within 5 seconds after powering on (the MCU indicator light flashes once every 300 milliseconds). At this time, you can run the configuration file to read and write the configuration normally.
The microROS control board has two type-C ports. What is the difference?
Answer: The type-C interface marked Serial is mainly used for communication, configuration, firmware burning, etc. The type-C interface marked 5V OUT is used to power the Raspberry Pi 5.
Why does the robot buzzer keep beeping?
Answer: When the battery power of the robot is low, it will make a beep beep sound (one beep every 100 milliseconds). At this time, the robot cannot be controlled. Please save the code, shut down, and then charge the robot.
What does the robot MCU status indicator light mean?
Answer: The baseboard microcontroller boots up and enters the configuration state. After about 5 seconds, it automatically enters the connection agent state. After the agent is successfully connected, it starts to initialize ROS related topics. If there is a microROS error, it will automatically end. microROS task, if microROS initialization is completed, it will enter normal state.
| LED light indication function | LED light phenomenon |
|---|---|
| configuration status | The LED light flashes (once every 300 milliseconds) |
| connection agent status | LED light flashes slowly (once every 1 second) |
| microROS error | LED light flashes quickly (once every 50 milliseconds) |
| normal status | LED light flashes twice (fast flashes 2 times every 3 seconds) |
| low voltage state | LED light flashes quickly (blinks once every 100 milliseconds) |
How to avoid interference when there are multiple robots in the same LAN?
Answer: You can avoid interference by setting different ROS_DOMAIN_ID. The setting range of ROS_DOMAIN_ID: 0~101. Please modify the set_ros_domain_id(20) parameter in the config_robot.py file and write the configuration to the microROS control board. Then add a line "export ROS_DOMAIN_ID=20" to the .bashrc file in the virtual machine/computer user directory, save and restart the terminal.?
Answer: Press the reset button again to reconnect to the agent.
What should I do if an error appears when opening the microROS agent?
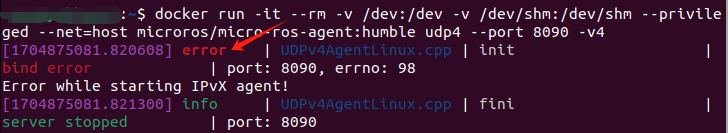
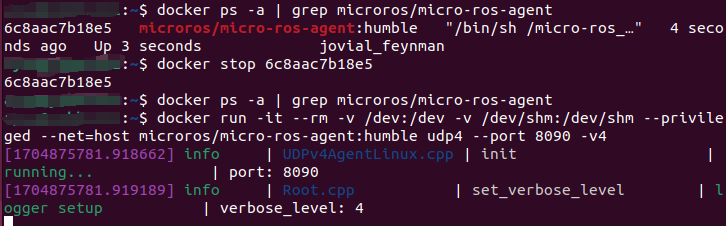
Answer: The microROS agent can only be opened in one terminal. If a terminal has already opened the microROS agent in the background, an error will be reported when opening the agent again. Please press Ctrl+C on the original agent terminal to exit the agent and then run the agent. If the agent is shut down abnormally, causing the docker process to run in the background, please first query the current docker process number, end the current agent docker process, and then run the agent.
docker ps -a | grep microros/micro-ros-agentdocker stop xxxxxxxxxxdocker run -it --rm -v /dev:/dev -v /dev/shm:/dev/shm --privileged --net=host microros/micro-ros-agent:humble udp4 --port 8090 -v4