yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
MicroROS Robot📖
01. Introduction
  • 0.Unpacking and reviewing video
  • 1. ReadMe - learning route
  • 2. Introduction to lidar
  • 3. Introduction to microROS control board
  • 4. FAQ
  • 5. About charging
02. Assembly course
  • Assembly steps
03. Preparation
  • First Trial
  • 1. Write firmware
  • 2. How to install and use VM
  • 3. microROS control board configuration
  • 4. Connect to microROS agent
04. VM Remote control course
  • 1. VM keyboard remote control
  • 2. VM handle remote control
05.ROS-WiFi module configuration
  • 0. Serial port configuration WiFi instructions
  • 1.Module usage in car(ReadMe)
  • 2.Connection module proxy
  • 3.Camera picture correction(ReadMe)
  • 4.Calibrate servo PTZ(ReadMe)
06.ROS+OpenCV course
  • 1.OpenCV Getting started
  • 2.Geometric transformation
  • 3.Image processing and drawing text line segments
  • 4.Image beautification
07.Mediapipe course
  • 1. Hand detection
  • 2. Posture detection
  • 3. Overall inspection
  • 4. Face detection
  • 5. Face recognition
  • 6. Facial effects
  • 7. 3D object recognition
  • 8. Brush
  • 9. Finger control
  • 10. Gesture recognition
08. Robot basic course
  • 1. Robot information release
  • 2. Robot keyboard control
  • 3. Robot handle control
  • 4. Robot state estimation
  • 5. Linear speed calibration
  • 6. Angular velocity calibration
  • 7. Robot URDF model
09. Lidar course
  • 1. Lidar avoid
  • 2. Lidar following
  • 3. Lidar guard
  • 4. Lidarpatrol
  • 5. Gmapping mapping
  • 6. Cartographer mapping
  • 7. Navigation2 navigation avoid
  • 8. ROS Robot APP mapping
  • 9. ROS Robot APP navigation
10. Multi-machine course
  • 1. Multi-machine handle control
  • 2.Multi-machine keyboard control
  • 3. Multi-machine navigation
11.Robot visual interaction
  • 1. Color tracking
  • 2. Object recognition and tracking
  • 3.Face recognition tracking
  • 4.Autonomous driving line patrol
  • 5.QR code motion control
  • 6.Gesture control car movement
  • 7.Palm control car movement
  • 8.Gesture control car action group
  • 9.Palm control 2DOF servo PTZ
12. Linux basic course
  • 1. Introduction to Linux system
  • 2. Ubuntu file system
  • 3. Ubuntu common commands
  • 4. Ubuntu common editors
  • 5. Ubuntu software operation commands
  • 6. Virtual machine installation
  • 7. SSH remote control
  • 8. VNC remote control
  • 9. Remote file transfer
  • 10. Driver library and communication
  • 11. Static IP and hotspot mode
  • 12. Bind device ID
  • 13. Capacity expansion and resource allocation
  • 14. Update system software source
  • 15. set root password
  • 16. sudo free password
  • 17. Connect to WiFi network
  • 18. View system version
  • 19. Customized service management
  • 20. Back up system image
13. Docker course
  • 1. Overview and installation
  • 2. Common commands
  • 3. In-depth understand and publishing images
  • 4. Hardware interaction and data processing
  • 5. Enter robot docker container
18.ROS2 basic course
  • 1. Introduction to ROS2
  • 2.ROS2 install Humble
  • 3. ROS2 development environment
  • 4. ROS2 workspace
  • 5. ROS2 function package
  • 6. ROS2 node
  • 7.ROS2 topic communication
  • 8. ROS2 service communication
  • 9. ROS2 action communication
  • 10. ROS2 custom interface message
  • 11. ROS2 parameter service case
  • 12. ROS2 meta-function package
  • 13. ROS2 distributed communication
  • 14. ROS2 DDS
  • 15. ROS2 time related API
  • 16. ROS2 common command tools
  • 17. ROS2 rviz2 use
  • 18. ROS2 rqt toolbox
  • 19. ROS2 Launch startup file configuration
  • 20. ROS2 recording and playback tool
  • 21. ROS2 URDF model
  • 22. ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
15. microROS control board development environment
  • 1. Introduction to microROS control board
  • 2. Set up ESP32-IDF development environment
  • 3. ESP32-IDF configuration tool
  • 4. Install ESP32-microros components
  • 5. Install and start microROS agent
  • 6. Flash-tool burning firmware
16. ESP32 basic course
  • 1. Turn on the LED light
  • 2. Button function
  • 3. Drive the buzzer
  • 4. Serial communication
  • 5. Battery voltage detection
  • 6. Drive PWM servo
  • 7. Drive motor
  • 8. Read motor encoder data
  • 9. PID controls car speed
  • 10. Read IMU data
  • 11. Read radar data
  • 12. Flash access data
  • 13. Partition table and memory
  • 14. Bluetooth communication
  • 15. WiFi networking
  • 16. Robot kinematics analysis
  • 17. ROS-WiFi camera module
17. microros basic course
  • 1. Publish topic
  • 2. Subscribe topic
  • 3. Multi-topic subscribe and publish
  • 4. Subscribe buzzer topics
  • 5. Subscribe PWM servo topics
  • 6. Subscribe speed control topics
  • 7. Release speed topic
  • 8. Release IMU data topic
  • 9. Publish lidar data topics
  • 10. Customized transmission method
Download
  • Mapping_APP(iOS_Android)
  • Code and firmware
  • Hardware info and driver software
  • VM image file
  • Instruction manual
  • SystemFile_RPi
  • SystemFile_JetsonNANO
  • 3D_Model_File
  • ROS2_Basic_VM
Download ZIP

Welcome to MicroROS Robot repository

1.OpenCV Getting started

1.OpenCV Getting started

1 、OpenCV synopsis
image-20220217202241894

What is OpenCV? Its full name is Open source Computer Vision Library, an open source computer vision library. As shown in the above figure, what we see is the logo of OpenCV, which is composed of three small circles with distinct R, G, and B colors. In other words, it is an open source API library for computer vision. This also means that,

(1)Whether it is scientific research or commercial applications, it can be used for development;

(2)The source code of all API functions is publicly available, and you can see the program steps implemented internally;

(3)You can modify the source code of OpenCV and compile it to generate specific API functions that you need.

The image processing on ROSMASTER utilizes certain functions of OpenCV's function library, or it can be said that its existence is indispensable in the vast majority of image processing design fields. As early as many years ago, OpenCV has shown great skills in intrusion detection, specific object tracking, object detection, face detection, facial recognition, facial tracking and other fields, and these are just the tip of the iceberg in its application. Since we recognize the versatility of OpenCV, in this chapter of the course, we will introduce you to several basic image processing functions that we use in our course, as well as some common functions. Here, we will first have a rough understanding of these knowledge, and then we will teach you two practical projects: color recognition and tracking, and face recognition and tracking. However, the powerful application functions provided by OpenCV go far beyond that. If you are interested in developing OpenCV computer vision libraries and want to learn more, the following are several websites for you to refer to and study:

OpenCV Official homepage:https://www.opencv.org

OpenCV Chinese forums:http://www.opencv.org.cn

OpenCV CSDN forums:https://bbs.csdn.net/forums/OpenCV

2、OpenCV Image reading and display

2.1、Image Reading:

img = cv2.imread('yahboom.jpg', 0) The first parameter is the path of the image, and the second parameter is how to read this image.

cv2.IMREAD_UNCHANGED:Keep the original format unchanged:-1;

cv2.IMREAD_GRAYSCALE:Read the image in grayscale mode, which can be represented by 0;

cv2.IMREAD_COLOR:,Read in a color image, which can be represented as 1; Default value

cv2.IMREAD_UNCHANGED:Read in an image and include its alpha channel, which can be represented as 2。

2.2、Image display

cv.imshow('frame', frame):Open a window named frame and display frame data (image/video data) Parameter meanings:

The first parameter represents the name of the window to be created and opened

The second parameter represents the image to be displayed

2.3、Code and actual effect display

Running programs

cd ~/yahboomcar_ws/src/yahboom_esp32ai_car/scripts/opencv/
python3 1_1.py
xxxxxxxxxx
import cv2 as cv
•
if __name__ == '__main__':
    img = cv.imread('yahboom.jpg')
    while True :
        cv.imshow("frame",img)
        action = cv.waitKey(10) & 0xFF
        if action == ord('q') or action == 113:
            break
    img.release()
    cv.destroyAllWindows()

After running the program, the effect image:
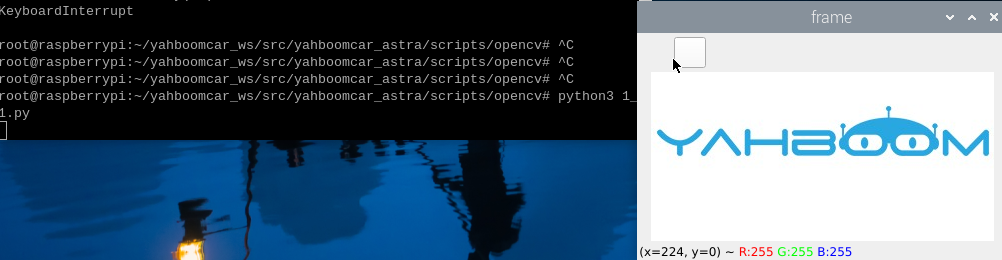
image-20240123155730268

3、OpenCV image writing

3.1、Function method:cv2.imwrite('new_img_name', img)

Parameter meanings:

The first parameter is the name of the saved file

The second parameter is the saved image

3.2、Code and actual effect display

xxxxxxxxxx
cd ~/yahboomcar_ws/src/yahboom_esp32ai_car/scripts/opencv/
python3 1_2.py
xxxxxxxxxx
import cv2 as cv
•
if __name__ == '__main__':
    img = cv.imread('yahboom.jpg')
    cv.imwrite("yahboom_new.jpg",img)   
    new_img = cv.imread('yahboom_new.jpg') #
    while True :
        cv.imshow("frame",img)
        cv.imshow("new_frame",new_img)
        action = cv.waitKey(10) & 0xFF
        if action == ord('q') or action == 113:
            break
    img.release()
    cv.destroyAllWindows()

After running the program, the effect image
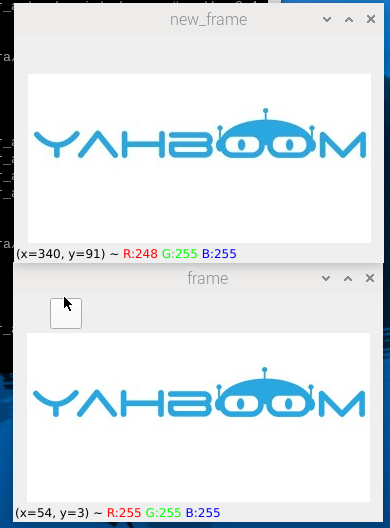
image-20240123155924108

4、OpenCV pixel operation

4.1、Pixel operation, we can change any position to a new pixel color.

Firstly, we need to read the image and then modify the value of bgr by assigning an area in black.

4.2、Code and actual effect display

Running programs

xxxxxxxxxx
cd ~/yahboomcar_ws/src/yahboom_esp32ai_car/scripts/opencv/
python3 1_4.py
xxxxxxxxxx
import cv2
if __name__ == '__main__':
    img = cv2.imread('yahboom.jpg')
    (b,g,r) = img[100,100]
    print(b,g,r)
    i=j=0
    for j in range(1,255):
        img[i,j] = (0,0,0)
        for j in range(1,255):
            img[i,j] = (0,0,0)
    while True :
        cv2.imshow("frame",img)
        action = cv2.waitKey(10) & 0xFF
        if action == ord('q') or action == 113:
            break
    img.release()
    cv2.destroyAllWindows()

After running the program, the effect image
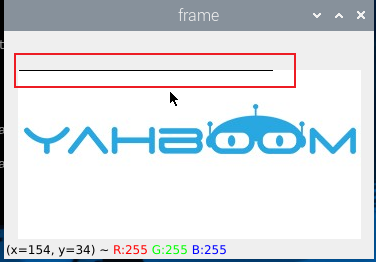
image-20240123160253808

The red box represents the modified pigment values.


Calibrate servo PTZ(ReadMe)
Geometric transformation

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文