Welcome to PALMSLAM repository
1. Write the firmware
Burn factory firmware
Note: The control board has been burned with factory firmware. If no other firmware has been burned, there is no need to burn the factory firmware again. The factory firmware of the control board only provides bin file burning, and does not provide program source code.
The factory firmware is stored in the [Program Source Code Summary] -> [Factory-Firmware] directory in the document
1. Install CH340 serial port driver
If the Windows system has already installed the CH340 serial port driver, you can skip this step.
The CH340 serial port driver file path is in the [Hardware Related Information] -> [CH341SER.zip] of the supporting information
Unzip to get the following file
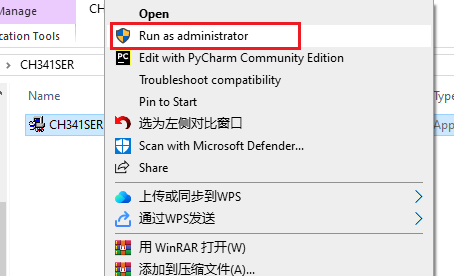
Open the installation package as an administrator
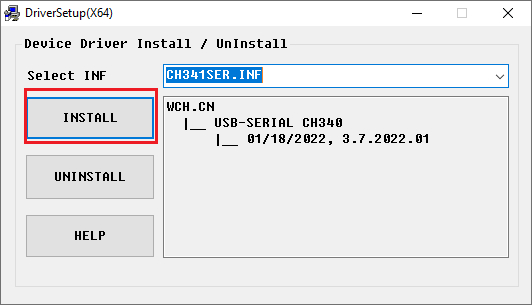
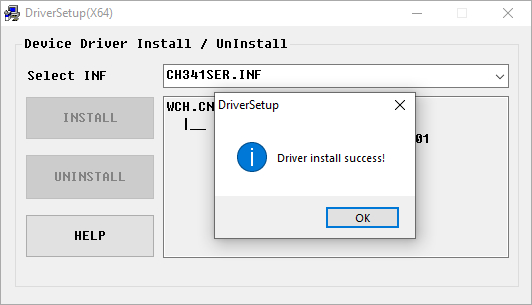
After the driver installation is complete, click OK.
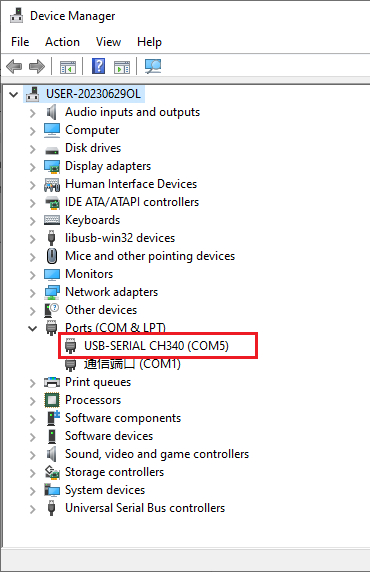
Open the [Device Manager] of the Windows system. If you see the CH340 device in [Port], it means that the driver installation is successful.
2. Download Flash Tool
Download URL:
xxxxxxxxxxhttps://www.espressif.com.cn/zh-hans/support/download/other-tools
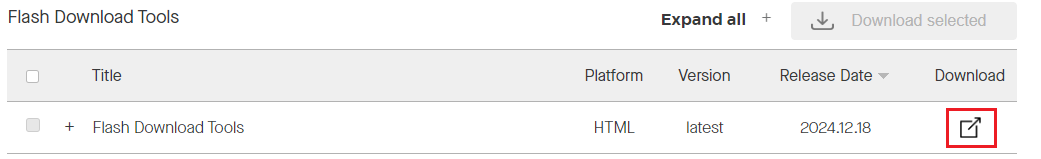
Unzip to get flash_download_tool, double-click to open.
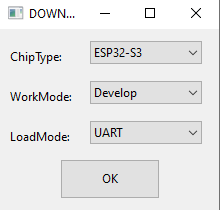
As shown in the figure below, select serial port to burn ESP32-S3. Click OK to open the burning tool.
3. Configure the burning tool
In ‘SPIDownload’, select the firmware PLAMSLAMv1.2.bin to be burned to ESP32S3, where V1.2 is the firmware version number and the firmware address is 0x0. Make sure to check the box on the left of the bin file, and the file and address are both green.
Check DoNotChgBin, select the connected COM port, and keep other configurations as default.
| Firmware name | Firmware address | Remarks |
|---|---|---|
| PLAMSLAMv1.2.bin | 0x0 | Factory firmware bin file |
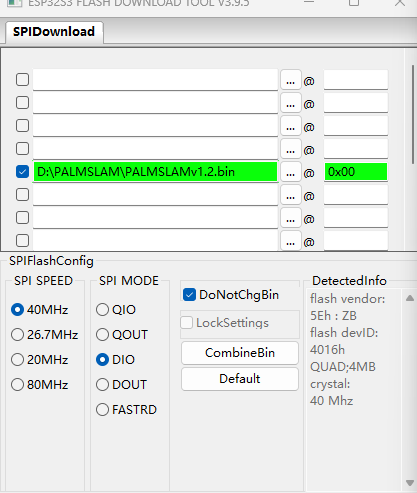
4. Start burning firmware
Click the START button and the tool will automatically start burning the firmware.
Note: If the firmware does not start burning automatically, please press and hold the boot0 key, then press the reset key, release the boot0 key, manually enter the burning mode, and then click the START button.
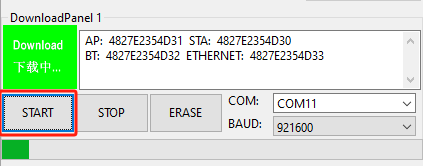
5. Burning completed
After the download is complete, the blue FINISH logo is prompted. At this time, power off and restart the MCU or press the reset button to start the program, and close the burning tool.
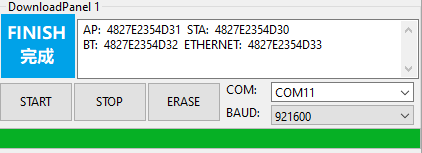
VI. Check the factory firmware
The storage path of the serial port assistant software is in the supporting materials [Hardware related information] -> [CP2102 serial port chip] -> [UartAssist.exe].
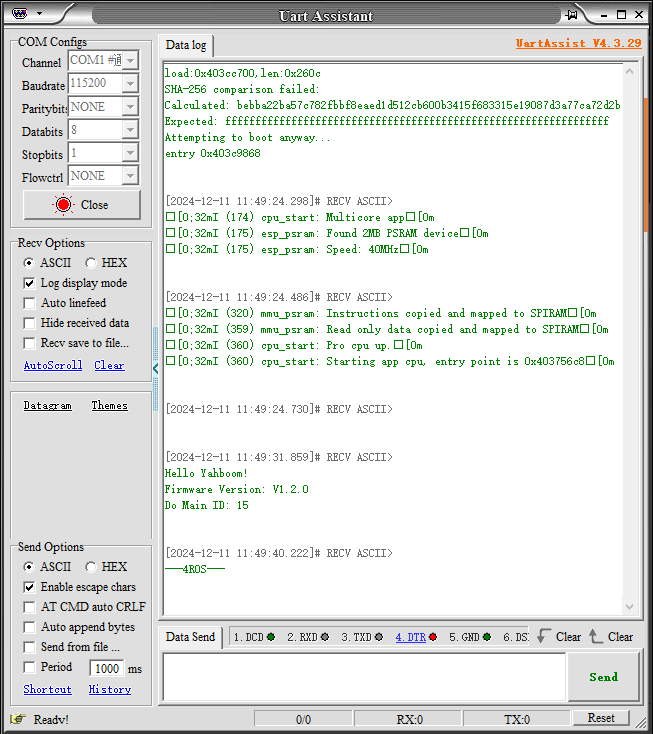
Open the serial port assistant, as shown in the figure below, select the serial port number of the microROS control board, the baud rate is 115200, 8-bit data, 1-bit stop, no check, no flow control.
Press the reset button of the control board to print out hello yahboom and the current firmware version information, do_main_id information.
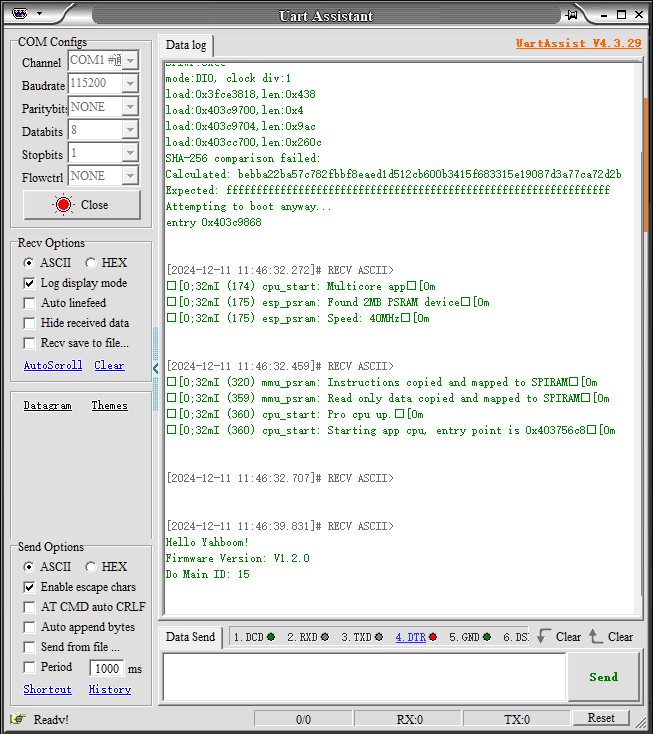
If an external oled display is connected, it will show imu init waiting..
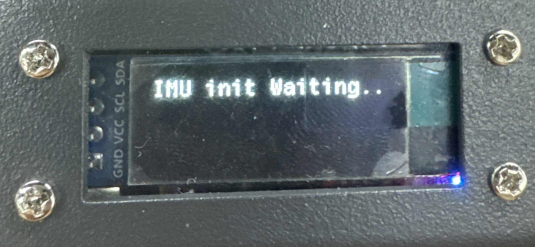
After waiting for 6 seconds, the alarm level selection will be displayed. At this time, we directly press the button and the buzzer will beep, indicating that the default level is selected. For detailed selection, please refer to the following chapters.
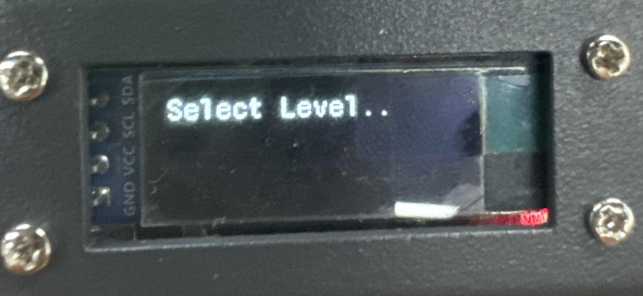
After selecting the alarm level, the radar model selection will be displayed.
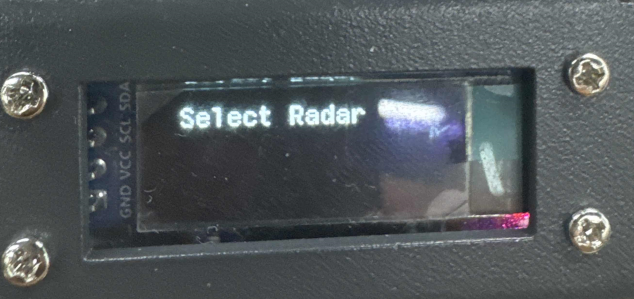
Pressing the button at this time will select the default radar selected for the first time, which is the 4ROS radar, and display the data of the imu x-axis and y-axis as well as the distance information directly in front of the laser radar.
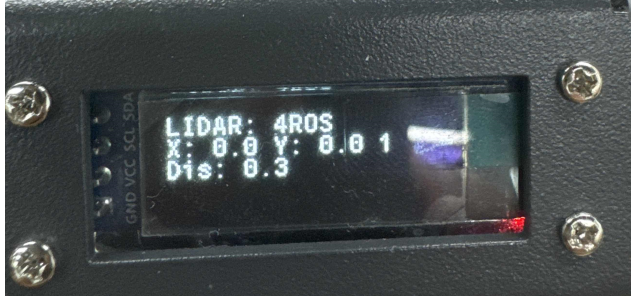
At the same time, the selected radar model will be printed in the serial port debugging information.