yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
PALMSLAM📖
1. Product Introduction
  • 0.Get started
  • 1. Learning route
  • 2. Frequently Questions
  • 3. Control panel introduction
  • 4. Introduction to LiDAR
  • 5. Robot charging and battery considerations
  • 6.Unboxing and reviewing
2. Assembly video
  • Installation Video
3. Basic configuration
  • 0. Get started quickly
  • 1. Write the firmware
  • 2. Virtual machine installation and startup system
  • 3. Expansion board configuration parameters
  • 4. How to choose the alarm level and radar model
  • 5. Connection Agent
4. LiDAR course
  • 0. Enter the same docker terminal
  • 1. Robot information release
  • 2. Robot URDF model
  • 3. Basic distance measurement function
  • 4. SLAM Gmapping
  • 5. SLAM Cartographer
  • 6. APP mapping
5. Linux operating system
  • 1.Introduction to Linux system
  • 2.Ubuntu file system
  • 3.Ubuntu common commands
  • 4.Ubuntu common editors
  • 5.Ubuntu software operation commands
  • 6.Virtual machine installation
  • 7.SSH remote control
  • 8.VNC remote control
  • 9.Transfer files remotely
  • 10.Driver library and communication
  • 11.Static IP and hotspot mode
  • 12.Bind device ID
  • 13.Capacity expansion and resource allocation
  • 14.Update system software sources
  • 15.Set root user password
  • 16.sudo free password
  • 17.Connect to WiFi network
  • 18.View system version
  • 19.Customized service management
  • 20.Back up system image
6. ROS2 Basic Course
  • 1.Introduction to ROS2
  • 2.ROS2 install Humble
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
Download
  • System_File
  • VM_File
  • Code
  • Software_Tool
  • Hareware_Info
  • 3D_Model_File
  • Instruction_Manual
  • ROS2_Basic_VM
Download ZIP

Welcome to PALMSLAM repository

5. Connection Agent

Connect to microROS agent

Note: Before connecting to the agent, you need to select the alarm level and radar model through the oled screen before starting the connection.

1. Open the agent

If you are using the factory virtual machine system, you can enter in the terminal:

xxxxxxxxxx
sh ~/start_agent_computer.sh

If you are using a third-party virtual machine system, you need to install the docker development environment first, and open the terminal to enter:

xxxxxxxxxx
docker run -it --rm -v /dev:/dev -v /dev/shm:/dev/shm --privileged --net=host microros/micro-ros-agent:humble udp4 --port 8090 -v4

2. Connect to the agent

Turn on the power switch of the robot, automatically connect to the agent, and the connection is successful as shown in the figure below
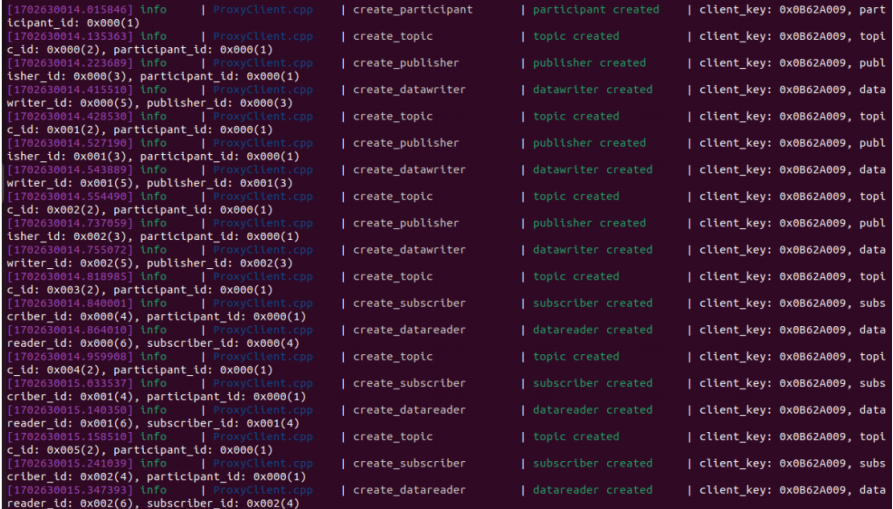
img

Note: If the connection is not successful, please check and confirm the configuration parameters of the robot, whether it can connect to the local area network normally, and whether the agent IP address and port number correspond.

3. Test ROS node

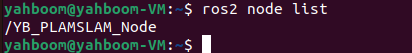
Open the ROS2 terminal environment and enter the following command to view the /YB_PLAMSLAM_Node node name

xxxxxxxxxx
ros2 node list

image-20241205122709221

If the /YB_PLAMSLAM_Node node cannot be searched, please check and confirm that the ROS DOMAIN ID of the .bashrc file on the virtual machine/computer must be consistent with the configuration on the microROS control board to search for node information.
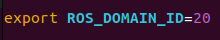
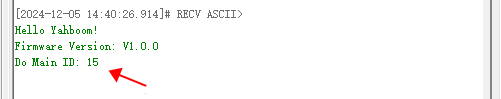
image-20240116121146817

image-20241205151645386

How to choose the alarm level and radar model
Enter the same docker terminal

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文