yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
MicroROS Robot Expansion Board📖
01. microROS control board development environment
  • 1. Introduction to microROS control board
  • 2. Set up ESP32-IDF development environment
  • 3. ESP32-IDF configuration tool
  • 4. Install ESP32-microros components
  • 5. Install and start microROS agent
  • 6. Flash-tool burning firmware
02. ESP32 basic course
  • 1. Turn on the LED light
  • 2. Button function
  • 3. Drive the buzzer
  • 4. Serial communication
  • 5. Battery voltage detection
  • 6. Drive PWM servo
  • 7. Drive motor
  • 8. Read motor encoder data
  • 9. PID controls car speed
  • 10. Read IMU data
  • 11. Read radar data
  • 12. Flash access data
  • 13. Partition table and memory
  • 14. Bluetooth communication
  • 15. WiFi networking
  • 16. Robot kinematics analysis
  • 17.Drive ESP32 WiFi camera
03. microros basic course
  • 1.Publish topic
  • 2. Subscribe topic
  • 3. Multi-topic subscribe and publish
  • 4. Subscribe buzzer topics
  • 5. Subscribe PWM servo topics
  • 6. Subscribe speed control topics
  • 7. Release speed topic
  • 8. Release IMU data topic
  • 9. Publish lidar data topics
  • 10. Customized transmission method
04.ROS2 basic course
  • 1. Introduction to ROS2
  • 2.ROS2 install Humble
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
05. Robot basic course
4.1 Robot information release
  • Robot information release
4.0 Preparation
  • 1. Write firmware
  • 2. How to install and use VM
  • 3. microROS control board configuration
  • 4. Connect to microROS agent
4.2 Robot keyboard control
  • Robot keyboard control
4.3 Robot handle control
  • Robot handle control
4.4 Robot state estimation
  • Robot state estimation
4.5 Line speed calibration
  • Line speed calibration
4.6 Angular velocity calibration
  • Angular velocity calibration
4.7 Robot URDF model
  • Robot URDF model
Download
  • Firmware And Code
  • VM_File
  • 3D Model File
  • ROS2_Basic_VM
Download ZIP

Welcome to MicroROS Robot Expansion Board repository

Robot keyboard control

Robot keyboard control

Note: The virtual machine needs to be in the same LAN as the car, and the ROS_DOMAIN_ID needs to be consistent. You can check [Read me] to set the IP and ROS_DOMAIN_ID on the board.

1. Program function description

After the program is started, the car movement can be controlled through the keyboard.

2. Start and connect to the agent

Taking the supporting virtual machine as an example, enter the following command to start the agent:

sudo docker run -it --rm -v /dev:/dev -v /dev/shm:/dev/shm --privileged --net=host microros/micro-ros-agent:humble udp4 --port 8090 -v4
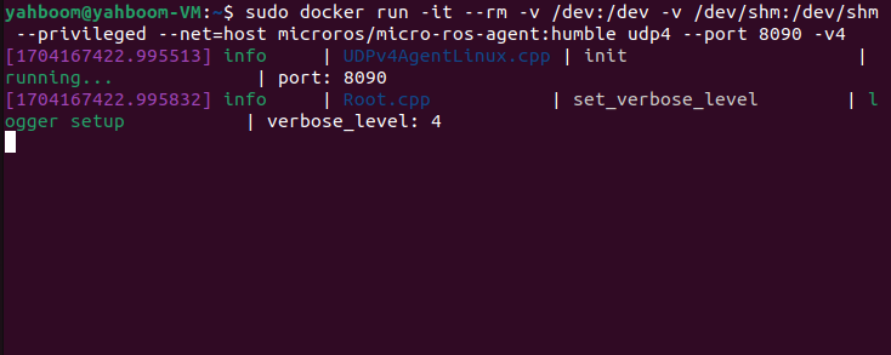
image-20240102115411750

Then, turn on the car switch and wait for the car to connect to the agent. The connection is successful, as shown in the figure below.
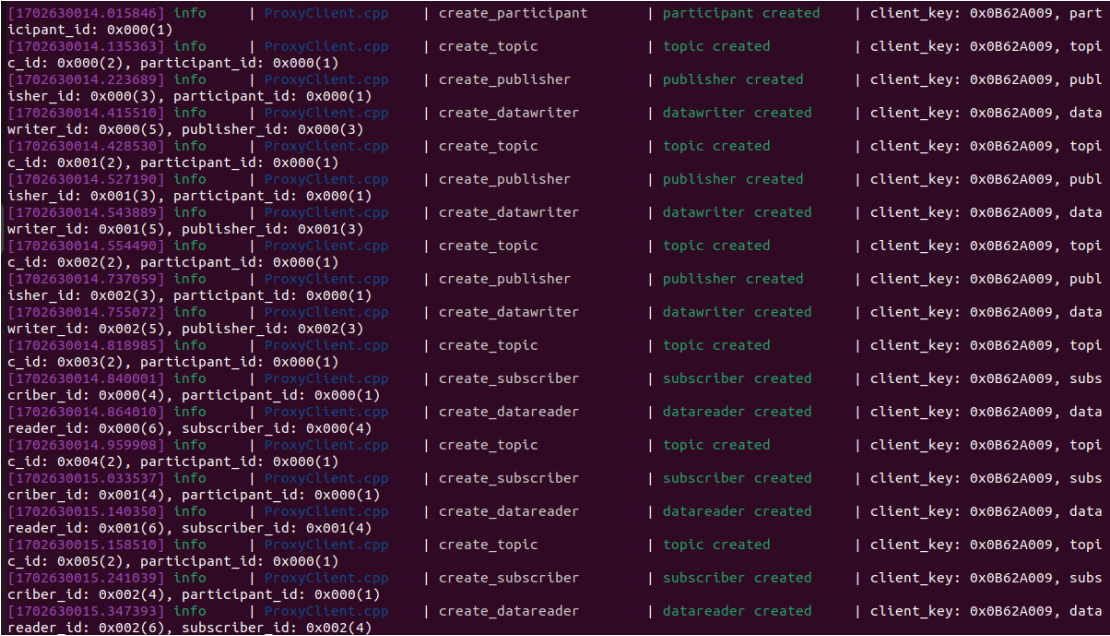
image-20231215174852342

3、Start the keyboard control program

Enter the following command in the terminal to start the keyboard control program.

xxxxxxxxxx
ros2 run yahboomcar_ctrl yahboom_keyboard
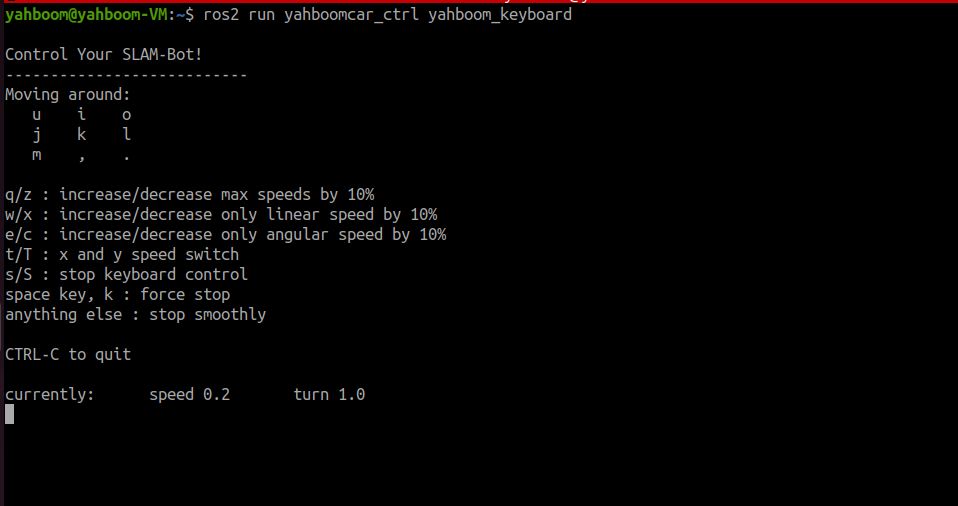
image-20231215175049195

Keyboard key descriptions are as follows

Directional control.

【i】or【I】【linear,0】【u】or【U】【linear,angular】
【,】【-linear,0】【o】or【U】【linear,-angular】
【j】or【J】【0,angular】【m】or【M】【-linear,-angular】
【l】or【L】【0,-angular】【.】【-linear,angular】


According to the control table description, you can go forward by pressing the [i] key. Press [,] to go back,Press [l] to rotate to the right, press [j] to rotate to the left, and so on.

speed control table

speed changespeed changekeyboard keysspeed change
【q】Linear speed and angular speed increased by 10%【z】Linear speed and angular speed are reduced by 10%
【w】Only line speed increases by 10%【x】Only line speed is reduced by 10%
【e】Only the angular velocity is increases by 10%【c】Only the angular velocity is reduced by 10%
【t】Linear speed X-axis/Y-axis direction switching【s】Stop keyboard control


Note: Since the car has a four-wheel drive structure with ordinary tires and cannot move sideways, the [t] button has no meaning. Before each use of keyboard control, you need to click on the terminal that starts the program, otherwise the key event cannot be detected.


Connect to microROS agent
Robot handle control

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文