yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
MicroROS Robot Expansion Board📖
01. microROS control board development environment
  • 1. Introduction to microROS control board
  • 2. Set up ESP32-IDF development environment
  • 3. ESP32-IDF configuration tool
  • 4. Install ESP32-microros components
  • 5. Install and start microROS agent
  • 6. Flash-tool burning firmware
02. ESP32 basic course
  • 1. Turn on the LED light
  • 2. Button function
  • 3. Drive the buzzer
  • 4. Serial communication
  • 5. Battery voltage detection
  • 6. Drive PWM servo
  • 7. Drive motor
  • 8. Read motor encoder data
  • 9. PID controls car speed
  • 10. Read IMU data
  • 11. Read radar data
  • 12. Flash access data
  • 13. Partition table and memory
  • 14. Bluetooth communication
  • 15. WiFi networking
  • 16. Robot kinematics analysis
  • 17.Drive ESP32 WiFi camera
03. microros basic course
  • 1.Publish topic
  • 2. Subscribe topic
  • 3. Multi-topic subscribe and publish
  • 4. Subscribe buzzer topics
  • 5. Subscribe PWM servo topics
  • 6. Subscribe speed control topics
  • 7. Release speed topic
  • 8. Release IMU data topic
  • 9. Publish lidar data topics
  • 10. Customized transmission method
04.ROS2 basic course
  • 1. Introduction to ROS2
  • 2.ROS2 install Humble
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
05. Robot basic course
4.1 Robot information release
  • Robot information release
4.0 Preparation
  • 1. Write firmware
  • 2. How to install and use VM
  • 3. microROS control board configuration
  • 4. Connect to microROS agent
4.2 Robot keyboard control
  • Robot keyboard control
4.3 Robot handle control
  • Robot handle control
4.4 Robot state estimation
  • Robot state estimation
4.5 Line speed calibration
  • Line speed calibration
4.6 Angular velocity calibration
  • Angular velocity calibration
4.7 Robot URDF model
  • Robot URDF model
Download
  • Firmware And Code
  • VM_File
  • 3D Model File
  • ROS2_Basic_VM
Download ZIP

Welcome to MicroROS Robot Expansion Board repository

18.ROS2 rqt toolbox

18. ROS2 Rqt Toolbox

  • This tutorial folder contains a demo animation git file, which provides a visual guide to the process of implementing the examples in this section.
  • image-20250905172110533

1. Introduction to Rqt

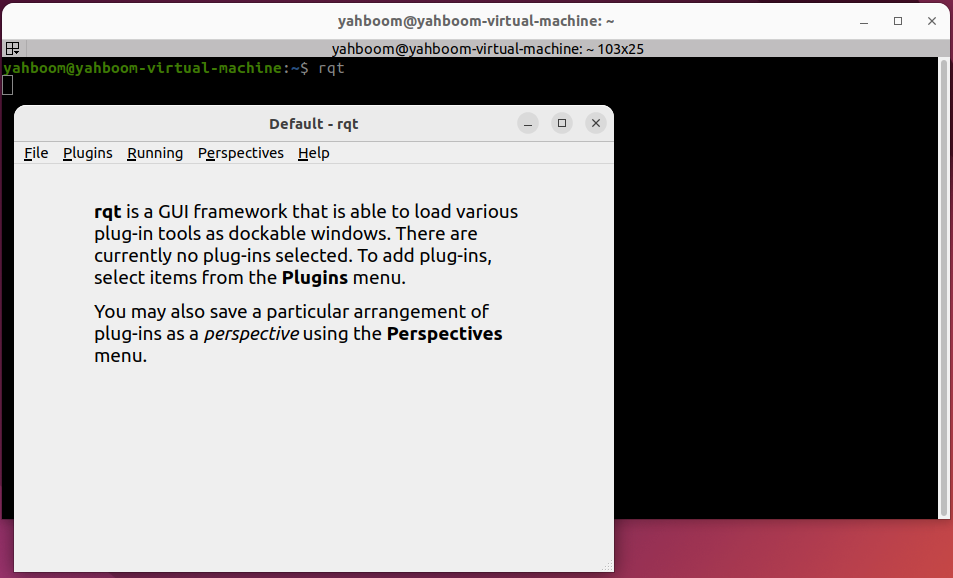
Rqt is another modular visualization tool provided by ROS. Like Rviz, it is based on the QT visualization tool. Before using it, you need to install it using the following command. Then, you can start it with the command rqt.

2. Installation

  • Generally, the RQT toolbox is installed by default if you install the desktop version.
  • If you do not install the full version when installing ROS and need to install it, you can install it as follows:
xxxxxxxxxx
sudo apt install ros-${ROS_DISTRO}-rqt*

3. Startup

Common RQT startup commands include:

  • Method 1: rqt

image-20250905172216440

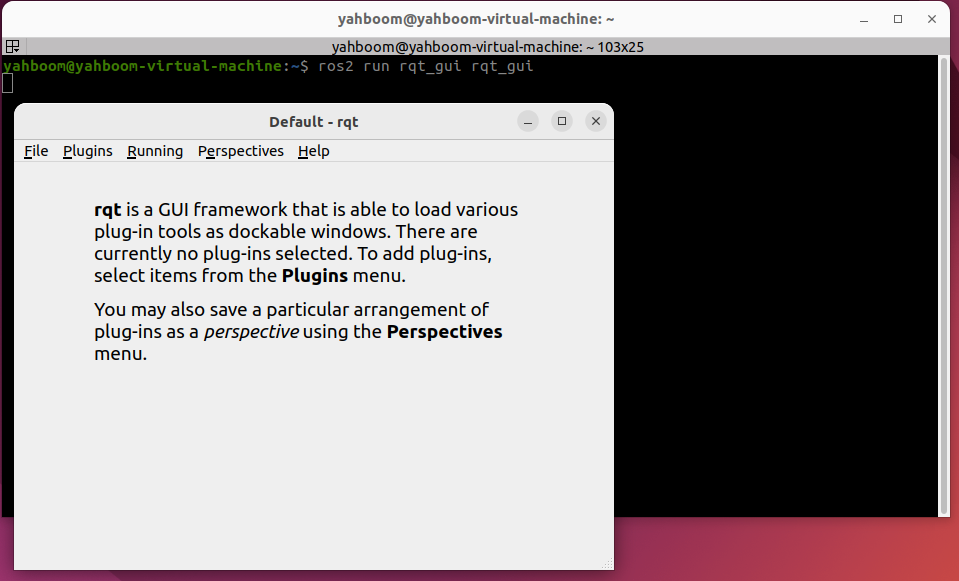
  • Method 2: ros2 run rqt_gui rqt_gui

image-20250905172235292

4. Plugin Usage

After starting RQT, you can add the required plugins through the plugins section:
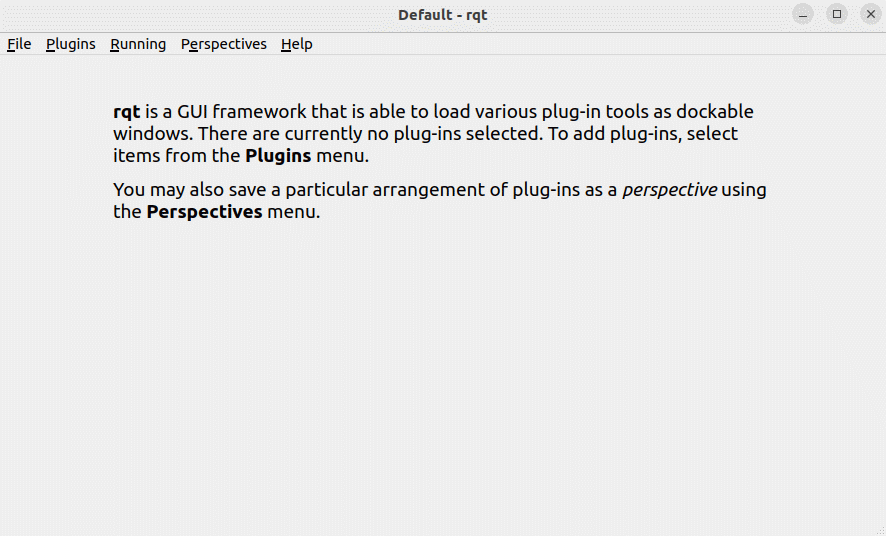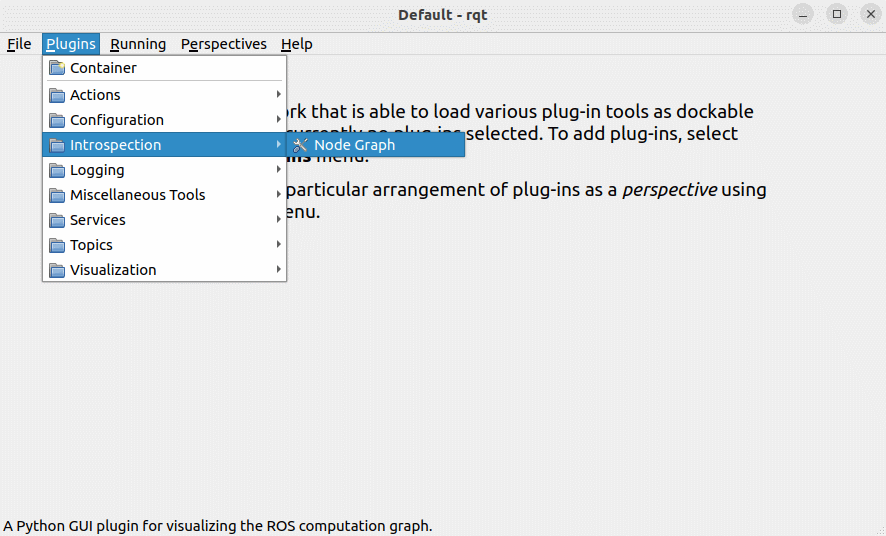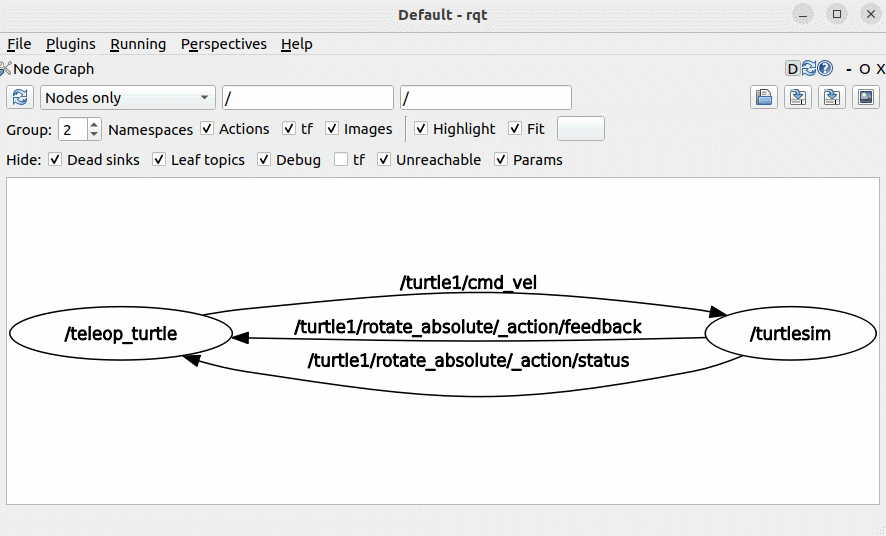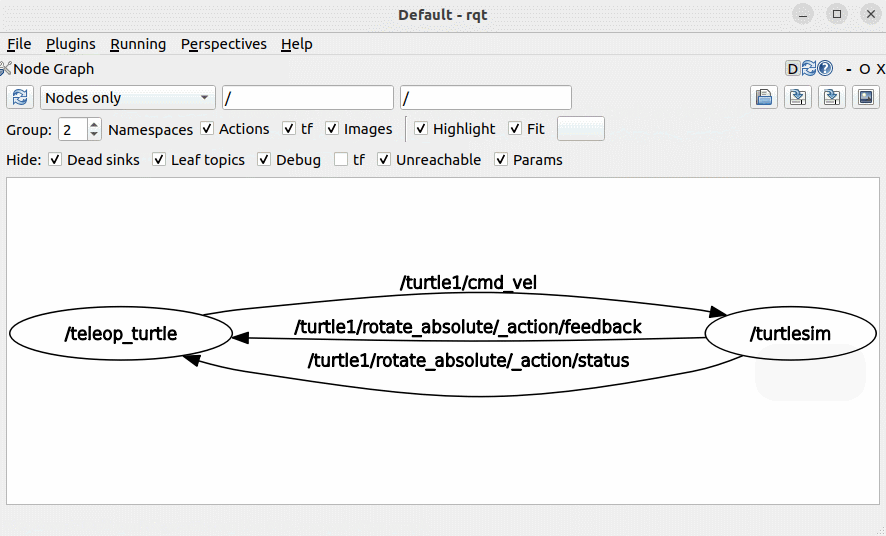
img

The plugins section includes plugins related to topics, services, actions, parameters, logging, and more. You can select plugins as needed to facilitate debugging of ROS2 programs. An example usage is shown below.

4.1. Topic Plugin

Add the topic plugin and send speed commands to control the turtle's movement.
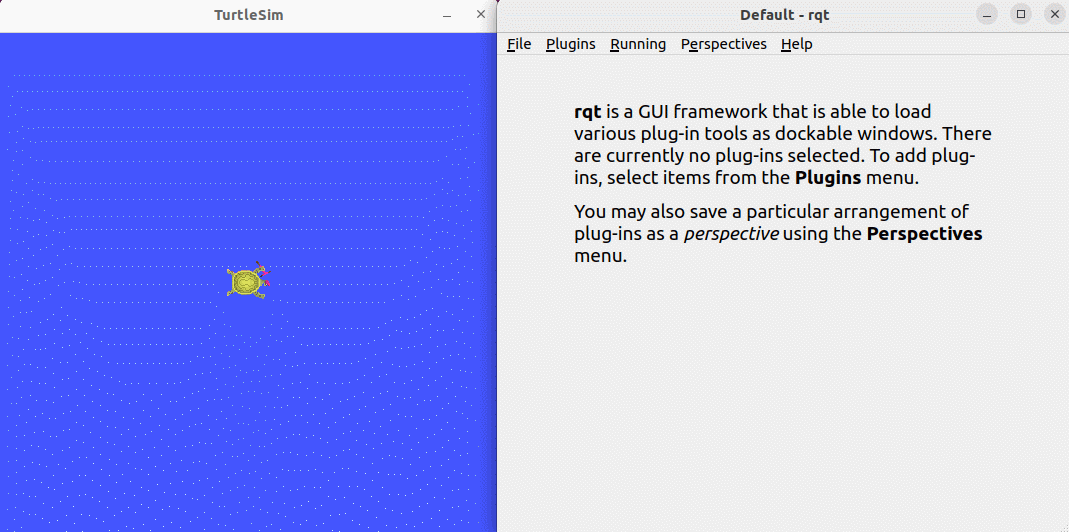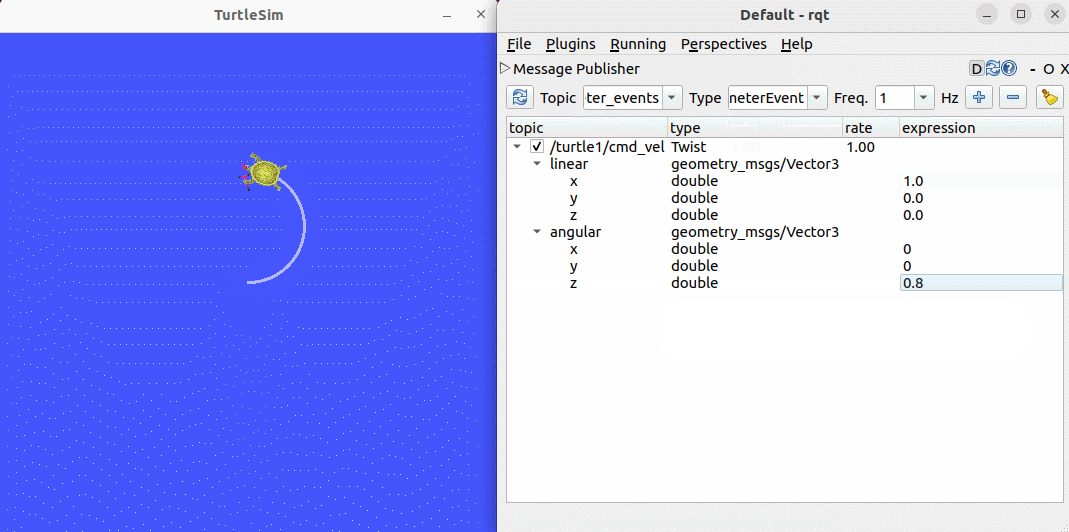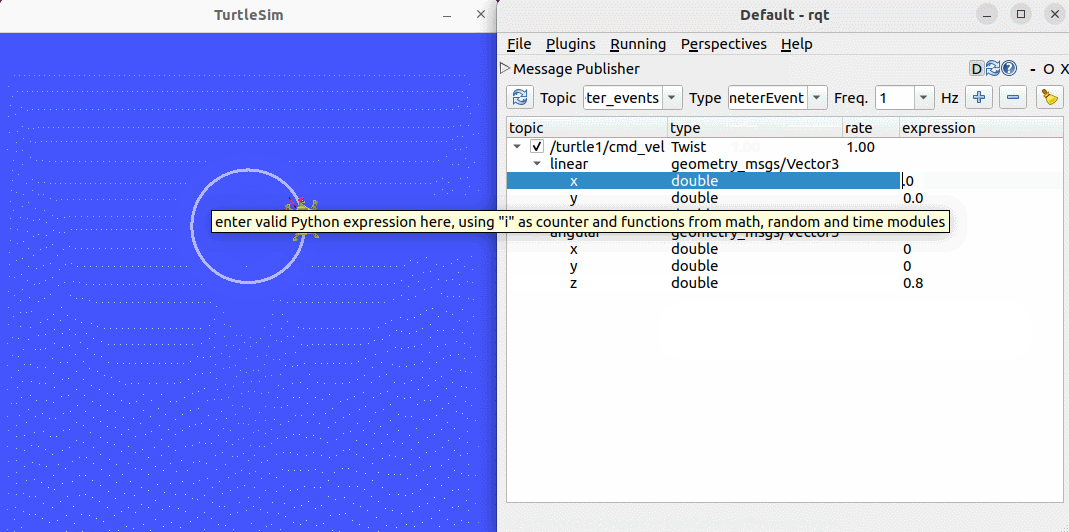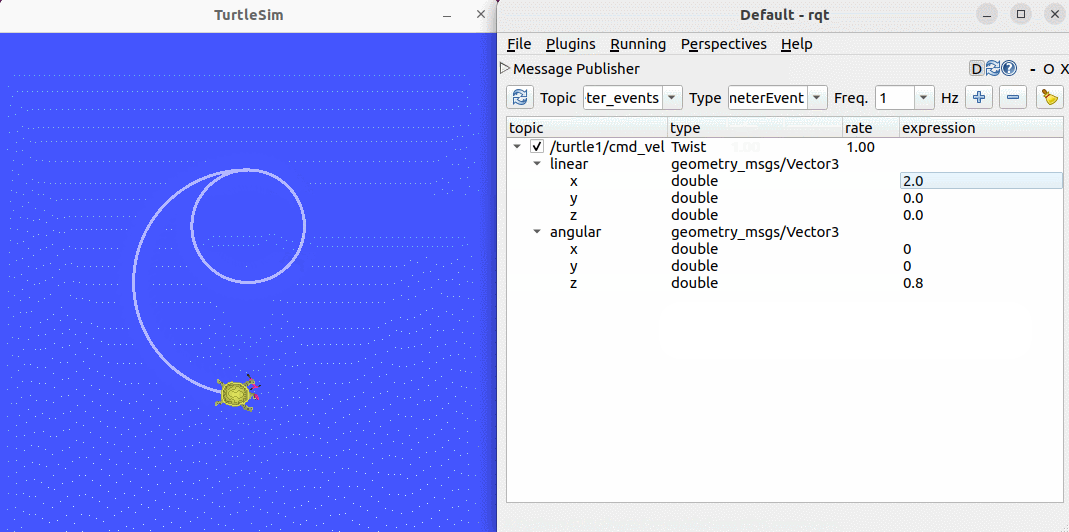
img

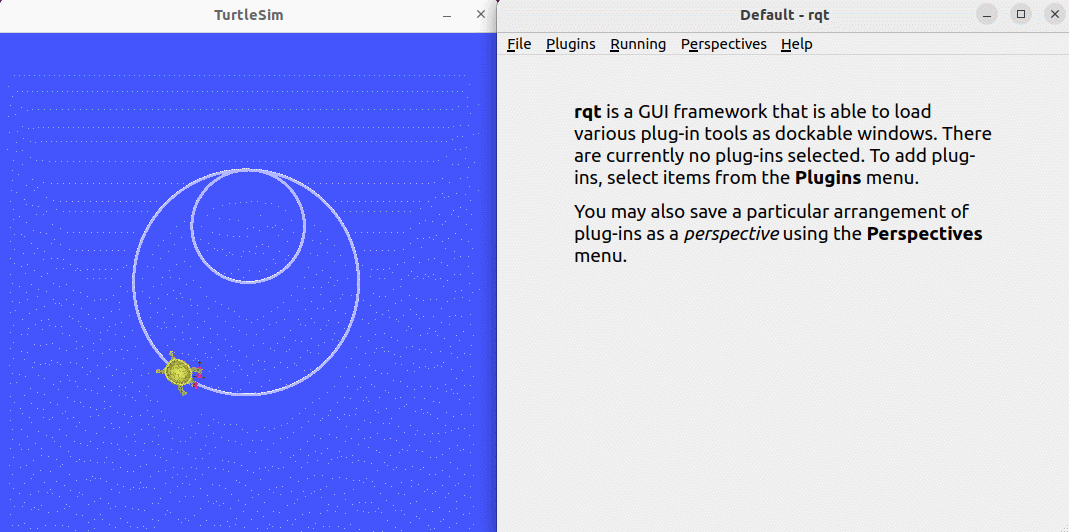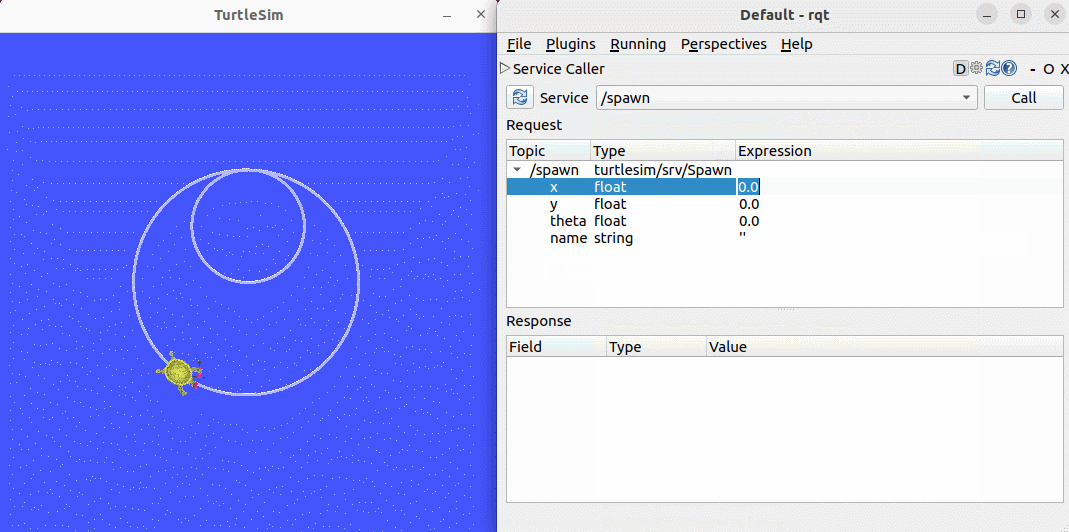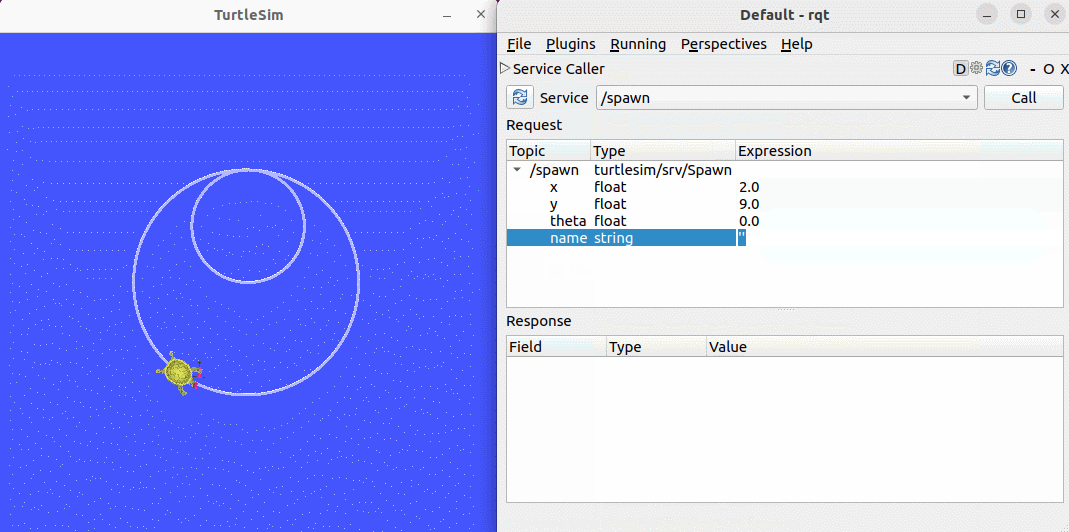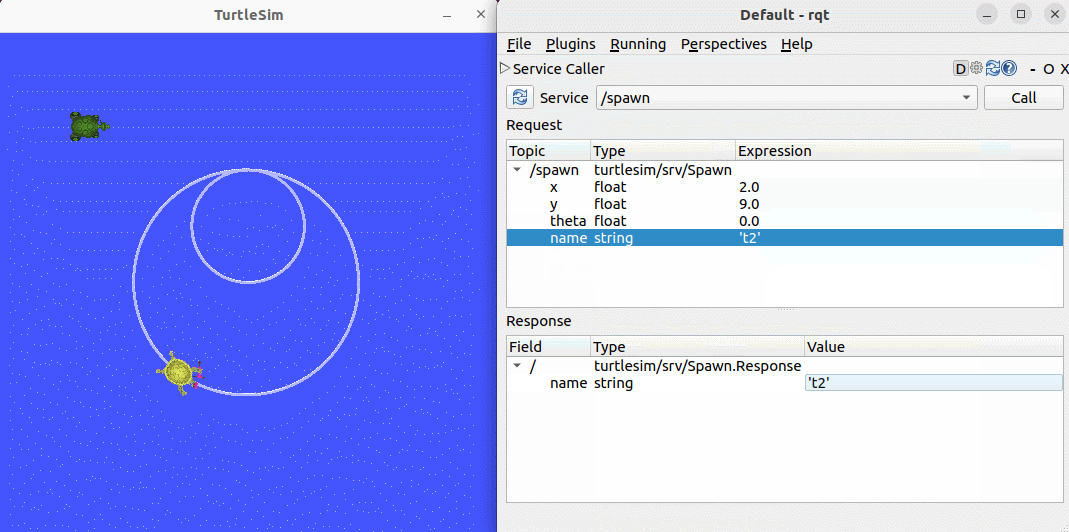
4.2. Service Plugin

Add the service plugin and send a request to spawn a turtle at a specified location.
img

4.3. Parameter Plugin

Use the parameter plugin to dynamically change the background color of the turtle window.
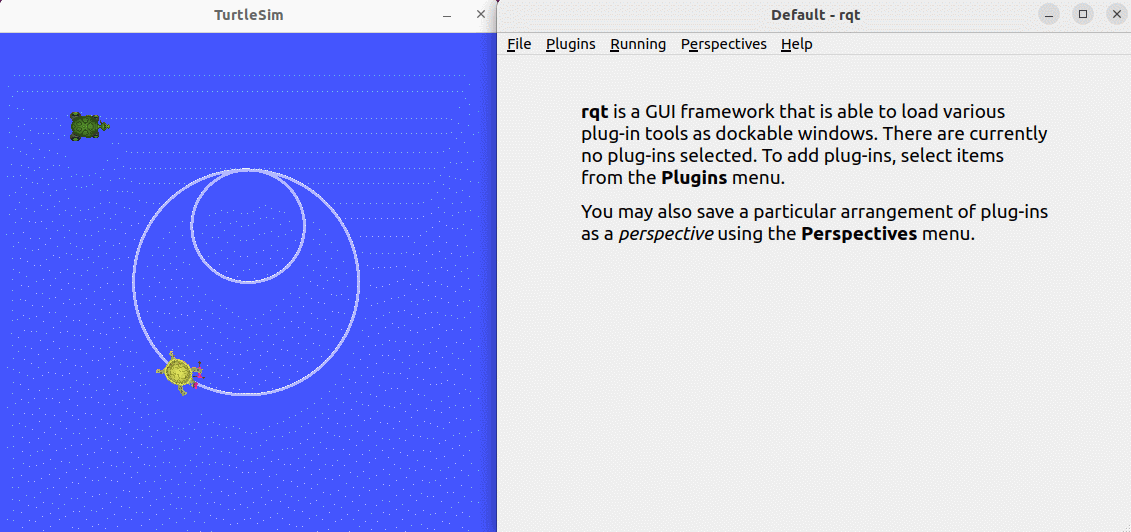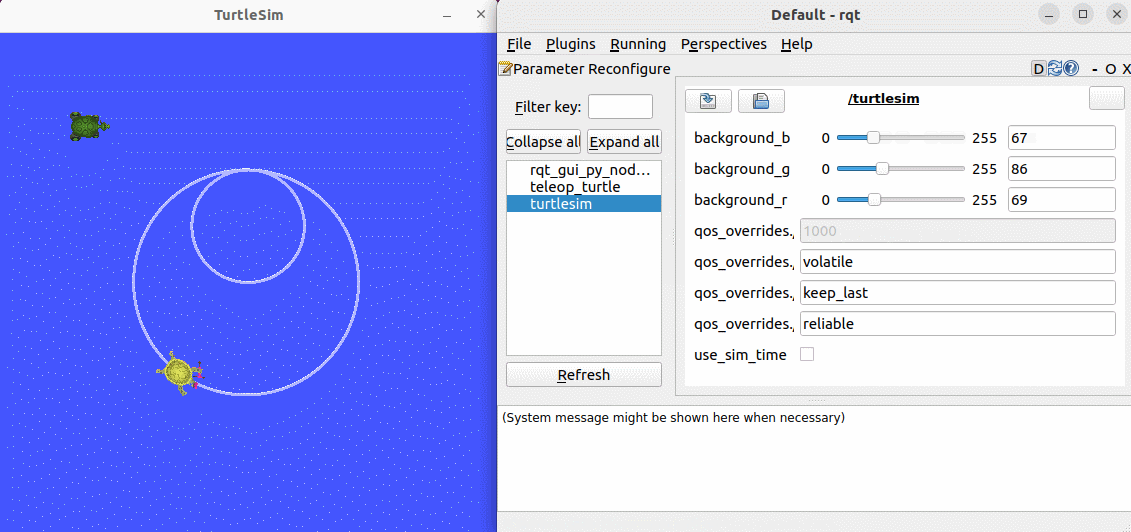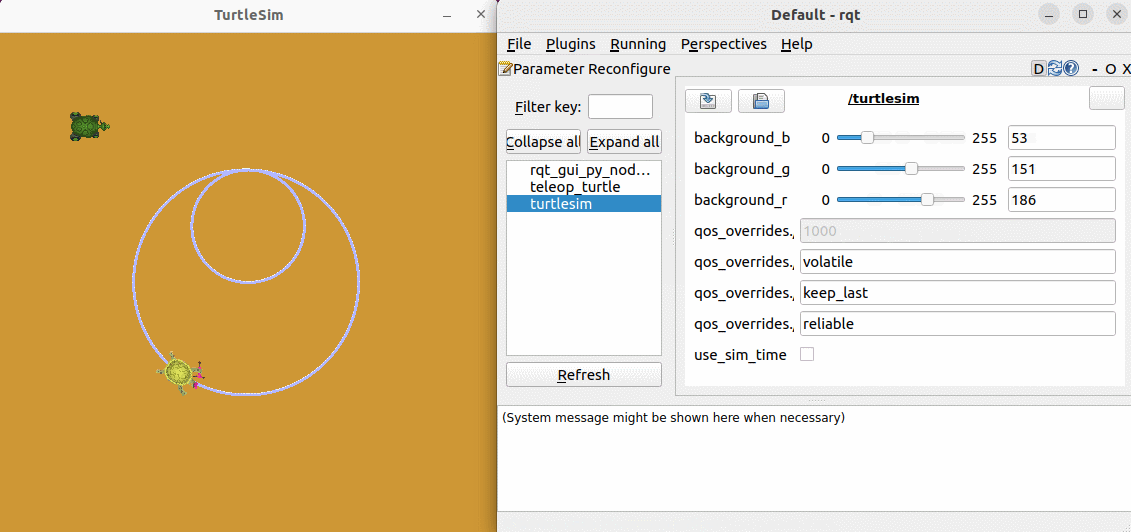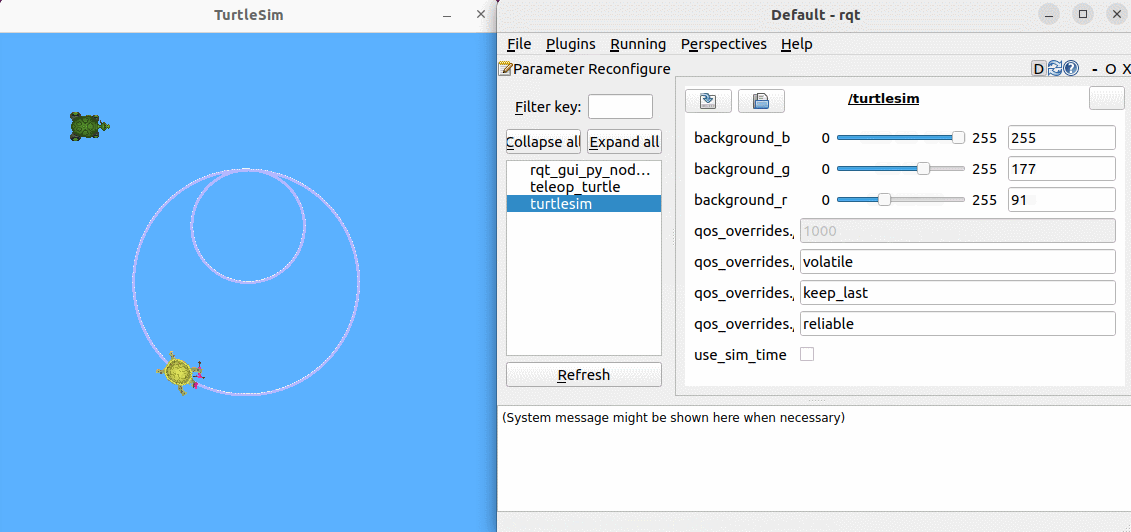
img

ROS2 rviz2 use
ROS2 Launch startup file configuration

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文