Welcome to AI View Depth camera repository
1.Hand detection
1.Hand detection
1.1 MediaPipe Hands
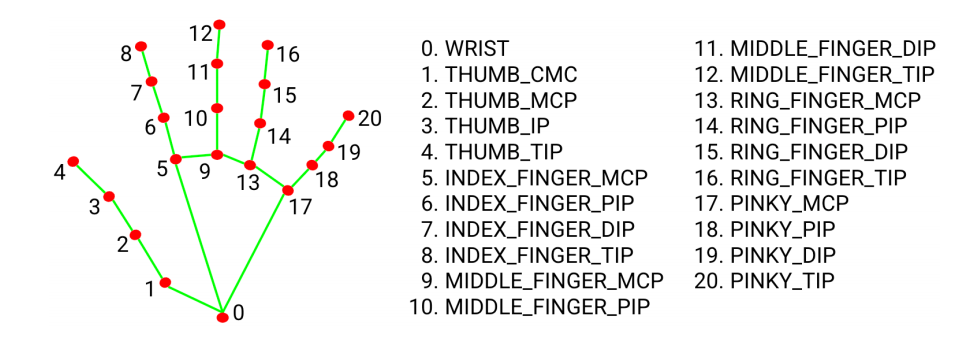
MediaPipe Hands is a type of high fidelity case tracking and resolution system. It uses machine learning (ML) to infer 21 3D coordinates from frames.
After palm detection of the entire image, precise key point localization of 21 3D joint coordinates within the detected region is performed through regression based on a part labeling model, i.e. direct coordinate prediction. This model learns the internal pose table of the human body, and is even robust to partially observable human body and self occlusion.
In order to obtain real-world data, 21 3D coordinates were used to dynamically annotate approximately 30K real-world images, as shown below (obtaining Z values from the image depth map, if each corresponding coordinate has a Z value). In order to better cover possible body postures and provide additional supervision on the properties of the body, a high-quality synthetic body model was drawn in various backgrounds and mapped to the corresponding 3D coordinates.
1.2 Hand detection
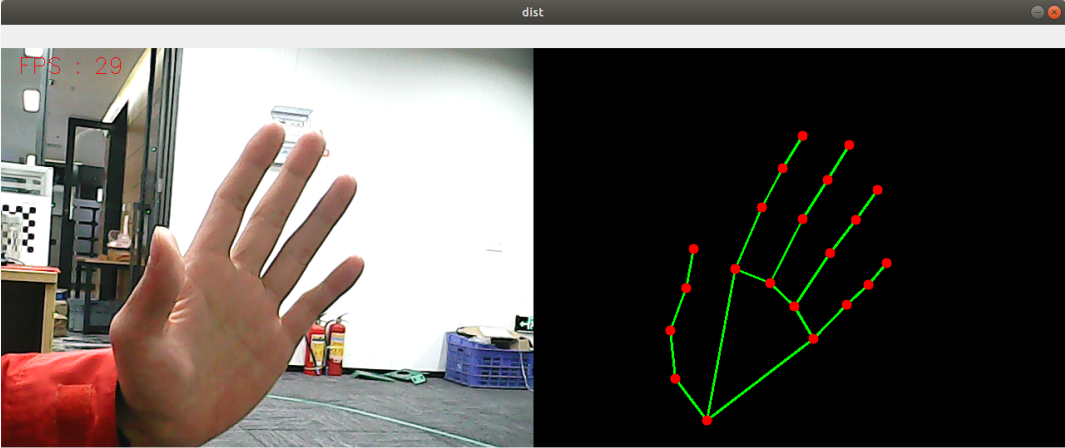
1) Start
Input following command:
roscorerosrun yahboomcar_mediapipe 01_HandDetector.py
2) Code
Code path:/home/yahboom/orbbec_ws/src/yahboomcar_mediapipe/scripts/01_HandDetector.py
x
#!/usr/bin/env python3# encoding: utf-8import rospyimport timeimport cv2 as cvimport numpy as npimport mediapipe as mpfrom geometry_msgs.msg import Pointfrom yahboomcar_msgs.msg import PointArray
class HandDetector: def __init__(self, mode=False, maxHands=2, detectorCon=0.5, trackCon=0.5): self.mpHand = mp.solutions.hands self.mpDraw = mp.solutions.drawing_utils self.hands = self.mpHand.Hands( static_image_mode=mode, max_num_hands=maxHands, min_detection_confidence=detectorCon, min_tracking_confidence=trackCon ) self.pub_point = rospy.Publisher('/mediapipe/points', PointArray, queue_size=1000) self.lmDrawSpec = mp.solutions.drawing_utils.DrawingSpec(color=(0, 0, 255), thickness=-1, circle_radius=6) self.drawSpec = mp.solutions.drawing_utils.DrawingSpec(color=(0, 255, 0), thickness=2, circle_radius=2)
def pubHandsPoint(self, frame, draw=True): pointArray = PointArray() img = np.zeros(frame.shape, np.uint8) img_RGB = cv.cvtColor(frame, cv.COLOR_BGR2RGB) self.results = self.hands.process(img_RGB) if self.results.multi_hand_landmarks: for i in range(len(self.results.multi_hand_landmarks)): if draw: self.mpDraw.draw_landmarks(frame, self.results.multi_hand_landmarks[i], self.mpHand.HAND_CONNECTIONS, self.lmDrawSpec, self.drawSpec) self.mpDraw.draw_landmarks(img, self.results.multi_hand_landmarks[i], self.mpHand.HAND_CONNECTIONS, self.lmDrawSpec, self.drawSpec) for id, lm in enumerate(self.results.multi_hand_landmarks[i].landmark): point = Point() point.x, point.y, point.z = lm.x, lm.y, lm.z pointArray.points.append(point) self.pub_point.publish(pointArray) return frame, img
def frame_combine(slef,frame, src): if len(frame.shape) == 3: frameH, frameW = frame.shape[:2] srcH, srcW = src.shape[:2] dst = np.zeros((max(frameH, srcH), frameW + srcW, 3), np.uint8) dst[:, :frameW] = frame[:, :] dst[:, frameW:] = src[:, :] else: src = cv.cvtColor(src, cv.COLOR_BGR2GRAY) frameH, frameW = frame.shape[:2] imgH, imgW = src.shape[:2] dst = np.zeros((frameH, frameW + imgW), np.uint8) dst[:, :frameW] = frame[:, :] dst[:, frameW:] = src[:, :] return dst
if __name__ == '__main__': rospy.init_node('handDetector', anonymous=True) capture = cv.VideoCapture(0) capture.set(6, cv.VideoWriter.fourcc('M', 'J', 'P', 'G')) capture.set(cv.CAP_PROP_FRAME_WIDTH, 640) capture.set(cv.CAP_PROP_FRAME_HEIGHT, 480) print("capture get FPS : ", capture.get(cv.CAP_PROP_FPS)) pTime = cTime = 0 hand_detector = HandDetector(maxHands=2) while capture.isOpened(): ret, frame = capture.read() # frame = cv.flip(frame, 1) frame, img = hand_detector.pubHandsPoint(frame, draw=False) if cv.waitKey(1) & 0xFF == ord('q'): break cTime = time.time() fps = 1 / (cTime - pTime) pTime = cTime text = "FPS : " + str(int(fps)) cv.putText(frame, text, (20, 30), cv.FONT_HERSHEY_SIMPLEX, 0.9, (0, 0, 255), 1) dist = hand_detector.frame_combine(frame, img) cv.imshow('dist', dist) # cv.imshow('frame', frame) # cv.imshow('img', img) capture.release() cv.destroyAllWindows()