Welcome to AI View Depth camera repository
8.Target tracking algorithm
8. Opencv application - target tracking
Locate the object in the continuous frames of the video is called tracking. In OpenCV, you can use traditional target tracking algorithms (such as mean tracking, Kalman filtering, etc.) or deep learning-based target trackers (such as MOSSE, CSRT, etc.) to track the target. Deep learning target trackers usually perform better in accuracy and robustness
8.1. Use
Source launch file path: /opt/ros/noetic/share/opencv_apps/launch
Step 1: Start the camera
xxxxxxxxxxroslaunch astra_visual opencv_apps.launch img_flip:=false
img_flip parameter: whether the image needs to be flipped horizontally, the default is false.
The [usb_cam-test.launch] file opens the [web_video_server] node by default, and you can directly use the [IP:8080] web page to view the image in real time.
Step 2: Start the corner detection function of Opencv_apps
xxxxxxxxxxroslaunch opencv_apps camshift.launch # Target tracking algorithmEach function case will have a parameter [debug_view], Boolean type, whether to use Opencv to display the image, displayed by default.
If you do not need to display, set it to [False], for example
xxxxxxxxxxroslaunch opencv_apps camshift.launch debug_view:=FalseHowever, after starting in this way, some cases may not be displayed in other ways, because in the source code, some [debug_view] is set to [False], which will turn off the image processing.
8.2, Display method
rqt_image_view
Enter the following command and select the corresponding topic
xxxxxxxxxxrqt_image_view
opencv
The system displays by default, no processing is required.
Web viewing
(Under the same LAN) Enter IP+port in the browser, for example:
xxxxxxxxxx192.168.2.116:8080
For specific IP, use your current virtual machine IP.
8.3, Effect display
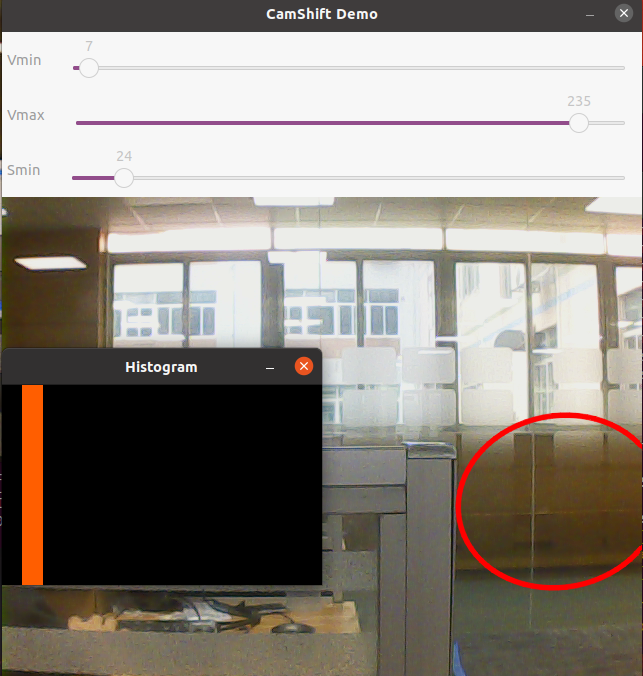
You can see an adjustable window appear on the screen, and a red frame appears to follow.