Welcome to AI View Depth camera repository
4.Face detection
4.Face detection
4.1 Dlib
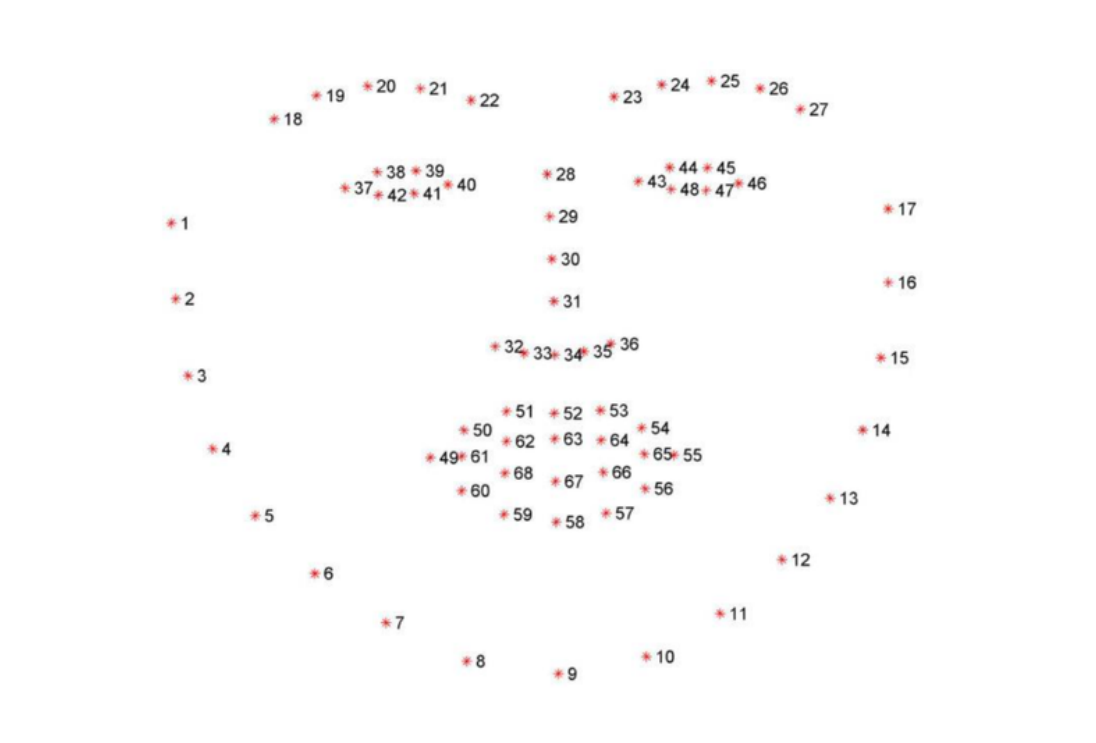
DLIB is a modern C++toolkit that includes machine learning algorithms and tools for creating complex software in C++to solve real-world problems. It is widely applied in fields such as machines, embedded devices, mobile phones, and high-performance computing environments in the industry and academia. The dlib library uses 68 points to mark important parts of the face, such as the right eyebrow at 18-22 points and the mouth at 51-68 points. Get the dlib library_ Frontal_ Face_ The detector module detects a face, causing a shape_ Predictor_ 68_ Face_ Landmarks. dat feature data predicts facial feature values.
4.2 Face detection
1) Start
Input following command:
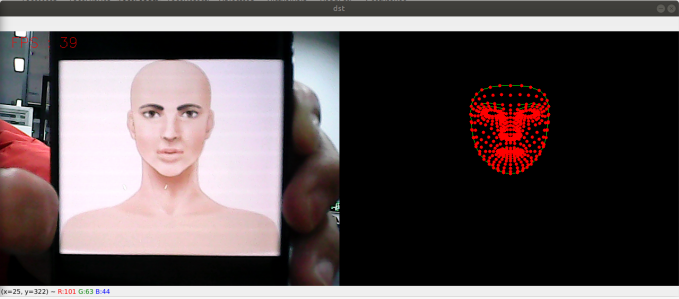
ros2 run yahboomcar_mediapipe 04_FaceMesh
2) Code
Code path: ~/orbbec_ws/src/yahboomcar_mediapipe/yahboomcar_mediapipe/04_FaceMesh.py
x#!/usr/bin/env python3# encoding: utf-8#import ros libimport rclpyfrom rclpy.node import Nodefrom geometry_msgs.msg import Pointimport mediapipe as mp#import define msgfrom yahboomcar_msgs.msg import PointArray#import commom libimport cv2 as cvimport numpy as npimport timeprint("import done")
class FaceMesh(Node): def __init__(self, name,staticMode=False, maxFaces=2, minDetectionCon=0.5, minTrackingCon=0.5): super().__init__(name) self.mpDraw = mp.solutions.drawing_utils self.mpFaceMesh = mp.solutions.face_mesh self.faceMesh = self.mpFaceMesh.FaceMesh( static_image_mode=staticMode, max_num_faces=maxFaces, min_detection_confidence=minDetectionCon, min_tracking_confidence=minTrackingCon ) self.pub_point = self.create_publisher(PointArray,'/mediapipe/points',1000) self.lmDrawSpec = mp.solutions.drawing_utils.DrawingSpec(color=(0, 0, 255), thickness=-1, circle_radius=3) self.drawSpec = self.mpDraw.DrawingSpec(color=(0, 255, 0), thickness=1, circle_radius=1)
def pubFaceMeshPoint(self, frame, draw=True): pointArray = PointArray() img = np.zeros(frame.shape, np.uint8) imgRGB = cv.cvtColor(frame, cv.COLOR_BGR2RGB) self.results = self.faceMesh.process(imgRGB) if self.results.multi_face_landmarks: for i in range(len(self.results.multi_face_landmarks)): if draw: self.mpDraw.draw_landmarks(frame, self.results.multi_face_landmarks[i], self.mpFaceMesh.FACEMESH_CONTOURS, self.lmDrawSpec, self.drawSpec) self.mpDraw.draw_landmarks(img, self.results.multi_face_landmarks[i], self.mpFaceMesh.FACEMESH_CONTOURS, self.lmDrawSpec, self.drawSpec) for id, lm in enumerate(self.results.multi_face_landmarks[i].landmark): point = Point() point.x, point.y, point.z = lm.x, lm.y, lm.z pointArray.points.append(point) self.pub_point.publish(pointArray) return frame, img
def frame_combine(slef,frame, src): if len(frame.shape) == 3: frameH, frameW = frame.shape[:2] srcH, srcW = src.shape[:2] dst = np.zeros((max(frameH, srcH), frameW + srcW, 3), np.uint8) dst[:, :frameW] = frame[:, :] dst[:, frameW:] = src[:, :] else: src = cv.cvtColor(src, cv.COLOR_BGR2GRAY) frameH, frameW = frame.shape[:2] imgH, imgW = src.shape[:2] dst = np.zeros((frameH, frameW + imgW), np.uint8) dst[:, :frameW] = frame[:, :] dst[:, frameW:] = src[:, :] return dst
def main(): print("start it") rclpy.init() capture = cv.VideoCapture(0) capture.set(6, cv.VideoWriter.fourcc('M', 'J', 'P', 'G')) capture.set(cv.CAP_PROP_FRAME_WIDTH, 640) capture.set(cv.CAP_PROP_FRAME_HEIGHT, 480) print("capture get FPS : ", capture.get(cv.CAP_PROP_FPS)) pTime, cTime = 0, 0 face_mesh = FaceMesh('face_mesh') while capture.isOpened(): ret, frame = capture.read() # frame = cv.flip(frame, 1) frame, img = face_mesh.pubFaceMeshPoint(frame,draw=False) if cv.waitKey(1) & 0xFF == ord('q'): break cTime = time.time() fps = 1 / (cTime - pTime) pTime = cTime text = "FPS : " + str(int(fps)) cv.putText(frame, text, (20, 30), cv.FONT_HERSHEY_SIMPLEX, 0.9, (0, 0, 255), 1) dst = face_mesh.frame_combine(frame, img) cv.imshow('dst', dst) # cv.imshow('frame', frame) # cv.imshow('img', img) capture.release() cv.destroyAllWindows()