yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
Raspberry Pi 4B📖
1.Preparation before use
  • 1.1 Download image
  • 1.2 Write image into SD card
  • 1.3 Start up Raspberry Pi
  • 1.4 Linux common commands
  • 1.5 Precautions
2.Basic course
  • 2.1 Log into Raspberry Pi system
  • 2.2 Change password and root account
  • 2.3 Remote transfer file
  • 2.4 Backup image file
  • 2.5 Fixing Raspberry Pi IP
  • 2.6 Set screen keep on
  • 2.7 Get Pi temperature
  • 2.8 Connect WIFI
  • 2.9 Modify Pi time
  • 2.10 Set the boot self-starting program
3.Expand course
  • 3.1 Serial port communicates with external devices
  • 3.2 2.Serial port login Pi
  • 3.3 Configured as a router
  • 3.4 Install Jupyter Lab
  • 3.5 Install Jupyter Widgets
  • 3.6 More Detail for Widgets
  • 3.7 Install OpenCV
  • 3.8 Install Tensorflow
4.Programming course
C language
  • 1.Development environment
  • 2.Print Hello World
  • 3.Pin output level
  • 4.Read pin level
  • 5.PWM output
Python language
  • 1.Development environment
  • 2.Print basic usage
  • 3.Pin output level
  • 4.Read pin level
  • 5.PWM output
5.AI vision course
A.Getting started with OpenCV
  • 6.Picture Rotation
  • 1.Introduction of OpenCV
  • 2.OpenCV image read and display
  • 3.OpenCV image write
  • 4.OpenCV image quality
  • 5.OpenCV pixel operation
B.OpenCV Geometric transformat
  • 1.Picture Zoom
  • 2.Picture Cut
  • 3.Picture Shift
  • 4.Picture Mirroring
  • 5.Affine Map
  • 7.Perspective Transformation
C.OpenCV picture processing
  • 1.Grayscale processing
  • 2.Image Binarization
  • 3.Edge detection
  • 4.Drawing line segment
  • 5.Drawing rectangle circle
  • 6.Drawing text picture
D.OpenCV image beautification
  • 1.Histogram of color pictures
  • 2.Histogram equalization
  • 3.Image restoration
  • 4.Brightness enhancement
  • 5.Skin whitening
  • 6.Gaussian mean filtering
  • 7.Median filtering
F.AI Advanced Course (Ubuntu system)
  • 1. QR code
  • 2. Human posture estimation
  • 3. Target detection
  • 4. Mediapipe development
  • 5. yolov4-tiny
E.Install TensorFlow
  • Install TensorFlow
6.ROS1 coursenew
Basic Course
  • 1.ROS introduction
  • 2.Project file structure
  • 3.Common commands and tools
  • 4.Publisher
  • 5.Subscribers
  • 6.Customize topic messages and use
  • 7.Client
  • 8.Server
  • 9.Custom service messages and usage
  • 10.TF release and monitoring
Visual Image Processing
  • 1. AR vision
  • 2. AR QR code
  • 3. ROS+Opencv foundation
  • 4. ROS+Opencv application
  • 5. MediaPipe development
7.ROS2 coursenew
Docker Course
  • 1.Overview and installation
  • 2.Common commands
  • 3.Understand and publish images
  • 4.Hardware interaction data processing
  • 5.Enter docker container
  • 6.Update docker images
Basic Course
  • 1.Introduction to ROS2
  • 2.Commands and tools
  • 3.ROS2 Topic communications
  • 4.ROS2 service communications
  • 5.ROS2launch file starts
OpenCV Course
  • 1.OpenCV Basic Course
  • 2.ROS+opencv application
  • 3.QR code recognition
  • 4.AR Vision
  • 5.Mediapipe
8.Accessories installation
  • 1. Installation of heat sink
  • 2. Wiring of cooling fan
  • 3. Double fan armor case Installation
  • 4. Argon NEO aluminum case installation
  • 5. Argon ONE aluminum alloy case installation
  • 6. Metal shell with built-in fan installation
  • 7. Acrylic case with cooling fan installation
  • 8. White-red ABS protective case installation
Download
  • Tools
  • C_code
  • Python code
  • ROS System
Download ZIP

Welcome to Raspberry Pi 4B repository

3.Image restoration

Image restoration

Image restoration is a type of algorithm in computer vision whose goal is to fill the area within an image or video. It is also used to delete small, no need objects in the image.

dst = cv2.inpaint(src, inpaintMask, inpaintRadius, flags)

Parameter Description:

l src: source image(original image)

l inpaintMask: binary mask indicating pixels to be repaired.

l dst: result image

l inpaintRadius: radius of restoration

l flags: restoration algorithm, mainly including INPAINT_NS (Navier-Stokes based method) or INPAINT_TELEA (Fast marching based method)

Code:

# Add damage to the original image
import cv2 
import numpy as np
import matplotlib.pyplot as plt
 
img = cv2.imread('yahboom.jpg',1)
for i in range(200,300):
    img[i,200] = (255,255,255)
    img[i,200+1] = (255,255,255)
    img[i,200-1] = (255,255,255)
for i in range(150,250):
    img[250,i] = (255,255,255)
    img[250+1,i] = (255,255,255)
    img[250-1,i] = (255,255,255)
cv2.imwrite('damaged.jpg',img)
# cv2.imshow('image',img)
# cv2.waitKey(0)
img = cv2.cvtColor(img, cv2.COLOR_BGR2RGB)
plt.imshow(img)
    plt.show()

 After running the following program, a pictures will be displayed in the jupyterLab control interface, as shown below.
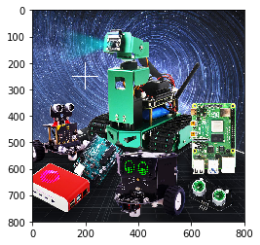
 

image.png 


#1 damaged image 2 mask 3 inpaint
import cv2 
import numpy as np
import matplotlib.pyplot as plt
 
img = cv2.imread('damaged.jpg',1)
#cv2.imshow('src',img)
imgInfo = img.shape
height = imgInfo[0]
width = imgInfo[1]
paint = np.zeros((height,width,1),np.uint8)
 
for i in range(200,300):
    paint[i,200] = 255
    paint[i,200+1] = 255
    paint[i,200-1] = 255
for i in range(150,250):
    paint[250,i] = 255
    paint[250+1,i] = 255
    paint[250-1,i] = 255
#cv2.imshow('paint',paint)
#1 src 2 mask
imgDst = cv2.inpaint(img,paint,3,cv2.INPAINT_TELEA)
 
# cv2.imshow('image',imgDst)
# cv2.waitKey(0)
img = cv2.cvtColor(img, cv2.COLOR_BGR2RGB)
paint = cv2.cvtColor(paint, cv2.COLOR_BGR2RGB)
imgDst = cv2.cvtColor(imgDst, cv2.COLOR_BGR2RGB)
 
 
plt.figure(figsize=(14, 9), dpi=100)  # Set the size and pixels of the drawing area
plt.subplot(131)  # The first in a row and three columns
plt.imshow(img)
plt.subplot(132)  # The second in a row and three columns
plt.imshow(paint)
plt.subplot(133)  # The third in a row and three columns
plt.imshow(imgDst)
    plt.show()

 After running the above program, three pictures will be displayed in the jupyterLab control interface, as shown below.
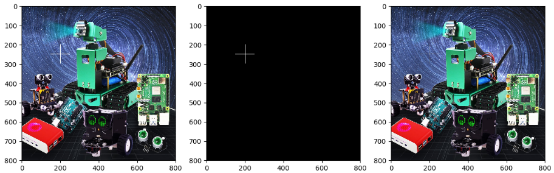
image.png 


Histogram equalization
Brightness enhancement

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文