yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
Muto S2 Robot📖
1.Introduction to Muto Robot
  • 1.Introduction to Muto Robot
  • 2.Accessories introduction
  • 3.Precautions for battery
  • 4.FAQ
2.Assembly and write system
  • 1.Raspberry Pi write system
  • 2.Jetson Nano write sytem
  • 3. Robot assembly tutorial
  • 4. Installation Video Part1-Part5
  • 4. Installation Video Part6-Part10
3.Remote control course
  • 1.Close APP control process
  • 2.Mobile APP remote control tutorial
  • 3.USB wireless handle remote control
4.Linux basic course
  • 1.Introduction to Linux system
  • 2.Ubuntu file system
  • 3.Ubuntu common commands
  • 4.Ubuntu common editors
  • 5.Ubuntu software operation commands
  • 6.Virtual machine installation
  • 7.SSH remote control
  • 8.VNC remote control
  • 9.Transfer files remotely
  • 10.Driver library and communication
  • 11.Static IP and hotspot mode
  • 12.Bind device ID
  • 13.Capacity expansion and resource allocation
  • 14.Update system software sources
  • 15.Set root user password
  • 16.sudo free password
  • 17.Connect to WiFi network
  • 18.View system version
  • 19.Customized service management
  • 20.Back up system image
5.JupyterLab course
  • 1.ReadMe before operate
  • 2.Environment setup
  • 3.Basic usage tutorial
  • 4.Widgets configuration
  • 5.Widgets controls use
6.Jetson NANO course
  • 1.About JetsonNano system
  • 2.Network configuration and Jtop
  • 3.swap space increased
  • 4.API usage of GPIO library
  • 5.Hardware library configuration
  • 6.Pin reading function
  • 7.Pin level output control
  • 8.Control LED
  • 9.Jetson Nano communicates with external device serial ports
  • 10.jetson nano I2C communication
7.Raspberry Pi course
  • 1.Python usage
  • 2.Use APT to install Python packages
  • 3.Python virtual environment
  • 4.GPIO Zero
  • 5.Pin output high and low levels
  • 6.Pin reads high and low levels
  • 7.Pin output PWM
  • 8.Serial communication
  • 9.I2C communication
8.Robot basic course
  • 1.Control buzzer
  • 2.Control PWM servo
  • 3.Control bus servo
  • 4.Robot forward and backward
  • 5.Robot move left and right
  • 6.Robot rotate left and right
  • 7.Control height
  • 8.Control head
  • 9.Action group performance
  • 10.Read data
  • 11.Host computer control
  • 12.Camera driver
9.Open Source CV course
  • 1.Introduction to Open Source CV
  • 2.Image reading and display
  • 3.Picture writing
  • 4.Image Quality
  • 5.Pixel operations
  • 6.Image zoom
  • 7.Picture cut
  • 8.Picture pan
  • 9.Picture mirroring
  • 10.Affine transformation
  • 11.Picture rotation
  • 12.perspective transformation
  • 13.Grayscale processing
  • 14.Binary image
  • 15.Edge green detection
  • 16.Line segment drawing
  • 17.Rectangular circle drawing
  • 18.Text and picture drawing
7.AI vision course
  • 0.Color HSV value calibration
  • 1.Color recognition
  • 2.Color tracking
  • 3.Color following
  • 4.Color recognition action group
  • 5.Face detection
  • 6.Face tracking
  • 7.Greet people
  • 8.QR code recognition
  • 9.QR code instructions
  • 10.visual line following
  • 11.Motion learning
  • 12.Teach pendant synchronized action
8.Machine deep learning
  • 1.KNN
  • 2.TensorFlow basic tutorial
  • 3.Basic use of PyTorch
  • 4.Yolov5 detects objects in real time
  • 5.Jetson-inference environment construction(selective viewing)
  • 6.Object detection and action
  • 7.Body movement control robot
  • 8.Gesture controlled robot
Remote login control
  • 1. VNC and SSH remote login
  • 2. Jupyter lab login and case code running
9.FAQnew
  • Using your own Jetson board, Muto S2 cannot start normally
Download
  • APP(iOS/Android)
  • SystemFile_For_RPi5
  • System_for_RPi4
  • System_for_JetsonNANO
  • Hardware and protocol
  • Instruction manual
  • Jetson_Boot_USB.tar.gz
Download ZIP

Welcome to Muto S2 Robot repository

2. Jupyter lab login and case code running

Jupyter lab login and case code running

1.Jupyter lab login

1.1 LAN connection

Note: Using the factory image provided by Yahboom, SSH, VNC, jupyter lab and other related environments are configured, and the boot is self-starting. Please do not reconfigure it yourself, otherwise exceptions will occur, and you will need to follow the tutorial to re-burn the factory image.

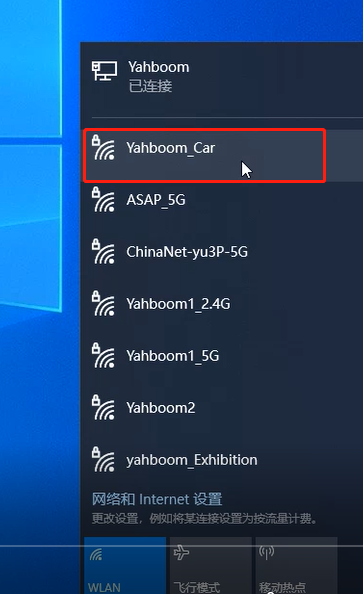
Connect your Windows computer to the car to send out a hotspot, taking the Raspberry Pi 4WD car as an example. The computer finds the wifi name of the car Yahboom_car (the hotspot name and password issued by other models of products can be viewed according to the manual), enter the password: 12345678 to connect, the default IP address of the car is 192.168 .50.1 . (The IP address of other models of products is not necessarily this. You can check it according to the manual, or through the oled display connected to the product. The default IP addresses of other products are 192.168.1.11 and 192.168.8.88).

If the computers are on the same network and have been verified to be able to log in via VNC or SSH, you can generally log in to jupyter lab directly and skip the mutual IP ping verification process.
 

1.2 Check network connectivity

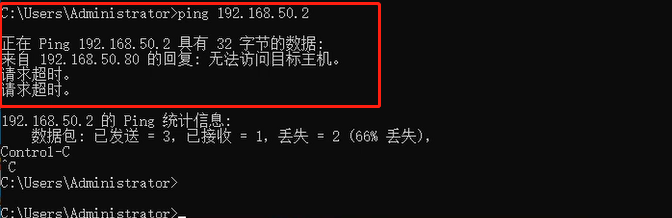
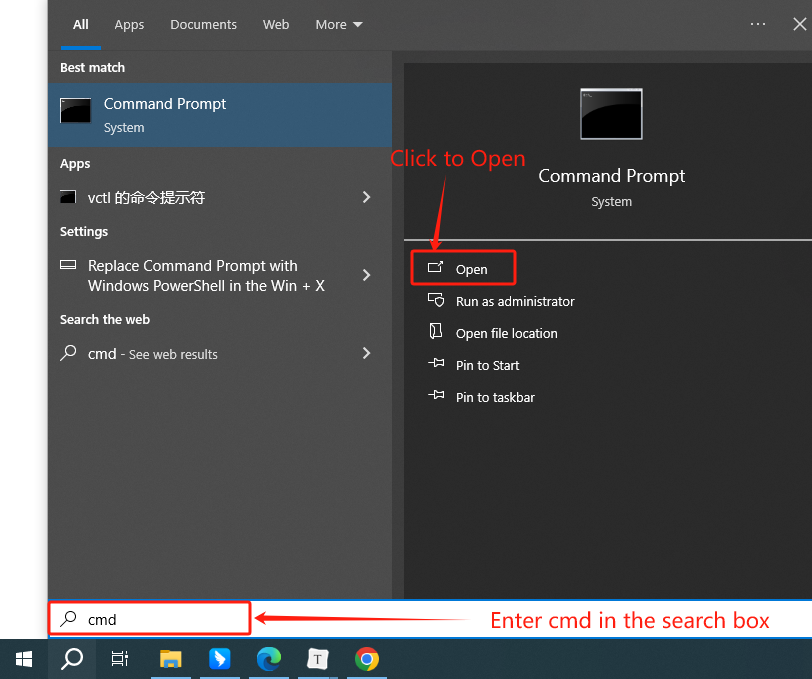
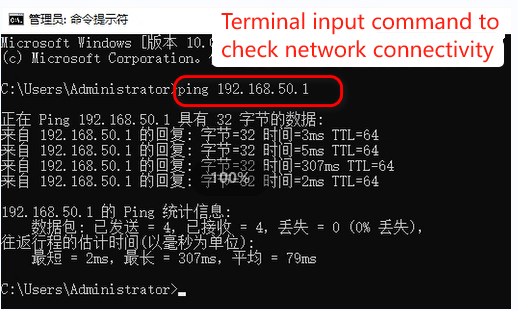
Enter cmd in the computer search window to open the command running window, and ping the IP address of the car in the terminal (for example: ping 192.168.50.1) to check whether the network is open. If a reply appears, it means that the network is smooth. If the target host cannot be accessed, it means that the network is not smooth. You need to check whether the firewall is turned on on the computer and turn off anti-virus software such as Tinder.


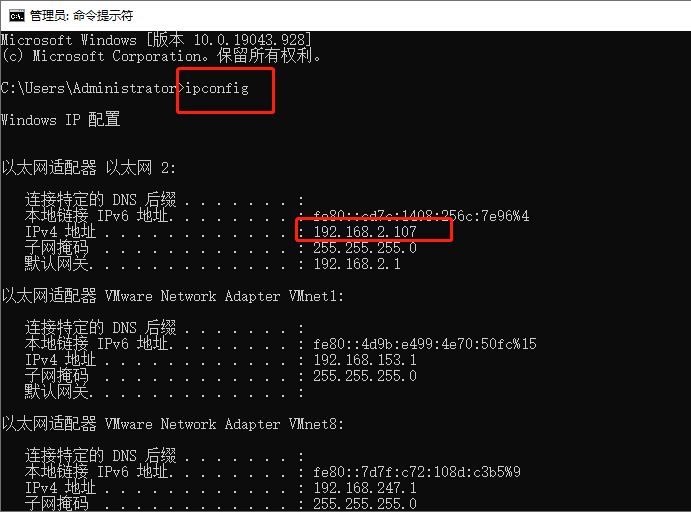
Note: If the motherboard system is connected to its own router network, or is not a spontaneous hotspot product (a network connected through a distribution network or network cable). Both the car system terminal and the windows computer terminal need to ping each other's IP. If one party cannot ping successfully (windows computers check the IP address through the command ipconfig, and the motherboard system checks the IP address through the command ifconfig). It means there is a problem with the network. Please change to another LAN to connect. Please do not connect to the campus network. The campus network is blocked and remote login such as VNC and SSH is not possible.


1.3 Jupyter lab login

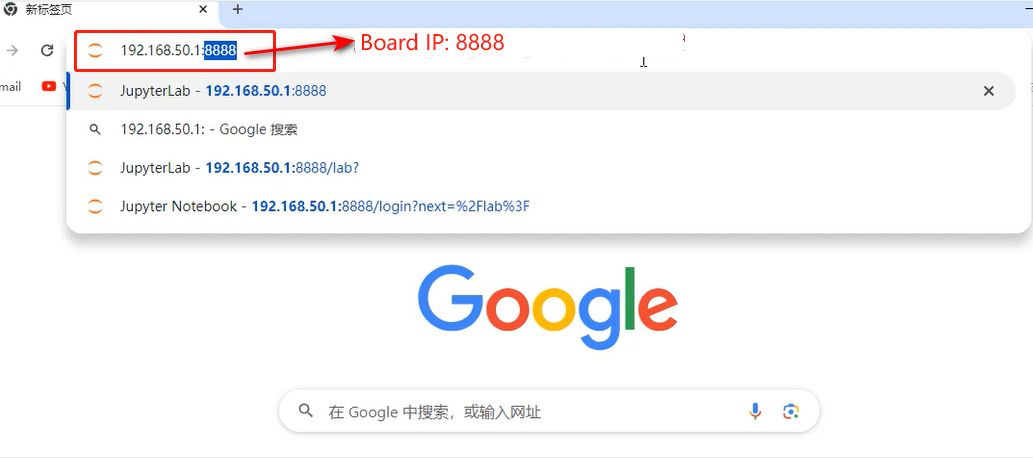
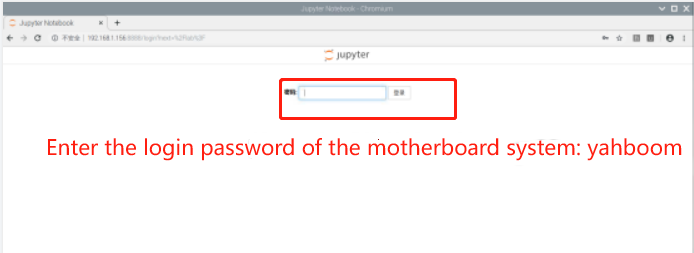
Open Google Chrome on your computer and enter the IP address of the car to log in. For example, the IP address of the spontaneous hotspot of the Raspberry Pi 4wd car is 192.168.50.1. Enter 192.168.50.1:8888 in the browser. Press the Enter button to log in. In the pop-up interface, enter the system password: yahboom. Please note that it is case-sensitive. After remembering the password, you do not need to enter the password again when you log in next time.
2. Run the case code

Taking the Raspberry Pi 4WD car as an example, the following interface will appear after successfully logging into jupyter lab.
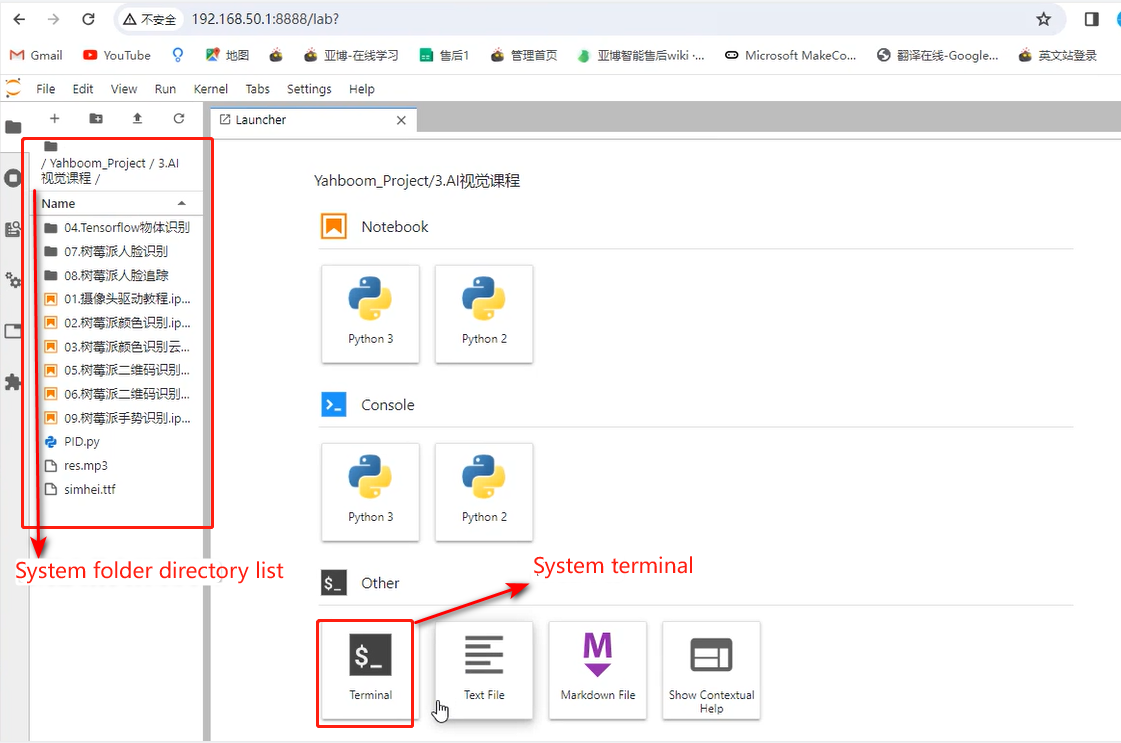


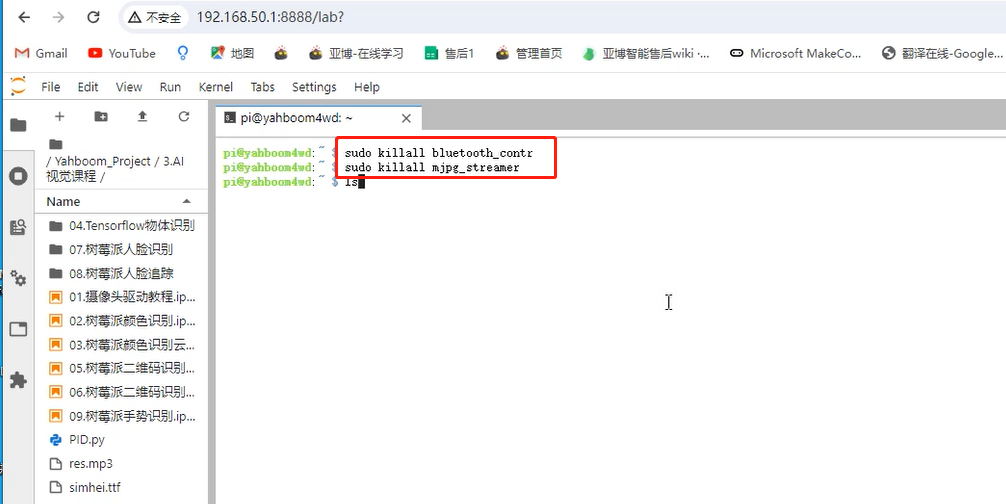
Open the terminal and close the process used for the mobile app to start the connection class. Failure to close it will occupy peripheral resources and cause the case code to run abnormally. The operation methods of other types of products are different. For details, you can check the closing and opening chapters of the APP's self-starting factory program. If you close the large program permanently, you don't need to repeat this operation every time you turn on the computer.


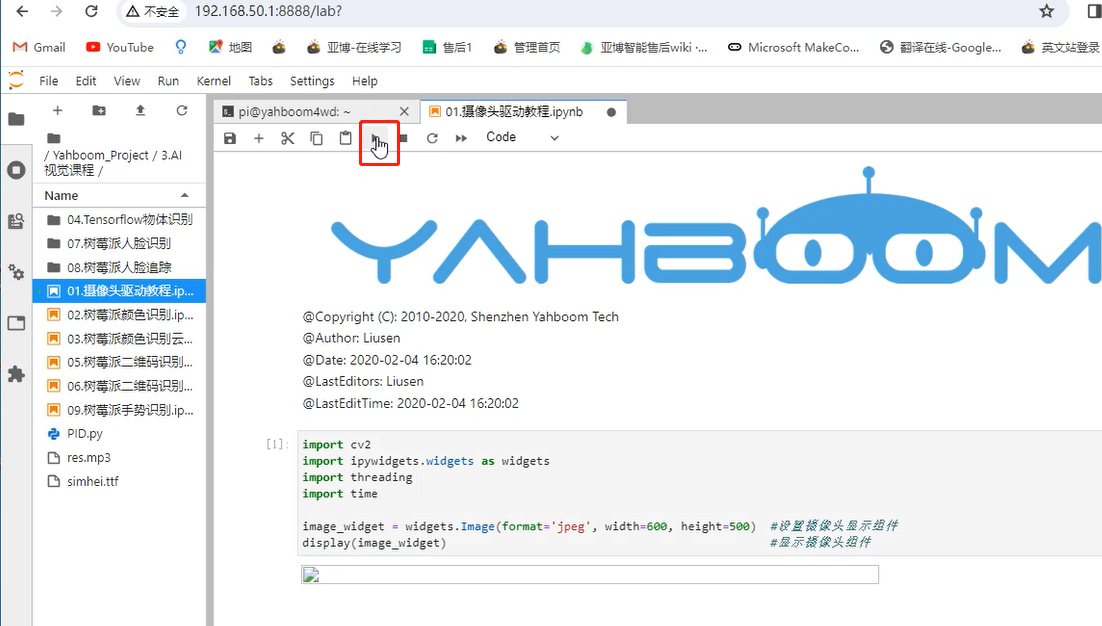
This time, we take the case of driving the camera on the Raspberry Pi 4wd car as an example. Find the driver code in the corresponding path of the driver camera and open it. Click single-step execution to run the code section by section, and wait until the code is executed. You can open the camera screen.
 

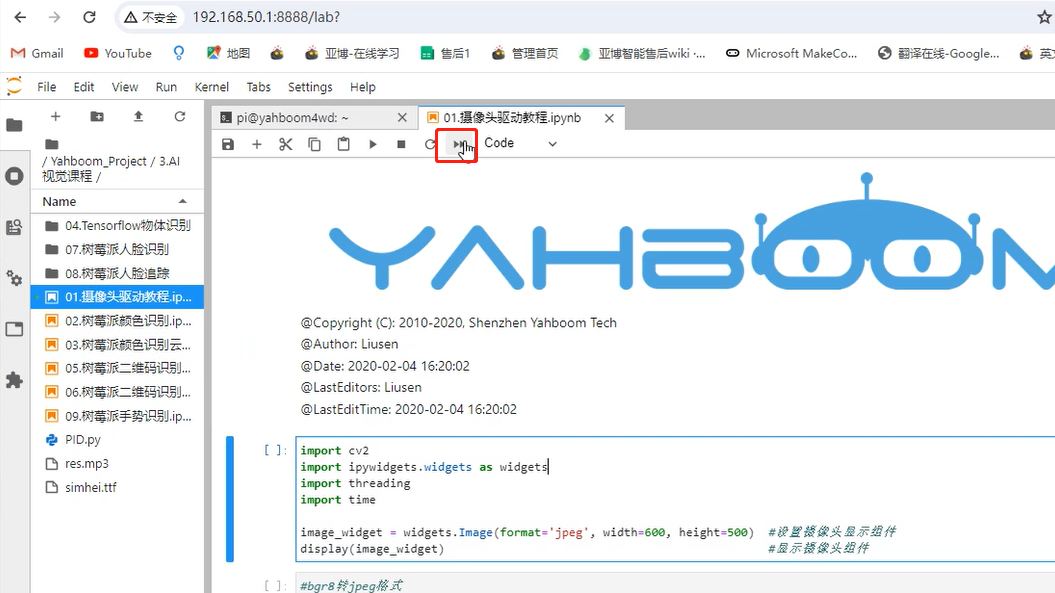
You can also click the Run All button yourself, and the code will run quickly.


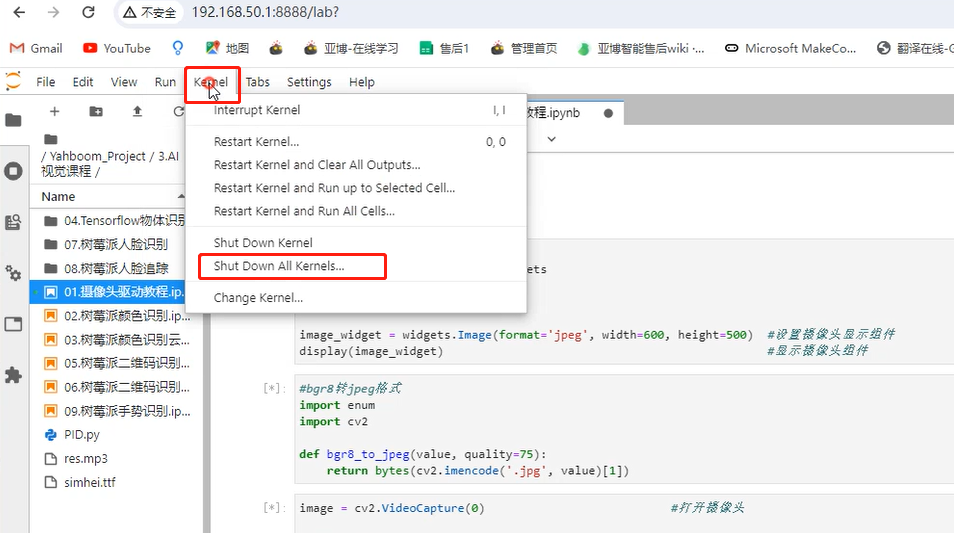
Each time you finish running a case, you need to close the running process, otherwise an exception will occur when running the next case.
 

For other functions in jupyter lab, you can view tutorials in other chapters, or refer to the official website tutorial.

https://jupyterlab.readthedocs.io/en/stable/user/interface.html

VNC and SSH remote login
Using your own Jetson board, Muto S2 cannot start normally

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文