yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
Jetson ORIN NANO SUPER📖
01.Get started
  • 01. Learning route
  • 02. Get started quickly
  • 03. System Update Notesnew
  • 04. Disable automatic updates and troubleshooting issues
  • 05. Notes on Jetson Orin Nano Official Kitnew
02.Jetson basic course
  • 01.Jetson board introduction
  • 02.Write Jetson original system
  • 03.Installing Jetson environment
  • 04.Backup SSD system
  • 05.Restore initial image system
  • 06.Write SUPER original system(optional)
  • 07.Write SUPER boot (optional)
  • 08. SSD expansion
  • 09.Jetpack old system upgraded to Yahboom SUPER factory system
  • 10.Write the system onto your own solid-state drive
03.Basic setting course
  • 01.Basic knowledge
  • 02.Network configuration
  • 03.SSH remote login
  • 04.VNC remote control
  • 05.Remote file transfer
  • 06.Jtop tool
  • 07.Exchange space expansion
  • 08.Use VSCode
  • 09.Use VMware
04.GPIO control course
  • 01.GPIO description
  • 02.GPIO library installation
  • 03.GPIO reading
  • 04.GPIO output
  • 05.Serial communication
  • 06.I2C communication
05.Vision basic course
  • 01.CSI camera preview
  • 02.USB camera preview
  • 03.Use Jupyter Lab
  • 04.Use JetCam
06.OpenCV basic course
  • 01.Image reading
  • 02.Image saving
  • 03.Image modification
  • 04.Image scaling
  • 05.Image cropping
  • 06.Image translation
  • 07.Image mirroring
  • 08.Image grayscale conversion
  • 09.Image binarization
  • 10.Image edge detection
  • 11.Add line segments
  • 12.Add rectangles
  • 13.Add circular shape
  • 14.Add ellipses
  • 15.Add polygons
  • 16.Add Text
  • 17.Preview USB camera image
  • 18.Preview CSI camera image
07.Vision advanced course
01.Environment construction
  • 01.TensorFlow
  • 02.PyTorch
  • 03.Torchvision
02.DeepStream development
  • 01.DeepStream environment
  • 02.Four types of detection(traffic)
03.YOLO11 development
  • 01.YOLO environment construction
  • 02.CLI use
  • 03.Object detection
  • 04.Instance segmentation
  • 05.Pose estimation
  • 06.Image classification
  • 07.Oriented object detection
  • 08.Model conversion
  • 09.Dataset annotation
  • 10.Model training conversion
  • 11.Model prediction
04.Mediapipe development
  • 01.Mediapipe environment
  • 02.Hand detection
  • 03.Face detection
  • 04.Face effects
  • 05.3D object recognition
  • 06.Virtual brush
  • 07.Gesture recognition
  • 08.Finger control
  • 09.Posture estimation
  • 10.Face mask
  • 11.Overall detection
  • 12.Green scene removal(Human)
05.QR code recognition
  • QR code recognition
06.YOLO26 development
  • 01.YOLO environment constructionnew
  • 02.CLI usenew
  • 03.Object detectionnew
  • 04.Instance segmentationnew
  • 05.Pose estimationnew
  • 06.Image classificationnew
  • 07.Oriented object detectionnew
  • 08.Model conversionnew
  • 09.Dataset annotationnew
  • 10.Model training conversionnew
  • 11.Model predictionnew
08.Docker basic course
  • 01.Docker introduction
  • 02.Docker installation
  • 03.Docker command
  • 04.Docker usage
  • 05.Docker interaction
09.ROS1-Melodic
01.ROS1 basic course
  • 01. Introduction to ROS
  • 02. Project file structure
  • 03. Common commands and tools
  • 04. Publisher
  • 05. Subscribers
  • 06. Customize topic messages and use
  • 07. Client
  • 08. Server
  • 09. Customize service messages and usage
  • 10. TF release and monitoring
02.ROS1 vision course
  • 00.Must read before running
  • 01.Camera preview
  • 02.QR code
  • 03.Human posture estimation
  • 04.Target detection
  • 05.AR vision
  • 06.Opencv application
  • 07.ROS+Opencv basics
  • 08.Mediapipe development
10.ROS2-Humble
01.ROS2 basic course
  • 01.Introduction to ROS2
  • 02.ROS2 install Humble
  • 03.ROS2 development environment
  • 04.ROS2 workspace
  • 05.ROS2 function package
  • 06.ROS2 node
  • 07.ROS2 topic communication
  • 08.ROS2 service communication
  • 09.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
02.ROS2 vision course
  • 01.Camera preview (USB)
  • 02.Camera preview (CSI)
  • 03.Camera calibration (USB)
  • 04.Camera calibration (CSI)
  • 05.AR vision (USB)
  • 06.AR vision (CSI)
11.Offline AI model coursenew
Offline large model (Text Interaction)
  • 1.AI large model environment deployment
  • 2.Install large model dialogue platform
  • 3.Meta Al Llama3.2 model
  • 4.Alibaba Cloud Qwen3 model
  • 5.Microsoft Phi-4-mini model
  • 6.DeepSeek DeepSeek-R1 model
  • 7.Alibaba Cloud Qwen2.5v visual multimodal large model
  • 8.Google Gemma3 visual multimodal large model
  • 9.Lava visual multimodal large model
  • 10.MiniCPM-V visual multimodal large model
  • 11.Multimodal visual understand application
  • 12.Multimodal text image application
  • 13.Multimodal video analysis application
  • 14.Multi module visual position application
  • 15.Multimodal table scanning application
  • 16.Multimodal autonomous agent application
Offline large model (Voice Interaction)
  • 0.Voice interaction hardware connection (ReadMe)
  • 1.Offline speech to text (ASR)
  • 2.Offline text to speech (TTS)
  • 3.AI large model voice interaction
  • 4.Multimodal visual understand speech interaction
  • 5.Multimodal text and graphics application
  • 6.Multimodal video analysis application
  • 7.Multi module visual position application
  • 8.Multimodal table scanning application
  • 9.Multimodal autonomous proxy application
  • 10.AI large model offline voice assistant
12.Online AI model coursenew
Online large model (Text Interaction)
  • 1.OpenRouter large model API aggregation platform
  • 2.Multimodal visual understand application
  • 3.Multimodal visual localization application
  • 4.Multimodal table scanning application
  • 5.Multimodal autonomous proxy application
Online large model (Voice Interaction)
  • 0.Voice interaction hardware connection (ReadMe)
  • 1.Online speech to text (ASR)
  • 2.Online text to speech (TTS)
  • 3.AI large model voice interaction
  • 4.Multimodal visual understand speech interaction
  • 5.Multi module visual position application
  • 6.Multimodal table scanning application
  • 7.Multimodal autonomous proxy application
  • 8.AI large model online voice assistant
13.NVIDIA lsaac ROS coursenew
  • 1.Build lsaac ROS environment
  • 2.Deep segmentation
  • 3.DNN stereoscopic depth
  • 4.Free space segmentation
  • 5.Image distortion processing
  • 6.Image segmentation
  • 7.3D scene reconstruction and mapping
  • 8.Object detection
  • 9.3D attitude estimation
  • 10.Visual SLAM
14.OpenClaw Deployment and Basic Usagenew
  • 01.OpenClaw Quick Start on Jetson Platform
  • 02.OpenClaw Deployment
  • 03.OpenClaw WhatsApp Plugin Application
  • 04.OpenClaw WebChat Interaction
  • 05.OpenClaw TUI Interaction
  • 06.OpenClaw Tools Introduction
  • 07.OpenClawGate Gateway User Manual
  • 08.OpenClaw Features Overview
  • 09.OpenClawHub Introduction (Skill Installation)
  • 10.OpenClaw Application - File Management
  • 11.OpenClaw Application - Camera
  • 12.OpenClaw Application - Browser Control
  • 13.OpenClaw Application - Script Execution
  • 14.OpenClaw Application - AI Programming (Peripheral & GPIO Control)
  • 15.OpenClaw Application - Dedicated AI Assistant
  • 16.OpenClaw Web Search Capability Configuration
15.OpenClaw Advanced Developmentnew
1.Preparation Before Use
  • 01. Peripheral Hardware Configuration
  • 02. OpenClaw API-KEY Configuration
  • 03. OpenClaw Model Switching
  • 04. OpenClaw Prompts
  • 05. AI Voice Interaction Configuration
  • 06. Three Dialogue Configuration Tests
2.OpenClaw AI Programming Peripheral Control
  • 1. Servo Control
  • 2. RGB Strip
  • 3. OLED Display
  • 4. Temperature and Humidity Sensor
  • 5. Camera Application
  • 6. AI Script Peripheral Control
3.OpenClaw Peripheral Integration Applications
  • 1. Plant Care Assistant
  • 2. AI Calorie Estimation
  • 3. AI Rock Paper Scissors Game
  • 4. AI Pet
  • 5. AI Weather Station
  • 6. Temperature and Humidity Dashboard
  • 7. Scheduled Tasks
Download
  • System_File
  • VM_File
  • 3D_Model_File
  • DataSheet_File
  • Software_Tools
  • Code
  • Instruction_Manual
  • ROS2_Basic_VM
Download ZIP

Welcome to Jetson ORIN NANO SUPER repository

当製品の日本語版マニュアル資料は、こちらからご取得ください。

1. Plant Care Assistant

OpenClaw Plant Care Assistant Tutorial

Before starting, please complete the [01-Hardware Configuration], [02-openclaw API-KEY Configuration], [03-openclaw Model Switching], [04-AI Voice Interaction Configuration], [05-Three Dialogue Solution Configuration Tests] under the Prerequisites directory. If you are currently only using TUI / whatsapp, you can skip 04 for now. This article assumes the basic environment has been prepared and only expands on the plant care project itself.

1. Tutorial Objectives

This article demonstrates OpenClaw's multi-peripheral coordination capability through the plant care scenario.

  • Understand how to combine temperature/humidity, OLED, RGB, and camera into a plant care assistant

  • Communicate with OpenClaw through three methods: whatsapp, TUI, and voice code

2. Hardware Preparation

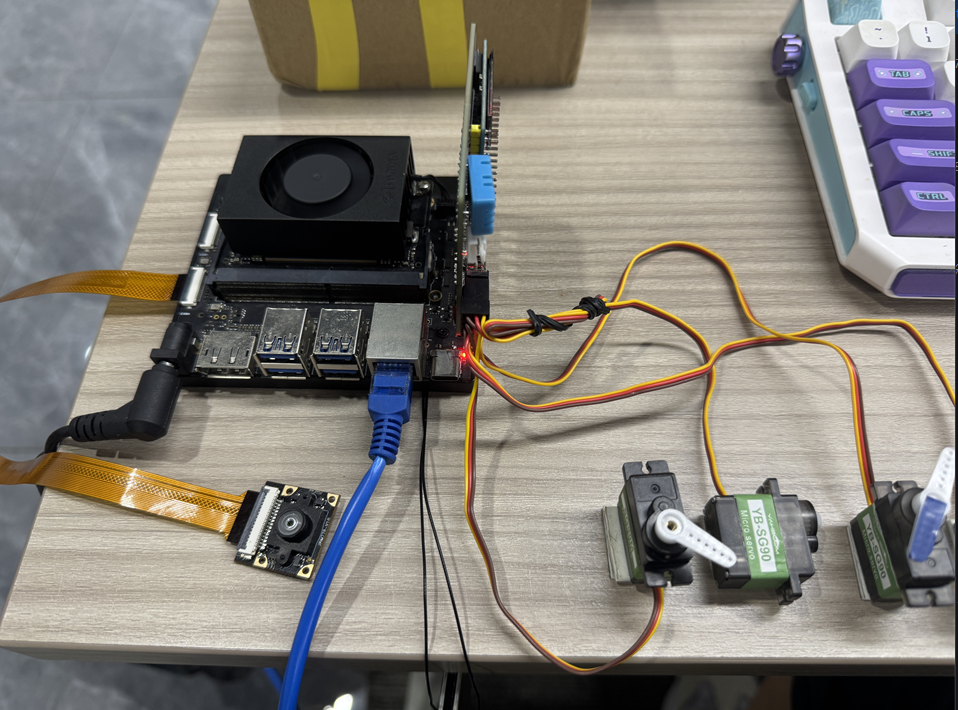
  • OpenClaw mainboard

  • DHT temperature and humidity sensor

  • OLED display

  • RGB light strip / RGB light bead module

  • CSI camera

  • [Optional] AI voice module + speaker

  • Wiring diagram

image-20260601101101156

3. Software Preparation

Code entry points that will be used in the tutorial

  • Camera photo command: /home/jetson/hardware_hal_demo/seewhat

  • Voice entry: /home/jetson/voice_to_openclaw/src/main.py

This project is essentially not dependent on a single "large project script", but lets OpenClaw orchestrate multiple basic tools:

  • dht is responsible for reading environmental temperature and humidity

  • oled is responsible for displaying care information

  • rgb is responsible for status alerts

  • seewhat is responsible for observing plant appearance

4. Test Project Basic Capabilities

Before starting this project, please complete one openclaw tui basic dialogue self-check; if you haven't done it yet, see [05-Three Dialogue Solution Configuration Tests]. After passing, enter TUI to verify the basic capabilities in the project.

Terminal input:

openclaw tui
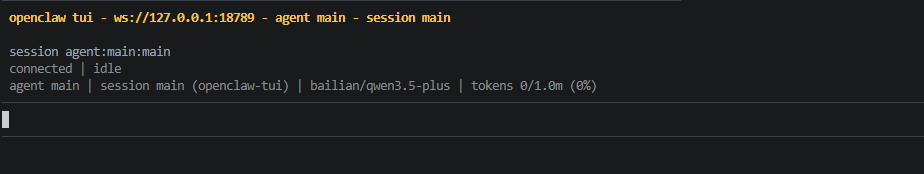
image-20260601101153207

After confirming OpenClaw can dialogue normally, you can try the following types of commands:

  • Read current temperature and humidity

  • Display "Plant OK" on OLED

  • Change RGB light to green

  • Help me take a photo

If these individual capabilities can all run through, it indicates that the main chains required by the project are all prepared.

5. Three Solutions for Communicating with OpenClaw

SolutionSuitable ScenariosAdvantagesRecommended Positioning
whatsappRemote care, classroom demonstrationsEasy to connect, suitable for remote status viewingDemonstrate "remote natural language care"
TUILocal debugging, project joint debuggingMost direct, easiest to troubleshootFirst run through multi-peripheral chain
Voice codeVoice companionship, complete AI experienceCloser to real assistant experienceAs final demonstration solution

If optional AI voice module + speaker are selected, whatsapp dialogue, tui, whatsapp dialogue need to broadcast OpenClaw's reply content. You can run the following program in terminal. AI voice module dialogue does not need to run repeatedly

  • Modify whether to enable broadcast parameter

xxxxxxxxxx
/home/jetson/voice_to_openclaw/.env
xxxxxxxxxx
ENABLE_TTS=true  #This parameter controls whether to broadcast. After modification and saving, run the following program in terminal
  • Terminal input

xxxxxxxxxx
cd ~/voice_to_openclaw
source .venv/bin/activate
python -m src.openclaw_session_tts

image-20260601101210272

5.1 whatsapp Solution

For whatsapp connection and robot creation steps, please directly refer to [05-Three Dialogue Solution Configuration Tests]. This section only retains dialogue examples suitable for the plant care project.

After successfully creating a robot, you can remotely inquire about plant status in whatsapp, for example:

  • Take a photo to see the current plant status, and perform plant care
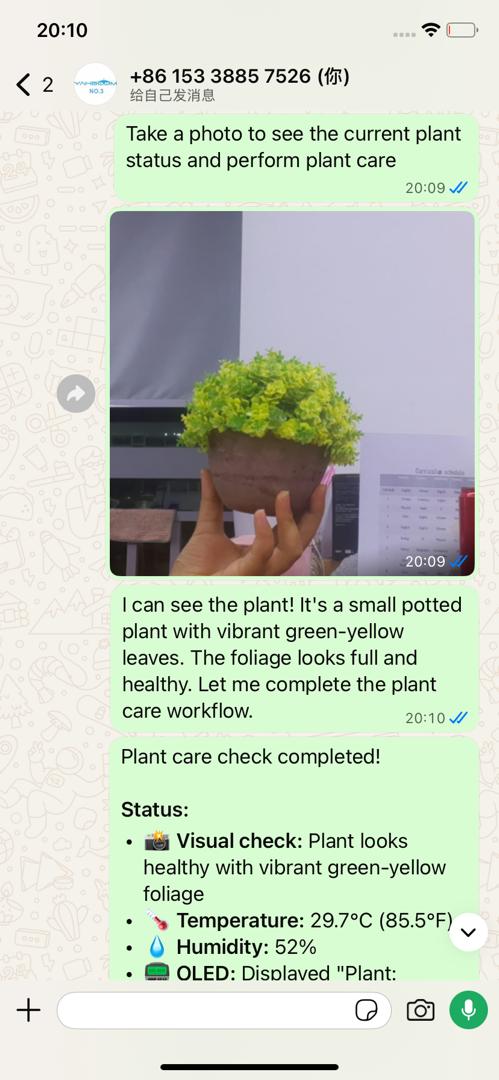
image-20260428152248217

5.2 TUI Solution

If you have completed the TUI self-check in Chapter 0, directly enter terminal text dialogue:

xxxxxxxxxx
openclaw tui

Then you can directly enter project-related commands, for example:

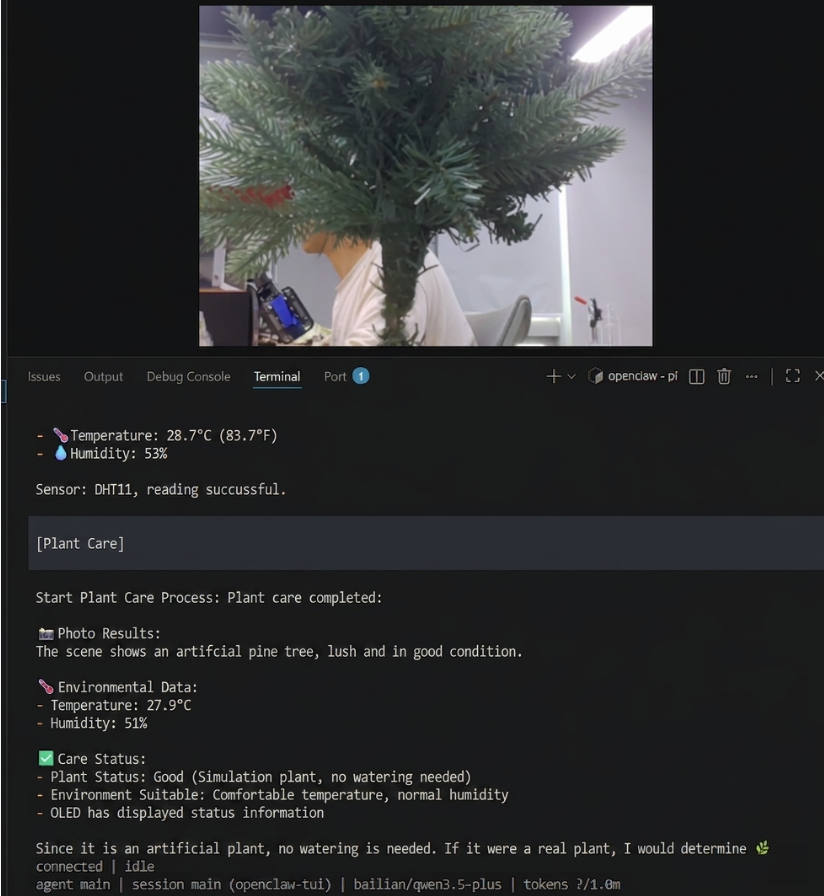
  • Plant care

image-20260601101236693

5.3 Voice Code Solution

xxxxxxxxxx
Requires optional AI voice interaction module + speaker

For voice module installation, environment configuration, and basic wake-up process, please directly refer to [04-AI Voice Interaction Configuration]. After waking up, you can directly say control content, for example:

  • Help me check the plant status and whether it‘s suitable for watering now
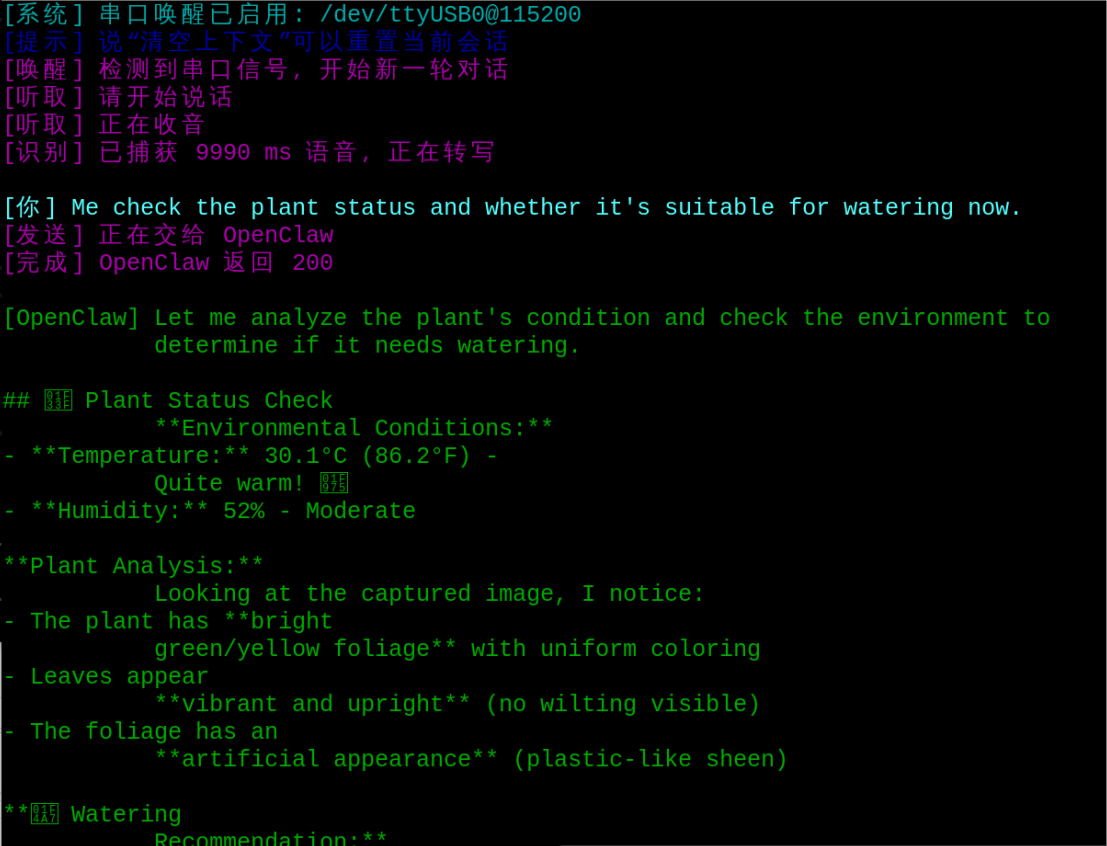
image-20260601101314913

6. Project Implementation

Note: The following are all dialogue demonstrations using openclaw tui method. You can also choose whatsapp or voice method to complete.

6.1 Scenario One: Environment Reading

Experimental Objective

Read the current temperature and humidity around the plant, completing the most basic environmental perception.

Effect Description

OpenClaw will call DHT to read current environmental data, and use natural language to feedback temperature and humidity.

Example Instructions

  • Read temperature and humidity near the current plant

  • What is the current environmental temperature and humidity

  • Help me check if the potted plant area is too dry

6.2 Scenario Two: Status Judgment

Experimental Objective

Let OpenClaw provide a brief plant care suggestion after obtaining environmental data.

Effect Description

Besides directly reporting values, OpenClaw can also summarize conclusions like "too dry", "too hot", "status normal" in more natural everyday language.

Example Instructions

  • Judge plant status based on current temperature and humidity

  • Is it suitable for watering now

6.3 Scenario Three: Audio-Visual Alert

Experimental Objective

When environmental status is not ideal, use OLED and RGB to give more intuitive alerts.

Effect Description

For example, when environment is normal, light green; when too hot, light yellow; when abnormal, light red. At the same time, display simple prompt information on OLED, so it's not just "able to speak", but has clear peripheral feedback.

Example Instructions

  • If environment is normal, light green

  • If too hot, light yellow and prompt me

  • Display "Plant Needs Care" on OLED

Extensible Gameplay

  • Link with buzzer for stronger alerts

  • Make into desktop care status light

  • Add scheduled polling and auto-refresh

6.4 Scenario Four: Photo Observation

Experimental Objective

Use camera to photograph current plant image, and let OpenClaw make a simple description.

Effect Description

This step is suitable for observing leaves, pot surface, or overall growth. The current tutorial focuses on "taking a look and making a description", not automatic disease judgment, so it is more suitable for teaching demonstrations and lightweight auxiliary observation.

Example Instructions

  • Take a photo of the plant

  • Check how the leaves are doing

  • After taking a photo, describe the current plant image

AI Script Peripheral Control
AI Calorie Estimation

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文