yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
RDK S100(P) Board📖
0. RDK S100(P) Developer Kit
  • 1. RDK S100(P) Official Tutorial
1. Introduction to RDK S100(P) Development Board
  • 1.1 Introduction to the RDK S100(P) Development Board
  • 1.2 Install Operating System
  • 1.3 Interface Descriptions
  • 1.4 Accessory installation
  • 1.5 Camera Expansion Board
  • 1.6 MCU Port Expansion Board
  • 1.7 Precautions for using 15.6-inch screens
2. Basic Settings Course
  • 2.1 Network Configuration
  • 2.2 Remote Login
  • 2.3 System Update
  • 2.4 Boot Auto-Start Configuration
  • 2.5 RDK Exclusive Command Usage
  • 2.6 Linux Command Usage
  • 2.7 Example of GPIO read and write operations
  • 2.8 Using USB Camera
  • 2.9 Using MIPI Camera
  • 2.10 SSD mounting
  • 2.11 Binocular camera depth algorithm
3. TogetheROS.Bot Vision Applications
  • 1. About TogetheROS. Bot
  • 2. System Installation
  • 3. Object Detection(YOLO)
  • 4. Image Classification(mobilenetv2)
  • 5. Image Segmentation(mobilenet_unet)
  • 6. Perception Algorithm(BEV)
  • 7. Human Detection and Tracking (Ultralytics YOLO Pose)
4.Offline AI model course
Offline large model (Text Interaction)
  • 1. AI large model environment deployment
  • 2. Install large model dialogue platform
  • 3. Meta AI Llama 3.2 model
  • 4. Alibaba Cloud Qwen3 model
  • 5. Microsoft Phi-4 mini model
  • 6. DeepSeek - DeepSeek-R1 model
  • 7. Alibaba Cloud Qwen2.5vl Visual Multimodal Large Model
  • 8. Google Gemma3 Visual Multimodal Large Model
  • 9. Lava Visual Multimodal Large Model
  • 10. MiniCPM-V Visual Multimodal Large Model
  • 11. Multimodal visual understand application
  • 12. Multimodal text to image application
  • 13. Multimodal visual localization application
  • 14. Multimodal table scanning application
  • 15. Multimodal Autonomous Agent Applications
Offline large model (Voice Interaction)
  • 0. Voice Interaction Hardware Connection (Must Read)
  • 1. Offline speech-to-text (ASR)
  • 2. Offline Text-to-Speech (TTS)
  • 3.AI large model voice interaction
  • 4. Multimodal visual understanding voice interaction
  • 5. Multimodal Text-to-Image application
  • 6. Multimodal video analytics application
  • 7. Multimodal visual localization application
  • 8. Multimodal table scanning application
  • 9. Multimodal autonomous agent application
  • 10. AI Large Model Offline Voice Assistant
5.Online AI model course
Online large model (Text Interaction)
  • 1.OpenRouter large model API aggregation platform
  • 2.Multimodal visual understand application
  • 3.Multimodal visual localization application
  • 4.Multimodal table scanning application
  • 5.Multimodal autonomous agent application
Online large model (Voice Interaction)
  • 0.Voice interaction hardware connection (ReadMe)
  • 1.Online speech to text (ASR)
  • 2.Online text to speech (TTS)
  • 3.AI large model voice interaction
  • 4.Multimodal visual understand speech interaction
  • 5.Multimodal visual localization application
  • 6.Multimodal table scanning application
  • 7.Multimodal autonomous proxy application
  • 8.AI large model online voice assistant
6.YOLO26 tutorials
  • 01.YOLO26 environment
  • 02.CLI use
  • 03.Object detection
  • 04.Instance segmentation
  • 05.Pose estimation
  • 06.Image classification
  • 07.Oriented object detection
  • 08.Model conversion
  • 09.Dataset annotation
  • 10.Model training - conversion
  • 11.Model prediction
7.OpenClaw Advanced Development
  • 1.OpenClaw Deployment
  • 2.OpenClaw WhatsApp Plugin Application
  • 3.OpenClaw WebChat Interaction
  • 4.OpenClaw TUI Interaction
  • 5.OpenClaw Tools Introduction
  • 6.OpenClawGate Gateway User Manual
  • 7.OpenClaw Features Overview
  • 8.OpenClawClawHub Introduction (Skill Installation)
  • 9.OpenClaw Application - File Management
  • 10.OpenClaw Application - Camera
  • 11.OpenClaw Application - Browser Control
  • 12.OpenClaw Application - Script Execution
  • 13.OpenClaw Application - AI Programming (Peripheral & GPIO Control)
  • 14.OpenClaw Application - Dedicated AI Assistant
  • 15.OpenClaw Web Search Capability Configuration
8.ROS2 basic course
  • 1.Introduction to ROS2
  • 2.ROS2 install Humble
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
Download
  • Annex_File
  • Code
Download ZIP

Welcome to RDK S100(P) Board repository

4.OpenClaw TUI Interaction

4. OpenClaw TUI Interaction

TUI (Text User Interface) is OpenClaw's "command line chat window". When you can't easily open the web console on Jetson, or you're connected via SSH remotely, you can use TUI to complete most daily interactions in the terminal: conversations, model switching, status checking, session management, skill invocation, etc.
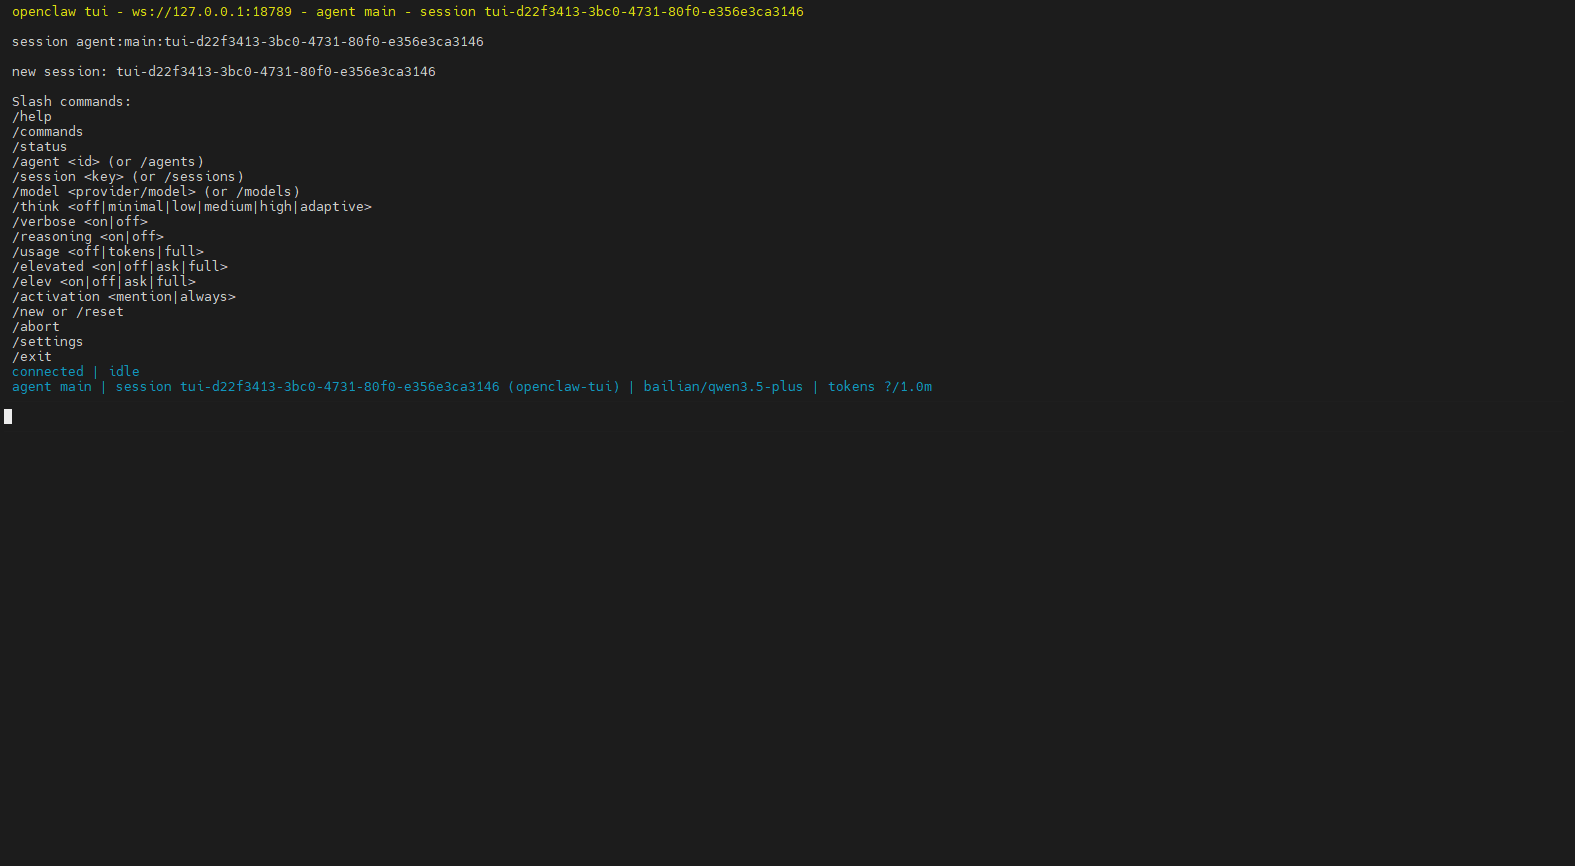
OpenClaw TUI 界面(可替换为你的截图)

1. How to Enter TUI

Execute in terminal:

openclaw tui

If you have already started openclaw gateway (e.g., gateway/server) in another terminal, you can directly execute openclaw tui to enter the interactive interface

2. What is the TUI Interface

You can understand TUI as a "chat box with commands":

  • Top: Conversation history (your messages, model replies, tool/skill outputs)
  • Bottom: Input box (enter questions or send slash commands)
  • Send method: Press Enter after typing

Recommended first-time actions:

xxxxxxxxxx
/status

3. Slash Commands

Slash commands generally need to be sent as standalone messages starting with /, used to control sessions and run operations.

CommandFunctionWhen to UseExample
/helpView help and command listWhen you don't know available commands/help
/statusCheck current statusWhen suspecting disconnection, want to see context usage/status
/newStart new conversation line (new session)Topic switching, avoid context interference/new
/resetReset session (equivalent to restarting, same effect as new)Conversation goes off track, want to clear context/reset
/model / /models listView/switch modelsWhen wanting faster or stronger models/models list
/think mediumSet thinking depthDaily recommendation: use low or disable/think medium
/stopStop current taskWhen stuck, want to stop immediately/stop
/context detailView currently injected contextTroubleshoot "why it remembers/forgets certain content"/context detail
/compactCompress earlier history into summaryConversation too long, context nearly full/compact
/skill <name>Run a specific skillWhen you know skill name and want to run directly/skill web_search

Two additional "daily usage" recommendations:

  • Write only one slash command per message for best reliability
  • To quickly browse all commands, use /help or /commands

4. Sessions and Memory

In OpenClaw, these two concepts have clear divisions:

  • Session: Manages "where this conversation has progressed". When you use /new, /reset in TUI, you're essentially switching/reopening sessions.
  • Memory: Manages "content that should be retained long-term across sessions". It writes to disk (Markdown) and retrieves back to current session when needed.

4.1 Where are Session Files

Sessions are saved to disk in JSONL format, common locations (actual installation path may vary):

  • Index: ~/.openclaw/agents/<agentId>/sessions/sessions.json
  • Transcripts: ~/.openclaw/agents/<agentId>/sessions/<SessionId>.jsonl

A more convenient way for actual troubleshooting is to first execute:

xxxxxxxxxx
openclaw status

It usually provides the store path and recent session information.

4.2 How to "Use" Memory

You can understand Memory as "letting the robot take notes":

  • memory/YYYY-MM-DD.md: Daily process records, suitable for recording progress, temporary decisions
  • MEMORY.md: Long-term stable information (preferences, fixed rules, project constraints, etc.)

Practical recommendations:

  • To make a conclusion available across sessions: directly tell the robot "write this to MEMORY.md"
  • Before /new to switch to new topic: first use /compact or write key decisions to Memory, then switch sessions

5. Quick Start Workflow

  1. Enter TUI: openclaw tui
  2. Confirm status: /status
  3. Select model: /models list → /model <number or name>
  4. Daily conversation: directly enter questions and press Enter
  5. Topic switching: /new
  6. Context too long: /compact
  7. Key conclusions need long-term retention: have robot write to Memory

6. Common Troubleshooting

6.1 No Response After Entering Commands

  • Confirm commands are sent as standalone lines (don't mix with regular text)
  • First use /help to see which commands are supported in current version

6.2 Feeling "It's Starting to Talk Nonsense or Can't Understand" or Being Interfered by History

  • Start new session: /new or /reset
  • Check what context was injected: /context detail

6.3 Responses Getting Slower

  • Reduce thinking depth: /think low or /think minimal
  • Compress history: /compact
OpenClaw WebChat Interaction
OpenClaw Tools Introduction

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文