Welcome to RDK X5 MagicBox repository
Quick Start
Quick Start
Precautions
To avoid malfunction or damage to this product, please observe the following:
- When in use, place the product on a stable, flat, non-conductive surface.
- Do not arbitrarily flip the arm. When in use, return it to the initial position parallel to the housing.
- Avoid keeping the servo in a stalled state for a long time to prevent overcurrent heating and extend its service life.
- Do not squeeze or twist the camera folding mechanism. Do not exceed the maximum folding angle to avoid irreversible damage.
- When installing the SD card, remove the baffle first. Be careful not to insert the SD card into the gap between the housing and the RDK X5.
- Connecting incompatible devices to this product causing device damage will not be supported for repair.
- All peripheral devices used with this product should comply with relevant national standards and bear corresponding marks to ensure safety and performance requirements are met.
Unboxing List
- RDK X5 Magicbox, with built-in 32GB TF card
- Data cables: A-to-C x1, C-to-C x1
Power Supply
- Type-C interface, 5V/5A DC input
- Use a power adapter supporting PD 3.0 protocol to power the Magicbox through the power port
Network Configuration
Method 1: Flash Connect Configuration
Go to PC "Control Panel -> Network and Internet -> Network and Sharing Center -> Change Adapter Settings".
Connect the PC to the Flash Connect port on the left side of Magicbox.
Find the corresponding Ethernet device, right-click and select "Properties".
Note
Please select the correct Ethernet device.
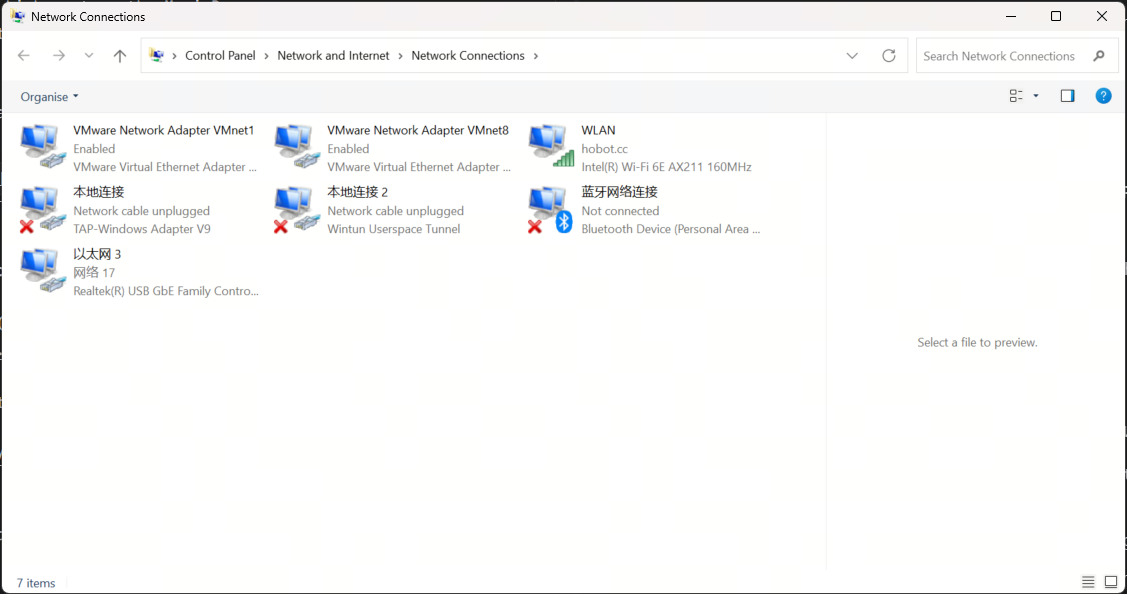
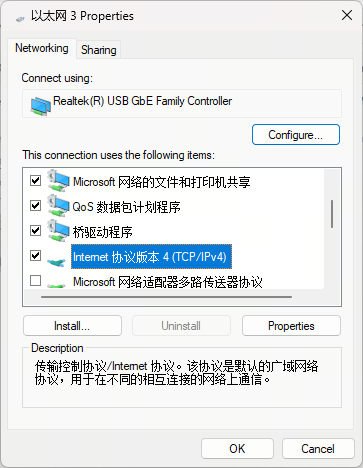
Find the "Network -> Internet Protocol Version 4" option and double-click to open.
Fill in the corresponding network parameters at the position shown below and click OK.
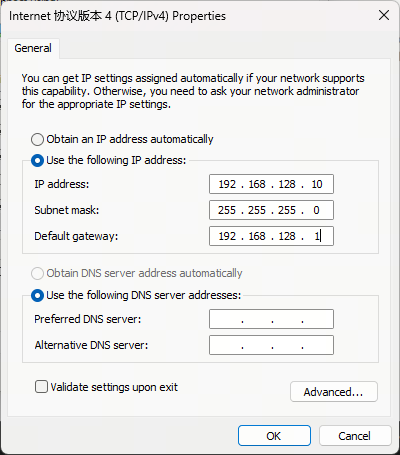
Open PowerShell and use the following command to verify if the development board is accessible:
ping 192.168.128.10.
Method 2: Wired Ethernet Port Configuration
Go to PC "Control Panel -> Network and Internet -> Network and Sharing Center -> Change Adapter Settings".
Connect the PC to the Ethernet port on the right side of Magicbox.
Find the corresponding Ethernet device, right-click and select "Properties".
Note
Please select the correct Ethernet device.
Find the "Network -> Internet Protocol Version 4" option and double-click to open.
Fill in the corresponding network parameters at the position shown below and click OK.
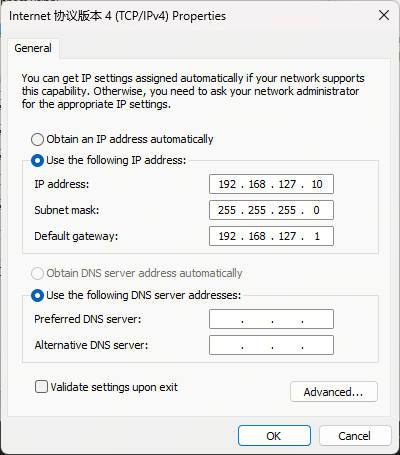
Open PowerShell and use the following command to verify if the development board is accessible:
ping 192.168.127.10.
Starting Magicbox
After powering on, wait approximately 50 seconds. The white lights will light up in sequence, and finally the white light will blink. Hearing the startup sound effect indicates successful startup.
Example Experience
Use the following commands to set the application auto-start switch. When set to enabled, the application will start automatically on boot. It is enabled by default.
xxxxxxxxxx# Enable auto-startsystemctl enable magicbox-start# Disable auto-startsystemctl disable magicbox-startNote
The left-to-right direction of the buttons mentioned in this article refers to the direction when the Magicbox light strip is facing the user.
Stereo Depth Estimation
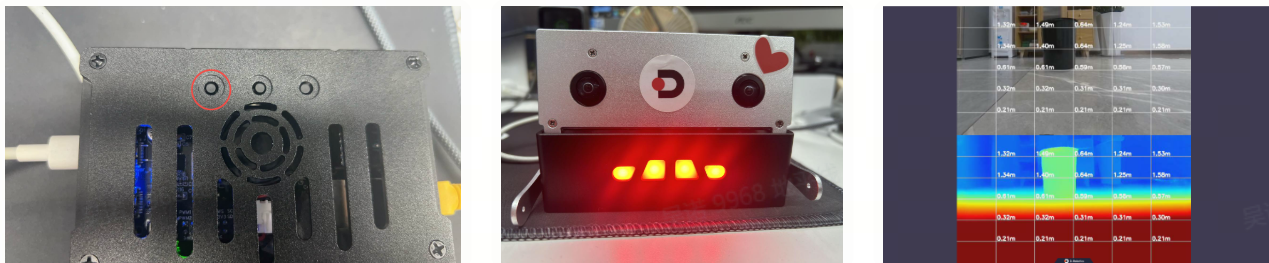
Press the leftmost button, the light changes to red. When using Flash Connect to configure the network, access http://192.168.128.10:8000 in the browser. When using wired Ethernet to configure the network, access http://192.168.127.10:8000 in the browser to view the effect.
Gesture Interaction
Press the middle button, the light changes to green. When using Flash Connect to configure the network, access http://192.168.128.10:8000 in the browser. When using wired Ethernet to configure the network, access http://192.168.127.10:8000 in the browser to view the effect and interact.
| Gesture | Hand Action | Triggered Action |
|---|---|---|
| ThumbUp | Thumbs up | Ear shaking |
| Victory | "V" gesture | Both feet extend |
| ThumbLeft | Thumb pointing left | Raise left hand |
| ThumbRight | Thumb pointing right | Raise right hand |
| Okay | OK gesture | Light blinking |

Voice Interaction
Note
It is recommended to use this in a relatively quiet environment, otherwise it may easily pick up surrounding sounds.
Press the rightmost button, the light changes to blue. After hearing the voice prompt "Hello, how can I assist you?", you can start the conversation.
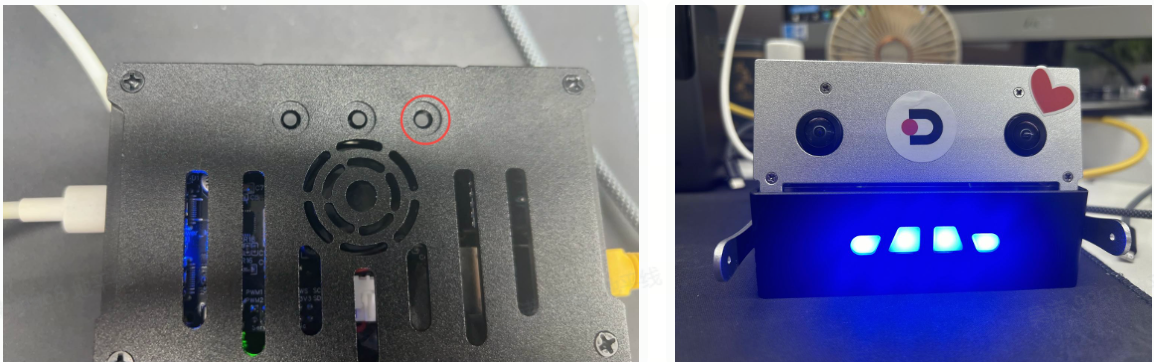
Voice commands:
- Use the voice command "End the conversation" to put the RDK X5Magicbox into sleep mode, and the light will switch to a breathing light pattern.
- Use the voice command "Hello, Digua" to wake it up, the light will remain steady, and you can start a conversation after waking up.
Voice interaction process:
- After receiving voice input, the microphone turns off, the blue lights gradually brighten one by one, and the speaker waits to broadcast the output from the large model.
- Once the voice broadcast is complete, the microphone turns on, and the blue light remains steady without changes, ready for the next round of conversation.
Use RDK Studio to Experience More Examples
Connect Magicbox using the RDK Studio tool to experience more examples in the Example Applications module. For download, installation and usage steps, refer to 1.9 RDK Studio User Guide | RDK DOC.
Resource Monitoring
After powering on, the resource monitoring function starts automatically. When using Flash Connect to configure the network, access http://192.168.128.10:7999 in the browser. When using wired Ethernet to configure the network, access http://192.168.127.10:7999 in the browser to view CPU, BPU and other resource consumption.