Welcome to RDK X5 MagicBox repository
1. Stereo Depth Estimation
Stereo Depth Estimation
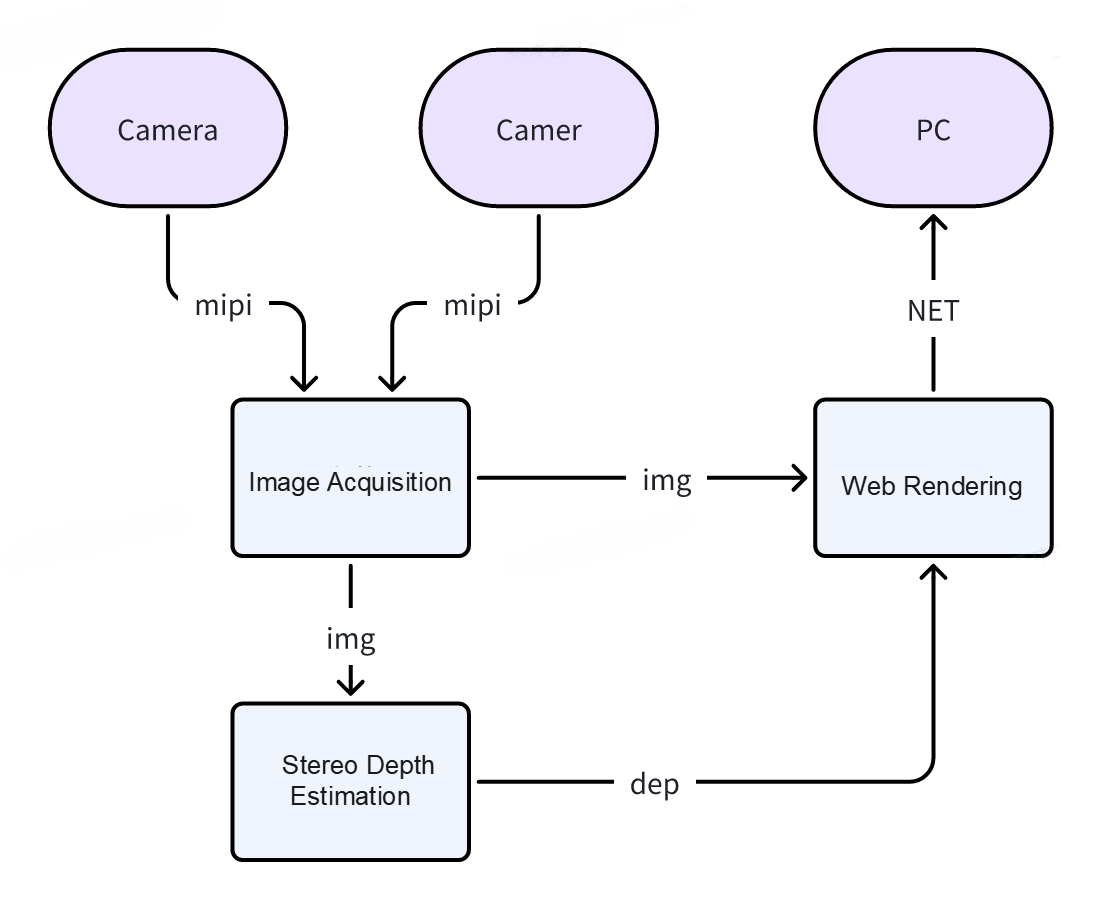
The D-Robotics stereo depth estimation algorithm takes binocular image data as input and outputs the disparity map and depth map corresponding to the left view. The algorithm borrows from the IGEV network and uses a GRU architecture, featuring good data generalization and high inference efficiency.
- For more details, refer to: Stereo Depth Estimation | RDK X5 Magicbox
- Code repository: https://github.com/D-Robotics/hobot_stereonet
- Functional architecture diagram: