yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
RDK X5 MagicBox📖
1.RDK MagicBox
  • 1. RDK MagicBox Official Materials
  • 2. Troubleshooting boot failure
  • 3. Linux memory query
2.RDK MagicBox Introduction
  • 1. Introduction to RDK MagicBox
  • 2. Write System File
  • 3. Hardware Interface Description
3.RDK MagicBox User Guide
1. Quick Start
  • Quick Start
2. Basic Peripheral Usage
  • Basic Peripheral Usage
3. Algorithm Development
  • 1. Stereo Depth Estimation
  • 2. Gesture Interaction
  • 3. Voice Interaction
4.RDK MagicBox Basic Settings
  • 1.Network configuration
  • 2.Remote login
  • 3.Update system
  • 4.srpi-config user guide
  • 5.config. txt configuration file
  • 6.Self-startup setting
  • 7.RDK exclusive command usage
  • 8.Linux command usage
  • 9.GPIO readwrite operation
  • 10.Image classification algorithm
  • 11.Use USB camera
  • 12.MIPI Camera Usage
5.RDKX5 Magicbox Basic Development Course
For C language
  • 1. Camera Image Acquisition and Display
  • 2. Camera Image Local Saving
  • 3. Camera Image Acquisition and Encoding
  • 4. Video File Decoding and Display
  • 5. RTSP Stream Decoding
  • 6. VPS Scaling Example
  • 7. Target Detection Algorithm — focs
  • 8. Target Detection Algorithm — YOLOv5s
  • 9. Using CAN
For Python language
  • 1. Prerequisites Before Using Pin Functions
  • 2. Using GPIO
  • 3. Using PWM
  • 4. Use serial port
  • 5. Using I2C
  • 6. Using SPI
For Linux Development
  • Linux Development Guide
6.Online AI Model Course
Online AI Model Course(Text Interaction)
  • 0. Preparation before use
  • 1. OpenRouter Large Model API Aggregation Platform
  • 2. Multimodal Visual Understanding Application
  • 3. Multimodal Visual Positioning Application
  • 4. Multimodal Table Scanning Application
  • 5. Multimodal Autonomous Agent Application
Online AI Model Course(Voice Interaction)
  • 1. Online Speech‑to‑Text (ASR)
  • 2. Online Text‑to‑Speech (TTS)
  • 3. AI Large Model Voice Interaction
  • 4. Multimodal Visual Voice Interaction
  • 5. Multimodal Visual Positioning Application
  • 6. Multimodal Table Scanning Application
  • 7. Multimodal Autonomous Agent Application
  • 8. AI Large Model Online Voice Assistant
7.OpenClaw Embodied AI Development
  • 1. Introduction to OpenClaw
  • 2. OpenClaw Deployment
  • 3. OpenClaw Whatsapp Plugin Application
  • 4. OpenClaw WebChat Interaction
  • 5. OpenClaw TUI Interaction
  • 6. OpenClaw Tool Introduction
  • 7. OpenClawGate Gateway User Manual
  • 8. OpenClaw Plugin Feature Introduction
  • 9. OpenClaw ClawHub Introduction (skill installation)
  • 10. OpenClaw Application - File Management
  • 11. OpenClaw Application - Camera
  • 12. OpenClaw Application - Browser Control
  • 13. OpenClaw Application - Script Execution
  • 14. OpenClaw Application - AI‑programmed Status Light Control
  • 15. OpenClaw Application - AI‑programmed Servo Control
  • 16. OpenClaw Application - Dedicated AI Assistant
8.ROS2 Basic Tutorial
  • 1.Introduction to ROS2
  • 2.ROS2 install Humble
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
Download
  • Code
  • Software_tools
  • SystemFile
Download ZIP

Welcome to RDK X5 MagicBox repository

2. OpenClaw Deployment

OpenClaw Deployment

Note: It is recommended to refer to the Feishu configuration for the installation method. Downloading openclaw from RDK Studio is relatively simple and easy to use.

1. OpenClaw Installation

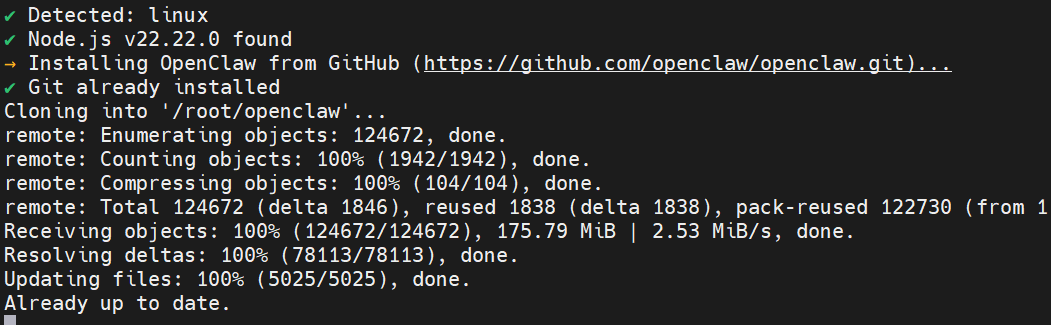
One-click installation:

curl -fsSL https://openclaw.ai/install.sh | bash -s -- --install-method git

To elaborate, this script performs the following operations:

Install corresponding dependencies:
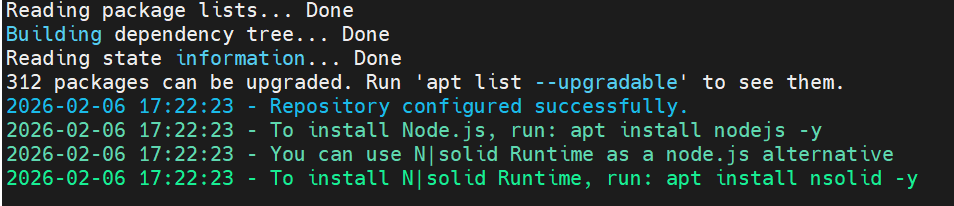
 

RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-image-14

Note that GitHub repository needs to be cloned at this step:

Prepare a scientific internet tool that can clone git repositories, otherwise this step may fail
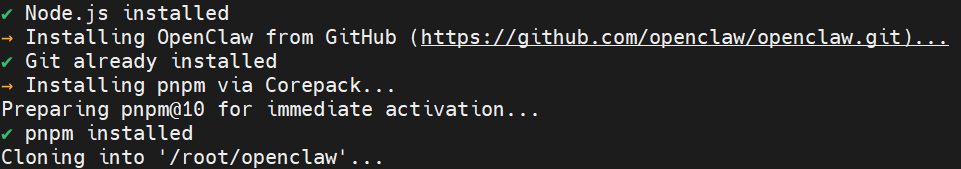
RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-image-13

RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-image-10

After installation is complete, you will see the following screenshot:
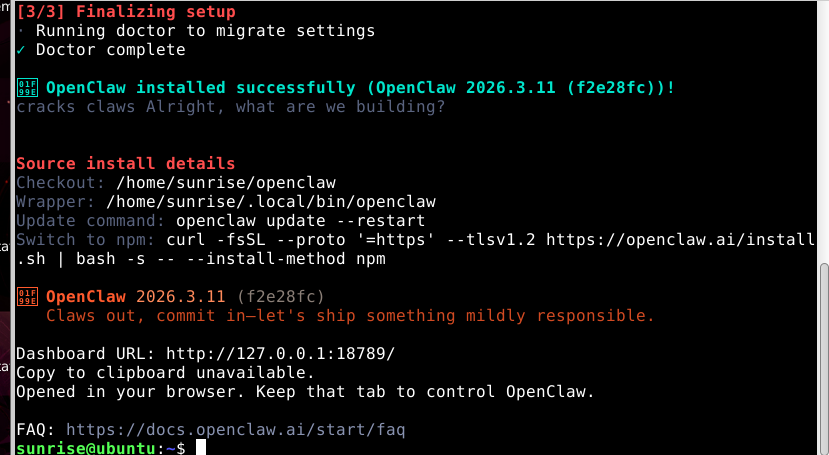
image-20260316202806464

After installation, add the environment variable to ~/.bashrc. The specific path depends on where you installed the files:

xxxxxxxxxx
echo 'export PATH="/root/.local/bin:\/root/.local/bin:/usr/hobot/bin/:/usr/local/sbin:/usr/local/bin:/usr/sbin:/usr/bin:/sbin:/bin:/usr/games:/usr/local/games:/snap/bin"' >> ~/.bashrc
or
echo'export PATH="$PATH:/home/sunrise/.npm-global/bin"'>> ~/.bashrc

Let's refresh and configure the environment variables:

xxxxxxxxxx
source ~/.bashrc

Now you can start using openclaw via command line.

2. OpenClaw Initial Configuration

Use the following command for initial configuration:

xxxxxxxxxx
openclaw onboard

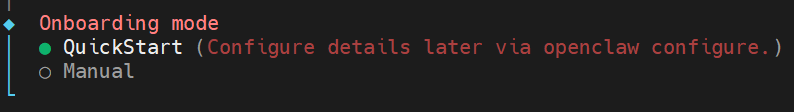
Let's configure the options. You can follow the green circles for corresponding configuration:
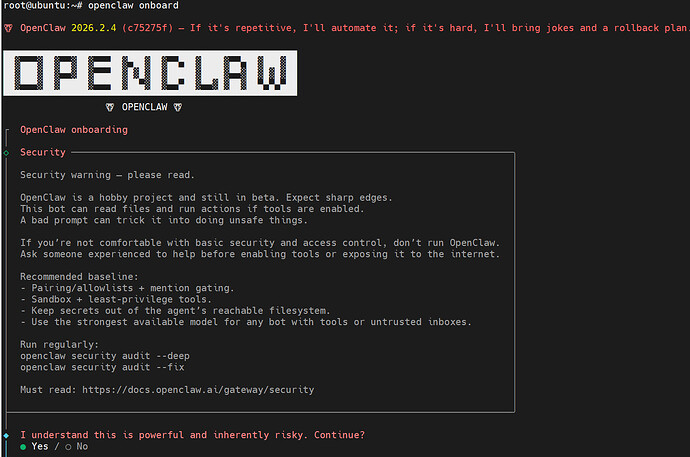
RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-image

RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-image-1

For this step, use your own API key for the relevant configuration:
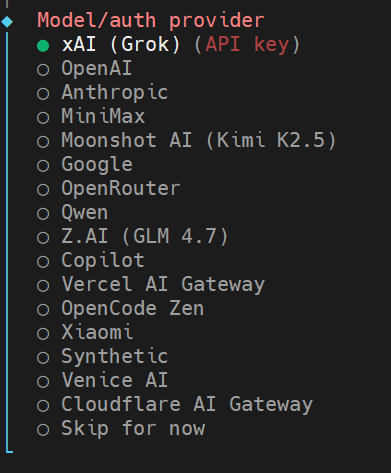
RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-image-2

Social software configuration can be skipped:
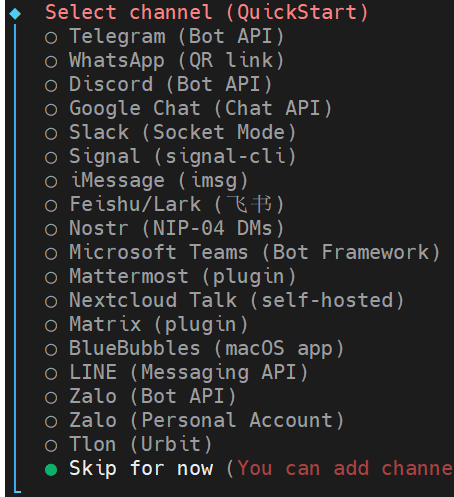
RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-image-3

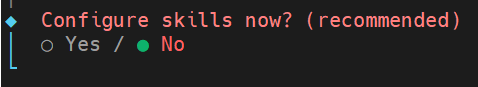
Skills can be skipped for now

RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-image-4

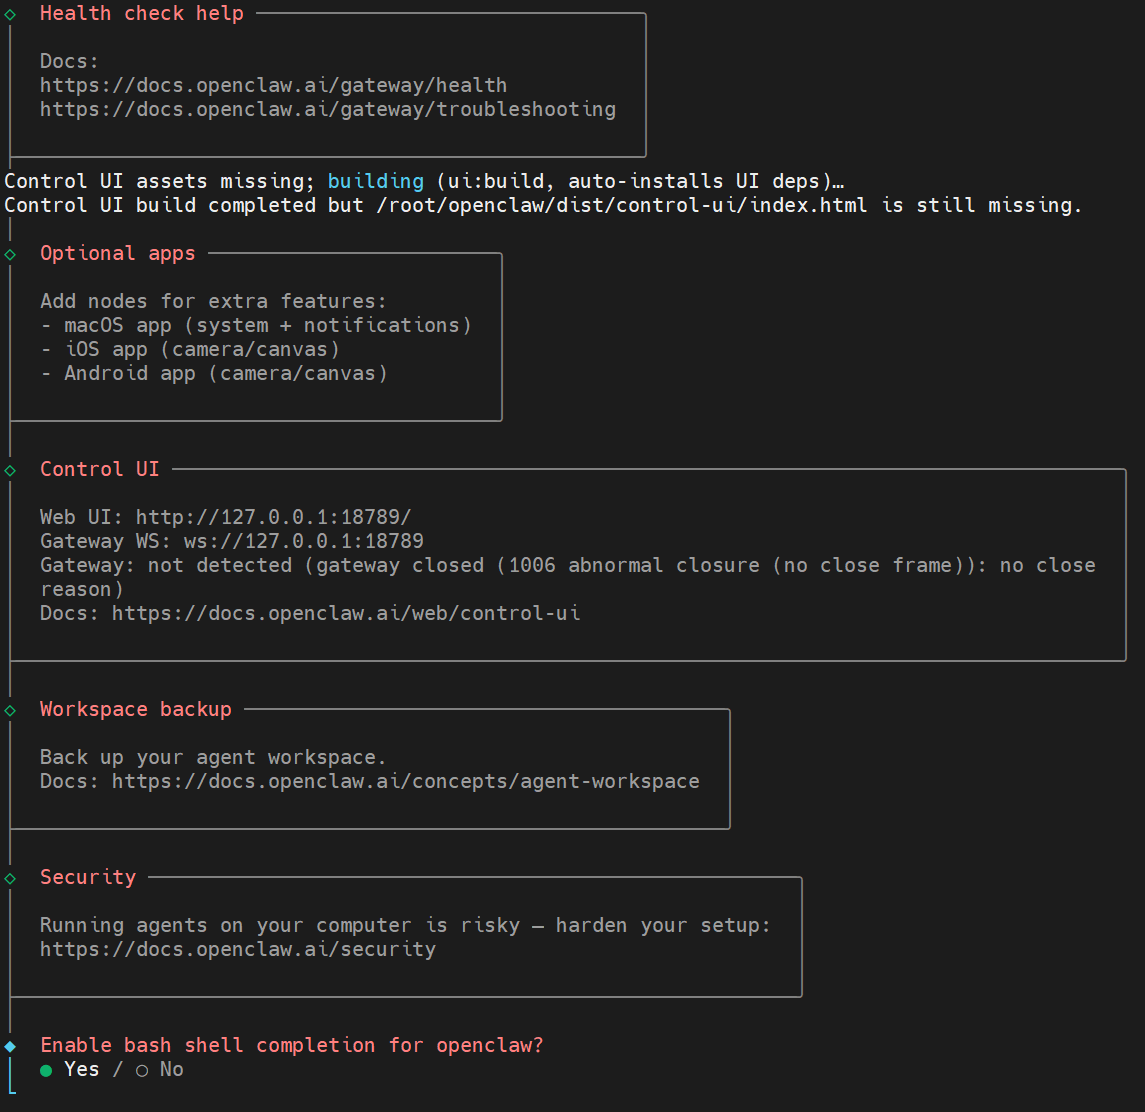
You will see that the gateway service has been installed:
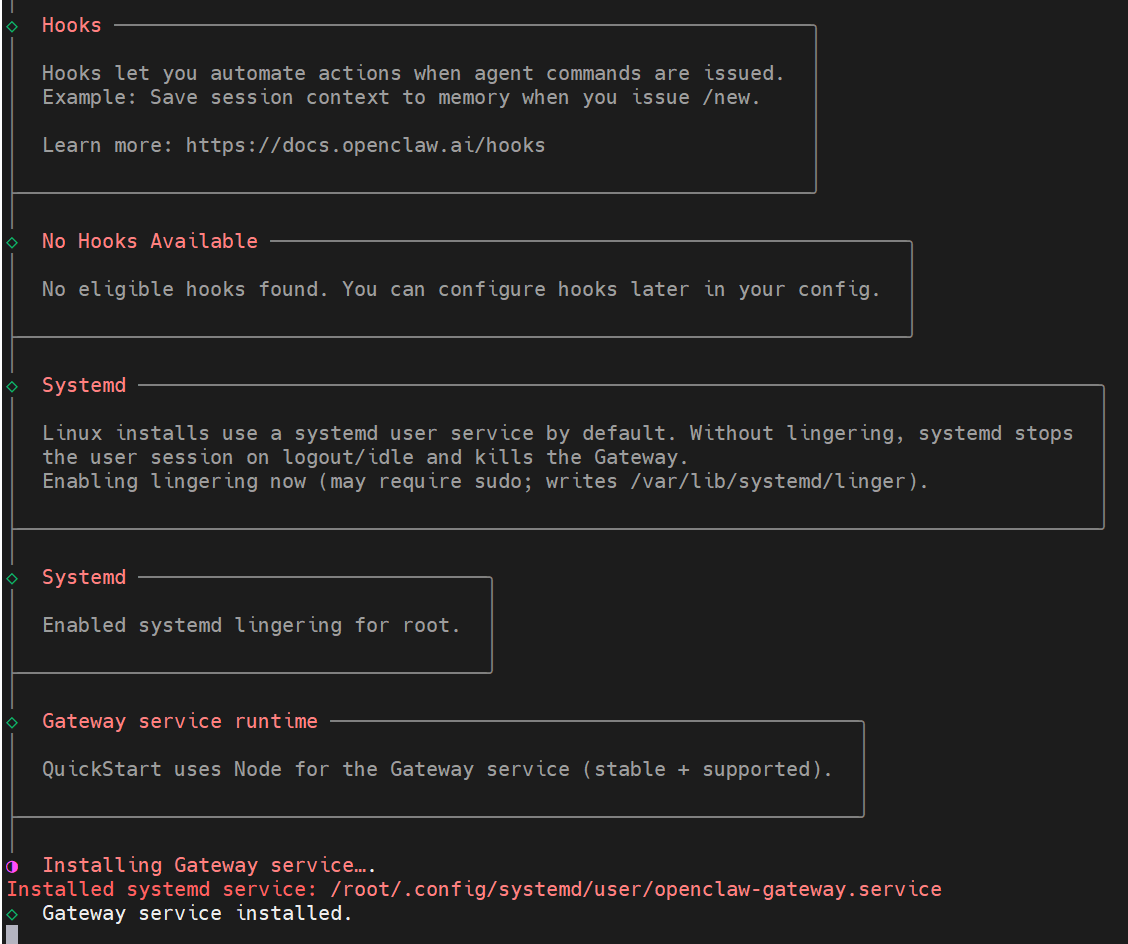
RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-image-5

RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-image-6

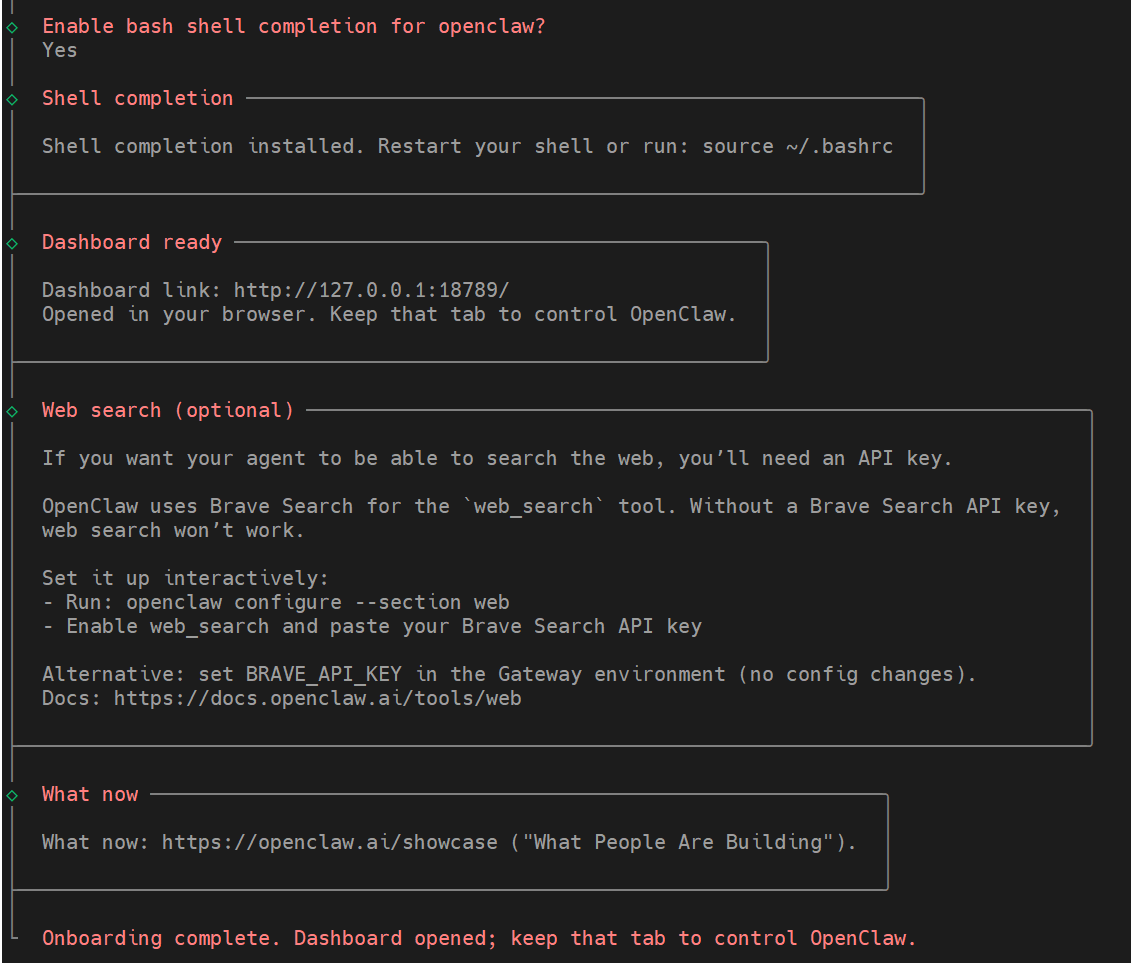
Enable bash completion

RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-image-7

3. Configuring Agent and Persona

In the latest OpenClaw version, users need the OpenClaw Gateway Token to activate the web interface, so that you can use the graphical UI.

In the ~/.openclaw/openclaw.json file, find the corresponding OpenClaw Gateway Token:
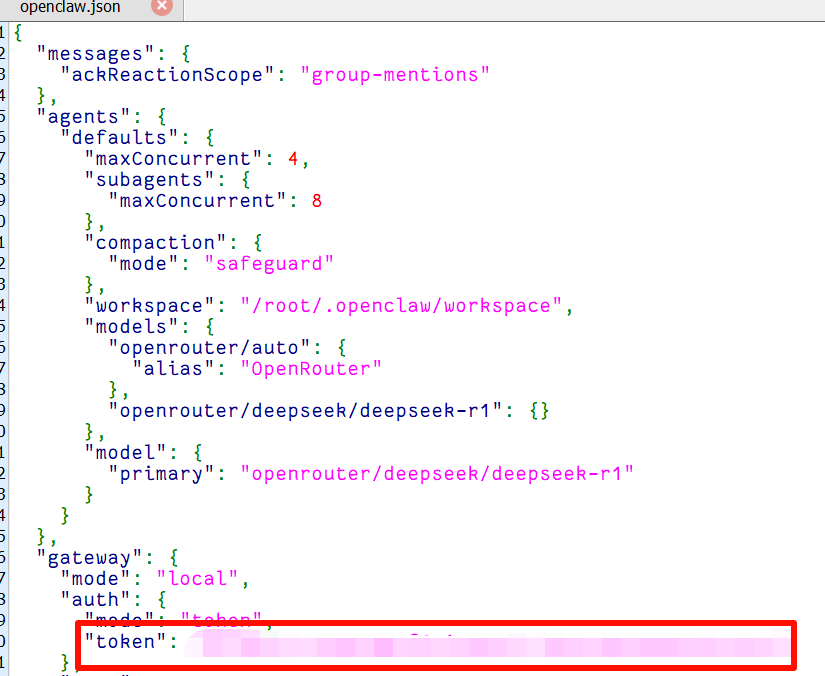
RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-image-8

Copy the token, then connect the RDK X5 to an HDMI display, open a browser, and open the UI interface. Enter:

xxxxxxxxxx
localhost:18789

In the top Overview section, enter the Gateway Token to activate the UI graphical interface. Copy it into the red box below:
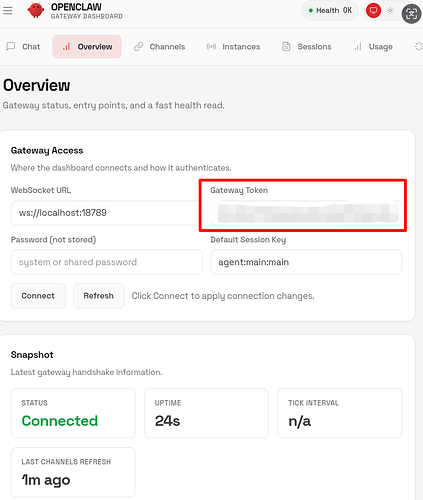
 

RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-image-9


Then select Chat in the top bar to start a conversation:
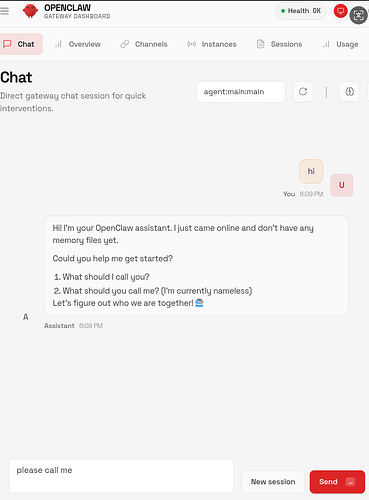
RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-image-11

You can see that for first-time use, you need to configure some information. You can refer to this写法:
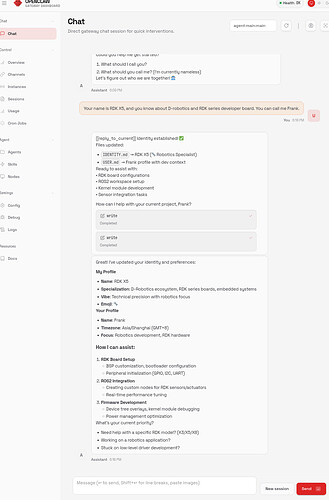
 

RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-2

At this point, we have completed the first call to the RDK Agent and given the RDK Agent its corresponding positioning.

From the response, we can see that the RDK Agent modified the IDENTITY.md and USER.md files. We can navigate to the corresponding files to check if they have been modified by OpenClaw. The default paths for the two files are:

xxxxxxxxxx
~/.openclaw/workspace/IDENTITY.md

and

xxxxxxxxxx
~/.openclaw/workspace/USER.md

The following shows the modifications to IDENTITY.md:
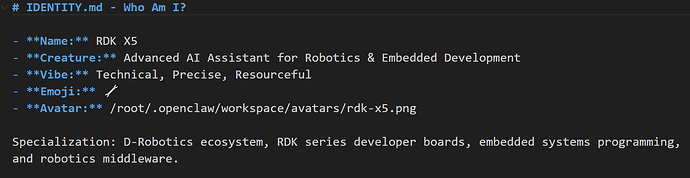
 

RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-image-19

The following shows the modifications to USER.md:
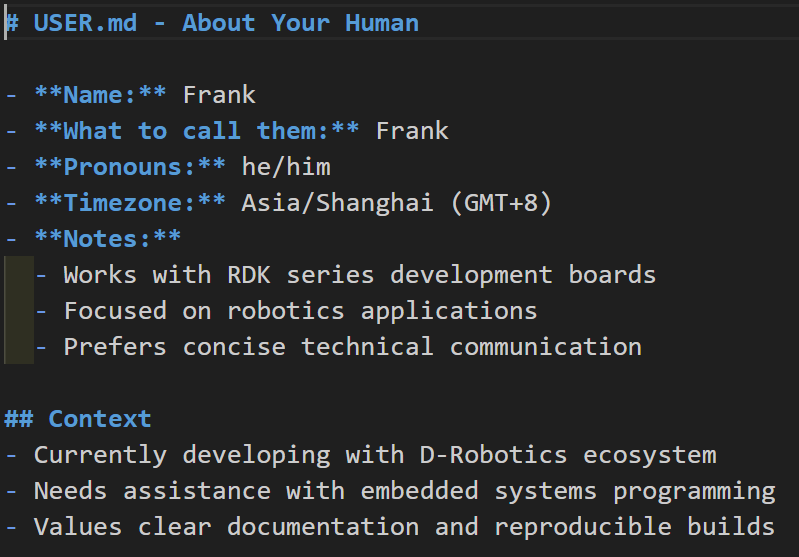
RDK MagicBox × OpenClaw: Embodied Intelligence Development New Paradigm-image-18

Here is a brief explanation of the persona files in OpenClaw:

  • IDENTITY.md (Identity Model, Role Setting)

    • Who is this Agent? What identity does it exist as?
    • Such as name, code name, role positioning, worldview settings, etc.
  • SOUL.md (Personality Model, Thinking Method)

    • How should the Agent think? How should it express itself?
    • Is the output personality style humorous or rational? Is the expression concise or verbose?
  • TOOLS.md (Capability Model, API Permission Table)

    • What tools can the Agent call?
    • Rules for tool calls, descriptions of tool purposes
  • AGENTS.md (Behavior Model, Decision System)

    • When to think? When to act? When to call tools?
    • Decision flow, execution strategy, task decomposition rules, etc.
  • USER.md (User Model, User Profile)

    • Who is this Agent's user? What are their preferences? What are their permissions?
    • What is the user's technical level? What style do they prefer, etc.
  • BOOTSTRAP (Birth Protocol)

    • How should the Agent awaken on first startup?
    • How to establish initial self-awareness and environmental perception
  • HEARTBEAT.md (Life Signal Protocol)

    • Is the Agent alive? Is it online?
    • Agent self-recovery mechanism, etc.
Introduction to OpenClaw
OpenClaw Whatsapp Plugin Application

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文