Welcome to Rider Pi Robot repository
2. Car rotation movement
Car rotation movement
1. Experimental purpose
Drive the car to move left and right
2. Experimental path source code
Enter the car system, end the car program, enter "ip (ip is the car's ip): 8888" in the browser, enter the password "yahboom"
 Then log in
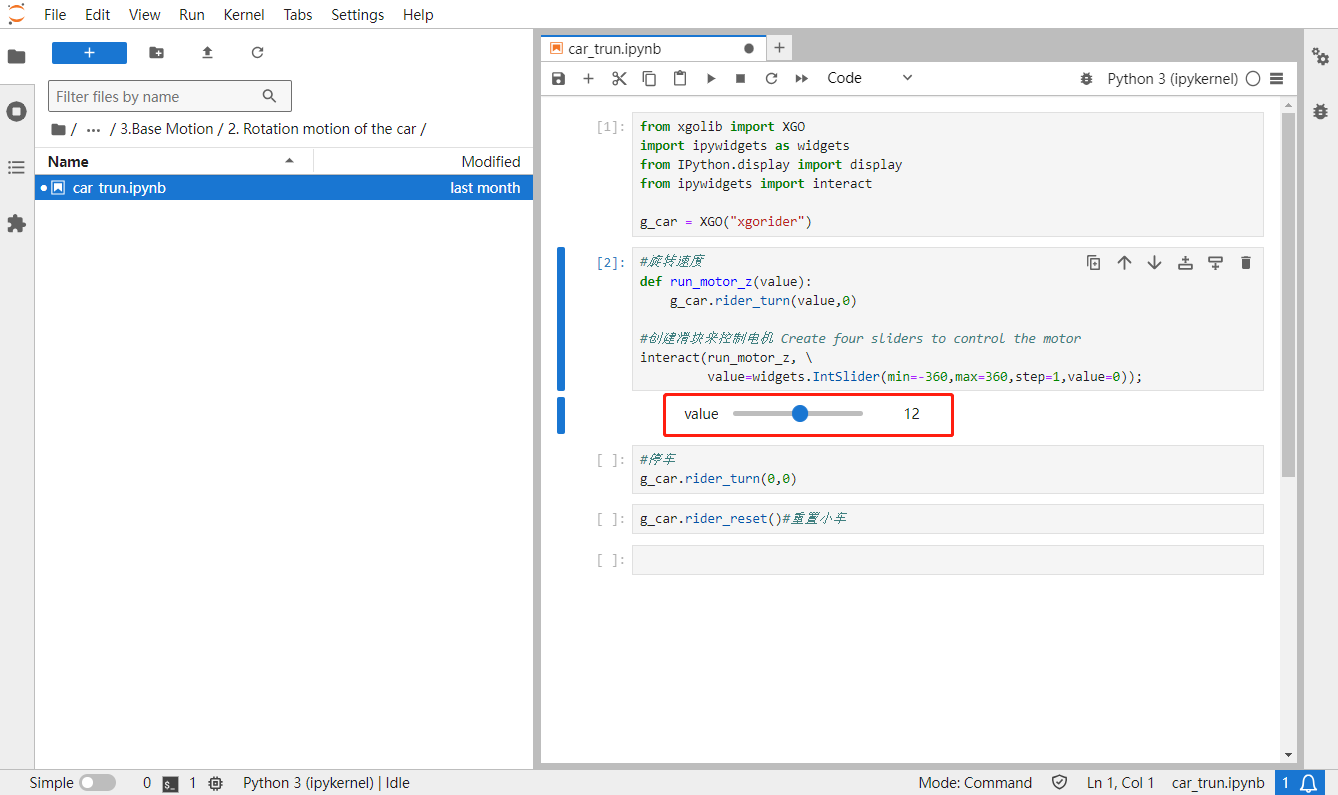
Enter the path of Rider-pi_class/3.Base Motion/2. Rotation motion of the car and run car_trun.ipynb.
3. Experimental phenomenon
After running the code, adjust the speed of the slider to make the car move left and right.
The car cannot be in a stopped state (that is, not in a standing balance state), otherwise it cannot move.
4. Analysis of main source code parameters
x#Rotation speeddef run_motor_z(value):g_car.rider_turn(value,0)#Create sliders to control the motor Create four sliders to control the motorinteract(run_motor_z, \value=widgets.IntSlider(min=-360,max=360,step=1,value=0));rider_turn: This function controls the left and right movement of the car, and the speed range is: -360 ~ 360.