yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
Self-balancing Robot Car📖
00.Get started quickly
  • 01.Balance car manual
  • 02.Balancing car assembly
  • 03.Get started quickly
  • 04.Balance car interface description
  • 05.Common Problem Analysis
  • 06.Balance Car V2 Library Function Development Manual
01.Environment development
  • 01.MDK-ARM installation
  • 02.STM32CubeIDE installation
  • 03.Common driver installation
  • 04.Download the program
  • 05.MDK-ARM project usage
  • 06.Program simulation
  • 07. VSCode Installation
02.STM32 getting started course
  • 01.Project creation
  • 02.LED Control(GPIO)
  • 03.Buzzer control(GPIO)
  • 04.Button control(EXTI)
  • 05.Serial communication(USART)
  • 06.Voltage detection(ADC)
  • 07.Basic timer(TIM)
  • 08.Universal timer(TIM)
  • 09.Advanced Timer(TIM)
  • 10.I2C Communication(I2C)-OLED
  • 11.SPI communication(SPI)-2.4G handle
  • 12.Independent Watchdog (IWDG)
  • 13.Window Watchdog (WWDG)
  • 14.DMA-USART
  • 15.DMA-I2C
03.STM32 expansion course
  • 01.Battery voltage detection (ADC)
  • 02.Ultrasonic module-measuring distance (TIM)
  • 03.Motor drive+encoder (TIM)
  • 04.OLED Data-Display(I2C)
  • 05.MPU6050-Data Read (I2C)
  • 06.Bluetooth module-Data reading (USART)
  • 07.2.4G handle-Data reading (SPI)
  • 08.Tracking module-Read status (GPIO)
  • 09.CCD module-Reading data (ADC)
  • 10.Electromagnetic module-Reading data (ADC)
  • 11.K210 module-Serial communication (USART)
  • 12.Tmini-Plus lidar-Reading data (USART)
04.Robot car PID control course
  • 01.PID basic concept
  • 02.PID example analysis
  • 03.P, PI, PD controller theory
  • 04.Position PID
  • 05.Incremental PID
  • 06.Cascade PID
  • 07.Balance principle of car
  • 08.Car upright control (PD)
  • 09.Car speed ​​control (PI)
  • 10.Car steering control (PD)
  • 11.Got angle and angular velocity (DMP algorithm)
  • 12.Got angle and angular velocity (Kalman filter algorithm)
  • 13.Got angle and angular velocity(Complementary filter algorithm)
05.Robot car basic course
  • 01.Car parameter adjustment
  • 02.Ultrasonic obstacle avoidance
  • 03.Ultrasonic follow
  • 04.Bluetooth remote control
  • 05.Load balance
06.Robot car advanced course
  • 01.4-channel tracking
  • 02.4-channel tracking avoid
  • 03.2.4G handle control
  • 04.CCD tracking
  • 05.CCD tracking avoid
  • 06.Electromagnetic tracking
  • 07.K210-QR code recognition
  • 08.K210-Color line tracking
  • 09.K210-Color follow
  • 10.K210-Self learning
  • 11.K210-Number recognition
  • 12.Lidar avoid
  • 13.Lidar guard
  • 14.Lidar follow
  • 15.Lidar patrol
  • 16.Lidar wall tracking-straight line
  • 17.Lidar wall tracking-multiple walls
  • 18. DIY Automatic driving car
07.Robot car LQR control
  • Robot car LQR control
08.Circuit design
  • 01.Overall circuit design
  • 02.STM32 minimum system
  • 03.Serial port circuit design
  • 04.Power circuit design
  • 05.MPU6050 Circuit Design
  • 06.Motor drive circuit design
09.Mathematical model
  • Mathematical model
10.Expand course
  • Autonomous Driving
Download
  • APP(Android)
  • Codes
  • Hardware-Info
  • SCH
  • Software Tools
  • STM32_Chip_DataSheet
  • 3D_Model_File
  • Video_PPT
Download ZIP

Welcome to Self-balancing Robot Car repository

15.DMA-I2C

DMA-I2C

DMA:I2C

DMA:I2CHardware connectionControl principleSoftware configurationPin definitionSoftware codeControl functionExperimental phenomenon

The tutorial demonstrates I2C communication through DMA to control OLED display.

The tutorial only introduces the standard library project code

Hardware connection
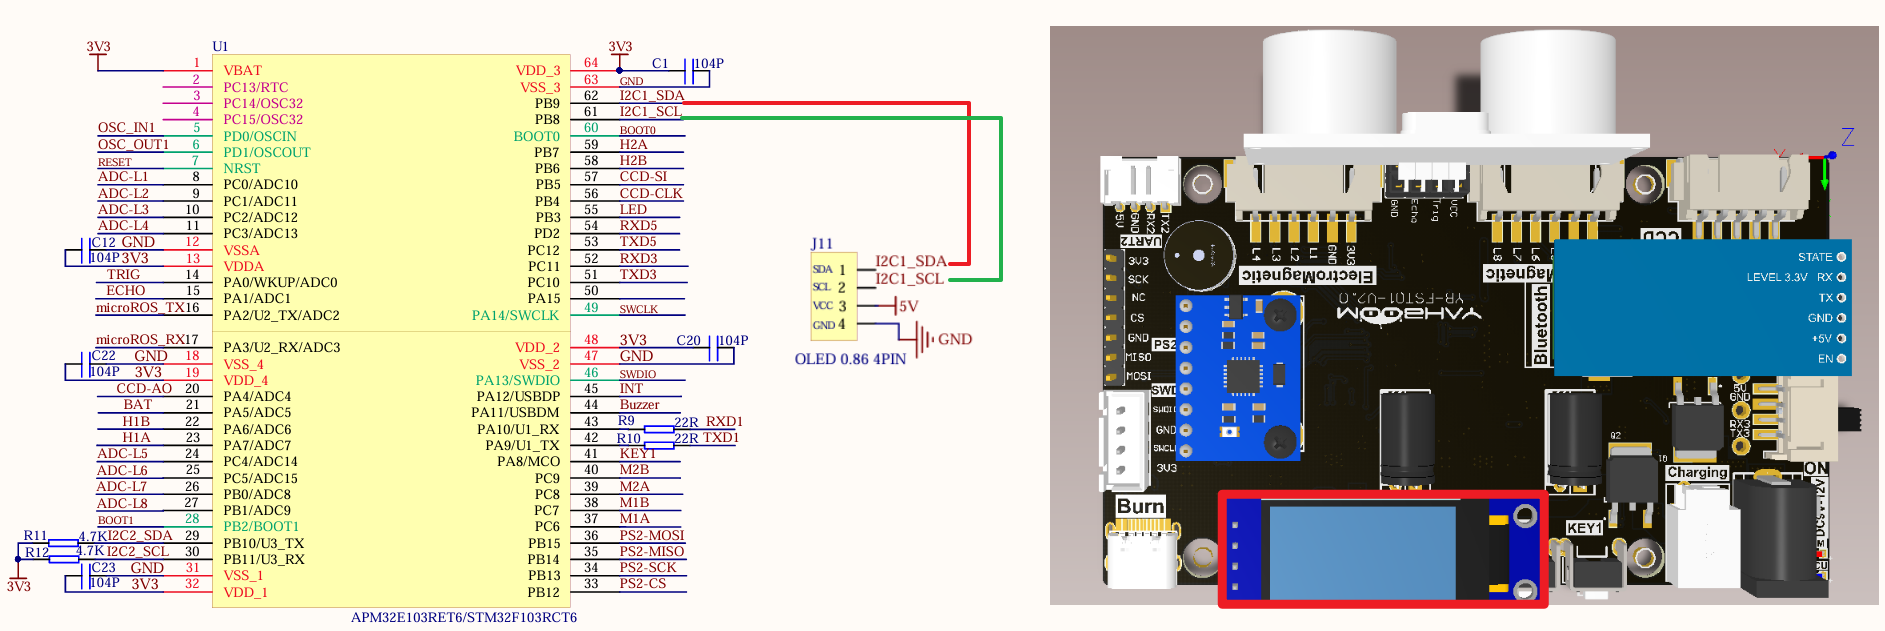
image-20240825210545798

PeripheralsDevelopment boardDescription
OLED: VCC5VOLED power supply
OLED: GNDGNDOLED common ground
OLED: SCLPB8Serial clock line (SCL)
OLED: SDAPB9Serial data line (SDA)

Control principle

xxxxxxxxxx
I2C related knowledge will not be introduced, mainly DMA knowledge.

STM32F103RCT6 has two DMA controllers, DMA1 has 7 channels and DMA2 has 5 channels;

It is used for high-speed data transmission between peripherals and memory and between memory and memory.

DMA characteristics

DMA initialization and startup are completed by the CPU, and the transmission process is performed by the DMA controller without CPU participation, thus saving CPU resources for other operations.

DMA1 request for each channel
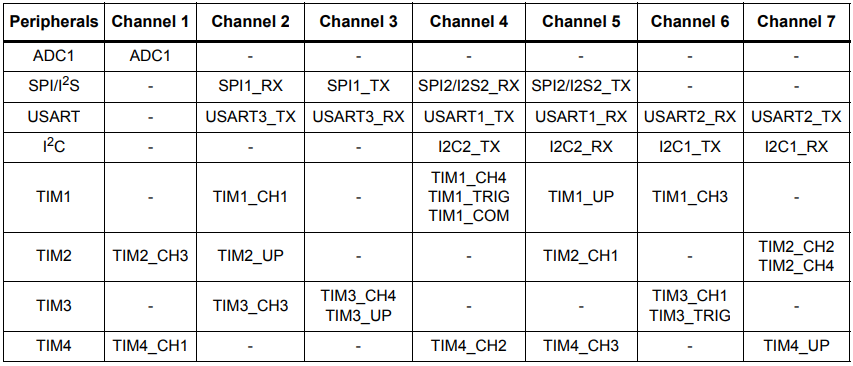
image-20240903165337168

DMA2 request for each channel

image-20240903165345514

This tutorial uses DMA1 channel 6.

Software configuration

Pin definition

Main control chipPinMain function (after reset)Default multiplexing functionRedefine function
STM32F103RCT6PB8PB8TIM4_CH3I2C1_SCL/CAN_RX
STM32F103RCT6PB9PB9TIM4_CH4I2C1_SDA/CAN_TX

Software code

Since the default function of the pin is the ordinary IO pin function, we need to use the redefine function.

xxxxxxxxxx
Product supporting data source code path: Attachment → Source code summary → 1.Base_Course → 15.I2C+DMA

Control function

The tutorial only briefly introduces the code, and you can open the project source code to read it in detail.

OLED_I2C_Init

​x
void OLED_I2C_Init(void)
{   
    GPIO_InitTypeDef GPIO_InitStructure;
    I2C_InitTypeDef I2C_InitStructure;

    RCC_APB1PeriphClockCmd(OLEDI2C_RCC, ENABLE);
    RCC_APB2PeriphClockCmd(OLED_RCC, ENABLE);

    //开启复用功能
    RCC_APB2PeriphClockCmd(RCC_APB2Periph_AFIO, ENABLE);
    GPIO_PinRemapConfig(GPIO_Remap_I2C1, ENABLE);

    //PB8——SCL PB9——SDA
    GPIO_InitStructure.GPIO_Mode  = GPIO_Mode_AF_OD;
    GPIO_InitStructure.GPIO_Pin   = OLE
DMA-USART
Battery voltage detection (ADC)

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文