Welcome to Self-balancing Robot Car repository
07.K210-QR code recognition
K210-QR code recognition
K210-QR code recognitionHardware connectionControl principleMain codeProgram flow chartExperimental phenomenon
The tutorial mainly demonstrates the function of using a balance car with a K210 visual module to control the balance car with a QR code.
xxxxxxxxxxThe tutorial only introduces the standard library project code
Hardware connection
| Peripherals | Development board |
|---|---|
| K210 visual module: VCC | 5V |
| K210 visual module: TXD | PA2 |
| K210 visual module: RXD | PA3 |
| K210 visual module: GND | GND |
Control principle
The K210 visual recognition module identifies the control instructions in the QR code information, and sends the identified QR code information to the development board. The development board controls the balance car to achieve corresponding actions according to the instruction information of the QR code.
K210 Vision Module
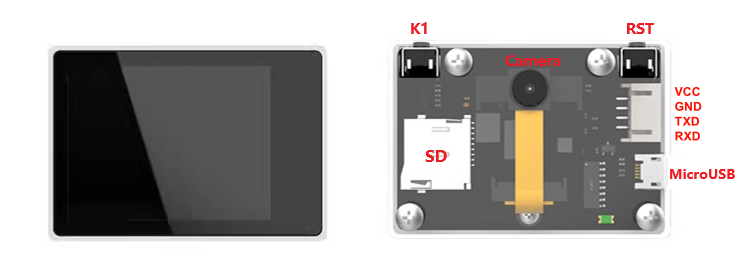
xxxxxxxxxxThe K210 vision module itself is a development board. For detailed usage, please refer to the module supporting tutorial
Download the program
Connect the SD card of the K210 vision module to the computer through a card reader, rename the program file to main.py and copy it to the SD card, then reinstall the SD card back into the SD card slot of the K210 vision module.
xxxxxxxxxxThe K210 vision module and development board case codes are in the same folder: the folder name will distinguish the development board to which the code belongs
QR code
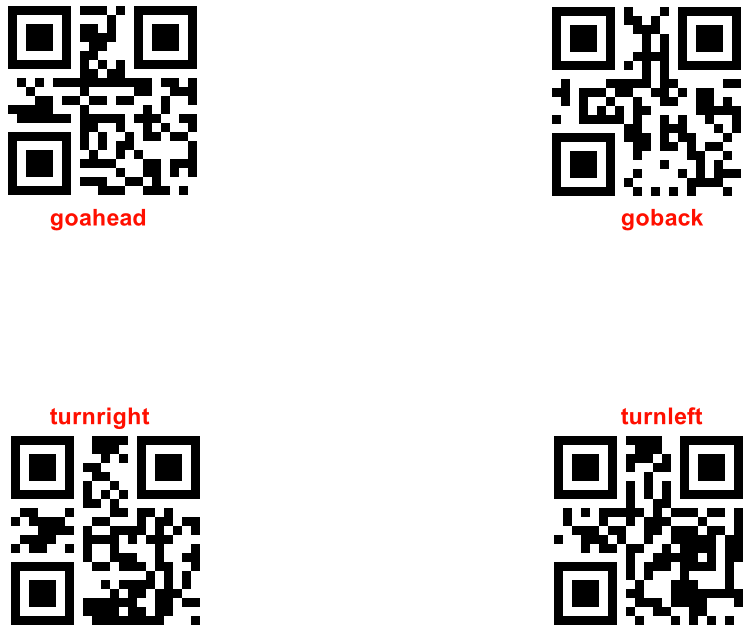
The QR code test can use the pictures in the tutorial, or use the webpage generated by QR Code online to generate a QR code picture.
Communication protocol
The program of the K210 visual module will parse the control instructions of the QR code, and the control instructions need to match the preset program.
| QR code information | K210 sent content | Balance car action |
|---|---|---|
| goahead | $goahead# | Stop after 2 seconds forward |
| goback | $goback# | Stop after 2 seconds backward |
| turnleft | $turnleft# | Stop after 1 second left and 1 second forward |
| turnright | $turnright# | Stop after 1 second right and 1 second forward |
Main code
The tutorial mainly explains the code for the K210 QR code recognition and control of the balance car function. For detailed code, please refer to the corresponding project file.
Deal_K210
Receive valid data sent by K210.
xvoid Deal_K210(uint8_t recv_msg){if (recv_msg == '$' && g_new_flag == 0){g_new_flag = 1;memset(buf_msg, 0, sizeof(buf_msg)); // Clear old datareturn;}if(g_new_flag == 1){if (recv_msg == '#'){g_new_flag = 0;g_index = 0;g_new_data = 1;}if (g_new_flag == 1 && recv_msg != '$'){buf_msg[g_index++] = recv_msg;if(g_index > 20) // Array overflow{g_index = 0;g_new_flag = 0;g_new_data = 0;memset(buf_msg, 0, sizeof(buf_msg)); // Clear old data}}}}
Change_state
Execute different actions according to different instructions sent by k210.
xxxxxxxxxxvoid Change_state(void){if(g_new_data == 1){g_new_data = 0;if (strcmp("goback", buf_msg) == 0 ){// The car moves back for two seconds and then stopsMove_X = -Go_speed;my_delay(2);Move_X = 0;}else if (strcmp("goahead", buf_msg) == 0 ){// The car moves back for two seconds and then stopsMove_X = Go_speed;my_delay(2);Move_X = 0;}else if (strcmp("turnleft", buf_msg) == 0){// The car turns left for 1 second and then moves forward for 1 second before stoppingMove_Z = -Trun_speed;my_delay(1);Move_Z = 0;Move_X = Go_speed;my_delay(1);Move_X = 0;}else if (strcmp("turnright", buf_msg) == 0 ){// The car turns right for 1 second and then moves forward for 1 second before stoppingMove_Z = Trun_speed;my_delay(1);Move_Z = 0;Move_X = Go_speed;my_delay(1);Move_X = 0;}}}
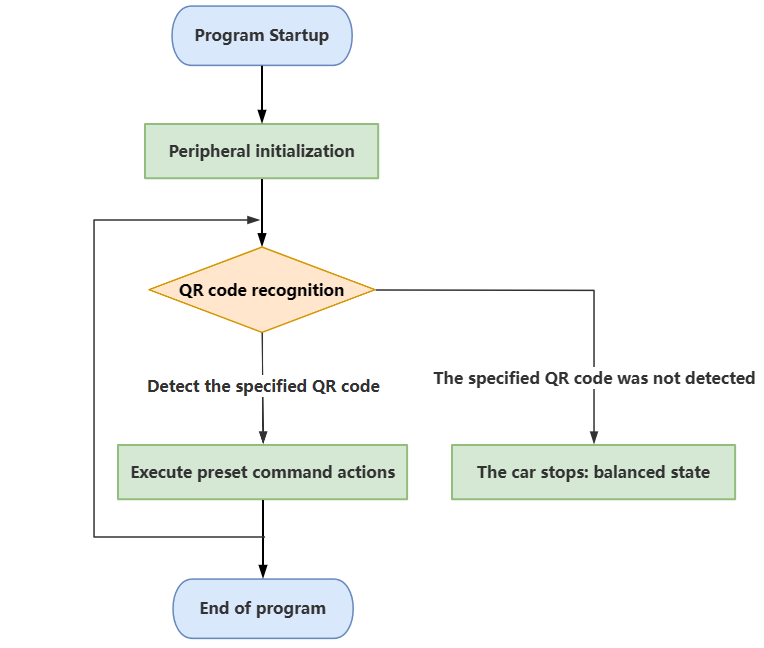
Program flow chart
Brief introduction to the function implementation process:
Experimental phenomenon
Software code
The K210_BalancedCar_QR.hex file generated by the project compilation is located in the OBJ folder of the K210_BalancedCar_QR project. Find the K210_BalancedCar_QR.hex file corresponding to the project and use the FlyMcu software to download the program to the development board.
xxxxxxxxxxBoth the K210 visual module and the development board need to download the program to realize the corresponding functionProduct supporting materials source code path: Attachment → Source code summary → 5.Balanced_Car_Extended → 07.K210_BalancedCar_QR
Experimental phenomenon
After the program is started, press KEY1 according to the OLED prompt to start the QR code recognition function of the balance car: OLED displays the program function name in real time (Start discern QR!); K210 visual recognition module recognizes the QR code and performs the corresponding action; if the QR code is not recognized, the balance car will stop moving and maintain balance.
The program has voltage detection. If the voltage is less than 9.6V, the low voltage alarm is triggered and the buzzer will sound.Common situations in which the voltage alarm is triggered:1. The power switch of the development board is not turned on, and only the Type-C data cable is connected for power supply2. The battery pack voltage is lower than 9.6V and needs to be charged in time