Welcome to NUWA-HP60C Depth Camera repository
3. Human Pose Estimation
3. Human Pose Estimation
3.1 Overview
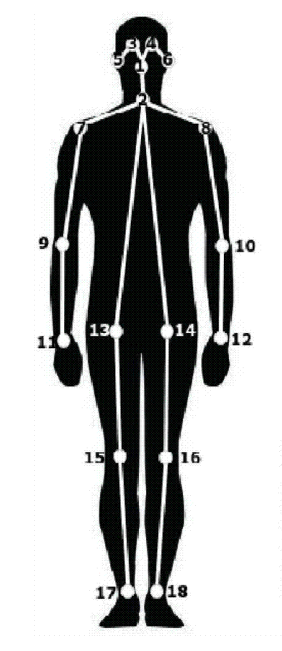
Human Posture Estimation estimates human posture by correctly linking the key points of the human body detected in the image. The key points of the human body usually correspond to joints with a certain degree of freedom on the human body, such as the neck, shoulder, elbow, wrist, waist, knee, ankle, etc., as shown in the figure below.
3.2 Principle
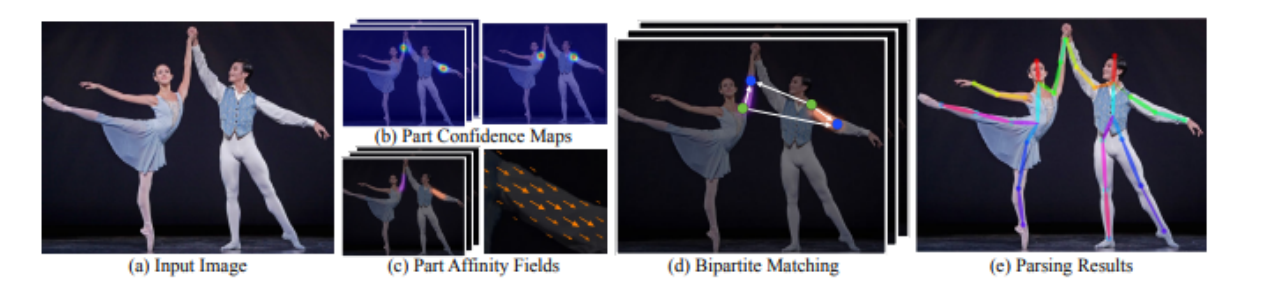
Input an image, extract features through the convolutional network, get a set of feature maps, and then split into two branches, using the CNN network to extract Part Confidence Maps and Part Affinity Fields respectively;
After obtaining these two pieces of information, we use Bipartite Matching in graph theory to find the Part Association, connects the joints of the same person. Due to the scalarity of PAF itself, the generated even matches are correct and finally merged into the overall skeleton of a person;
Finally, Multi-Person Parsing is solved based on PAFs—>Convert the Multi-person parsing problem into a graph problem—>Hungarian Algorithm
*Hungarian Algorithm is the most common algorithm for partial graph matching. The core of the algorithm is to find augmenting paths. It is an algorithm that uses augmenting paths to find the maximum matching of bipartite graphs.
3.3, Start
Source code path: ~/ascam_ws/src/ascam_visual/detection/target_detection.py
Start the camera
roslaunch ascamera hp60c.launch
Enter in a new terminal,
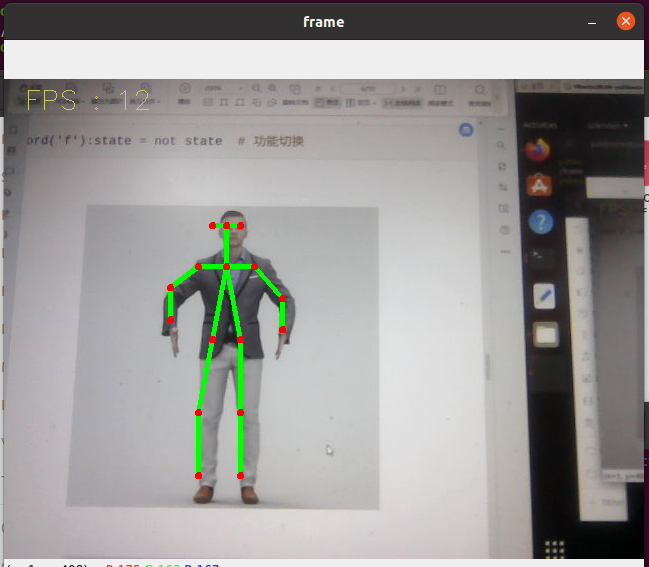
xxxxxxxxxxrosrun ascam_visual target_detection.pyAfter clicking the image frame, use the keyboard [f] key to switch target detection.