Welcome to NUWA-HP60C Depth Camera repository
4. KCF Object Tracking
4. KCF Object Tracking
4.1, Program startup
#Camera startupros2 launch ascamera hp60c.launch.pyros2 run yahboomcar_kcftracker kcf_tracker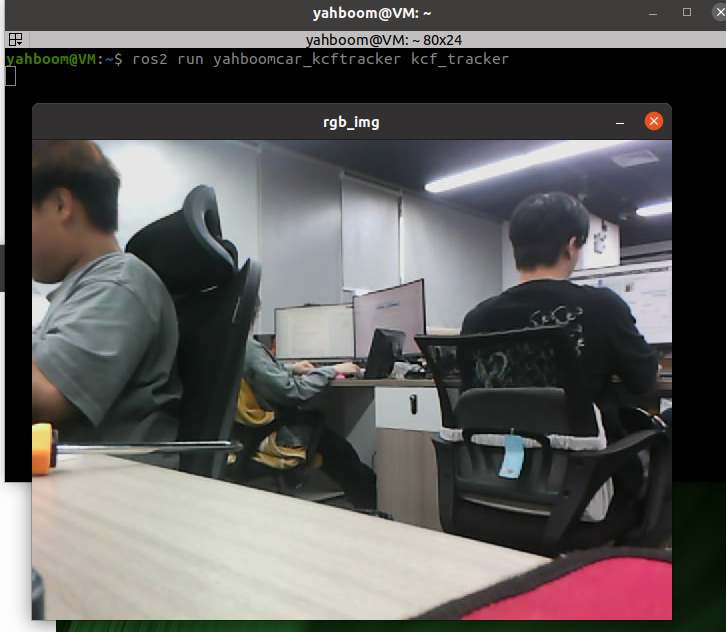
After the program is successfully started, the above figure is shown. Select the object to be tracked with the mouse. After releasing it, it will be framed, as shown in the figure below.
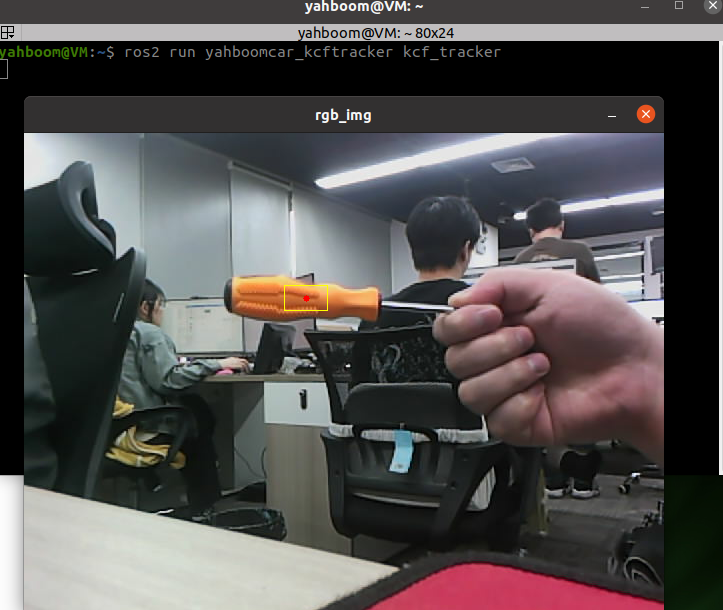
Then press the space bar to start tracking the object. The terminal will print out the center coordinates and distance of the tracked object.
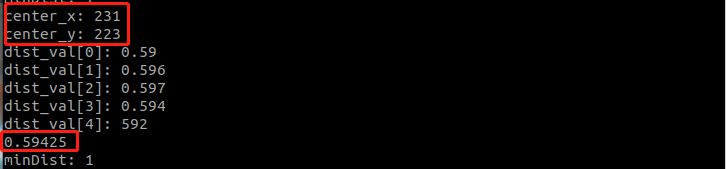
Similarly, since there is no robot chassis driver, the object tracking phenomenon cannot be seen intuitively, but the object tracking can be reflected indirectly through the terminal information and the changes in the /cmd_vel topic data. To view the speed topic data, enter the following command,
xxxxxxxxxxros2 topic echo /cmd_vel
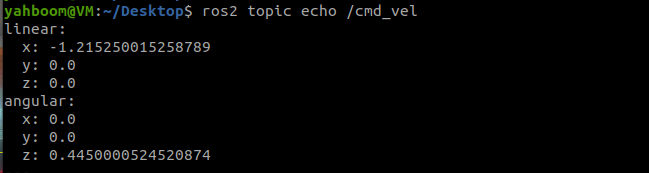
Move the tracked object, and the speed data here will also change.
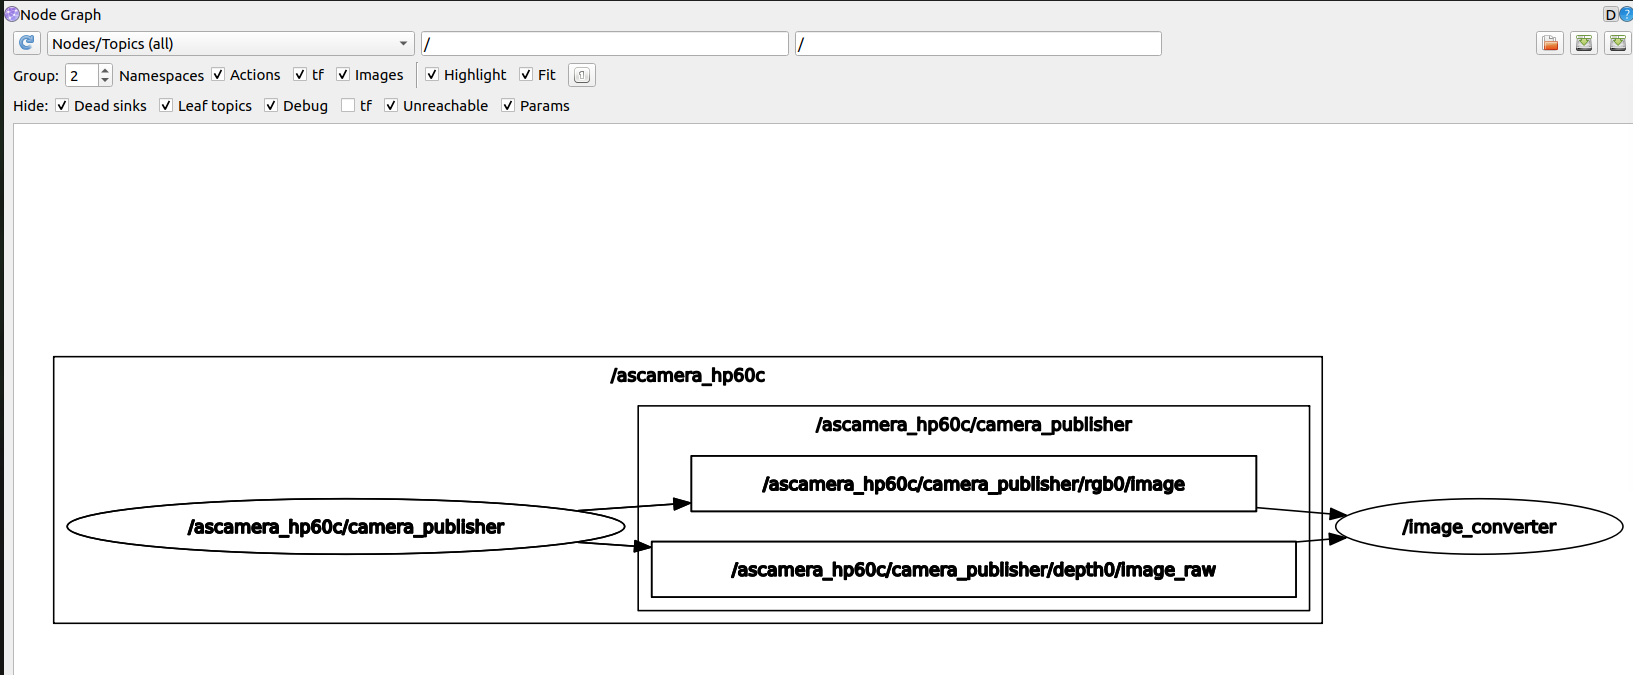
Check the communication between nodes and input in the terminal,
xxxxxxxxxxros2 run rqt_graph rqt_graph
4.2, core code
Code reference path,
xxxxxxxxxx~/ascam_ros2_ws/src/yahboomcar_kcftracker/src/kcf_tracker.cpp
The principle of function implementation is similar to color tracking. It calculates linear velocity and angular velocity based on the center coordinates of the target and the depth information fed by the depth camera, and then publishes it to the chassis. Some codes are as follows,
xxxxxxxxxx//This part is to obtain the center coordinates after selecting the object, which is used to calculate the angular velocityif (bBeginKCF) {result = tracker.update(rgbimage);rectangle(rgbimage, result, Scalar(0, 255, 255), 1, 8);circle(rgbimage, Point(result.x + result.width / 2, result.y + result.height/ 2), 3, Scalar(0, 0, 255),-1);} else rectangle(rgbimage, selectRect, Scalar(255, 0, 0), 2, 8, 0);//This part is to calculate the value of center_x and distance, which is used to calculate the speedint center_x = (int)(result.x + result.width / 2);int num_depth_points = 5;for (int i = 0; i < 5; i++) {if (dist_val[i] > 0.4 && dist_val[i] < 10.0) distance += dist_val[i];else num_depth_points--;}distance /= num_depth_points;//Calculate linear and angular velocityif (num_depth_points != 0) {std::cout<<"minDist: "<<minDist<<std::endl;if (abs(distance - this->minDist) < 0.1) linear_speed = 0;else linear_speed = -linear_PID->compute(this->minDist, distance);//-linear_PID->compute(minDist, distance)}rotation_speed = angular_PID->compute(320 / 100.0, center_x /100.0);//angular_PID->compute(320 / 100.0, center_x / 100.0)