Welcome to Building:bit Superkit repository
3.APP control
APP control
APP control1. Learning objectives2. Building blocks3. Motor wiring4. Programming5. Experimental Phenomenon5.1 Download APP5.2 APP remote controlAPP interface function introduction:
1. Learning objectives
In this course, we mainly learn how to use MakeCode graphical programming to realize Bluetooth APP remote control of Biped robot.
2. Building blocks
For the building blocks steps, please refer to the installation drawings of [Assembly Course]--[Biped robot] in the materials or the building blocks installation book.
3. Motor wiring
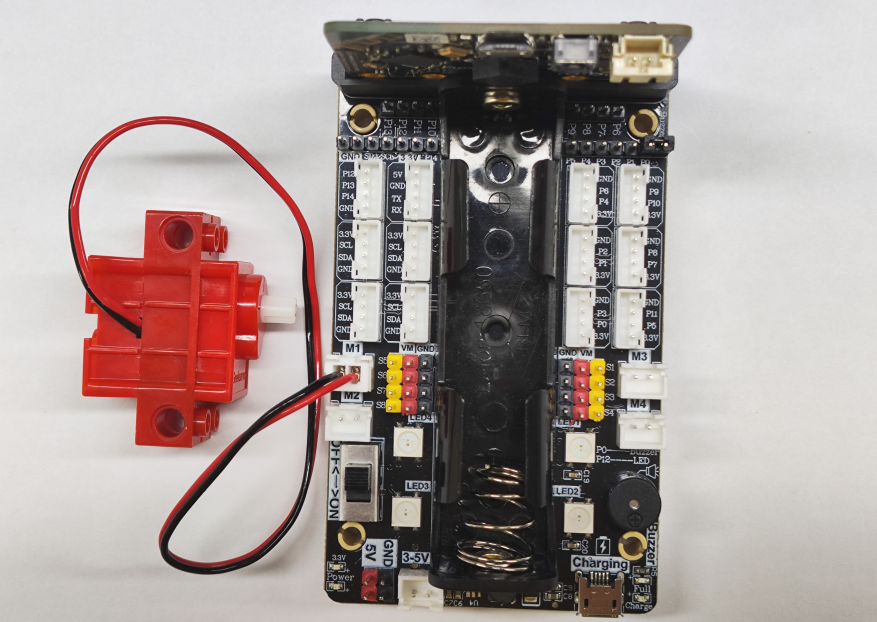
Insert the motor wiring on the left side of the car into the M1 interface of the Super:bit expansion board, with the black wire close to the battery side;
As shown below:
4. Programming
Method 1 Online programming:
First, connect micro:bit to the computer via a USB data cable. The computer will pop up a U disk. Click the URL in the U disk: https://makecode.microbit.org/ to enter the programming interface. Then, add the Yahboom software package https://github.com/YahboomTechnology/SuperBitLibV2, and you can start programming.
Method 2 Offline Programming:
Open the offline programming software MakeCode and enter the programming interface. Click [New] and add the Yahboom software package https://github.com/YahboomTechnology/SuperBitLibV2 to start programming.
For the summary program of this course, please open the microbit-Biped-robot-APP-control.hex we provide in the MakeCode programming interface to view it.
5. Experimental Phenomenon
5.1 Download APP
Android users, please use the mobile browser to scan the following QR code to download and install the APP;
Apple users, please use the hand camera to scan the QR code to download and install the APP.
! Note: During the installation or use of the APP, if the phone prompts that any permissions need to be obtained, please select "Agree".
5.2 APP remote control
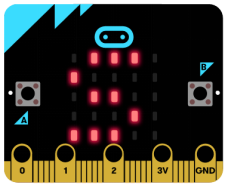
1) After the program is downloaded successfully, turn on the power switch of the car, and the micro:bit dot matrix will display an "S" pattern, as shown in the figure below. This is the state of Bluetooth disconnection.
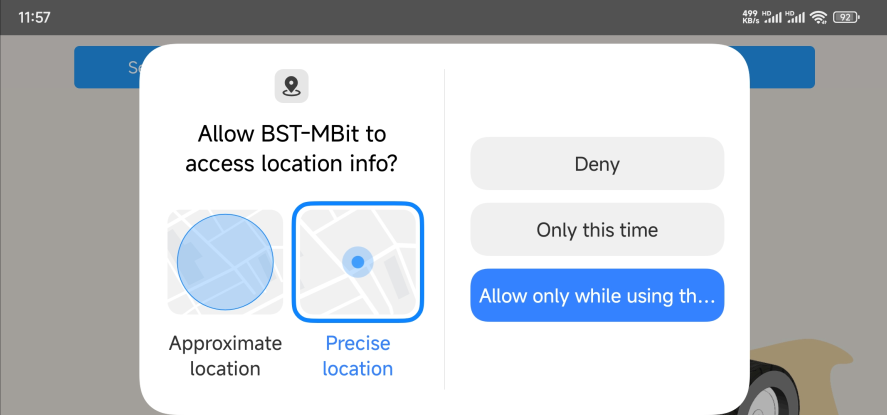
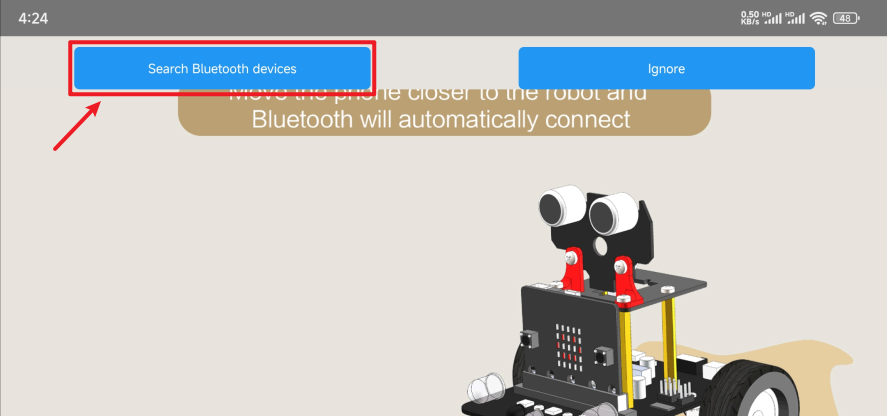
2) Turn on the Bluetooth of the mobile phone, open our APP, you can see the interface as shown in the figure below, click Allow APP to use positioning information.
3) After the mobile phone is close to the car and waits for a while, the Bluetooth will automatically connect; if it does not automatically connect, we can click [Search Bluetooth devices] to search for the device to connect.
After the Bluetooth is successfully connected, a smiley face pattern will be displayed on the micro:bit dot matrix; if the Bluetooth is disconnected, a crying face pattern will be displayed on the dot matrix.
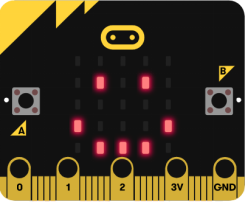
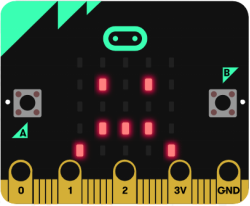
[Bluetooth successful connection status] [Bluetooth disconnection status]
APP interface function introduction:
Main control interface:
- The forward button controls the car to move forward;
- The backward button controls the car to move backward;
- The left-rotation button controls the Biped robot to move forward, and it will keep moving forward even if it is released;
- The right-rotation button controls the Biped robot to move backward, and it will keep moving backward even if it is released;
- Press the piano key 1, and the Biped robot stops moving;
- Press the piano key to hear the buzzer play different tones.
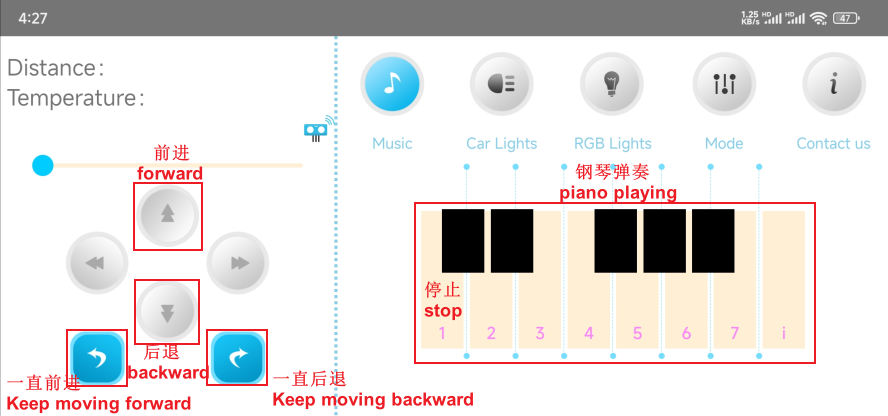
Car light interface:
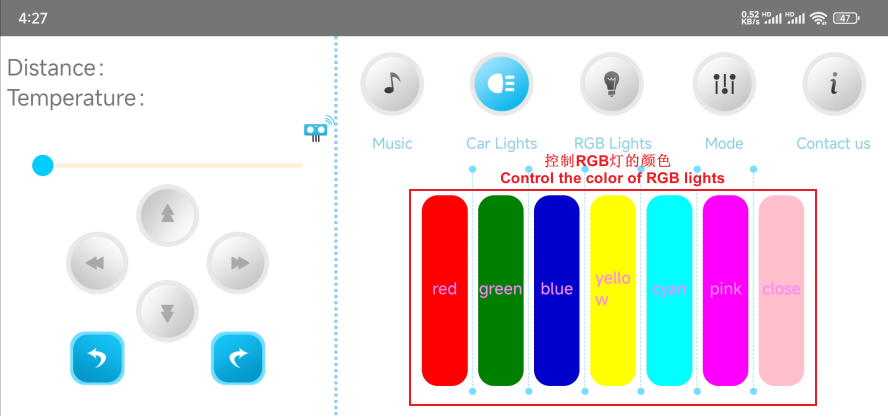
RGB light interface:
Due to the upgrade of micro:bit V2 motherboard, the Bluetooth code control has deleted the RGB light control and changed to dot matrix display.
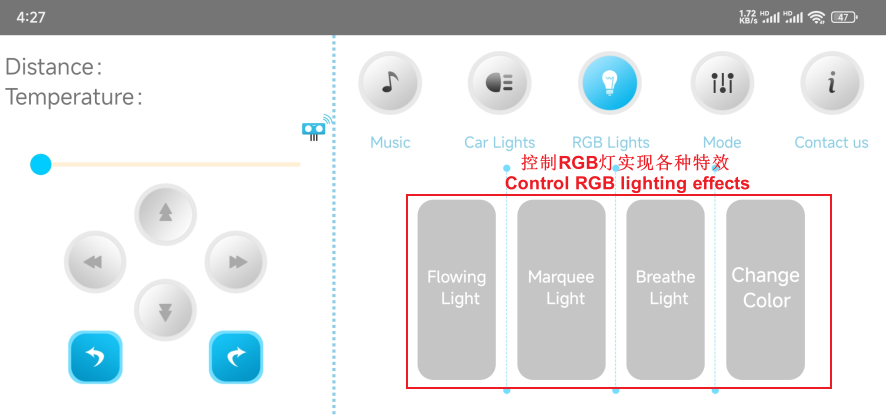
The buttons under the mode option have not yet defined any functions.