Welcome to Building:bit Superkit repository
3.1 Avoiding car
Avoiding car
Avoiding car1. Learning objectives2. Building blocks3. Sensor wiring4. Programming4.1 Adding extension packs4.2 Building blocks used4.3 Combining blocks5. Experimental phenomenon
1. Learning objectives
In this course, we mainly learn how to use MakeCode graphical programming to achieve obstacle avoidance for flying cars.
2. Building blocks
For detailed steps of building blocks, please refer to the installation drawings of [Assembly Course]-[Small flying car obstacle avoidance] or the building blocks installation brochure.
3. Sensor wiring
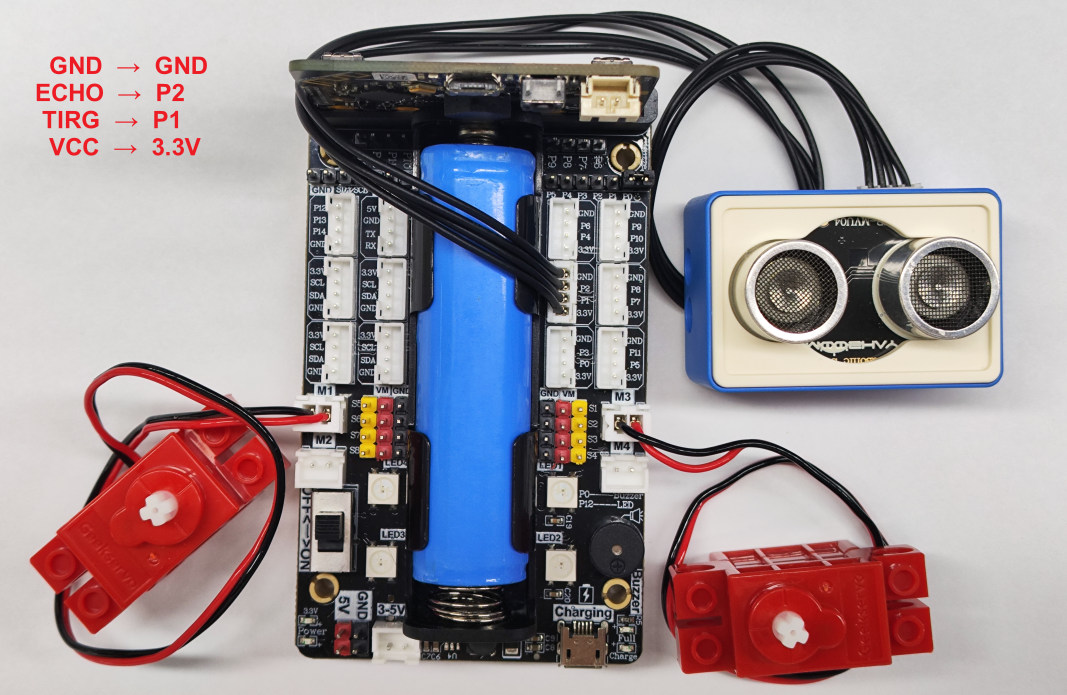
The motor wiring on the left side of the car is inserted into the M1 interface of the Super:bit expansion board, and the black wire is close to the battery side;
The motor wiring on the right side of the car is inserted into the M3 interface of the Super:bit expansion board, and the black wire is close to the battery side;
The ultrasonic wave is connected to the P1P2 interface.
4. Programming
Method 1 Online Programming:
First, connect micro:bit to the computer via a USB data cable. The computer will pop up a U disk. Click the URL in the U disk: https://makecode.microbit.org/ to enter the programming interface. Then, add the Yahboom software package https://github.com/YahboomTechnology/SuperBitLibV2 to start programming.
Method 2 Offline Programming:
Open the offline programming software MakeCode and enter the programming interface. Click [New] and add the Yahboom software package https://github.com/YahboomTechnology/SuperBitLibV2 to start programming.
4.1 Adding extension packs
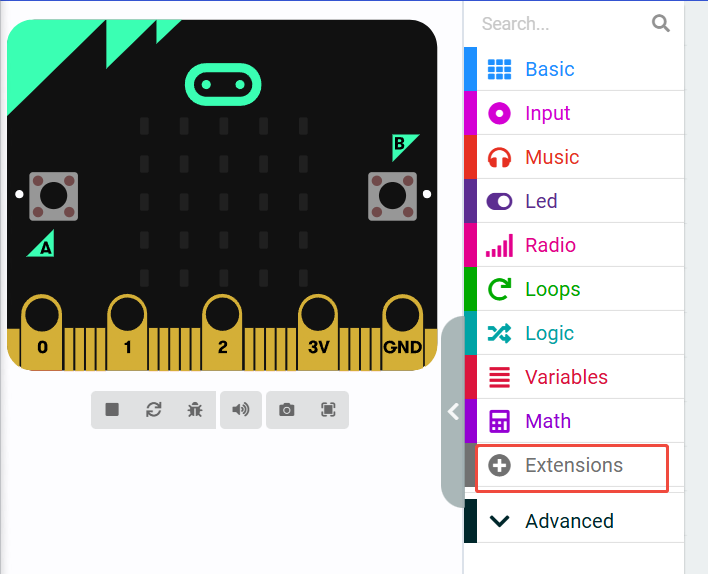
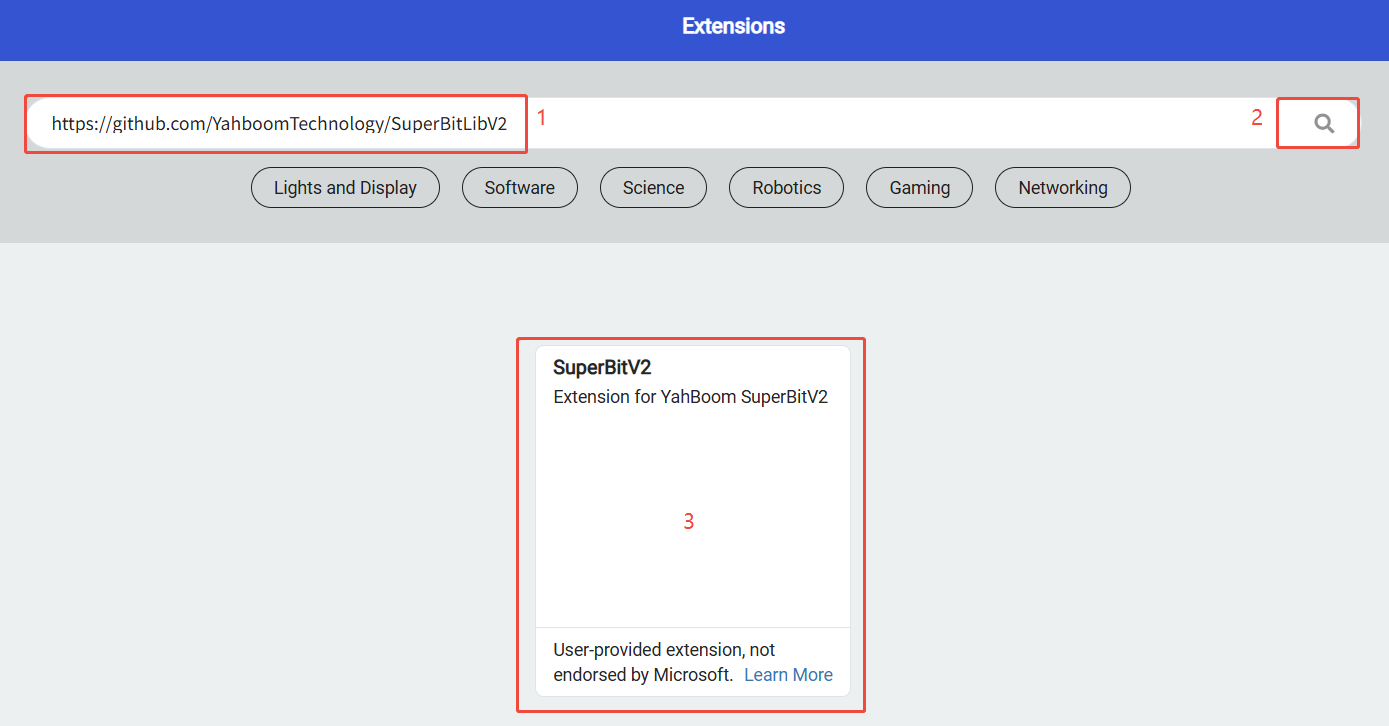
4.2 Building blocks used
The locations of the building blocks required for this programming are shown in the figure below.
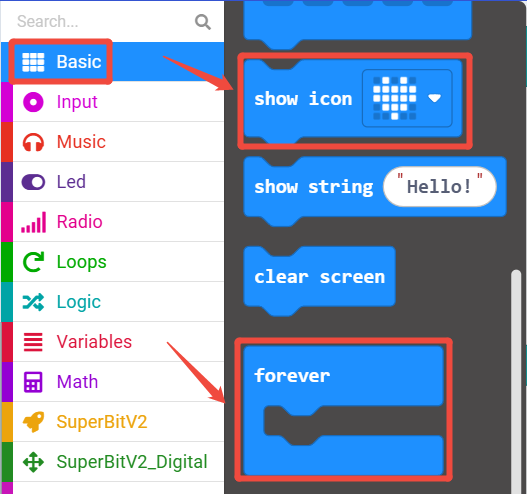
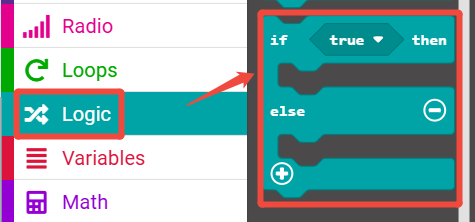
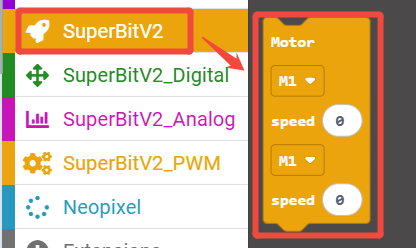
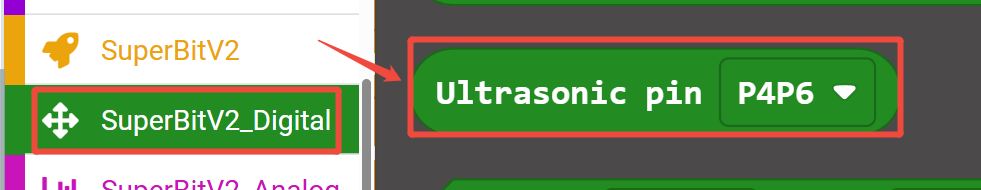
4.3 Combining blocks
The summary program is shown in the figure below.
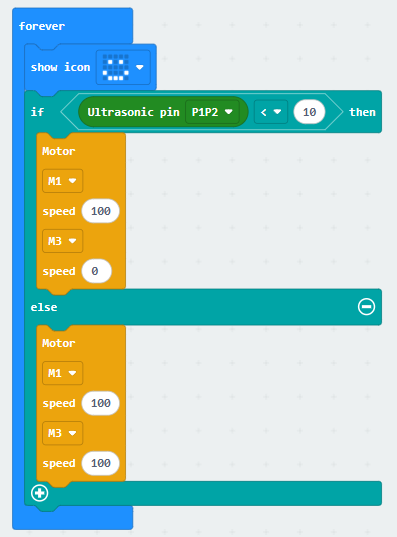
You can also directly open the Avoiding-car.hex file provided in this experiment and drag it into the browser that opens the URL, and the program diagram of this project source code will be automatically opened.
5. Experimental phenomenon
After the program runs successfully, the microbit dot matrix displays a smiley face. When the ultrasonic wave detects that the obstacle is less than 10cm away, the small flying car turns right to avoid the obstacle, and goes straight if there is no obstacle within 10cm.