yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
Building:bit Superkit📖
0.First Trial Video
1.Assembly Course
  • 1.1Mobile shooter
  • 1.2Pretty car
  • 1.3Clip robot
  • 1.4Proficient carrier
  • 1.5Skip car
  • 1.6Freestyle
  • 1.7Spider
  • 1.8Lifting platform
  • 1.9Biped robot
  • 1.10Changing Face
  • 1.11Carousel
  • 1.12Oscillating fan
  • 1.13Airplane
  • 1.14Unicycle
  • 1.15Auto-door
  • 1.16Dragon knight
  • 1.17Ultrasonic handheld rangefinder
  • 1.18Small flying car obstacle avoidance
  • 1.19Changing face
  • 1.20Adjustable RGB light
  • 1.21Adjustable fan
  • 1.22Photosensitive emergency light
  • 1.23Smart alarm clock
  • 1.24Light-controlled bipedal robot
  • 1.25Swimming robot avoid objects
  • 1.26Fleeing spider
  • 1.27Temperature humidity reminder
  • 1.28Temperature-controlled fan
  • 1.29Color recognition machine
  • 1.30Color-recognizing automatic door
  • 1.31Rokcer color changing light
  • 1.32Rokcer transporter
2.Preparation before class
  • 2.1 About BBC microbit
  • 2.2 Super:bit expansion board
  • 2.3 MakeCode Graphical Programming Guide
  • 2.4 MakeCode graphical API
  • 2.5 Python Programming Guide
  • 2.6 Superbit MicroPython API
  • 2.7 Notes on charging and battery use
3.Basic modeling MakeCode course
0.Basic course
  • 1.Buzzer play music
  • 2.Control RGB color
  • 3.Control all RGB lights
  • 4.Drive 270°building block servo
  • 5.Drive 180° servo
  • 6.Drive motor
A.Mobile shooter
  • 1.Cannonball shooting
  • 2.Music fortress
  • 3.APP control
  • 4.Micro:bit handle control
  • 5.WiFi camera control
B.Pretty car
  • 1.Dancer
  • 2.APP control
  • 3.Micro:bit handle control
  • 4.WiFi camera control
C.Clip robot
  • 1.Dancing and singing
  • 2.Button control clip
  • 3.APP control
  • 4.Micro:bit handle control
  • 5.WiFi camera control
D.Proficient carrier
  • 1.Dancing
  • 2.Button control shovel
  • 3.Transportation
  • 4.APP control
  • 5.Micro:bit handle control
  • 6.WiFi camera control
E.Skip car
  • 1.Dance battle
  • 2.Button control skip car
  • 3.Powerful carrier
  • 4.APP control
  • 5.Micro:bit handle control
  • 6.WiFi camera control
F.Freestyle
  • 1.Dancing and singing
  • 2.Freestyle advance
  • 3.APP control
  • 4.Micro:bit handle control
G.Spider
  • 1.Spider advance
  • 2.The dancing spider
  • 3.APP control
  • 4.Micro:bit handle control
  • 5.WiFi camera control
H.Lifting platform
  • 1.Automatic Lift
  • 2.Button control platform
  • 3.APP control
  • 4.Micro:bit handle control
I.Biped robot
  • 1.Walking
  • 2.Dancing and singing
  • 3.APP control
  • 4.Micro:bit handle control
J.Changing Face
  • 1.Changing face
  • 2.Bite the hand crocodile
  • 3.APP control
  • 4.Micro:bit handle control
K.Carousel
  • 1.Music carousel
  • 2.APP control
  • 3.Micro:bit handle control
L.Oscillating fan
  • 1.Colorful windmill
  • 2.Summer cooling artifact
  • 3.APP control
  • 4.Micro:bit handle control
M.Airplane
  • 1.Sailing Prelude
  • 2.APP control
  • 3.Micro:bit handle control
N.Unicycle
  • 1.Clumsy reptile
  • 2.APP control
  • 3.Micro:bit handle control
O.Auto-door
  • 1.Soldiers on duty
  • 2.Music door
  • 3.APP control
  • 4.Micro:bit handle control
P.Dragon knight
  • 1.Waving wings
  • 2.APP control
  • 3.Microbit handle control
4.Basic modeling Python course
0.Basic course
  • 1.Buzzer play music
  • 2.Control RGB color
  • 3.Control all RGB lights
  • 4.Drive 270° building block servo
  • 5.Drive 180° servo
  • 6.Drive motor
  • 7.Drive stepper motor
A.Mobile shooter
  • 1.Cannonball shooting
  • 2.Music fortress
  • 3.Micro:bit handle control
B.Pretty car
  • 1.Dancer
  • 2.Micro:bit handle control
C.Clip robot
  • 1.Dancing and singing
  • 2.Button control clip
  • 3.Micro:bit handle control
D.Proficient carrier
  • 1.Dancing
  • 2.Button control shovel
  • 3.Transportation
  • 4.Micro:bit handle control
E.Skip car
  • 1.Dance battle
  • 2.Button control skip car
  • 3.Powerful carrier
  • 4.Microbit handle control
F.Freestyle
  • 1.Dancing and singing
  • 2.Freestyle advance
  • 3.Micro:bit handle control
G.Spider
  • 1.Spider advance
  • 2.The dancing spider
  • 3.Micro:bit handle control
H.Lifting platform
  • 1.Automatic Lift
  • 2.Button control platform
  • 3.Micro:bit handle control
I.Biped robot
  • 1.Walking
  • 2.Dancing and singing
  • 3.Micro:bit handle control
J.Changing Face
  • 1.Changing face
  • 2.Bite the hand crocodile
  • 3.Micro:bit handle control
K.Carousel
  • 1.Music carousel
  • 2.Micro:bit handle control
L.Oscillating fan
  • 1.Colorful windmill
  • 2.Summer cooling artifact
  • 3.Micro:bit handle control
M.Airplane
  • 1.Sailing Prelude
  • 2.Micro:bit handle control
N.Unicycle
  • 1.Clumsy reptile
  • 2.Micro:bit handle control
O.Auto-door
  • 1.Soldiers on duty
  • 2.Music door
  • 3.Microbit handle control
P.Dragon knight
  • 1.Waving wings
  • 2.Micro:bit handle control
5.Sensor Advanced MakeCode coursenew
3.Sensor expansion course
  • 3.1 Avoiding car
  • 3.2 Changing Face
  • 3.3 Adjustable fan
  • 3.4 Photosensitive robot
  • 3.5 Swimming robot
  • 3.6 Spiders sense human body
  • 3.7 Temperature control fan
  • 3.8 Automatic safety door
  • 3.9 Rocker carrier car
2.Sensor basic course
  • 2.1 Hand-held range finder
  • 2.2 Adjustable RGB light
  • 2.3 Emergency light
  • 2.4 Vibrating alarm clock
  • 2.5 Infrared detection broadcast
  • 2.6Human body infrared detection broadcast
  • 2.7 Temperature and humidity broadcaster
  • 2.8 Color recognition machine
  • 2.9 Rocker control light
1.Sensor principle
  • 1.1 About ultrasonic sensors
  • 1.2 Ultrasonic ranging
  • 1.3 About potentiometers
  • 1.4 Adjust potentiometer
  • 1.5 About photosensitive sensors
  • 1.6 Read the light intensity
  • 1.7 About infrared modules
  • 1.8 Obstacle detection
  • 1.9 Introduction of module
  • 1.10 Human body detection
  • 1.11 About temperature-humidity modules
  • 1.12 Read temperature humidity
  • 1.13 About color recognition sensors
  • 1.14 Color recognition
  • 1.15 About rocker module
  • 1.16 Control rocker
6.Sensor Advanced Python coursenew
1.Sensor principle
  • 1.1 About ultrasonic sensorsnew
  • 1.2 Ultrasonic rangingnew
  • 1.3 About potentiometersnew
  • 1.4 Adjust potentiometernew
  • 1.5 About photosensitive sensorsnew
  • 1.6 Read the light intensitynew
  • 1.7 About infrared modulesnew
  • 1.8 Obstacle detectionnew
  • 1.9 About human infrared sensing modulesnew
  • 1.10 Human body detectionnew
  • 1.11 About temperature-humidity modulesnew
  • 1.12 Read temperature humiditynew
  • 1.13 About color recognition sensorsnew
  • 1.14 Color recognitionnew
  • 1.15 About rocker modulenew
  • 1.16 Control rockernew
2.Sensor basic course
  • 2.1 Hand-held range findernew
  • 2.2 Adjustable RGB lightnew
  • 2.3 Emergency lightnew
  • 2.4 Vibrating alarm clocknew
  • 2.5 Infrared detection broadcastnew
  • 2.6 Human body infrared detection broadcastnew
  • 2.7 Temperature and humidity broadcasternew
  • 2.8 Color recognition machinenew
  • 2.9 Rocker control lightnew
3.Sensor expansion course
  • 3.1 Avoiding carnew
  • 3.2 Changing Facenew
  • 3.3 Adjustable fannew
  • 3.4 Photosensitive robotnew
  • 3.5 Swimming robotnew
  • 3.6 Spiders sense human bodynew
  • 3.7 Temperature control fannew
  • 3.8 Automatic safety doornew
  • 3.9 Rocker carriernew
Download
  • APP(iOS_Android)
  • Code_PythonLibrary
  • Hardware manual
  • Bluetooth communication protocol
  • Assembly Instructions Manual
  • Makecode offline software
Download ZIP

Welcome to Building:bit Superkit repository

3.Micro:bit handle control

Micro:bit handle control

Micro:bit handle control1. Learning objectives2. Building blocks3. Motor wiring4. Programming4.1 Add expansion package4.2 Building blocks used4.3 Add new variables4.4 Combined blocks5. Experimental phenomenon

1. Learning objectives

In this course, we mainly learn how to use MakeCode graphical programming to realize the microbit handle to control the airplane.


2. Building blocks

For the building block steps, please refer to the installation drawings of [Assembly Course]--[Airplane] in the materials or the building block installation book.


3. Motor wiring

Insert the motor wiring on the left side of the car into the M1 interface of the Super:bit expansion board, and the black line is close to the battery side;

As shown below:
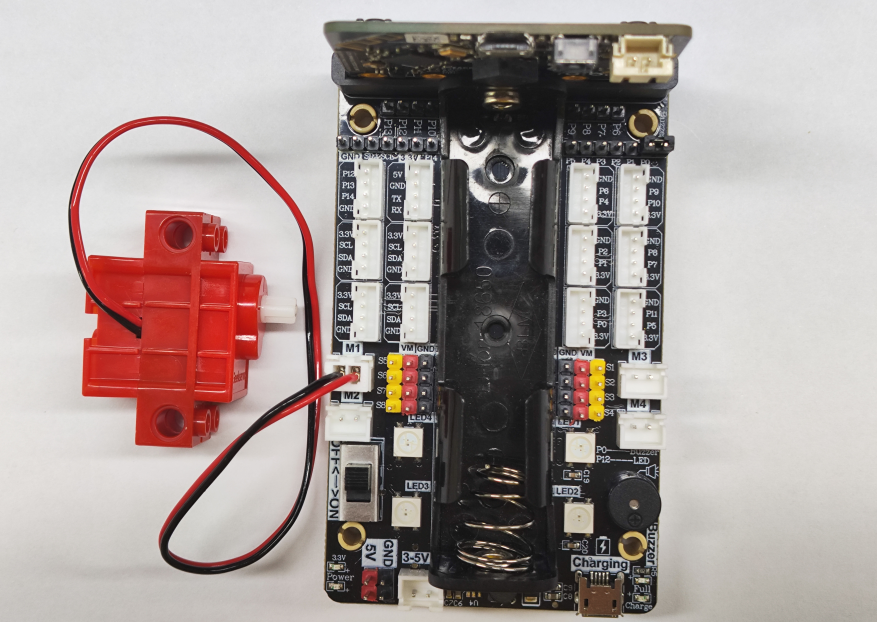
image-20250611160433482

4. Programming

Method 1 Online programming:

First, connect the micro:bit to the computer via a USB data cable, and the computer will pop up a U disk. Click the URL in the U disk: https://makecode.microbit.org/ to enter the programming interface. Then, add the Yaboom software package to program.

Method 2 Offline Programming:

Open the offline programming software MakeCode and enter the programming interface. Click [New] and add the Yaboom software package to start programming.

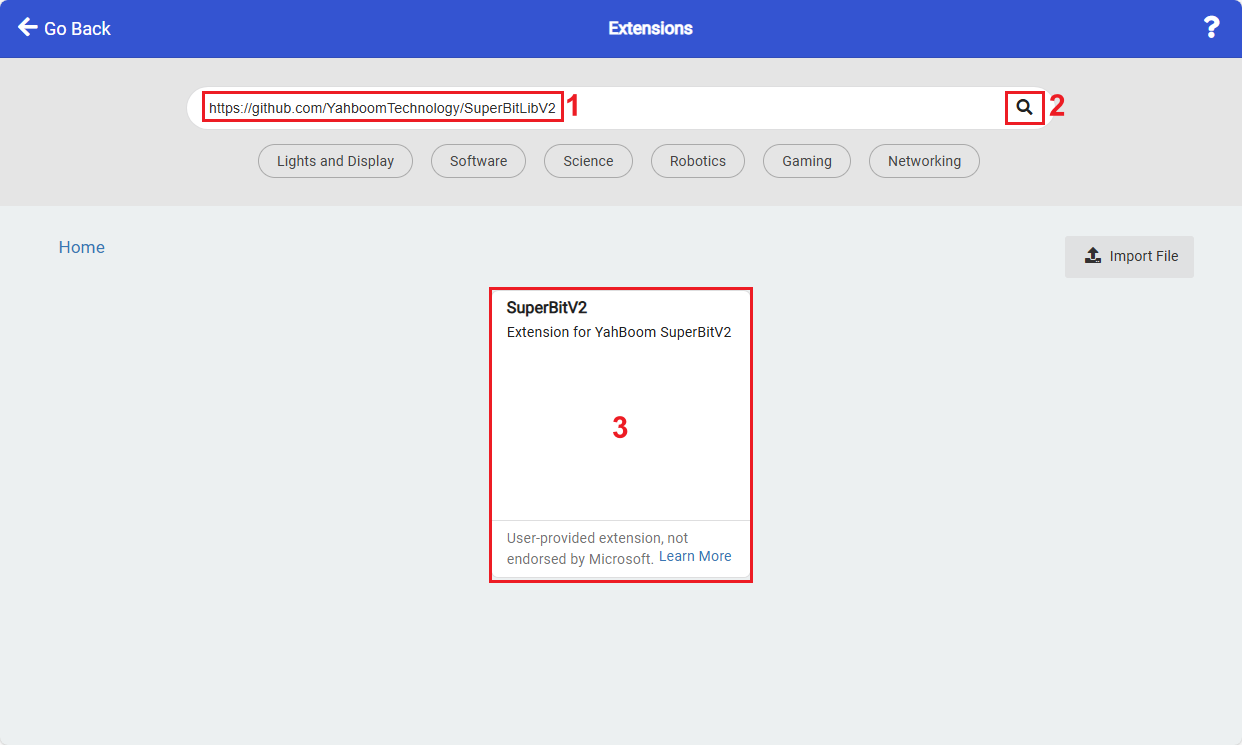
superbit kit expansion package: https://github.com/YahboomTechnology/SuperBitLibV2 Handle expansion package: https://github.com/YahboomTechnology/GHBitLib

4.1 Add expansion package
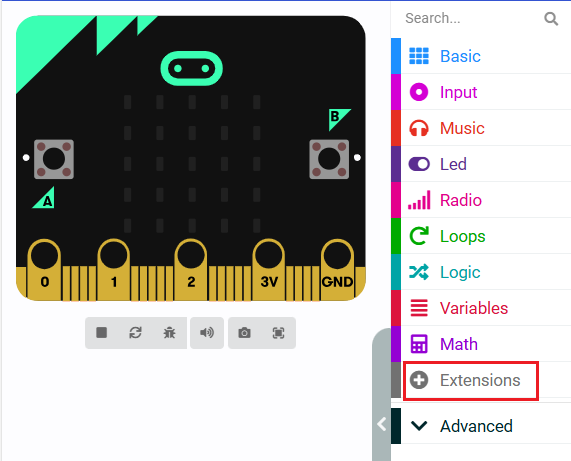
image-20250606184603631

image-20250606184759888

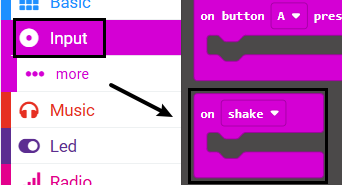
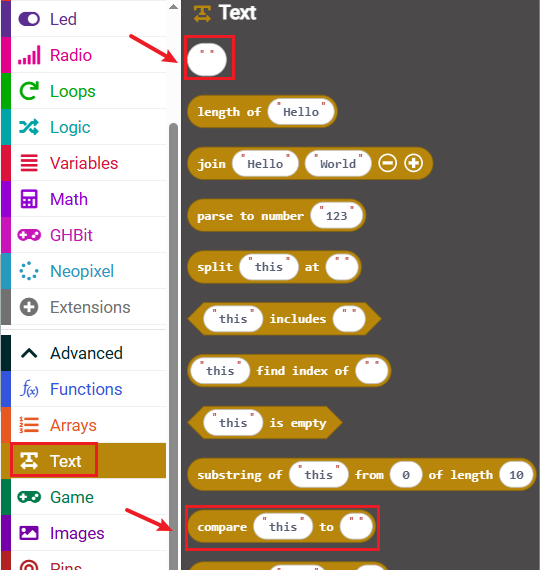
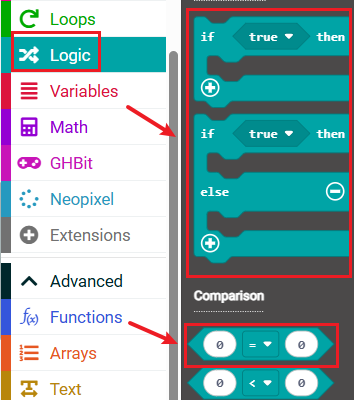
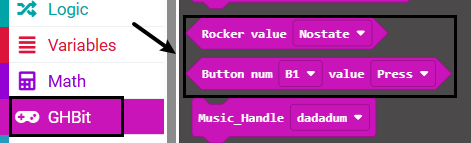
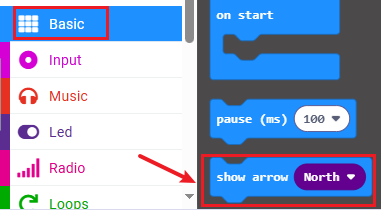
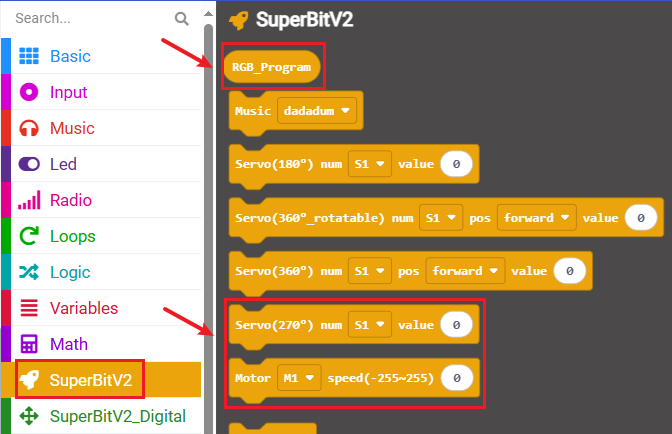
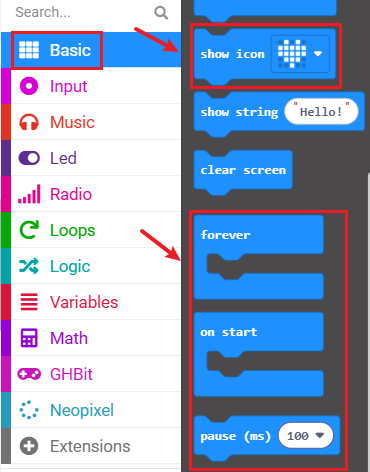
4.2 Building blocks used

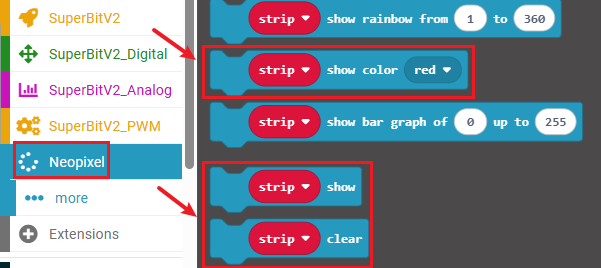
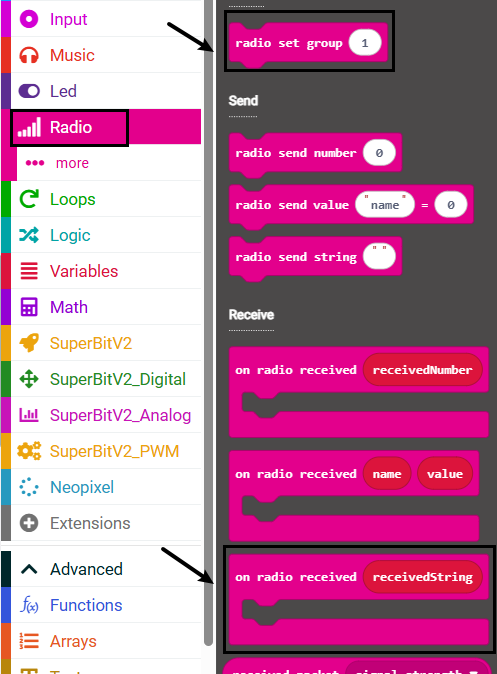
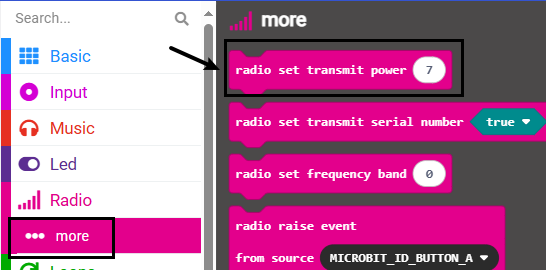
The location of the building blocks required for this programming is shown in the figure below.
1588044336115798

image-20250610174835687

image-20250610174626884

image-20250610174723708

image-20250610175759535

image-20250610175511071

image-20250610175905864

image-20250610180042653

image-20250610180238324

image-20250610180727860

image-20250610180850895

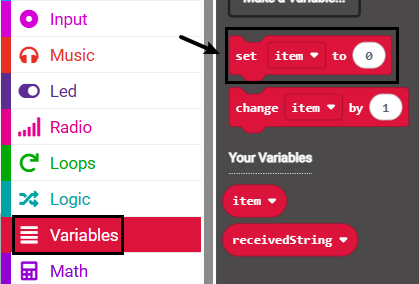
4.3 Add new variables

① Find the [Variable] option in the building block bar ---- [Set variable]
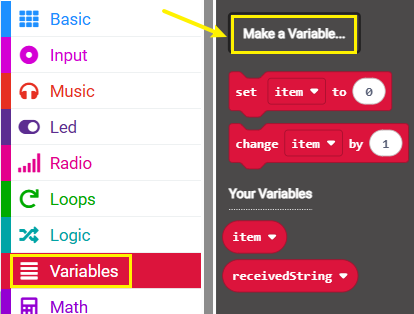
image-20250610181258643

② Enter the variable name to complete the new variable.
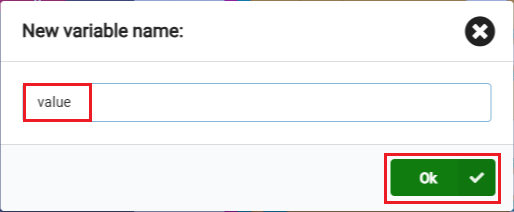
image-20250610181357390

4.4 Combined blocks

The microbit summary program on Airplane is shown in the figure below
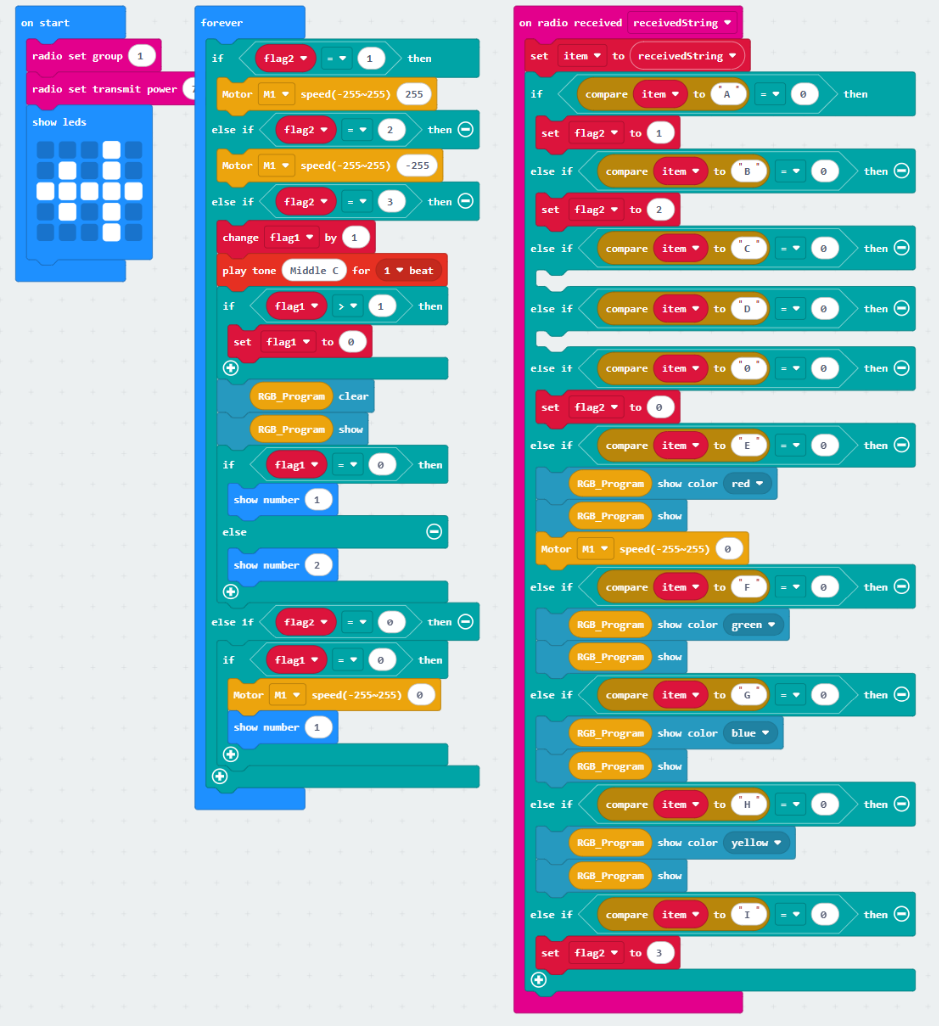
image-20250610183000547

Handle Rocker control program is as follows
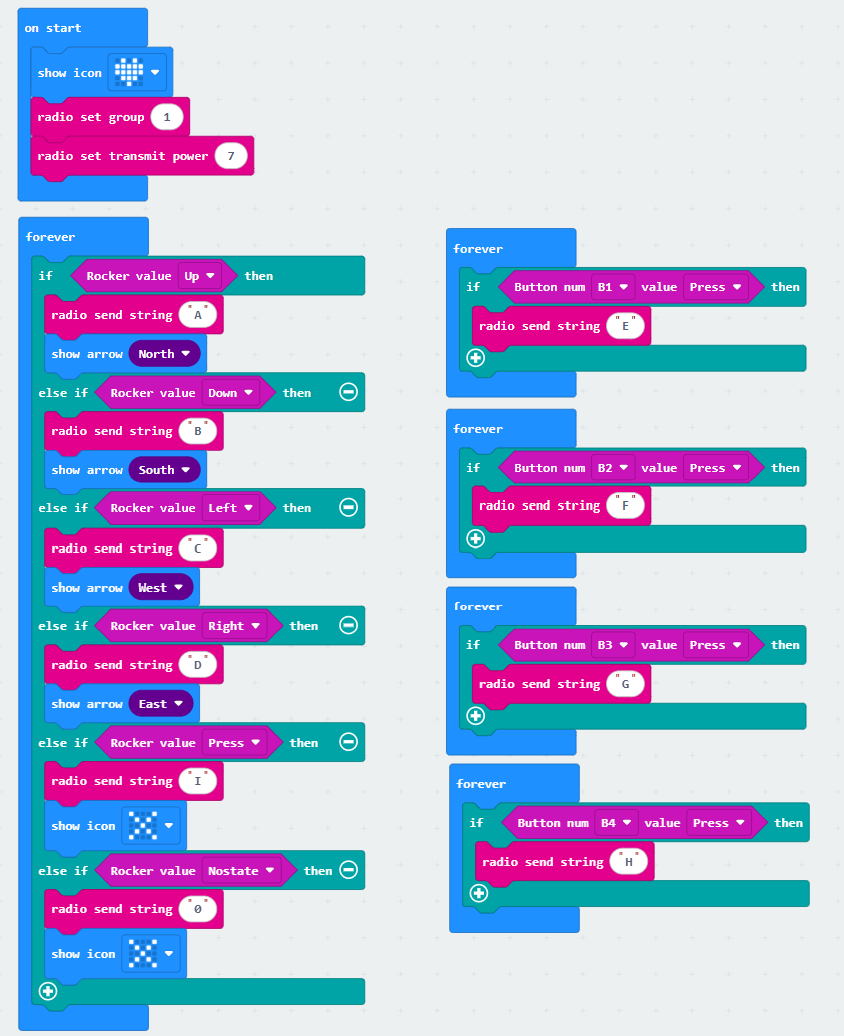
image-20250610183949848

Handle gravity control program is as follows
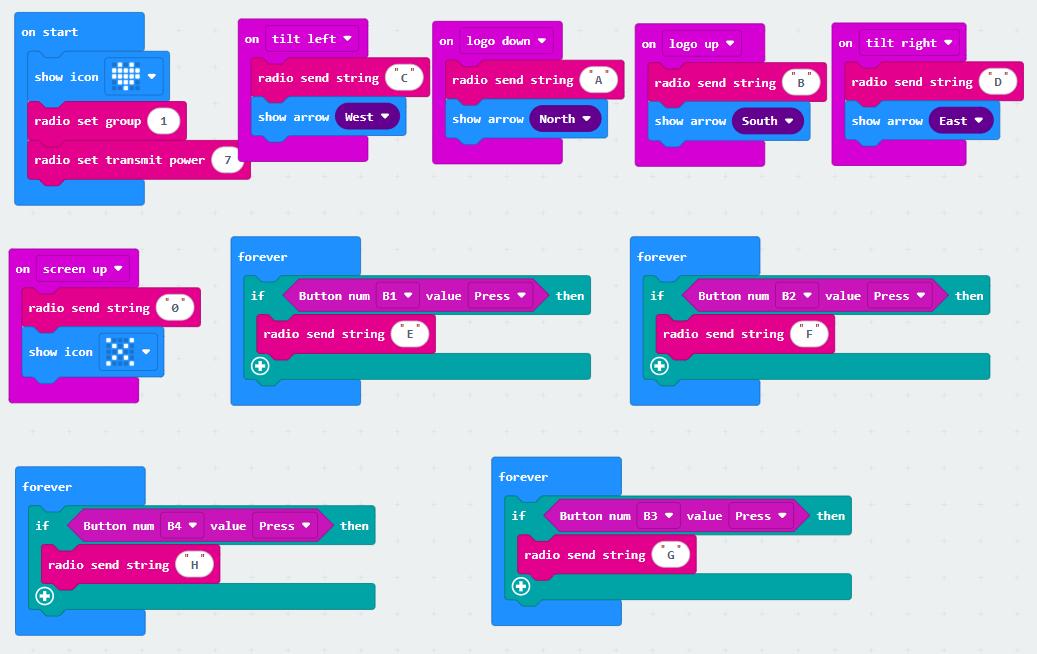
image-20250610185019064

You can also directly open the microbit-handle-control-airplane.hex、microbit-Handle-rocker-control.hex、microbit-Handle-gravity-control.hex Drag the file into the browser that opens the URL, and the program diagram of the source code of this project will be automatically opened


5. Experimental phenomenon

We need to download the Airplane program to the micro:bit motherboard of the Airplane, turn on the power switch of the Airplane, and we can see that the micro:bit dot matrix will initialize to display an airplane pattern, and then it will display the number 1 (indicating that it has entered the default mode 1).

Download the handle remote control program to the micro:bit motherboard of the handle, turn on the power switch of the handle, and we can see that the micro:bit dot matrix will initialize to display a heart pattern, and then it will display an "X" pattern, indicating that the handle is in the default state and no data is sent.

The two will automatically complete the pairing, and then we can start to remotely control the Airplane.

The handle functions are as follows.
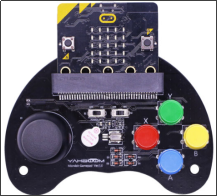
image.png

Handle Rocker control:

After the Rocker and Airplane are paired successfully, we can see the number 1 displayed on the micro:bit dot matrix of Airplane, indicating that it is in mode 1.

In mode 1:

  • Push the Rocker forward to control the propeller of Airplane to rotate counterclockwise, and it will stop rotating when you release your hand;
  • Push the Rocker backward to control the propeller of Airplane to rotate clockwise, and it will stop rotating when you release your hand;
  • Press the red button to light up the red RGB light;
  • Press the green button to light up the green RGB light;
  • Press the yellow button to light up the yellow RGB light;
  • Press the blue button to light up the blue RGB light.

We can press the Rocker to switch to mode 2, and we can see the number 2 displayed on the micro:bit dot matrix of Airplane, indicating that it is in mode 2.

In mode 2:

  • Push the Rocker forward to control the propeller of the Airplane to rotate counterclockwise, and it will keep rotating after releasing the hand;
  • Push the Rocker backward to control the propeller of the Airplane to rotate clockwise, and it will keep rotating after releasing the hand;
  • Press the red button to light up the red RGB light and stop the rotating propeller;
  • Press the green button to light up the green RGB light;
  • Press the yellow button to light up the yellow RGB light;
  • Press the blue button to light up the blue RGB light.

Each time the Rocker is pressed, it will switch back and forth between mode 1 and mode 2, and the RGB light will go out.


Handle gravity control:

After the handle and Airplane are successfully paired, we can see the number 1 displayed on the micro:bit dot matrix of Airplane.

  • Tilt the handle forward to control the propeller of the Airplane to rotate counterclockwise, and stop rotating when placed horizontally;
  • Tilt the handle backward to control the propeller of the Airplane to rotate clockwise, and stop rotating when placed horizontally;
  • Press the red button to light up the red RGB light;
  • Press the green button to light up the green RGB light;
  • Press the yellow button to light up the yellow RGB light;
  • Press the blue button to light up the blue RGB light.

(Note: There is only one mode for the Handle gravity control, and you cannot switch to mode 2)

APP control
Clumsy reptile

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文