Welcome to MicroROS-Pi5 repository
当製品の日本語版マニュアル資料は、こちらからご取得ください。
2. Introduction to lidar
2. Introduction to lidar
As a low-cost measurement single-line high-precision lidar sensor, the MS200 radar adopts the TOF measurement method. The small size of the MS200 radar allows it to be built into the robot body, optimizing the space usage of the robot content. Although small in size, it integrates a variety of long-distance measurement optimization algorithms, with a 90% reflectivity ranging range of up to 12.0m. At the same time, its power system uses a custom-optimized brushless DC motor with a service life of more than 10,000 hours.
Specifications are as follows:
| parameter | numerical value | explanation |
|---|---|---|
| Measuring range | 0.03m-12.0m | Under the condition of 90% reflectivity |
| measurement accuracy | Typical values: ≤4mm(0.2m-2.0m)、≤15mm(2.0m-12.0m) | Under the condition of 90% reflectivity, the radar collected data statistical results 100 times. |
| Scan angle | 360° | - |
| Frequency | 4500 points/second | - |
| spinning speed | 10Hz | - |
| Angular resolution | 0.8°@10Hz | - |
| Laser emission pitch angle | 0.5°-2° | Based on the bottom surface of the radar base frame |
| Laser zero emission azimuth angle | 0±2° | - |
| Operating Voltage | DC 5.0±0.5V | - |
| Operating temperature | -10℃~50℃ | Typical value 25℃ |
| Working current | typical:260mA | - |
| Starting current | less than 500mA | - |
| Product Size | 37.7×37.5×33.0 | Length × Width × Height (Unit: mm) |
| net weight | About 40g | - |
| Serial port baud rate | 230400 | - |
Interface definition:
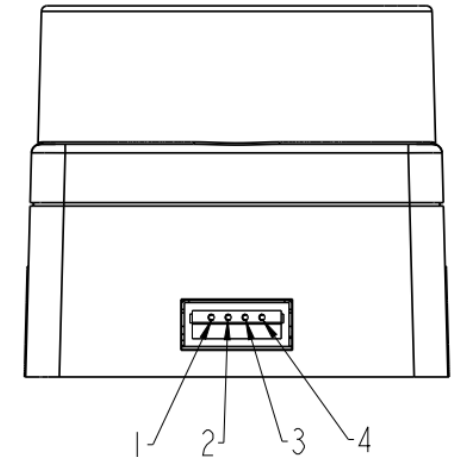
| Pin | Signal | Attributes | describe |
|---|---|---|---|
| 1 | Tx | Serial data sending | Tx(Send locally,0V~3.3V) |
| 2 | Rx | Serial port data reception | Rx(Local reception,0V~3.3V) |
| 3 | GND | Input power negative pole | GND(0V) |
| 4 | VCC | Input power positive pole | DC 5V(4.5V~5.5V) |
Serial port configuration parameters:
| baud rate | data bits | Stop bit | Check Digit | flow control |
|---|---|---|---|---|
| 230400 | 8 | 1 | None | None |