Welcome to RDK X5 Board repository
1.Function package usage process
1. Before using the ROS feature pack, it is necessary to ensure that the firmware library has been installed. You can refer to the third section of the "Python Basic Control Course" on installing the Rosmaster driver library
2. Create, initialize, and compile a ROS workspace (using driver-ws as an example)
Input following command in the terminal
xxxxxxxxxxmkdir yahboomcar_wscd yahboomcar_wsmkdir srccd src
Copy and paste all the feature pack folders in the folder into the src folder of the ROS workspace, then return to driver-ws.
Input following command in the terminal
xxxxxxxxxxcolcon build
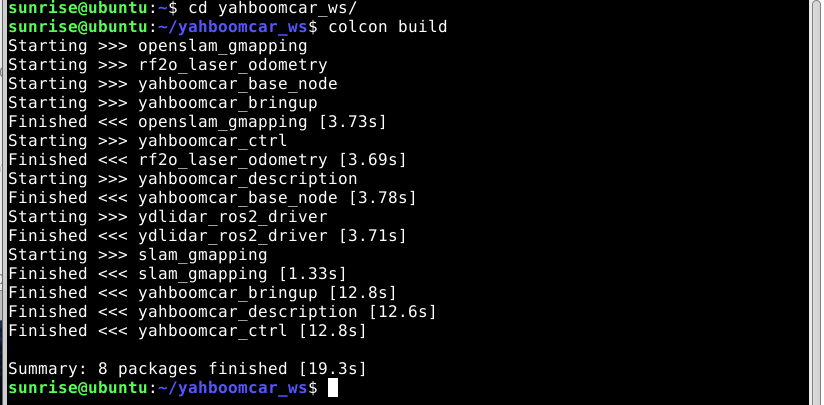
4、Add feature package path to environment variables
Input following command in the terminal
xxxxxxxxxxsudo gedit ./.bashrc
Paste the following content at the end of the file
xxxxxxxxxxsource ~/yahboomcar_ws/install/setup.bash5、Save, exit, enter the following command to refresh environment variables
xxxxxxxxxxsource ~/.bashrc
6、Compiling dependencies that may need to be installed
xxxxxxxxxx#以ros-humble为例sudo apt install ros-humble-geographic-*sudo apt install libgeograph*