yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
RDK X5 Board📖
1.Introduction to RDK X5 board
  • 1.Introduction to RDK X5 board
  • 2.Write system file
  • 3.Hardware interface description
  • 4.Install case and other accessories
  • 5.Use 7-inch display
2.Basic settings course
  • 1.Network configuration
  • 2.Remote login
  • 3.Update system
  • 4.srpi-config user guide
  • 5.config. txt configuration file
  • 6.Self-startup setting
  • 7.RDK exclusive command usage
  • 8.Linux command usage
  • 9.GPIO readwrite operation
  • 10.Image classification algorithm
  • 11.Use USB camera
  • 12.Use MIPI camera
  • 13.Binocular camera depth algorithm
3.Basic development course
C language
  • 1.Camera image display
  • 2.Local save camera images
  • 3.Camera image encoding
  • 4.Video file decoding
  • 5.RTSP streaming decoding
  • 6.VPS scaling example
  • 7.Target detection algorithm-fcos
  • 8.Target detection algorithm-YOLOv5s
  • 9.Using CAN
Python
  • 0.ReadMe
  • 1.Using GPIO
  • 2.Using PWM
  • 3.Using Serial port
  • 4.Using I2C
  • 5.Using SPI
4.ROS expansion board
Python basic control
  • 0.Bind PCB port devices
  • 1.Install the Rosmaster driver library
  • 2.Buzzer whistle
  • 3.Control PWM servo
  • 4.RGB colorful light bar special effects display
  • 5.Control the forward and reverse rotation of the motor
  • 6.Control the movement of the robot
  • 7.Control Serial Servo
  • 8.Update firmware of expansion board
  • 9.Drive OLED
ROS2 robot control
  • 1.Function package usage process
  • 2.Robot information release
  • 3.Robot keyboard control
  • 4.Robot state estimation
  • 5.Robot calibration
  • 6.URDF model
5.T-MINI PLUS Lidar
  • 0.Preparation before use(Must read)
  • 1.Environment setup
  • 2.T-MINI PLUS LiDAR drive
  • 3.Handheld LiDAR mapping
6.AI VIEW Depth camera
AI VIEW Depth camera use
  • 1.AI VIEW Depth camera use
  • 2.Camera internal parameter calibration
  • 3.Color tracking
  • 4.KCF object tracking
Mediapipe functions
  • 1.Hand detection
  • 2.Attitude detection
  • 3.Overall inspection
  • 4.Facial detection
  • 5.Facial recognition
OpenCV series courses
  • 1.ROS+opencv application
  • 2.QR code creation and recognition
  • 3.AR vision
7.Offline AI model course
Offline-LLM-Text-Interaction
  • 0.AI-Large-Model-Image-Description
  • 1.AI-Large-Model-Environment-Deployment
  • 2.LLM-Conversation-Platform-Installation
  • 3.Meta-AI-Llama3.2-Model
  • 4.Alibaba-Cloud-Qwen3-Model
  • 5.Microsoft-Phi-4-mini-Model
  • 6.DeepSeek-DeepSeek-R1-Model
  • 7.Alibaba-Cloud-Qwen2.5vl-Vision-Multimodal-Model
  • 8.Google-Gemma3-Vision-Multimodal-Model
  • 9.Llava-Vision-Multimodal-Model
  • 10.MiniCPM-V-Vision-Multimodal-Model
  • 11.Multimodal-Text-to-Image-Application
  • 12.Multimodal-Video-Analysis-Application
  • 13.Multimodal-Visual-Understanding-Application
  • 14.Multimodal-Visual-Localization-Application
  • 15.Multimodal-Table-Scanning-Application
  • 16.Multimodal-Autonomous-Agent-Application
Offline-LLM-Voice-Interaction
  • 0.Voice-Interaction-Hardware-Connection-Must-Read
  • 1.Offline-Speech-to-Text-ASR
  • 2.Offline-Text-to-Speech-TTS
  • 3.AI-Large-Model-Voice-Interaction
  • 4.Multimodal-Visual-Understanding-Voice-Interaction
  • 5.Multimodal-Text-to-Image-Application
  • 6.Multimodal-Video-Analysis-Application
  • 7.Multimodal-Visual-Localization-Application
  • 8.Multimodal-Table-Scanning-Application
  • 9.Multimodal-Autonomous-Agent-Application
  • 10.AI-Large-Model-Offline-Voice-Assistant
8.Online AI model course
Online-LLM-Text-Interaction
  • 1.OpenRouter-Large-Model-API-Aggregation-Platform
  • 2.Multimodal-Visual-Understanding-Application
  • 3.Multimodal-Visual-Localization-Application
  • 4.Multimodal-Table-Scanning-Application
  • 5.Multimodal-Autonomous-Agent-Application
Online-LLM-Voice-Interaction
  • 0.Voice-Interaction-Hardware-Connection-Must-Read
  • 1.Online-Speech-to-Text-ASR
  • 2.Online-Text-to-Speech-TTS
  • 3.AI-Large-Model-Voice-Interaction
  • 4.Multimodal-Visual-Voice-Interaction
  • 5.Multimodal-Visual-Localization-Application
  • 6.Multimodal-Table-Scanning-Application
  • 7.Multimodal-Autonomous-Agent-Application
  • 8.AI-Large-Model-Online-Voice-Assistant
9.YOLO26 tutorials
  • 01.YOLO environment construction
  • 02.CLI use
  • 03.Object detection
  • 04.Instance segmentation
  • 05.Pose estimation
  • 06.Image classification
  • 07.Oriented bounding box object detection
  • 08.Model conversion
  • 09.Dataset annotation
  • 10.Model training conversion
  • 11.Model prediction
10.OpenClaw Deployment and Basic Usagenew
  • 01.OpenClaw Quick Start
  • 02.OpenClaw Deployment
  • 03.OpenClaw WhatsApp Plugin Application
  • 04.OpenClaw WebChat Interaction
  • 05.OpenClaw TUI Interaction
  • 06.OpenClaw Tools Introduction
  • 07.OpenClawGate Gateway User Manual
  • 08.OpenClaw Features Overview
  • 09.OpenClawClawHub Introduction (Skill Installation)
  • 10.OpenClaw Application - File Management
  • 11.OpenClaw Application - Camera
  • 12.OpenClaw Application - Browser Control
  • 13.OpenClaw Application - Script Execution
  • 14.OpenClaw Application - AI Programming (Peripheral & GPIO Control)
  • 15.OpenClaw Application - Dedicated AI Assistant
  • 16.OpenClaw Web Search Capability Configuration
11.OpenClaw Advanced Developmentnew
1.Preparation Before Use
  • 01. Peripheral Hardware Configuration
  • 02. OpenClaw API-KEY Configuration
  • 03. OpenClaw Model Switching
  • 04. OpenClaw Prompts
  • 05. AI Voice Interaction Configuration
  • 06. Three Dialogue Configuration Tests
2.OpenClaw AI Programming Peripheral Control
  • 1. Servo Control
  • 2. RGB Strip
  • 3. OLED Display
  • 4. Temperature and Humidity Sensor
  • 5. Camera Application
  • 6. AI Script Peripheral Control
3.OpenClaw Peripheral Integration Applications
  • 1. Plant Care Assistant
  • 2. AI Calorie Estimation
  • 3. AI Rock Paper Scissors Game
  • 4. AI Pet
  • 5. AI Weather Station
  • 6. Temperature and Humidity Dashboard
  • 7. Scheduled Tasks
12.ROS2 basic course
  • 1.Introduction to ROS2
  • 2.ROS2 install Humble
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
Download
  • System_File
  • Code
  • Tools
Download ZIP

Welcome to RDK X5 Board repository

5. AI Weather Station

OpenClaw AI Weather Station Tutorial

Before starting, please complete [01-Peripheral hardware configuration], [02-openclaw API-KEY configuration], [03-openclaw switching model], [04-OpenClaw prompt words], [05-AI voice interaction configuration], [06-Three dialogue scheme configuration tests] in the Preparation before use directory. If you are currently only using TUI/WhatsApp, you can skip 05 first. This article assumes that the basic environment has been prepared and only the AI ​​weather station project itself will be launched.

1. Tutorial Objectives

This article demonstrates the capabilities of OpenClaw in a desktop weather station scenario through temperature and humidity collection, information display, and AI interpretation. After completing this tutorial, readers will be able to:

  • Learn how to combine DHT, OLED and RGB to create a local AI weather station
  • Converse with OpenClaw through WhatsApp, TUI, and voice code
  • Complete four project scenarios: environment collection, AI broadcast, weather card, status warning

2. Hardware preparation

  • OpenClaw main control board
  • DHT temperature and humidity sensor
  • OLED display
  • RGB light strip/RGB lamp bead module
  • [Optional] AI voice module + speaker
  • Wiring diagram

image-20260528201034862

3. Software preparation

Code entry that will be used in the tutorial

  • Temperature and humidity reading command: /home/sunrise/hardware_hal_demo/dht
  • OLED control command: /home/sunrise/hardware_hal_demo/oled
  • RGB control command: /home/sunrise/hardware_hal_demo/rgb
  • Voice entrance: /home/sunrise/voice_to_openclaw/src/main.py
  • Terminal text entry: /home/sunrise/voice_to_openclaw/src/text_main.py

The current focus of this set of tutorials is on the "local environmental weather station", which is based on DHT's indoor temperature and humidity data for display and explanation;

4. Test the basic capabilities of the project

Before starting the current project, please complete a basic dialogue self-test of openclaw tui; if you have not done so yet, please read [06-Three dialogue scheme configuration tests] first. After passing, enter the AI ​​weather station special test.

It is recommended to enter OpenClaw TUI first:

openclaw tui
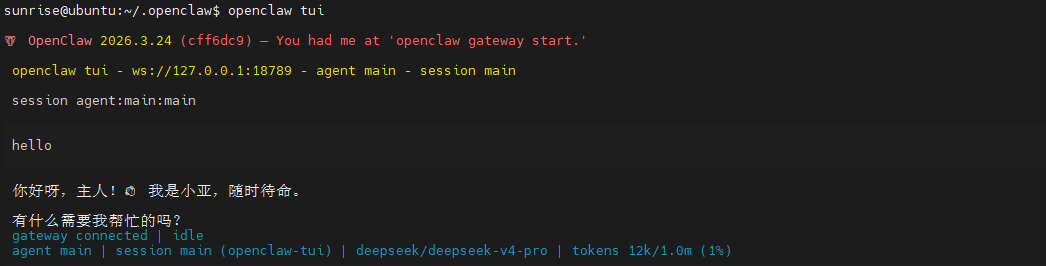
image-20260527164855215

Then test the following types of instructions in sequence:

  • Read current temperature and humidity
  • Display weather cards on OLED
  • If the environment is normal, the green light will turn on
  • Give me a brief environmental announcement

5. Three options for talking to OpenClaw

SolutionSuitable scenarioAdvantagesSuggested positioning
WhatsAppRemote viewing of the environment, classroom demonstrationsSuitable for remotely asking "How is the current environment?"Showing the "Remote Weather Station Assistant"
TUILocal debugging, threshold verificationThe easiest way to troubleshoot sensors and display logicRun through the collection link first
Voice codeVoice broadcast, desktop assistantCloser to daily use experienceAs the final demonstration solution

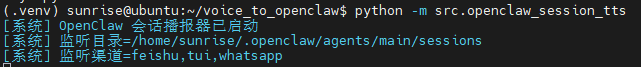
If the AI voice module + speaker is optional, Feishu dialogue, tui, and WhatsApp dialogue need to broadcast the content of openclaw's reply. You can run the following program on the terminal. The AI voice module dialogue does not need to be run repeatedly

  • Modify whether to open broadcast parameters
xxxxxxxxxx
/home/sunrise/voice_to_openclaw/.env
xxxxxxxxxx
ENABLE_TTS=true #This parameter is to control whether to broadcast. After modification, save it and run the following program on the terminal.
  • Terminal input
xxxxxxxxxx
cd ~/voice_to_openclaw
source .venv/bin/activate
python -m src.openclaw_session_tts

image-20260527162942497

5.1 WhatsApp solution

For WhatsApp access and robot creation steps, please refer directly to [06-Configuration Test of Three Dialogue Schemes]. After it is created, you can remotely view the environment status on WhatsApp, for example:

  • How is the indoor environment now? If it’s too hot, remind me.
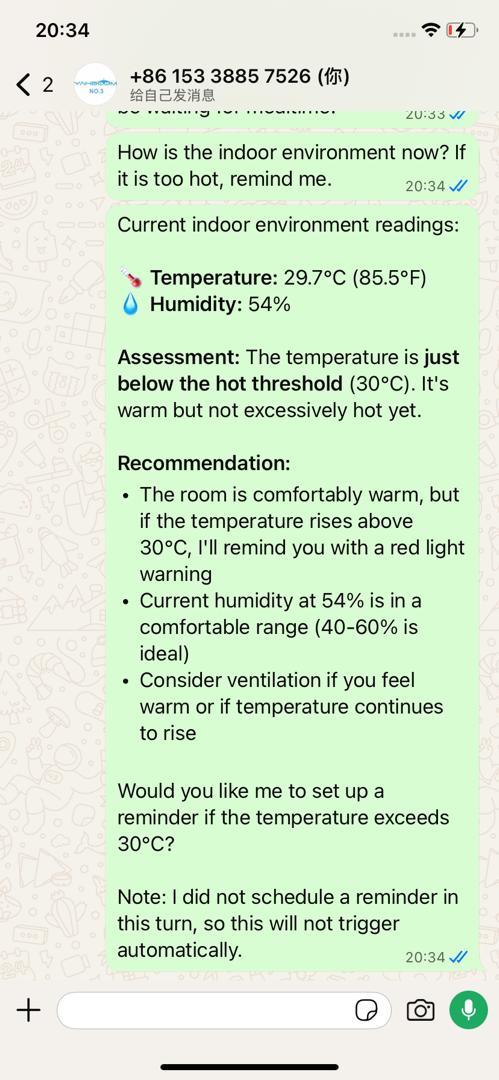
image-20260428182154957

5.2 TUI scheme

If you have completed the TUI self-test in Part 0, enter the terminal text dialogue directly:

xxxxxxxxxx
openclaw tui

Then enter project-related instructions, such as:

  • Get the current weather in Beijing and display it on OLED
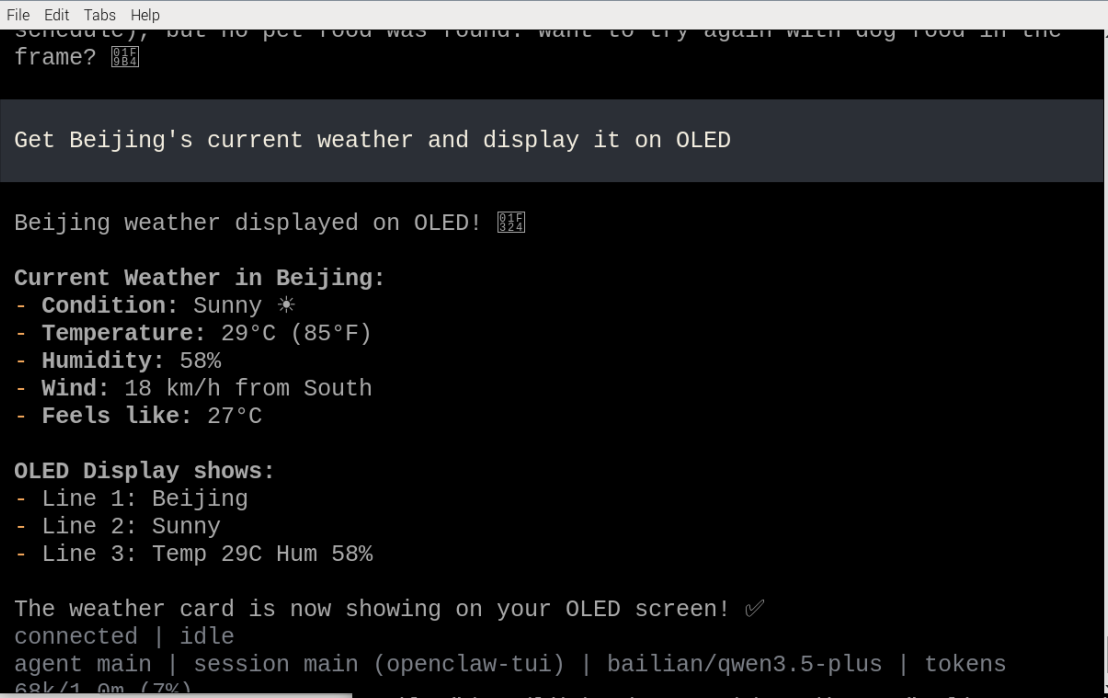
image-20260428182328574

5.3 Voice code scheme

xxxxxxxxxx
Requires optional ai voice interaction module + speaker

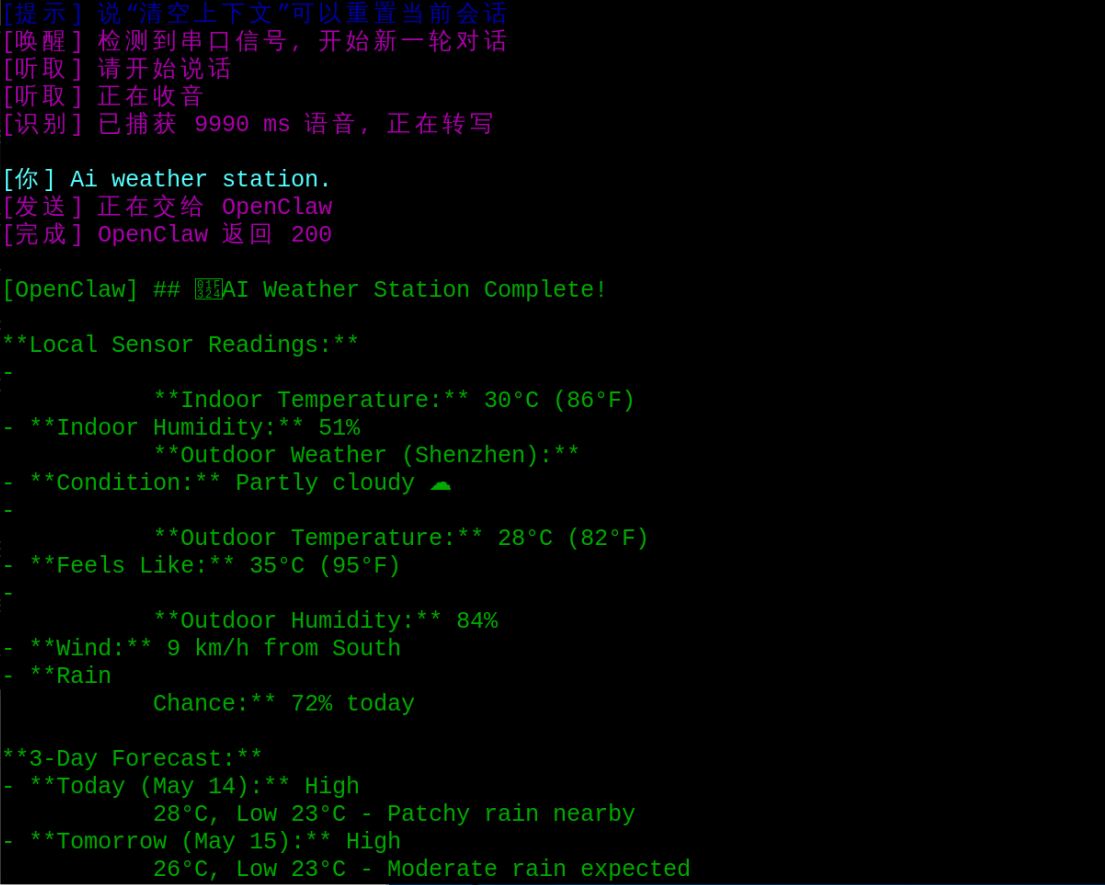
For voice module installation, environment configuration and basic wake-up process, please refer directly to [05-AI Voice Interaction Configuration]. After waking up, you can directly say the control content, such as:

  • ai weather station

image-20260428182423610

6. Project implementation

Note: The following are all dialogue demonstrations in openclaw tui mode. You can also choose WhatsApp or voice mode to complete it.

6.1 Scenario 1: Environment collection

Experimental goals

Read the temperature and humidity of the local environment to complete the most basic data sampling of the weather station.

Effect description

OpenClaw will call DHT to obtain the current environmental data and return the results to the user to form a real-time "weather reading" of the indoor environment.

Example instructions

  • Read the current ambient temperature and humidity
  • What is the indoor temperature and humidity now?
  • Help me check the current weather data

6.2 Scenario 2: AI broadcast

Experimental goals

Let OpenClaw not only report numbers, but also summarize the state of the environment like a weather announcer.

Effect description

OpenClaw can summarize "26 degrees, 57% humidity" into more natural words, such as "the environment is more comfortable", "a bit stuffy", "the air is slightly dry", etc.

Example instructions

  • Give me a brief environmental announcement
  • Is the environment comfortable now?
  • Make a weather summary based on current readings

6.3 Scenario 3: OLED weather card

Experimental goals

Display the local temperature and humidity results as a page more like a "weather card".

Effect description

In addition to text-only results, OLED can also arrange location, status, temperature and humidity into a concise card, making the entire project more like a displayable desktop device.

Example instructions

  • Display an indoor weather card on OLED
  • Get the current weather in xx place and display it on OLED

6.4 Scenario 4: RGB status warning

Experimental goals

Use RGB colors to quickly express the current environment status.

Effect description

For example, it lights up green when the environment is comfortable, yellow when it is hot, and red when it is abnormal. In this way, even without reading the text, you can quickly know the current state of the environment.

Example instructions

  • If the environment is normal, the green light will turn on
  • If the temperature is high, the yellow light will turn on
  • If there is an abnormality, the red light will flash.
AI Pet
Temperature and Humidity Dashboard

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文