yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
RDK X5 Robot📖
01. RDK-X5-Robot Introduction
  • 1.Introduction
  • 2.Common Problem Analysis
  • 3.Battery and charger usage precautions
  • 4.TF card expand capacity
02. Assembly Tutorial
  • Assembly Tutorial
  • Assembly Video-1
  • Assembly Video-2
  • Assembly Video-3
  • Assembly Video-4
03. Remote Control Course
  • 1.Mobile APP remote control
  • 2.USB Wireless Controller Remote Control
04. ROS Driver Board Course
  • 1. Introduction of extension board
  • 2. Set up STM32 development environment
  • 3. Key control buzzer sound
  • 4. FreeRTOS application
  • 5. Serial communication
  • 6. SBUS model remote control
  • 7. CAN bus communication
  • 8. RGB color light strip
  • 9. Timer interrupt control PWM servo
  • 10. Control serial steering gear
  • 11. Nine-axis attitude sensor to obtain data
  • 12. Control motor forward and reverse
  • 13. The timer captures encoder data
  • 14. Theory of robot kinematics analysis
  • 15. PID control robot motion
05. Basic Control Course
  • 1.Update expansion board firmware
  • 2.Install Python driver library
  • 3.Set the car type
  • 4.Open and close APP program control
  • 5.Turn hotspot mode on and off
  • 6.Buzzer sound
  • 7.Control the motor to rotate forward and reverse
  • 8.Controlling robot movement
  • 9.OLED display
  • 10.Control fans and lighting effects
06. Development Environment
  • 1. Virtual machine installation and use
  • 2. Linux Basics
  • 3. Remote connection
  • 4. Multi-machine communication configuration
  • 5. Bind device ID
  • 6. Image installation and backup
07. ROS2 Basic Course
  • 1. Introduction to ROS2
  • 2. ROS2 install Humble
  • 3. ROS2 development environment
  • 4. ROS2 workspace
  • 5. ROS2 function package
  • 6. ROS2 node
  • 7. ROS2 topic communication
  • 8. ROS2 service communication
  • 9. ROS2 action communication
  • 10. ROS2 custom interface message
  • 11. ROS2 parameter service case
  • 12. ROS2 meta-function package
  • 13. ROS2 distributed communication
  • 14. ROS2 DDS
  • 15. ROS2 time related API
  • 16. ROS2 common command tools
  • 17. ROS2 rviz2 use
  • 18. ROS2 rqt toolbox
  • 19. ROS2 Launch startup file configuration
  • 20. ROS2 recording and playback tool
  • 21. ROS2 URDF model
  • 22. ROS2 Gazebo simulation platform
  • 23. ROS2 TF2 coordinate transformation
08. Robot Chassis Control Course
  • 1. PID algorithm theory
  • 2. Robot information release
  • 3. Robot control
  • 4. Robot state estimation
  • 5. Robot calibration
  • 6. Robot trajectory tracking
  • 7. URDF Model
09. LiDAR Course
  • 1. Introduction and use of lidar
  • 2. Lidar obstacle avoidance
  • 3. Lidar tracking
  • 4. Lidar guard
  • 5. Lidar patrol
  • 6. gmapping mapping algorithm
  • 7. Cartographer mapping algorithm
  • 8. Navigation and obstacle avoidance
  • 9. App Mapping and Navigation
10. OpenCV Course
  • 1. Getting started with OpenCV
  • 2. OpenCV geometric transformation
  • 3. OpenCV Image Processing
  • 4. OpenCV image beautification
  • 5. QR code creation and recognition
11. Mipi Camera Course
  • 1. Camera driver
  • 2. Adjust the color HSV value
  • 3. Color recognition
  • 4. Color Tracking
  • 5. Color Follow
  • 6. QR code instructions
  • 7. Face Detection
  • 8. Object Detection
  • 9. Visual line patrol-OpenCV
  • 10. Visual line patrol-deep learning
  • 11. Human body tracking
  • 12. Gesture control
12. Depth Camera Course
  • 1. Use of Depth Camera
  • 2. Camera intrinsic calibration
  • 3. ROS+OpenCV Basics
  • 4. AR Vision
  • 5. Color Tracking
  • 6. Object Tracking
  • 7. RTAB-Map 3D Mapping Navigation
13. Multi-robot Synchronous Control
  • Multi-vehicle synchronous control
Remote login control
  • 1. VNC and SSH remote login
  • 2. Jupyter lab login and case code running
Download
  • System_File
  • Code
  • VM_File
  • Software_Tools
  • Hardware_Info
  • Firmware
  • Instruction_Manual
  • ROS2_Basic_VM
Download ZIP

Welcome to RDK X5 Robot repository

6. Image installation and backup

Image installation and backup

Image installation and backup6.1. Burn the SD card image6.2 Disk expansion6.3, backup SD card image6.2.1 Compress disk space6.2.2 View disk information6.2.3 Start disk backup

Note: The TF card of the RDK X5 robot has been burned with the image at the factory. You can directly insert the TF card into the robot for use. Generally, you do not need to burn the image system according to this tutorial! ! !

6.1. Burn the SD card image

Preparation: Windows 10/11 system computer, card reader, TF card (64G or larger recommended), factory image compressed package file.

Steps:

  1. Unzip the downloaded system compressed file to get the img image file;
  2. Insert the TF card into the card reader, and then insert the card reader into the computer USB port;
  3. Format the SD card to exfat format disk;
  4. Start the image burning software, here use the Win32DiskImager tool;
  5. Confirm the SD card device number and select the system image to be burned;
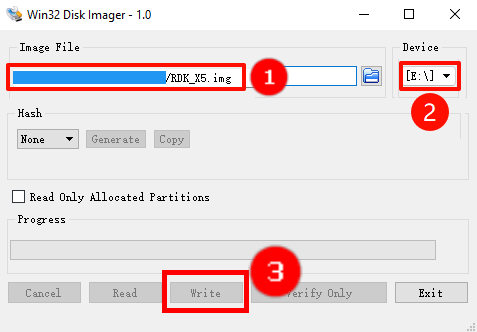
image-20241203120942413

  1. Wait for the image writing to complete;
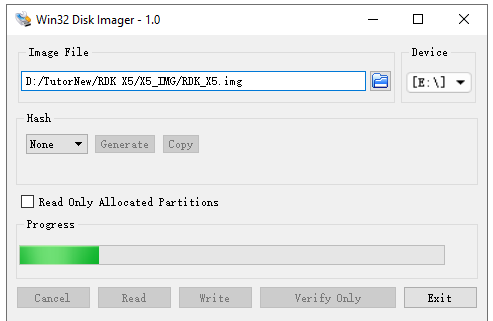
image-20241203121339904

  1. The progress bar will show the current burning progress. After the burning is completed, you can exit the software.
  1. Eject the disk

6.2 Disk expansion

Insert the SD card into the RDK X5 motherboard slot and wait for the system to start.

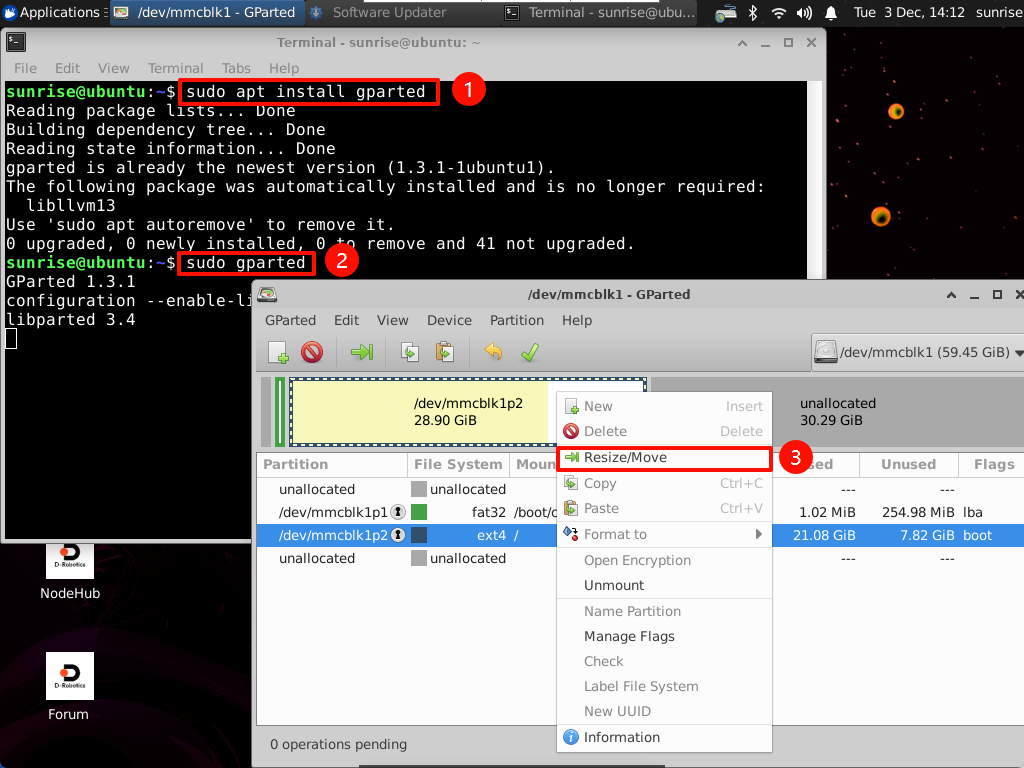
Install and run the GParted software on the system:

sudo apt install gparted #Install
sudo gparted #Run

image-20241203141259190

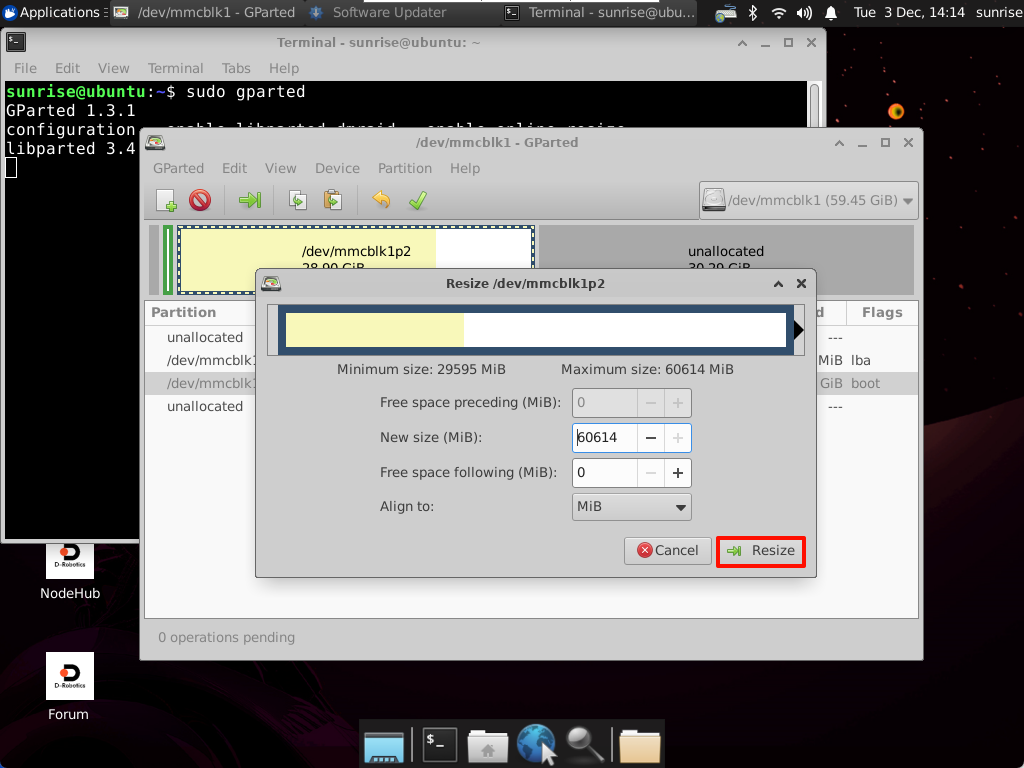
Drag the slider to change the disk space capacity:
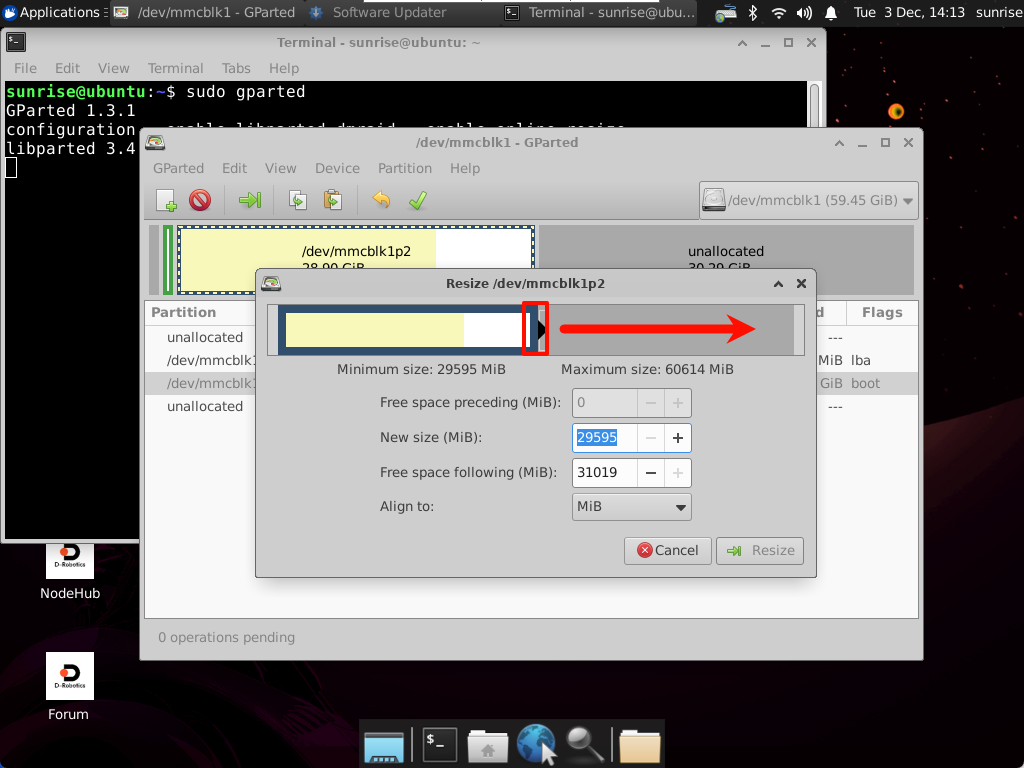
image-20241203141429300

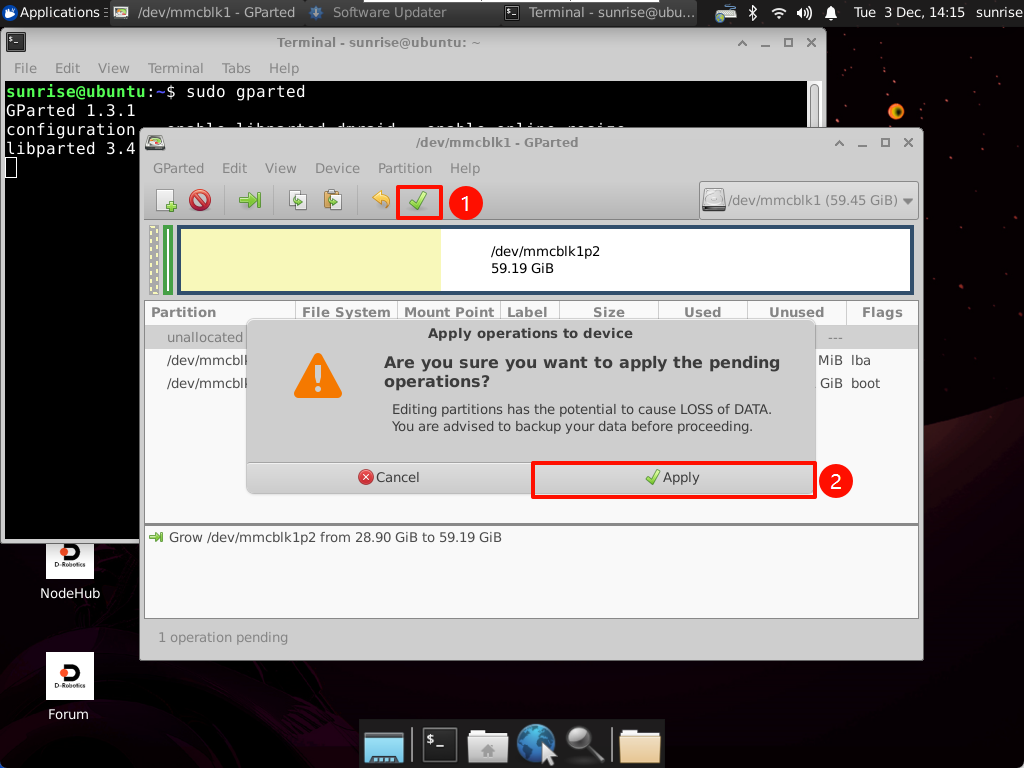
image-2024120314145267 5

image-20241203141526976

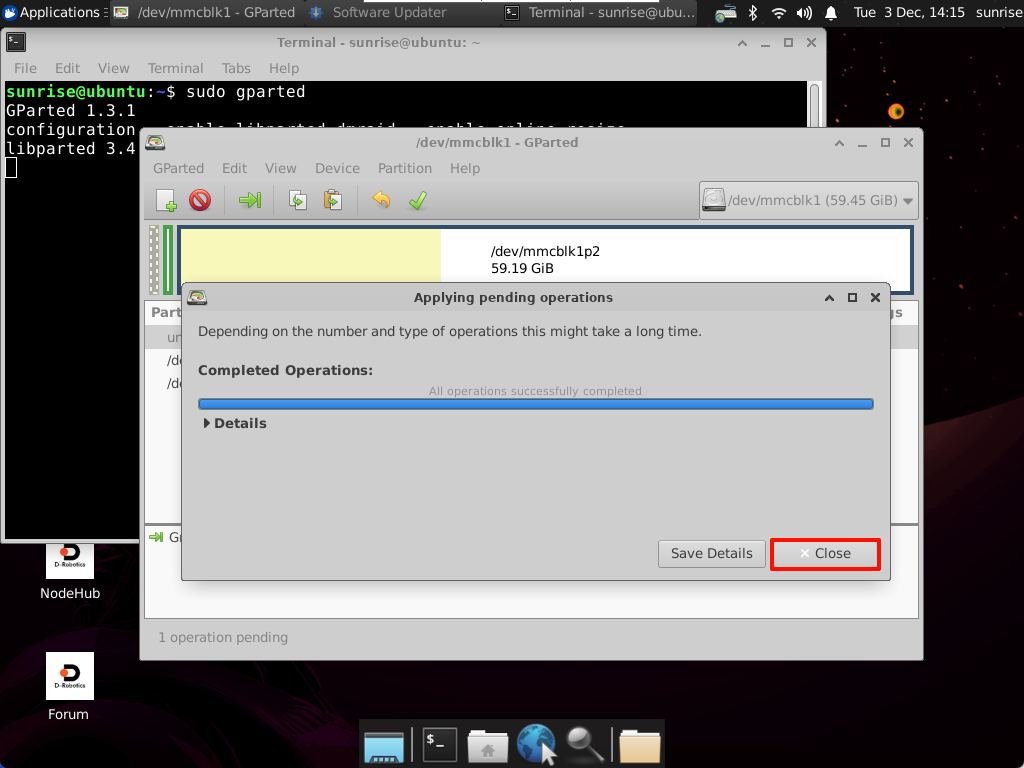
image-20241203141545812

After completing all operations, close the software!

6.3, backup SD card image

6.2.1 Compress disk space

Before backing up the image, use gparted software to compress the disk space of the SD card to reduce the image size.

Install and start gparted software in the virtual machine:

xxxxxxxxxx
sudo apt install gparted #Install
sudo gparted #Run

Insert the SD card into the running computer through the card reader and connect it to the virtual machine. In the opened gparted software, select the SD card in the upper right corner:
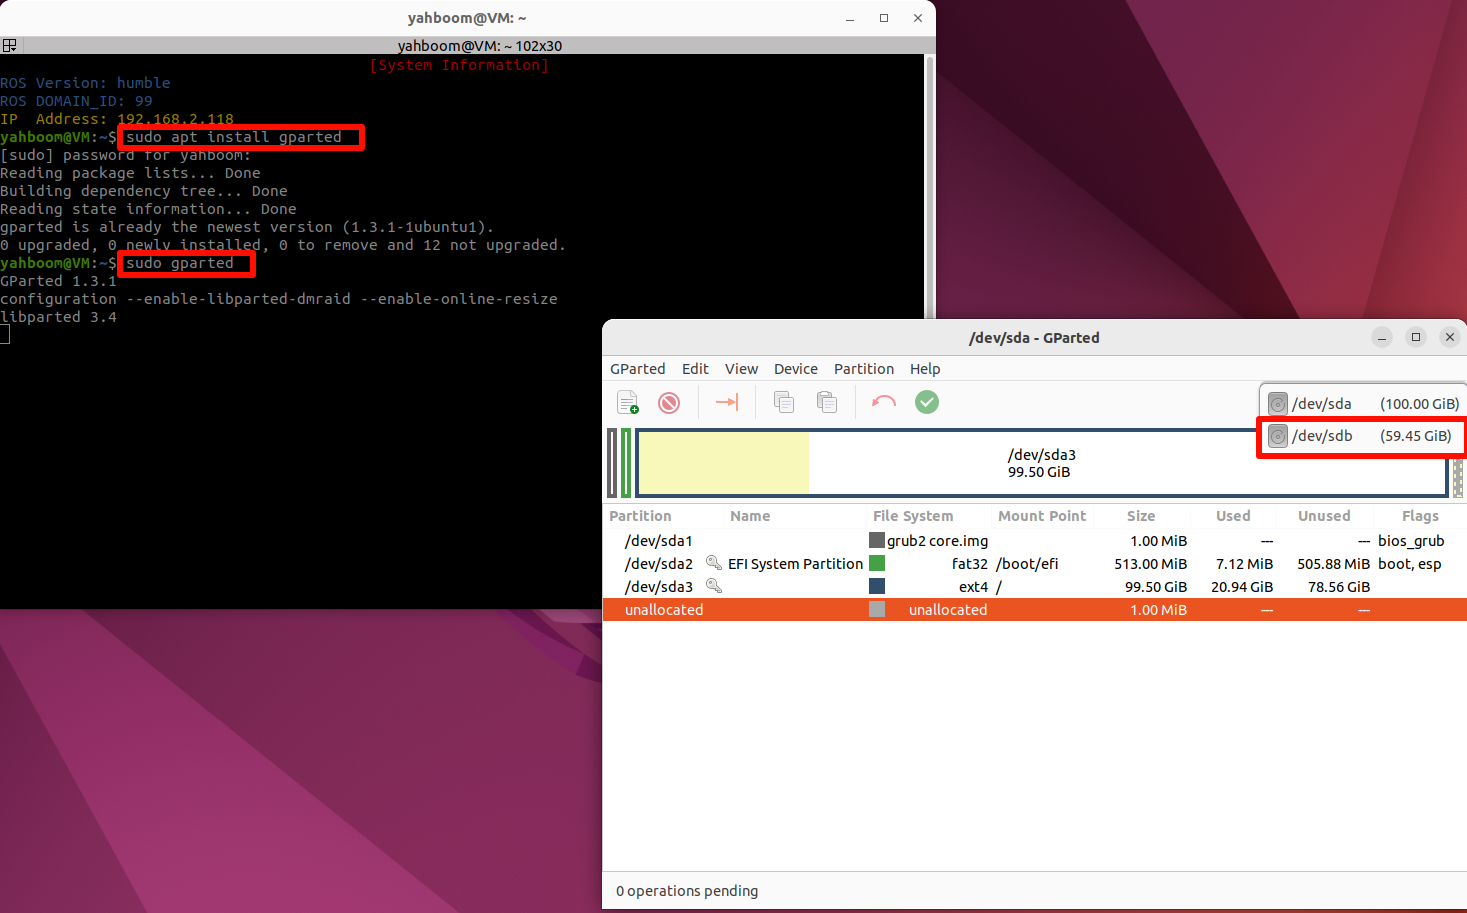
image-20241203180604652

Then right-click and select to uninstall the SD card mount:
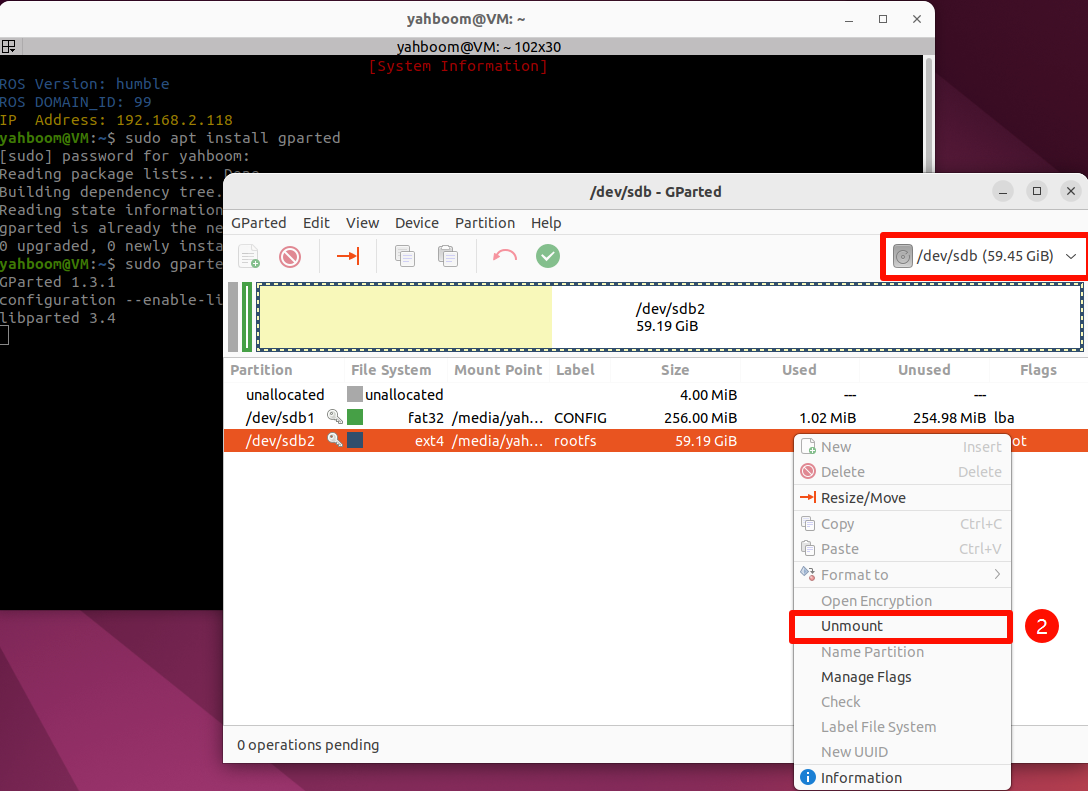
image-20241203180714583

Continue to right-click and select the "Resize/Moves" option to reset the space size of the SD card:
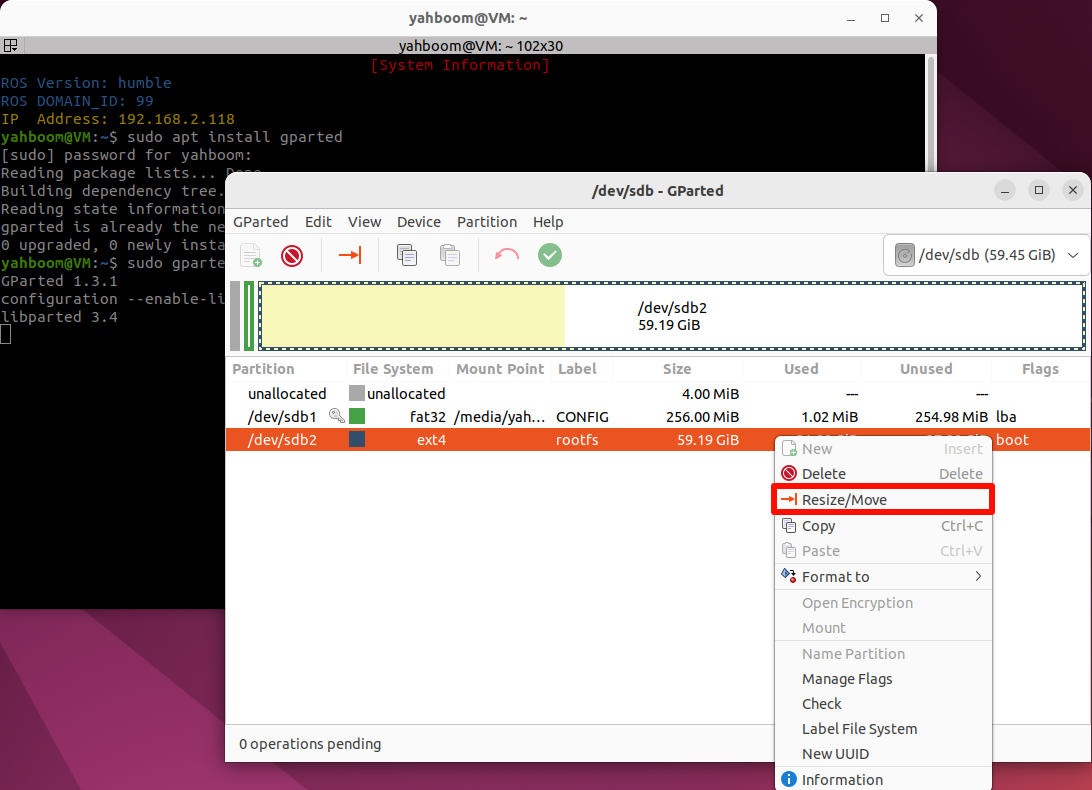
image-20241203180750444

Drag the right side of the space division bar to compress the space. The yellow one is the occupied partition and the white one is the free partition. Be careful to keep a little white free partition to prevent the image from failing to start.
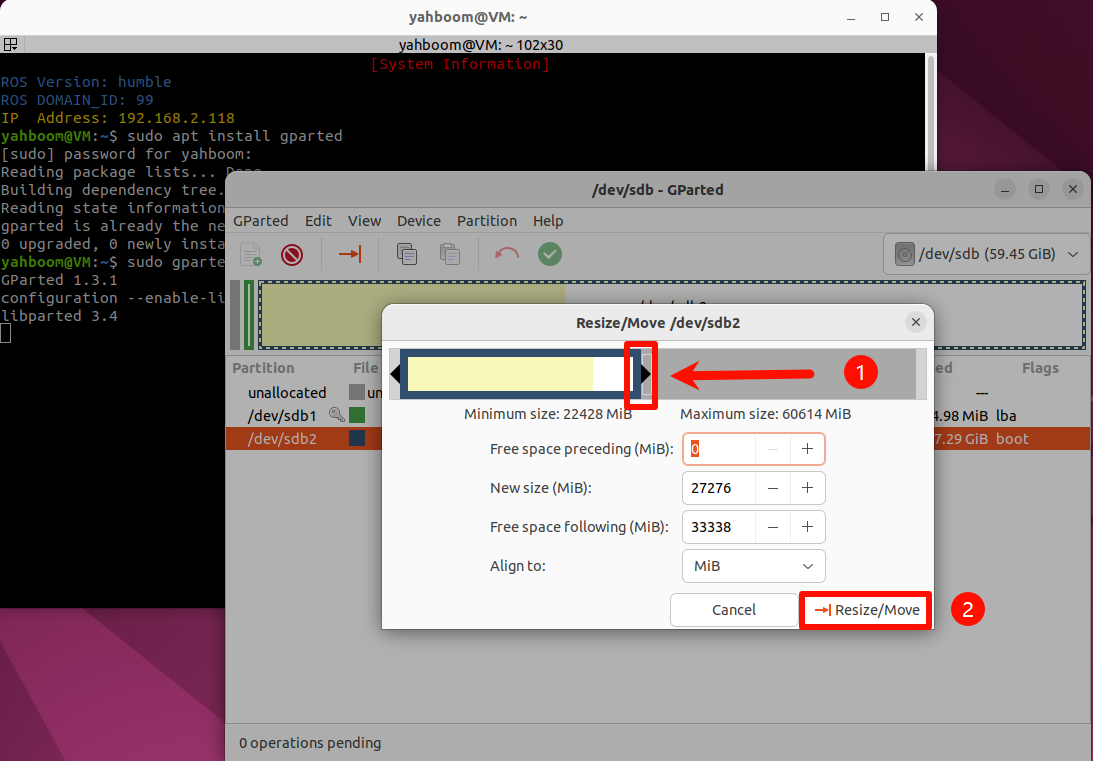
image-20241203180933381

After confirmation, click the execute button in the software to start the compression operation.
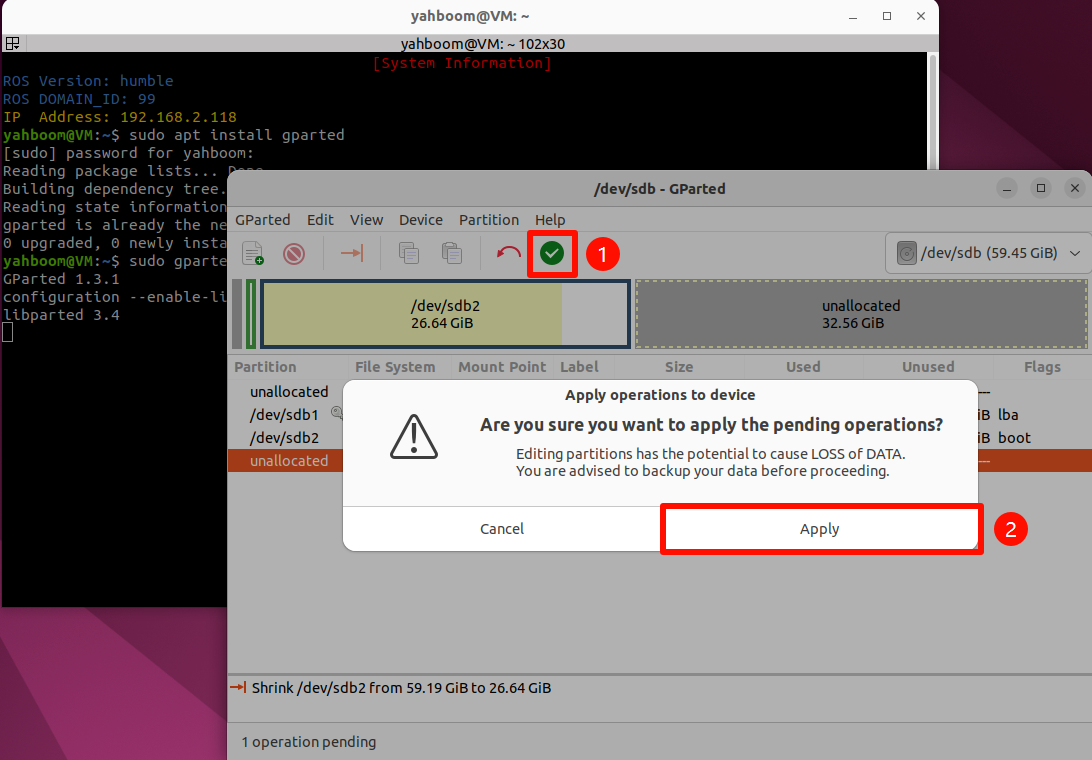
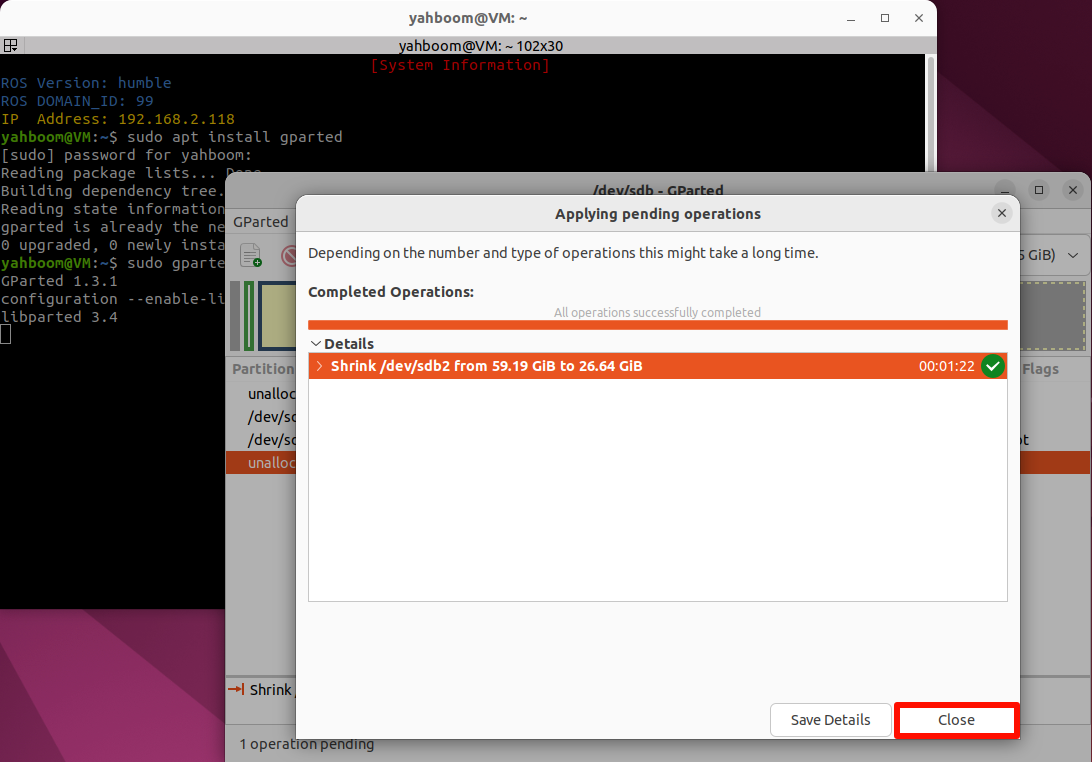
image-20241203181039619

image-20241203181322297

After the compression is completed, you can close the gparted software.

6.2.2 View disk information

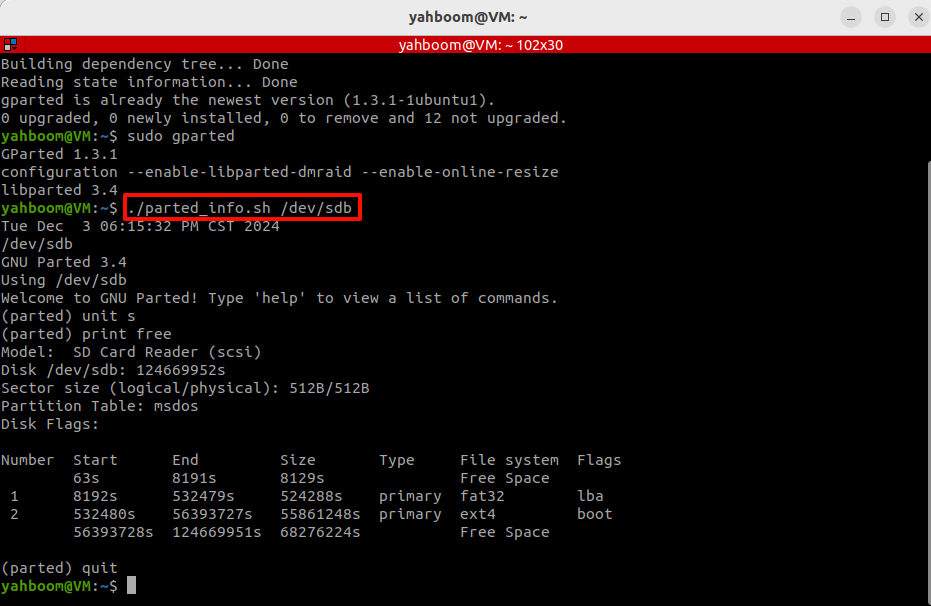
Open the terminal and use the script to view the current disk status:

xxxxxxxxxx
./parted_info.sh /dev/sdb

parted_info.sh script content

xxxxxxxxxx
#!/bin/bash
date
echo $1
sudo parted $1 <<EOF
unit s
print free
quit
EOF

image-20241203181628214

/dev/sdb in the figure is the disk number of the SD card, record this data in the figure: 56393728
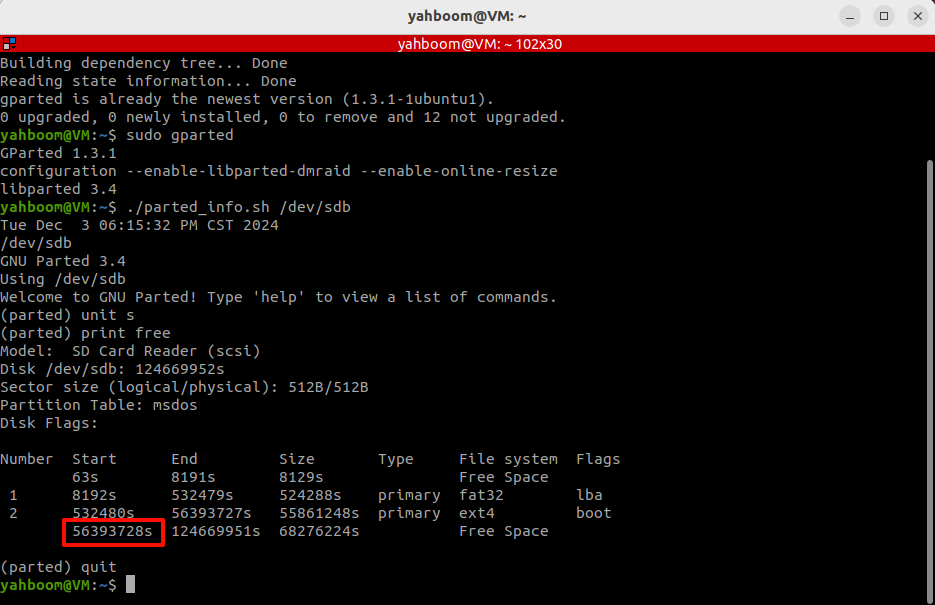
image-20241203181724766

6.2.3 Start disk backup

Use the dd command to back up the SD card to the img file. Enter the following in the terminal:

xxxxxxxxxx
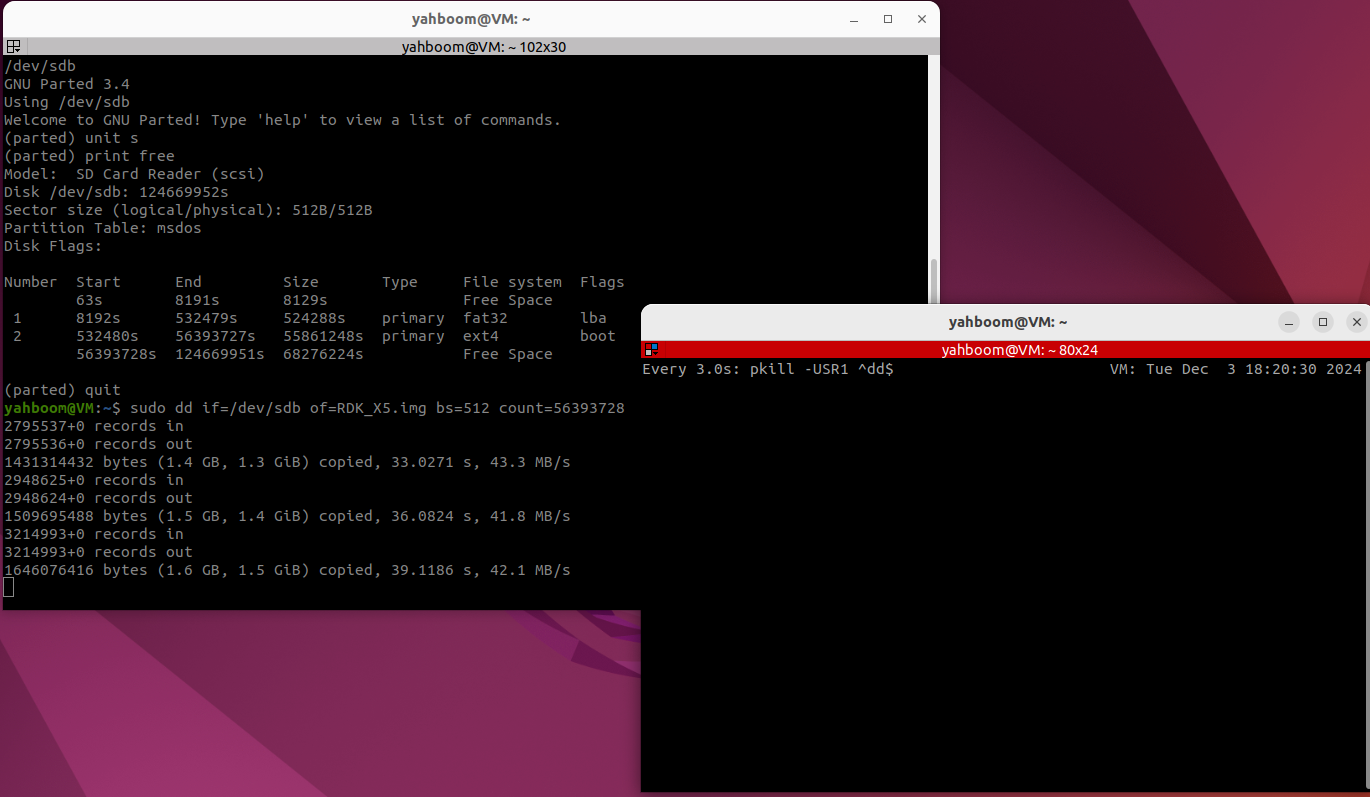
sudo dd if=/dev/sdb of=RDK_X5.img bs=512 count=56393728

where if=/dev/sdb is the disk device number queried in the first step, of=RDK_X5.img is the name of the backup, bs=512 indicates the block size,

count=56393728 indicates the backup size, and this data is obtained from the above steps.

At this time, there is no prompt information in the terminal. Reopen a terminal and run the following command to check the progress.

xxxxxxxxxx
sudo watch -n 3 pkill -USR1 ^dd$

image-20241203182048066

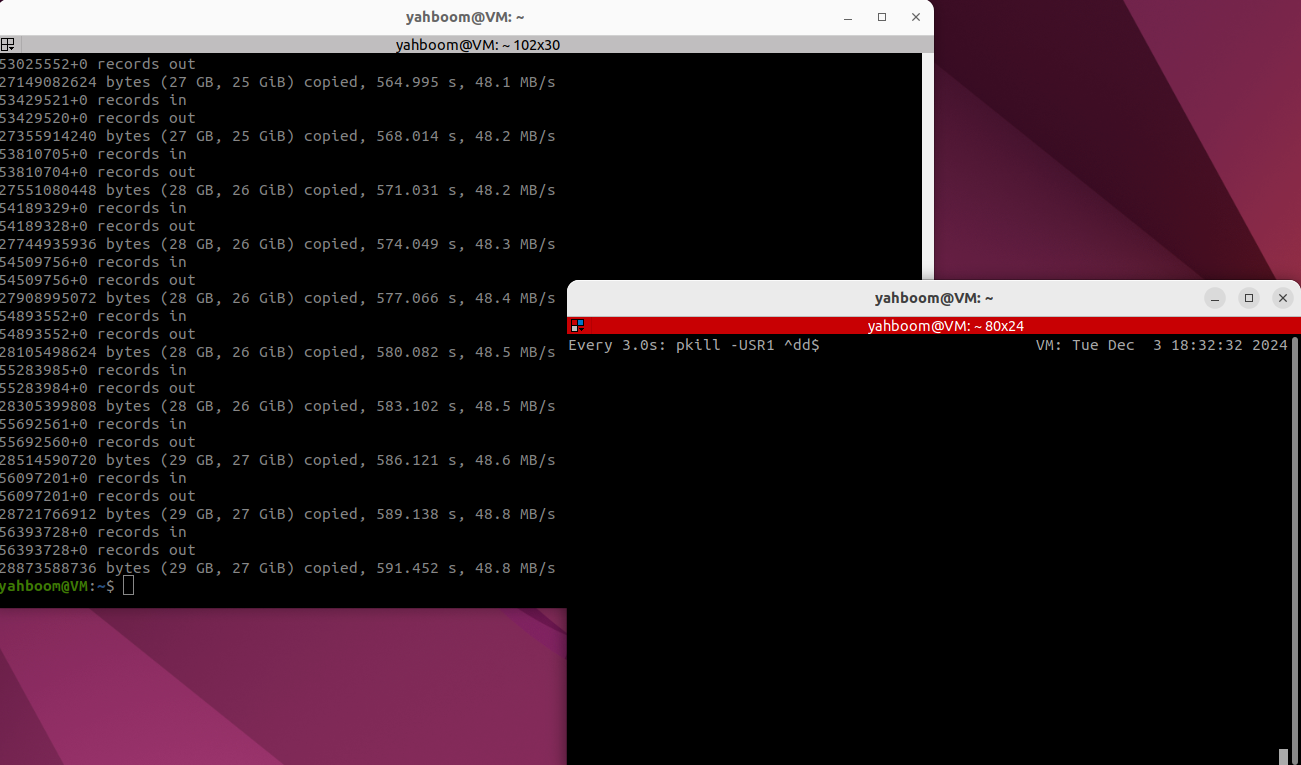
Wait for the backup to complete!

image-20241203183250091

The above is the image burning and backup process!

Bind device ID
Introduction to ROS2

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文