yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
RDK X5 Robot📖
01. RDK-X5-Robot Introduction
  • 1.Introduction
  • 2.Common Problem Analysis
  • 3.Battery and charger usage precautions
  • 4.TF card expand capacity
02. Assembly Tutorial
  • Assembly Tutorial
  • Assembly Video-1
  • Assembly Video-2
  • Assembly Video-3
  • Assembly Video-4
03. Remote Control Course
  • 1.Mobile APP remote control
  • 2.USB Wireless Controller Remote Control
04. ROS Driver Board Course
  • 1. Introduction of extension board
  • 2. Set up STM32 development environment
  • 3. Key control buzzer sound
  • 4. FreeRTOS application
  • 5. Serial communication
  • 6. SBUS model remote control
  • 7. CAN bus communication
  • 8. RGB color light strip
  • 9. Timer interrupt control PWM servo
  • 10. Control serial steering gear
  • 11. Nine-axis attitude sensor to obtain data
  • 12. Control motor forward and reverse
  • 13. The timer captures encoder data
  • 14. Theory of robot kinematics analysis
  • 15. PID control robot motion
05. Basic Control Course
  • 1.Update expansion board firmware
  • 2.Install Python driver library
  • 3.Set the car type
  • 4.Open and close APP program control
  • 5.Turn hotspot mode on and off
  • 6.Buzzer sound
  • 7.Control the motor to rotate forward and reverse
  • 8.Controlling robot movement
  • 9.OLED display
  • 10.Control fans and lighting effects
06. Development Environment
  • 1. Virtual machine installation and use
  • 2. Linux Basics
  • 3. Remote connection
  • 4. Multi-machine communication configuration
  • 5. Bind device ID
  • 6. Image installation and backup
07. ROS2 Basic Course
  • 1. Introduction to ROS2
  • 2. ROS2 install Humble
  • 3. ROS2 development environment
  • 4. ROS2 workspace
  • 5. ROS2 function package
  • 6. ROS2 node
  • 7. ROS2 topic communication
  • 8. ROS2 service communication
  • 9. ROS2 action communication
  • 10. ROS2 custom interface message
  • 11. ROS2 parameter service case
  • 12. ROS2 meta-function package
  • 13. ROS2 distributed communication
  • 14. ROS2 DDS
  • 15. ROS2 time related API
  • 16. ROS2 common command tools
  • 17. ROS2 rviz2 use
  • 18. ROS2 rqt toolbox
  • 19. ROS2 Launch startup file configuration
  • 20. ROS2 recording and playback tool
  • 21. ROS2 URDF model
  • 22. ROS2 Gazebo simulation platform
  • 23. ROS2 TF2 coordinate transformation
08. Robot Chassis Control Course
  • 1. PID algorithm theory
  • 2. Robot information release
  • 3. Robot control
  • 4. Robot state estimation
  • 5. Robot calibration
  • 6. Robot trajectory tracking
  • 7. URDF Model
09. LiDAR Course
  • 1. Introduction and use of lidar
  • 2. Lidar obstacle avoidance
  • 3. Lidar tracking
  • 4. Lidar guard
  • 5. Lidar patrol
  • 6. gmapping mapping algorithm
  • 7. Cartographer mapping algorithm
  • 8. Navigation and obstacle avoidance
  • 9. App Mapping and Navigation
10. OpenCV Course
  • 1. Getting started with OpenCV
  • 2. OpenCV geometric transformation
  • 3. OpenCV Image Processing
  • 4. OpenCV image beautification
  • 5. QR code creation and recognition
11. Mipi Camera Course
  • 1. Camera driver
  • 2. Adjust the color HSV value
  • 3. Color recognition
  • 4. Color Tracking
  • 5. Color Follow
  • 6. QR code instructions
  • 7. Face Detection
  • 8. Object Detection
  • 9. Visual line patrol-OpenCV
  • 10. Visual line patrol-deep learning
  • 11. Human body tracking
  • 12. Gesture control
12. Depth Camera Course
  • 1. Use of Depth Camera
  • 2. Camera intrinsic calibration
  • 3. ROS+OpenCV Basics
  • 4. AR Vision
  • 5. Color Tracking
  • 6. Object Tracking
  • 7. RTAB-Map 3D Mapping Navigation
13. Multi-robot Synchronous Control
  • Multi-vehicle synchronous control
Remote login control
  • 1. VNC and SSH remote login
  • 2. Jupyter lab login and case code running
Download
  • System_File
  • Code
  • VM_File
  • Software_Tools
  • Hardware_Info
  • Firmware
  • Instruction_Manual
  • ROS2_Basic_VM
Download ZIP

Welcome to RDK X5 Robot repository

20. ROS2 recording and playback tool

20. ROS2 Recording and Playback Tool

1. Introduction to Recording and Playback Tools

Bag2, a commonly used recording and playback tool in ROS2, is used to record topic data. We can use this command to store topic data as a file. Later, we can directly publish the topic data in the bag file without starting a node.

This tool is very useful when developing a real robot. For example, we can record topic data when the robot encounters a problem. After recording, we can publish it multiple times for testing and experimentation, or share the topic data with others to verify algorithms.

We will try using the bag tool to record topic data and replay it.

2. Usage Tutorial

2.1. Start the topic node to record

For example, the talker in the ros2 demo:

xxxxxxxxxx
ros2 run demo_nodes_py talker

2.2. Recording

/topic-name is the topic name

xxxxxxxxxx
# Record a single topic
ros2 bag record /topic-name
# Record multiple topics
ros2 bag record topic-name1 topic-name2
# Record all topics
ros2 bag record -a

Other Options

-o name Customize the output file name

xxxxxxxxxx
ros2 bag record -o file-name topic-name

-s Storage format

Currently only supports sqllite3; others are available with extensions.

2.3. Viewing Recorded Topic Information

Before playing a video, you can view relevant information about the video through the file information, such as the time, size, type, and number of topic records.

xxxxxxxxxx
# Assume the recorded file is rosbag2_2023_10_31-07_58_23
ros2 bag info rosbag2_2023_10_31-07_58_23

2.4. Play and View

2.4.1. Play

Next, we can replay the data using the following command.

xxxxxxxxxx
ros2 bag play rosbag2_2023_10_31-07_58_23

2.4.2. View

Use the ros2 topic command to view the data.

xxxxxxxxxx
ros2 topic echo /chatter

2.4.3. Playback Options

  1. Play at Multiple Speeds -r

The -r option modifies the playback speed. For example, the -r value, for example, 10 means 10x speed, playing the topic ten times faster.

xxxxxxxxxx
ros2 bag play rosbag2_2023_10_31-07_58_23 -r 10
  1. Loop Playback -l

This is for looping a single song.

xxxxxxxxxx
ros2 bag play rosbag2_2023_10_31-07_58_23 -l
  1. Play a Single Topic
xxxxxxxxxx
ros2 bag play rosbag2_2023_10_31-07_58_23 --topics /chatter

3. Example

3.1. Running the talker node

xxxxxxxxxx
ros2 run demo_nodes_py talker

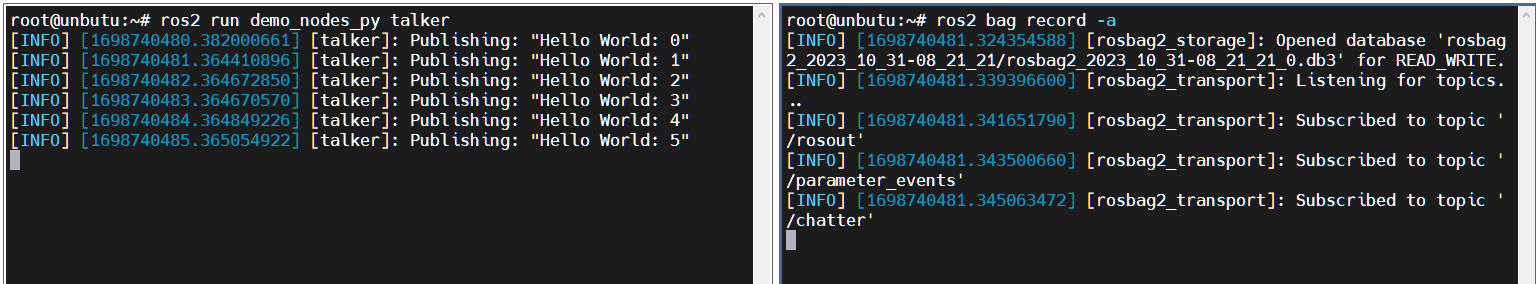
3.2. Recording

xxxxxxxxxx
# Record all topics
ros2 bag record -a

image-20231031162153843

How do I stop recording? Simply press Ctrl+C in the terminal to interrupt the recording.

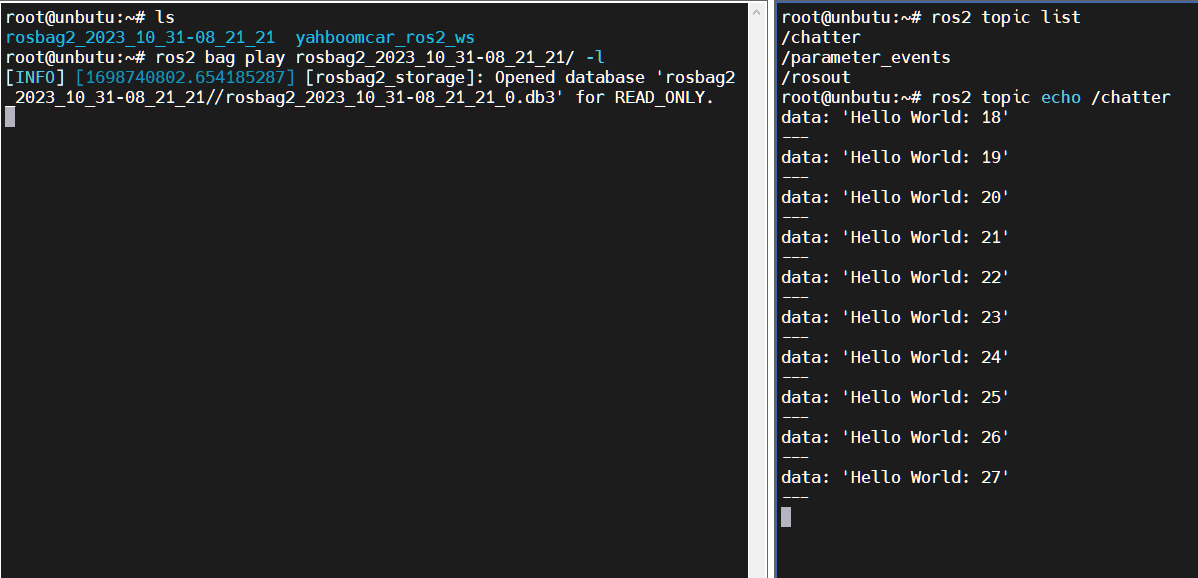
You will then find a folder named rosbag2_2023_10_31-08_21_21 in the terminal.

Open the folder to see its contents.
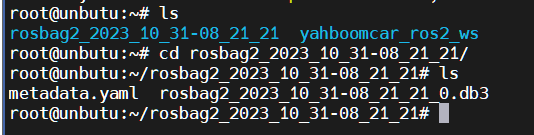
image-20231031162443246

This completes the recording.

3.3. Play and View

Here we loop the playback.

xxxxxxxxxx
ros2 bag play rosbag2_2023_10_31-07_58_23 -l

Open another terminal to view the topic:

xxxxxxxxxx
ros2 topic echo /chatter

image-20231031162719003

ROS2 Launch startup file configuration
ROS2 URDF model

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文