yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
RDK X3 Robot📖
01. About RDK-X3-Robot
1. Instructions
  • 1. Introduction
  • 2. FAQ
  • 3. Battery and charger use precautions
  • 4.TF card expand capacity
2. Common problem analysis
02. Assembly video
  • Part1-Install Motor
  • Part2-Install Battert Fixing Column
  • Part3-Install Motor Coupling
  • Part4-Install Mecanum wheel
  • Part5-Install Expansion Board
  • Part6-Wiring Show
  • Part7-Install Main Control Board
  • Part8-Install Car Top Plate and Antenna
  • Part9-Install OLED Screen
  • Part10-Install Depth Camera(Optional)
  • Part11-Install OLED Screen
  • Part12-Install HD Camera
  • Part13-Install Top Plate
  • Part14-Install Right Side Plate
  • Part15-Motor Wiring Show
  • Part16-lnstall Car Body
  • Part17-Install Battery
  • Part18-Install Lidar
03. Remote control tutorial
  • 1. The phone APP remote tutorial
  • 2. USB wireless controller remote tutorial
04. ROS functional tutorial
  • 1. Introduction of extension board
  • 2. Set up STM32 development environment
  • 3. Key control buzzer sound
  • 4. FreeRTOS application
  • 5. Serial communication
  • 6. SBUS model remote control
  • 7. CAN bus communication
  • 8. RGB color light strip
  • 9. Timer interrupt control PWM servo
  • 10. Control serial steering gear
  • 11. Nine-axis attitude sensor to obtain data
  • 12. Control motor forward and reverse
  • 13. The timer captures encoder data
  • 14. Theory of robot kinematics analysis
  • 15. PID control robot motion
05. Basic control tutorial
  • 1. Update the firmware of the expansion module
  • 2. Install the Python driver library
  • 3. Set the type of bottom car
  • 4. Open and close the APP program control
  • 5. Turn hotspot mode on and off
  • 6. The buzzer blows
  • 7. Control the motor forward and reverse
  • 8. Control robot movement
  • 9. OLED display
  • 10. Control fan and lamp effect
06. Development environment setup
  • 1. Virtual Machine
  • 2. Linux Basics
  • 3. Remote connection
  • 4. Multi-computer communication configuration
  • 5. Bind the device ID
  • 6. Image installation and backup
07. ROS2 Basic Course
  • 1. Introduction to ROS2
  • 2. ROS2 install Humble
  • 3. ROS2 development environment
  • 4. ROS2 workspace
  • 5. ROS2 function package
  • 6. ROS2 node
  • 7. ROS2 topic communication
  • 8. ROS2 service communication
  • 9. ROS2 action communication
  • 10. ROS2 custom interface message
  • 11. ROS2 parameter service case
  • 12. ROS2 meta-function package
  • 13. ROS2 distributed communication
  • 14. ROS2 DDS
  • 15. ROS2 time related API
  • 16. ROS2 common command tools
  • 17. ROS2 rviz2 use
  • 18. ROS2 rqt toolbox
  • 19. ROS2 Launch startup file configuration
  • 20. ROS2 recording and playback tool
  • 21. ROS2 URDF model
  • 22. ROS2 Gazebo simulation platform
  • 23. ROS2 TF2 coordinate transformation
08. Robot chassis control
  • 1. PID algorithm theory
  • 2. Robot information release
  • 3. Robot control
  • 4. Robot state estimation
  • 5. Robot calibration
  • 6. Robot trajectory tracking
  • 7. URDF model
09. Lidar courses
  • 1. Introduction and use of lidar
  • 2. Lidar obstacle avoidance
  • 3. Lidar following
  • 4. Lidar guard
  • 5. Patrol
  • 6. gmapping algorithm
  • 7. cartographer algorithm
  • 8. Navigation and obstacle avoidance
  • 9. App mapping and navigation
10. OpenCV courses
  • 1. Introduction to OpenCV
  • 2. OpenCV geometric transformation
  • 3. OpenCV image processing
  • 4. OpenCV image beautification
  • 5. Qr code creation and identification
11. MIPI camera course
  • 1. Camera driver
  • 2. Adjust the color HSV value
  • 3. Color recognition
  • 4. Color tracking
  • 5. Color follow
  • 6. Qr code command
  • 7. Face detection
  • 8. Object detection
  • 9. Visual Inspection -OpenCV
  • 10. Visual inspection - Deep learning
  • 11. Human tracking
  • 12. Gesture control
12. Depth Camera courses
  • 1. Use depth camera
  • 2. Calibration of camera internal reference
  • 3. ROS+OpenCV Foundation
  • 4. AR vision
  • 5. Color tracking
  • 6. Object tracking
13. Multi vehicle control
  • 1. Multi-vehicle synchronous control
  • 2. Multi-vehicle navigation
Remote login control
  • 1. VNC and SSH remote login
  • 2. Jupyter lab login and case code running
Download
  • RemoteCtrl_APP(iOS/Android))
  • Mapping_APP(iOS_Android)
  • Code
  • System File
  • VM_File
  • Manual
  • Software_File
  • Hardware_File
  • ROS2_Basic_VM
Download ZIP

Welcome to RDK X3 Robot repository

1. VNC and SSH remote login

VNC and SSH remote login

1. VNC remote login

1.1 LAN connection

Note: Using the factory image provided by Yahboom, the SSH and VNC environments are configured, and the system starts automatically. Please do not reconfigure yourself, otherwise exceptions will occur, and you will need to follow the tutorial to re-burn the factory image.。

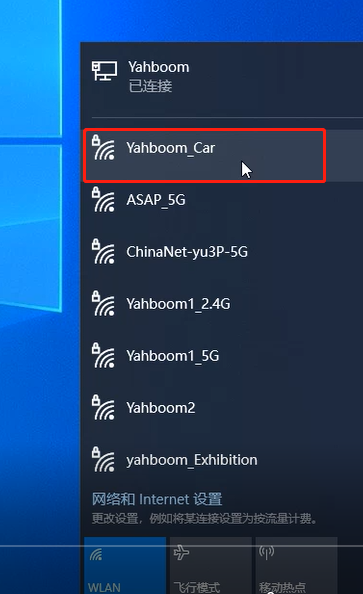
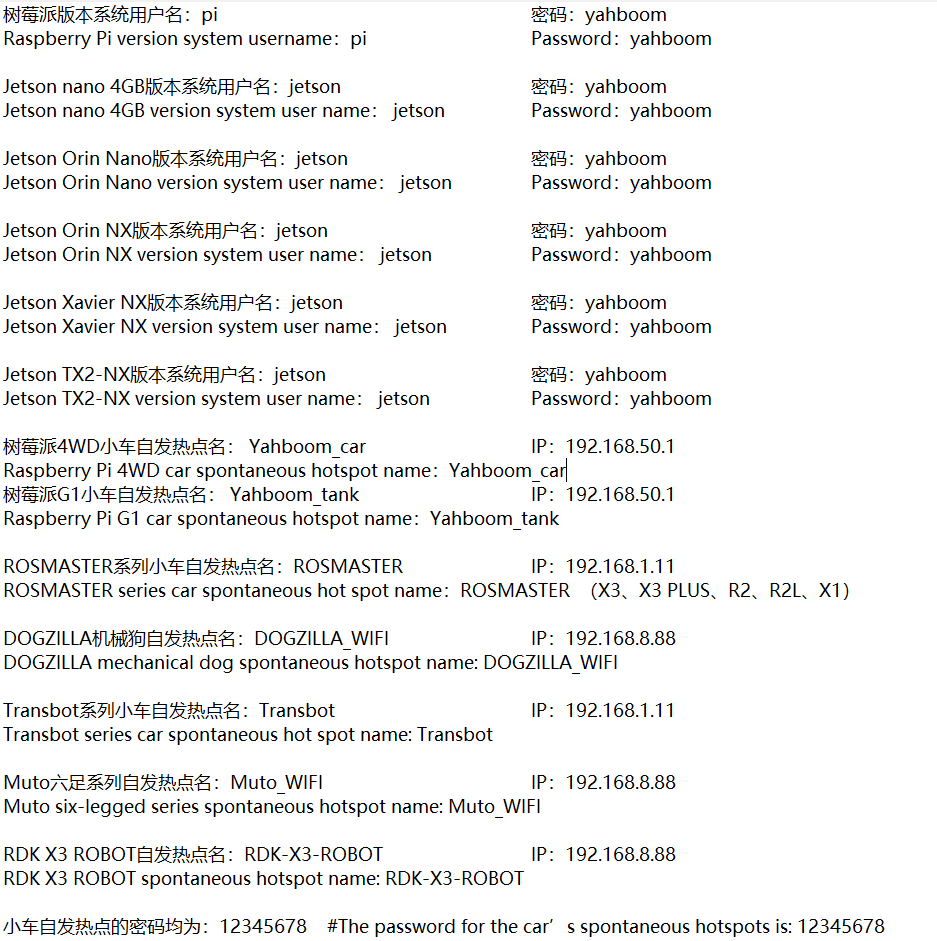
Connect your Windows computer to the car to send out a hotspot, taking the Raspberry Pi 4WD car as an example. The computer finds the car’s wifi name Yahboom_car (The hotspot names and passwords issued by other models of products can be viewed according to the instruction manual.) . Enter password: 12345678 to connect,The default IP address of the car is 192.168.50.1. (The IP address of other models of products is not necessarily this. You can check it according to the manual or through the OLED display connected to the product. The default IP addresses of other products are 192.168.1.11 and 192.168.8.88.).
 

1.2 Check the smooth communication of the network

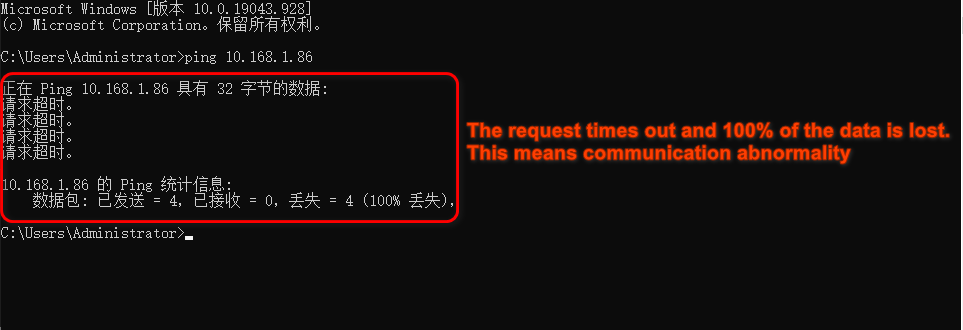
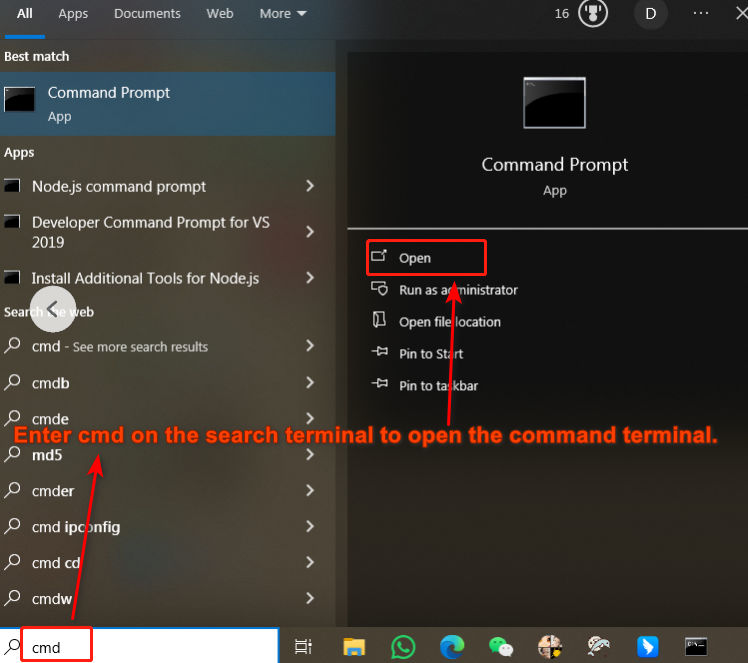
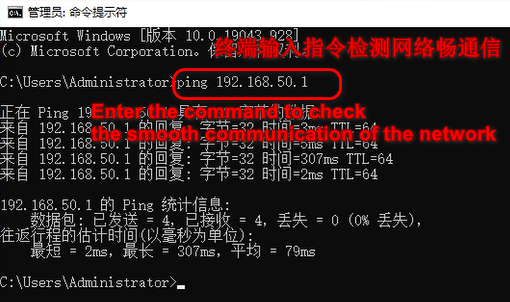
Enter cmd in the computer search window to open the command run window. Ping the IP address of the car in the terminal (for example: ping 192.168.50.1) to check whether the network is smooth。If a reply appears, it means the network is smooth. If the target host cannot be accessed, it means the network is not smooth. You need to check whether the firewall is turned on on your computer and turn off anti-virus software such as Tinder.


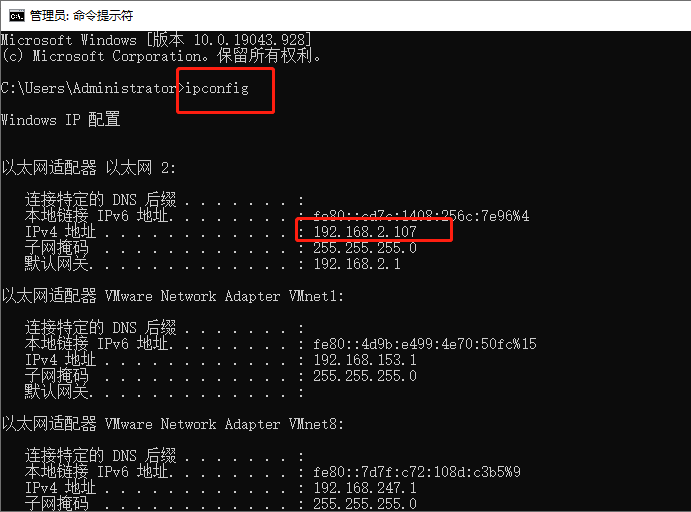
Note: If the main control board system is connected to its own router network, or is not a spontaneous hotspot product (a network connected through a distribution network or network cable). Both the car system terminal and the windows computer terminal need to ping each other's IP. If one party cannot ping successfully.(Windows computers use the command ipconfig to check the IP address, and ubuntu systems use the command ifconfig to check the IP address)。It means there is a problem with the network. Please change to another LAN to connect. Please do not connect to the campus network. The campus network is blocked and remote login such as VNC and SSH is not possible.


1.3 VNC remote login

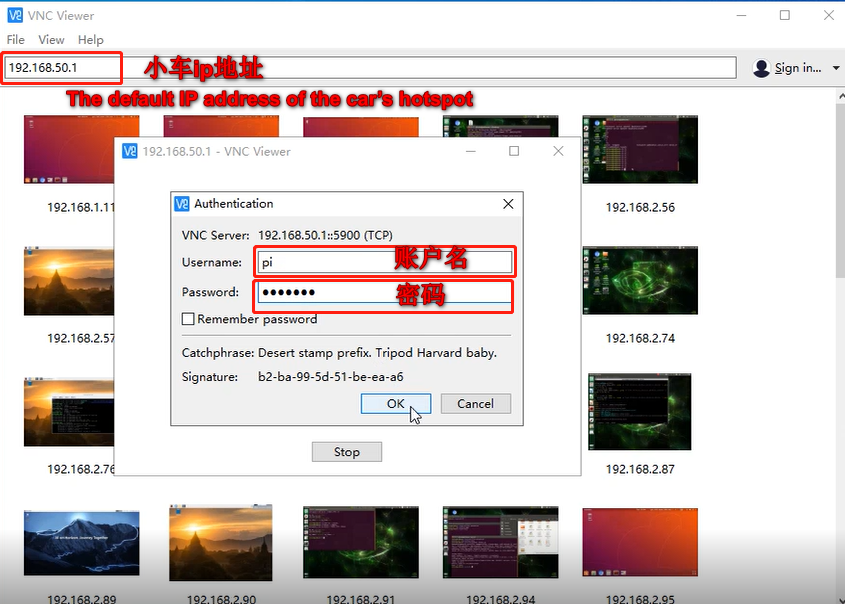
Install the vncviewer software provided on your windows computer(You can download the information from the provided link, or consult Yahboom technical staff in the group). After installation, open the VNC software, enter the IP address of the motherboard in the search box, enter account name pi, password yahboom to log in.(For other models of products, the account name and password used in the product manual shall prevail.)。
 

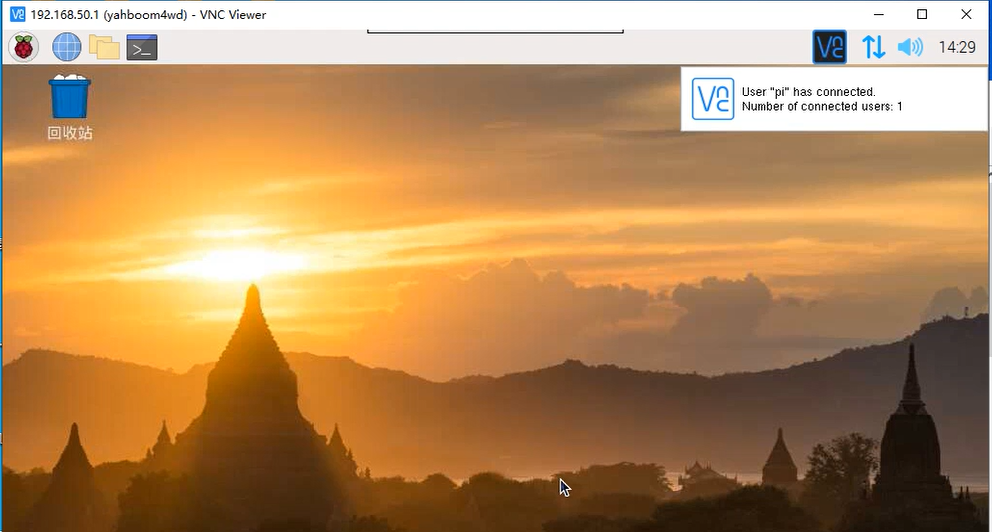
At this time, we can log in to the motherboard system remotely, and then run the code in the terminal, or edit the code and other operations.
2. SSH remote login

Connect your Windows computer to the hotspot emitted by the car, taking the Raspberry Pi 4WD car as an example. For the connection process and to check the smoothness of the network, please refer to the steps of the VNC login tutorial.

Install and open PUTTY login software(Other types of remote login software can be downloaded online by yourself. The company does not provide other software except tutorials.)Enter the IP address of the car. Then enter the account name and password to log in, and leave the others unchanged by default.

Note: When entering the password, the port will not display any letters. Simply enter it and press enter to log in
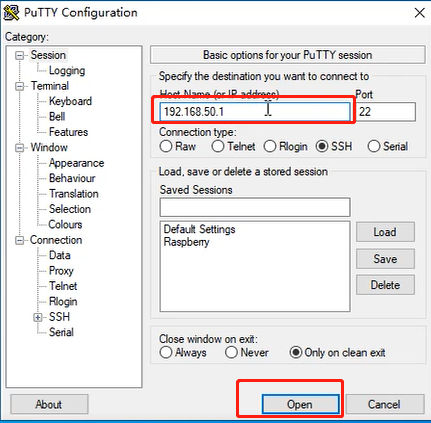
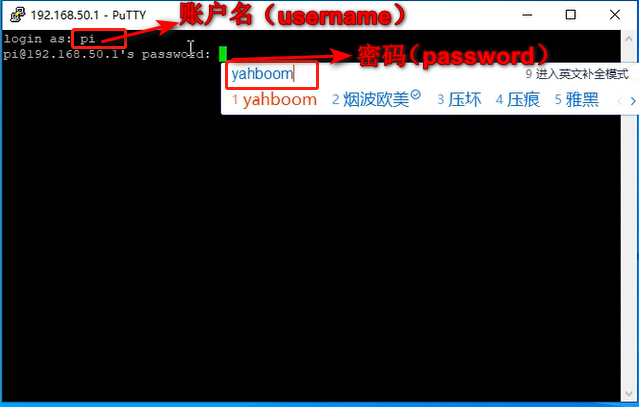


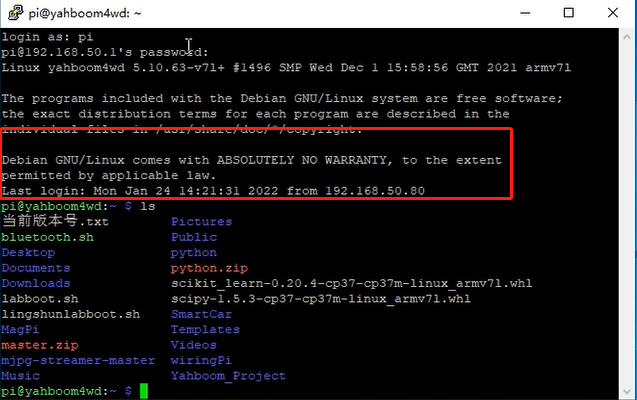
After entering the correct IP address and account name and password, we successfully logged in to the car's motherboard system, and we can now run commands on the terminal.


Multi-vehicle navigation
Jupyter lab login and case code running

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文