Welcome to RDK X3 Robot repository
1. Introduction and use of lidar
1. Introduction and use of lidar
1. Introduction and use of lidar1.1. Program Function Description1.2 Program Code Reference Path1.3. Programme startup1.4 Introduction to the MS200 Radar1.4.1 Overview1.4.2, Ranging Principle1.4.3, Baud Rate1.4.4 Specification Parameters
Before driving the lidar, you need to recognise the olidar lidar device on the cart side. The environment is already set up in the system image, SSH connect to the cart and enter it in the terminal:
ll /dev/olidar
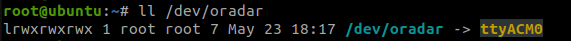
The result shows the olidar and its corresponding port, which means the lidar device is connected successfully. If no result is displayed, you can try to re-plug the lidar USB.
1.1. Program Function Description
After running the program, start the Lidar of olidar MS200, turn on the Lidar scanning data, and visualise the Lidar scanning data in rviz on the virtual machine side.
1.2 Program Code Reference Path
SSH connection to the car, start the lidar function source code location is located at.
xxxxxxxxxx~/software/library_ws/src/olidar_lidar/launch/ms200_scan.launch.py1.3. Programme startup
After SSH connecting to the car, run in the terminal, the
xxxxxxxxxxros2 launch olidar_lidar ms200_scan.launch.pyOpen a terminal on the VM side and run.
xxxxxxxxxxros2 launch yahboomcar_rviz yahboomcar_laser_launch.py
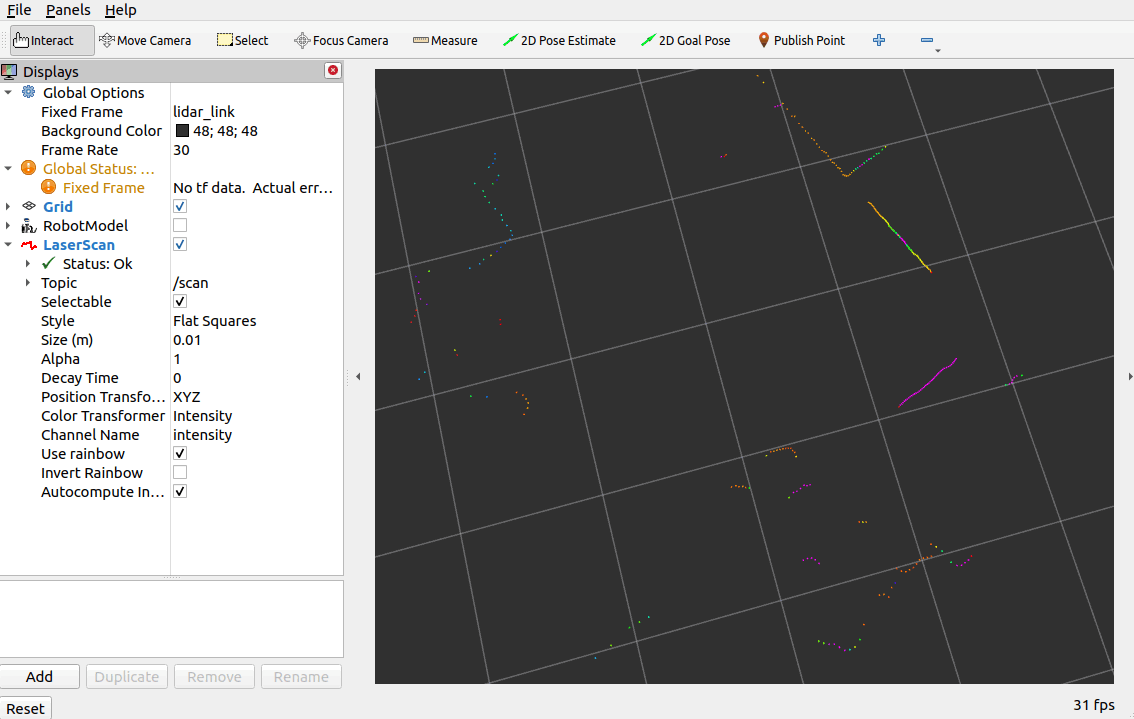
The data from the lidar scan can be printed with the following command, the
xxxxxxxxxxros2 topic echo /scan
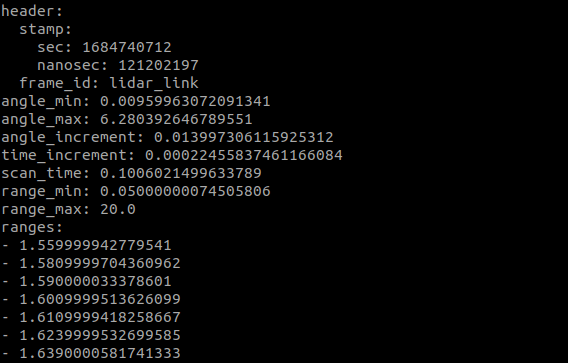
1.4 Introduction to the MS200 Radar
1.4.1 Overview
Single-line Lidar is a lidar in which the beam emitted from the laser source is a single line, with triangulation and TOF Lidar, mainly used in the field of robotics. Its scanning speed, strong resolution, high reliability, compared with multi-line Lidar, single-line Lidar in the angular frequency and sensitivity of the response faster, so the obstacle ranging distance and accuracy is also more accurate.
1.4.2, Ranging Principle
The measuring principle of AURORA MS200 is the TOF ranging method.
TOF LIDAR is based on measuring the time of flight of light to obtain the distance of the target. The working principle is that the laser transmitter sends out a modulated laser signal, which is reflected by the measured object and received by the laser detector, and the distance to the target is calculated by measuring the phase difference between the transmitted laser and the received laser.
1.4.3, Baud Rate
The baud rate of MS200 lidar is 230400.
1.4.4 Specification Parameters
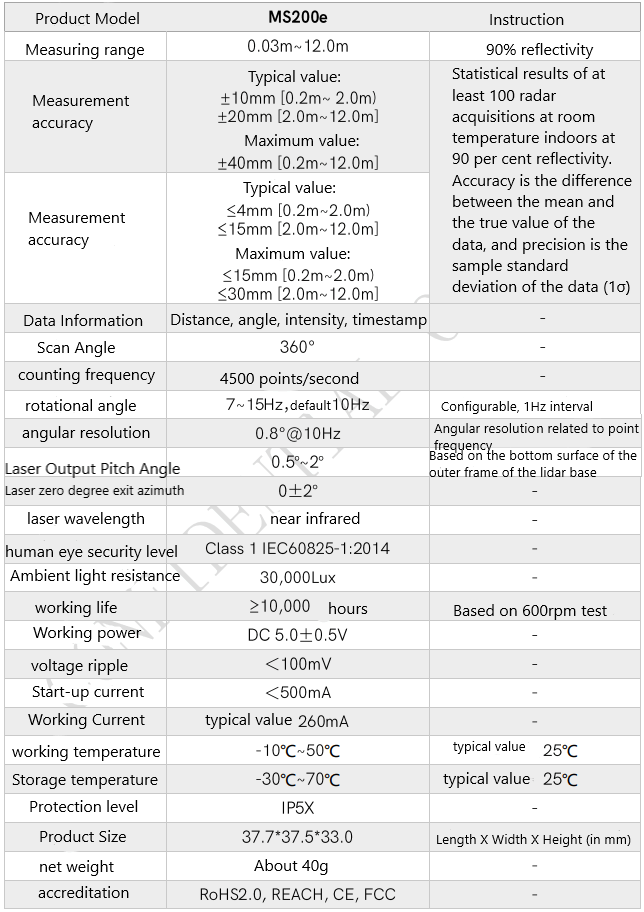
Among them, parameters such as range, measurement accuracy, rotation speed, and angular resolution are important indicators of the lidar's operational performance.