yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
RDK X3 Robot📖
01. About RDK-X3-Robot
1. Instructions
  • 1. Introduction
  • 2. FAQ
  • 3. Battery and charger use precautions
  • 4.TF card expand capacity
2. Common problem analysis
02. Assembly video
  • Part1-Install Motor
  • Part2-Install Battert Fixing Column
  • Part3-Install Motor Coupling
  • Part4-Install Mecanum wheel
  • Part5-Install Expansion Board
  • Part6-Wiring Show
  • Part7-Install Main Control Board
  • Part8-Install Car Top Plate and Antenna
  • Part9-Install OLED Screen
  • Part10-Install Depth Camera(Optional)
  • Part11-Install OLED Screen
  • Part12-Install HD Camera
  • Part13-Install Top Plate
  • Part14-Install Right Side Plate
  • Part15-Motor Wiring Show
  • Part16-lnstall Car Body
  • Part17-Install Battery
  • Part18-Install Lidar
03. Remote control tutorial
  • 1. The phone APP remote tutorial
  • 2. USB wireless controller remote tutorial
04. ROS functional tutorial
  • 1. Introduction of extension board
  • 2. Set up STM32 development environment
  • 3. Key control buzzer sound
  • 4. FreeRTOS application
  • 5. Serial communication
  • 6. SBUS model remote control
  • 7. CAN bus communication
  • 8. RGB color light strip
  • 9. Timer interrupt control PWM servo
  • 10. Control serial steering gear
  • 11. Nine-axis attitude sensor to obtain data
  • 12. Control motor forward and reverse
  • 13. The timer captures encoder data
  • 14. Theory of robot kinematics analysis
  • 15. PID control robot motion
05. Basic control tutorial
  • 1. Update the firmware of the expansion module
  • 2. Install the Python driver library
  • 3. Set the type of bottom car
  • 4. Open and close the APP program control
  • 5. Turn hotspot mode on and off
  • 6. The buzzer blows
  • 7. Control the motor forward and reverse
  • 8. Control robot movement
  • 9. OLED display
  • 10. Control fan and lamp effect
06. Development environment setup
  • 1. Virtual Machine
  • 2. Linux Basics
  • 3. Remote connection
  • 4. Multi-computer communication configuration
  • 5. Bind the device ID
  • 6. Image installation and backup
07. ROS2 Basic Course
  • 1. Introduction to ROS2
  • 2. ROS2 install Humble
  • 3. ROS2 development environment
  • 4. ROS2 workspace
  • 5. ROS2 function package
  • 6. ROS2 node
  • 7. ROS2 topic communication
  • 8. ROS2 service communication
  • 9. ROS2 action communication
  • 10. ROS2 custom interface message
  • 11. ROS2 parameter service case
  • 12. ROS2 meta-function package
  • 13. ROS2 distributed communication
  • 14. ROS2 DDS
  • 15. ROS2 time related API
  • 16. ROS2 common command tools
  • 17. ROS2 rviz2 use
  • 18. ROS2 rqt toolbox
  • 19. ROS2 Launch startup file configuration
  • 20. ROS2 recording and playback tool
  • 21. ROS2 URDF model
  • 22. ROS2 Gazebo simulation platform
  • 23. ROS2 TF2 coordinate transformation
08. Robot chassis control
  • 1. PID algorithm theory
  • 2. Robot information release
  • 3. Robot control
  • 4. Robot state estimation
  • 5. Robot calibration
  • 6. Robot trajectory tracking
  • 7. URDF model
09. Lidar courses
  • 1. Introduction and use of lidar
  • 2. Lidar obstacle avoidance
  • 3. Lidar following
  • 4. Lidar guard
  • 5. Patrol
  • 6. gmapping algorithm
  • 7. cartographer algorithm
  • 8. Navigation and obstacle avoidance
  • 9. App mapping and navigation
10. OpenCV courses
  • 1. Introduction to OpenCV
  • 2. OpenCV geometric transformation
  • 3. OpenCV image processing
  • 4. OpenCV image beautification
  • 5. Qr code creation and identification
11. MIPI camera course
  • 1. Camera driver
  • 2. Adjust the color HSV value
  • 3. Color recognition
  • 4. Color tracking
  • 5. Color follow
  • 6. Qr code command
  • 7. Face detection
  • 8. Object detection
  • 9. Visual Inspection -OpenCV
  • 10. Visual inspection - Deep learning
  • 11. Human tracking
  • 12. Gesture control
12. Depth Camera courses
  • 1. Use depth camera
  • 2. Calibration of camera internal reference
  • 3. ROS+OpenCV Foundation
  • 4. AR vision
  • 5. Color tracking
  • 6. Object tracking
13. Multi vehicle control
  • 1. Multi-vehicle synchronous control
  • 2. Multi-vehicle navigation
Remote login control
  • 1. VNC and SSH remote login
  • 2. Jupyter lab login and case code running
Download
  • RemoteCtrl_APP(iOS/Android))
  • Mapping_APP(iOS_Android)
  • Code
  • System File
  • VM_File
  • Manual
  • Software_File
  • Hardware_File
  • ROS2_Basic_VM
Download ZIP

Welcome to RDK X3 Robot repository

11. Human tracking

11. Human tracking

11. Human tracking1. Program function description2. Introduction to principle3. Program reference path4. The program starts


1. Program function description

After the program starts, stand in front of the mipi camera, let the car recognize the whole body, slowly move the body, the car will follow the human movement.

You can view the identification result in the browser on the PC.

2. Introduction to principle

The human body following function is to control the robot to follow the human body, which consists of MIPI image acquisition, human body detection and tracking, human body following strategy, image encoding and decoding, and WEB display terminal. The process is as follows:
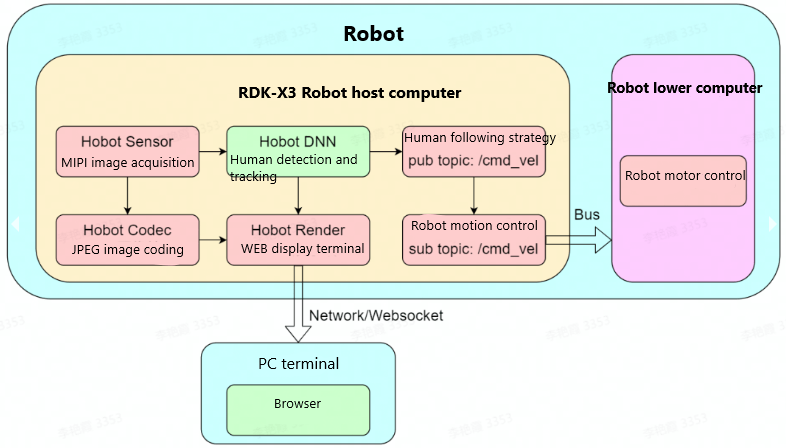
1684834010723

Human body detection and tracking algorithm example Subscribe pictures, use BPU for algorithmic reasoning, publish msg, including human body, human head, face, human hand frame and human key point detection results, and through multi-target tracking (MOT) function, realize the tracking of detection frame. The websocket package is used to render and display the pictures published by the camera and the corresponding algorithm results on the browser of the PC side.

The detection categories supported by the algorithm and the corresponding data types of different categories in the algorithm msg are as follows:

categoryInstructionsData type
bodyBody frameRoi
headHead frameRoi
faceFace frameRoi
handHand frameRoi
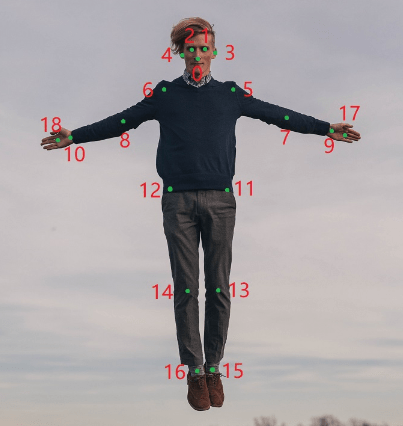
body_kpsBody key pointsPoint

Human key point algorithm result index is as follows:
1684837575625

3. Program reference path

After SSH connection car, the function source code is located in,

xxxxxxxxxx
#不识别手势
# Don't recognize gestures
/userdata/yahboomcar_ws/src/yahboomcar_deeplearning/body_tracking/launch/hobot_body_tracking_without_gesture.launch.py
#识别手势
# Recognize gestures
/userdata/yahboomcar_ws/src/yahboomcar_deeplearning/body_tracking/launch/hobot_body_tracking.launch.py

4. The program starts

After SSH connects to the car, the terminal runs,

xxxxxxxxxx
# 从TogetherROS的安装路径中拷贝出运行示例需要的配置文件
# Copy the configuration files needed to run the example from TogetherROS
cp -r /opt/tros/lib/mono2d_body_detection/config/ .
​
#启动launch文件
# Start the launch file
#不识别手势
# Don't recognize gestures
ros2 launch body_tracking hobot_body_tracking_without_gesture.launch.py
#识别手势
# Recognize gestures
ros2 launch body_tracking hobot_body_tracking.launch.py

The output log shows that the program runs successfully, the algorithm input and output frame rate is 30fps when reasoning, and the statistical frame rate is refreshed once every second.
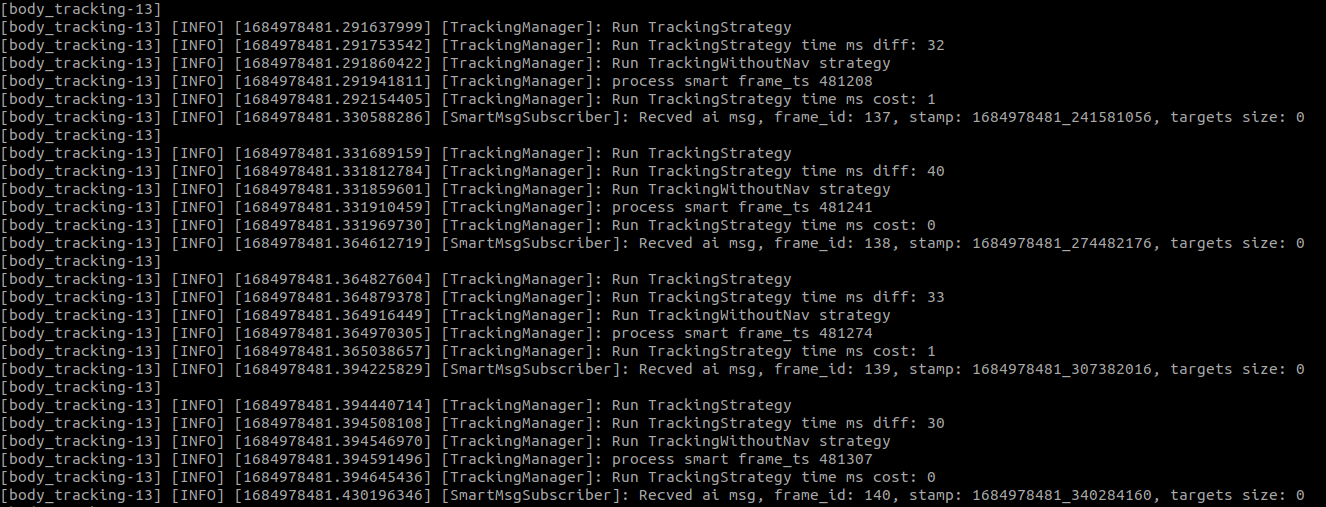
1684978560162

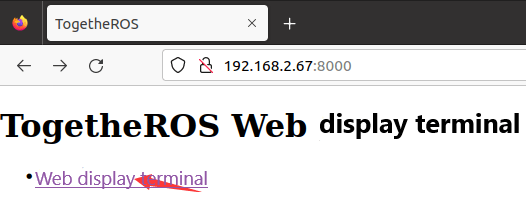
Open the browser on the PC side (note that the computer and the Rising Sun network must be in the same LAN), enter the URL: car IP:8000, for example, my car IP is 192.168.2.67, enter the URL in the browser on the virtual machine side,

xxxxxxxxxx
192.168.2.67:8000

1684978780956

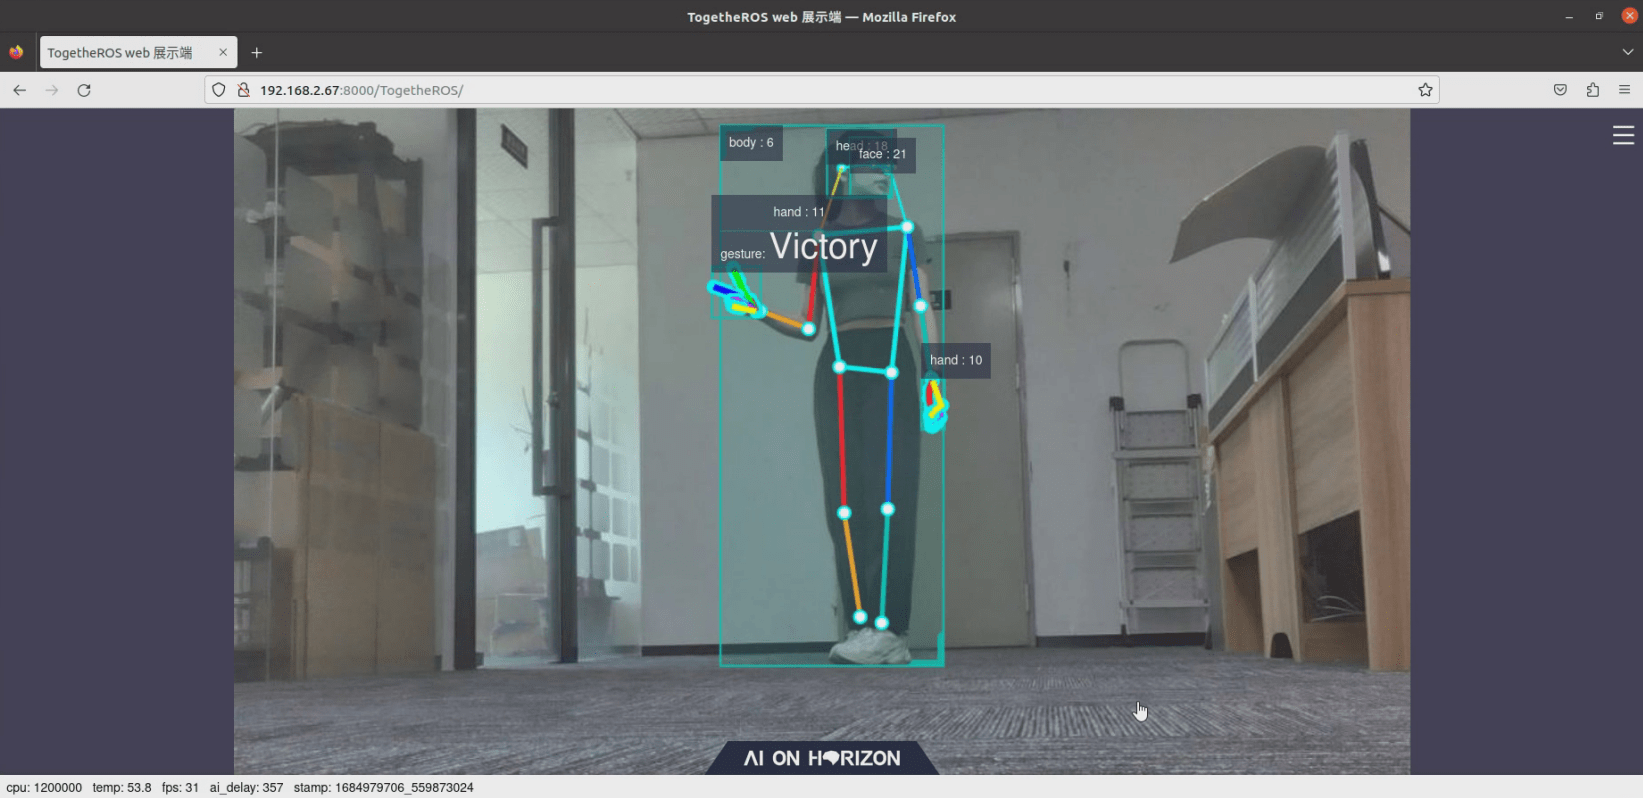
Click to enter the Web display terminal, the display screen is as follows:

Do not recognize gestures:
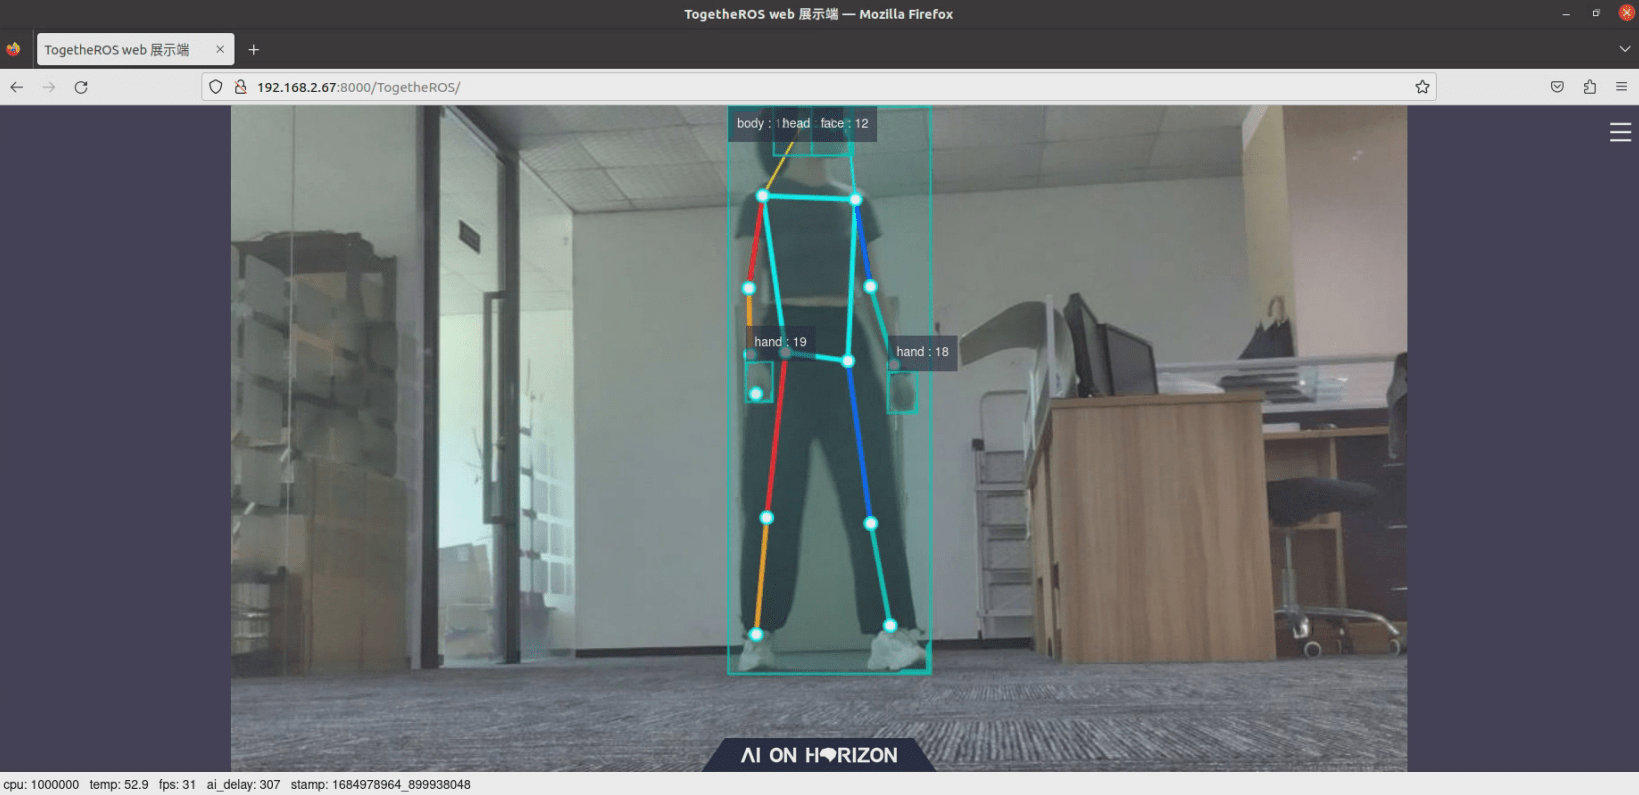
1684979192505

Recognize gestures:

1684979808267

Adjust the camera Angle, after recognizing the human body, the car will follow the human body, and maintain a certain distance.


Visual inspection - Deep learning
Gesture control

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文