yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
Transbot SE📖
01.Introduction to Transbot SE
  • 01. Introduction to Transbot SE
  • 02. Precautions for use and battery safety
  • 03. First Trial
02.First Trial
  • 2.1.APP control
  • 2.2.USB wireless handle control(Optional)
  • 2.3.Handle video control Transbot(Optional)
  • 2.4.Network configuration tutorial in hotspot mode
03.Hardware control course
  • 3.1About expansion board and update firmware
  • 3.2.Close self-starting process
  • 3.3.Install Transbot library
  • 3.4.Control buzzer and button
  • 3.5.Control PWM servo
  • 3.6.Control bus servo
  • 3.7.Control motor
  • 3.8.Control robot movement
04.Linux operating system
  • 1. Virtual machine installation and use
  • 2. Linux basics
  • 3. Remote control
  • 4. Multi-machine communication configuration
  • 5. Static IP and hotspot mode
  • 6. Web page real-time monitoring
  • 7. Expansion tutorial
  • 8. Write system images
05.Docker couse(For Pi5)
  • 1.Docker overview and docker installation
  • 2.Common commands for docker image containers
  • 3.Docker images deeply understand and publish images
  • 4.Docker hardware interaction and data processing
  • 5.Start the transbot se container
06.ROS basic course
  • 1.ROS introduction
  • 2.Project file structure
  • 3.Common commands and tools
  • 4.Publisher
  • 5.Subscribers
  • 6.Customize topic messages and use
  • 7.Client
  • 8.Server
  • 9.Custom service messages and usage
  • 10.TF release and monitoring
07.OpenCV courses
  • 1. Getting started with Open Source CV
  • 2. Open Source CV geometric transformation
  • 3. Open Source CV image processing and drawing text line segments
  • 4. Open Source CV image beautification
  • 5. Opencv application
  • 6. AR vision
  • 7. AR QR code
  • 8. ROS+Opencv foundation
  • 9. ROS+Opencv application
  • 10. MediaPipe development
08.ROS robot course
  • 1.PID algorithm
  • 2.Basic communication
  • 3.Keyboard control
  • 4.Handle control(Optional)
  • 5.Robot state estimation
  • 6.Data calibration
09.ROS simple camera course
  • 1.HD camera calibration
  • 2.HD camera color tracking
  • 3.HD camera color tracking (robotic arm)
  • 4.HD camera object tracking
  • 5. KCF target tracking
  • 6.HD camera face tracking
  • 7.HD camera robotic arm carrying
  • 8.HD camera Autopilot
10.ROS robotic arm control tutorial
  • 1.MoveIt configuration
  • 2.MoveIt control the real machine
  • 3.MoveIt moves randomly
  • 4.MoveIt kinematics design
  • 5.MoveIt cartesian path
  • 6.MoveIt avoiding
  • 7.MoveIt scene design
  • 8.MoveIt trajectory planning
  • 9.Mediapipe palm control car
  • 10.Mediapipe gesture control robotic arm
  • 11.Mediapipe gesture control car
  • 12.Mediapipe arm attitude control robotic arm
11.ROS multi-robot control(Optional)
  • 1. Multi-robot control(Optional)
  • 2. Multi-robot queue performance(Optional)
  • 3. Multi-robot robot arm dancing(Optional)
12.Deep learning courses
  • 1.KNN recognizes handwritten digits
  • 2.Basic use of TensorFlow
  • 3.Basic use of PyTorch(jetson)
  • 4.yolov5 model training(jetson)
  • 5.yolov5+tensorrt acceleration(jetson)
  • 6.yolov4-tiny
13.Installation Video
  • Part18
  • Part1-6
  • Part7-12
  • Part13.1-13.3.3
  • Part13.4.1-17
14.FAQnew
  • 1.Using your own Jetson board,Transbot-SE cannot start normally
Download
  • APP(iOS/Android)
  • System_File-Pi5
  • System_File-Pi4
  • System_File-Jetson
  • VM_File
  • Appendix
  • Code
  • InstructionManual
  • Jetson_Boot_USB.tar.gz
  • Hardware_Info
Download ZIP

Welcome to Transbot SE repository

5.MoveIt cartesian path

5. MoveIt Cartesian Path

5. MoveIt Cartesian Path5.1. Introduction5.2. Start5.3. Source code5.3.1. py file5.3.1.C++ file

This lesson takes the MoveIT simulation as an example. If you need to set the synchronization between the real machine and the simulation, please refer to the lesson [02, MoveIt Precautions and Controlling the Real Machine]. ! ! ! be careful! ! !

The effect demonstration is a virtual machine, and other masters are running (related to the performance of the master, depending on the actual situation).

5.1. Introduction

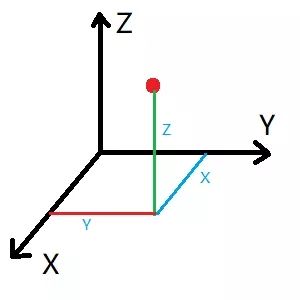
The Cartesian coordinate system is the collective name for the Cartesian coordinate system and the oblique coordinate system. A Cartesian path is actually a line connecting any two points in space
img

5.2. Start

Start the MoveIT

 roslaunch transbot_se_moveit_config demo.launch 

Start the Cartesian path node

xxxxxxxxxx
rosrun transbot_se_moveit_config 04_cartesian    # C++
rosrun transbot_se_moveit_config 04_cartesian.py # python
  • C++ code example

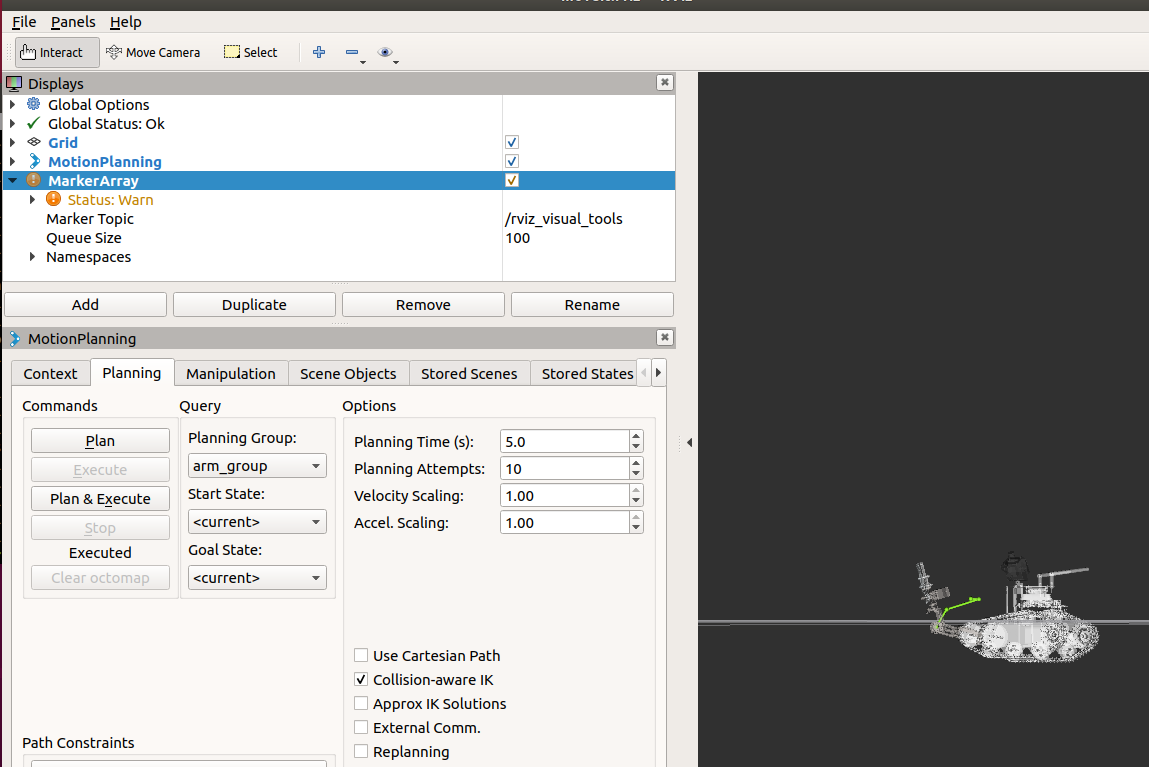
To view the track, you need to add the [MarkerArray] plugin and select the [/rviz_visual_tools] topic.
img

  • Python code example

The python code does not have a similar trajectory to C++, and there is no special effect after running.

5.3. Source code

5.3.1. py file

Set specific location

xxxxxxxxxx
    rospy.loginfo("Set Init Pose")
    joints = [0.49, 0.93]
    transbot.set_joint_value_target(joints)
    transbot.execute(transbot.plan())

Add waypoint

​x
    # Initialize waypoint list
    waypoints = []
    # If True, add the initial pose to waypoint list
    waypoints.append(start_pose)
    wpose = deepcopy(start_pose)
    wpose.position.x =0.00055
    wpose.position.y =0.1139
    wpose.position.z =0.049213
    waypoints.append(deepcopy(wpose))

    wpose.position.x =0.00055
    wpose.position.y =0.11303
    wpose.position.z =0.049142
    waypoints.append(deepcopy(wpose))

    wpose.position.x =0.00055
    wpose.position.y =0.10873
    wpose.position.z =0.048655
    waypoints.append(deepcopy(wpose))

    wpose.position.x =0.00055
    wpose.position.y =0.10616
    wpose.position.z =0.048255
    waypoints.append(deepcopy(wpose))


    wpose.position.x =0.00055
    wpose.position.y =0.10446
    wpose.position.z =0.047944
    waypoints.append(deepcopy(wpose))

Waypoint Planning

xxxxxxxxxx
        '''
        waypoints:waypoints:waypoint list
        eef_step:  terminal step value, calculate the inverse solution every 0.1m to determine whether it is reachable
        jump_threshold: jump threshold, set to 0 means jumping is not allowed
        plan: path, fraction:  path planning coverage
        '''
        (plan, fraction) = transbot.compute_cartesian_path(waypoints, 0.1, 0.0, True)

5.3.1.C++ file

Set specific location

xxxxxxxxxx
    ROS_INFO("Set Init Pose.");
    //Set specific location
    vector<double> pose{0.28, 2.14};
    transbot.setJointValueTarget(pose);

Add waypoint

xxxxxxxxxx
    //Initialize waypoint vector
    std::vector<geometry_msgs::Pose> waypoints;
    //Add the initial pose to the waypoint list
   waypoints.push_back(start_pose);
    
start_pose.position.x = 0.00055;
start_pose.position.y = 0.10701;
start_pose.position.z = 0.048397;
waypoints.push_back(start_pose);

start_pose.position.x = 0.00055;
start_pose.position.y = 0.17728;
start_pose.position.z = 0.026649;
waypoints.push_back(start_pose);

start_pose.position.x = 0.00055;
start_pose.position.y = 0.19944;
start_pose.position.z = -0.009218;
waypoints.push_back(start_pose);

Waypoint planning

xxxxxxxxxx
fraction = transbot.computeCartesianPath(waypoints, eef_step, jump_threshold, trajectory);


MoveIt kinematics design
MoveIt avoiding

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文