yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
Raspberry Pi 5📖
00.Quick Start (Must See)
  • 1.Quick Start (Must See)
  • 2.TF card expand capacity
  • 3.Raspberry Pi 5 - 1GB Version Must - See Before Use
01.Introduction to Raspberry PI 5
  • 1. Introduction to Raspberry PI 5
  • 2. Raspberry PI system installation and backup
  • 3. Powering the Raspberry PI 5
  • 4. Startup of Raspberry PI 5
  • 5. Installation and introduction of shell and active radiator
  • 6. GPIO and 40-pin pins
  • 7. Tips for using Raspberry PI 5
  • 8. Raspberry PI PCIe connector
  • 9. MIPI CSI DSI connector
  • 10. UART connector
  • 11. Real-time clock
  • 12. Power over Ethernet (PoE) connector
02.Introduction to common mirror systems
  • 1. Official Raspberry PI system
  • 2. Ubuntu
03.Basic settings of Raspberry Pi
  • 1. Update and upgrade operating system
  • 2.Introduction to raspi-config tool
  • 3.config.txt file description
  • 4.Network Configuration
  • 5.remote access
  • 6.Transfer files remotely
  • 7.Set display resolution and rotation
  • 8.Set screen to sleep
  • 9.Get real-time temperature of Raspberry Pi
  • 10.Play audio and video
  • 11.Using USB camera
  • 12.Using MIPI camera
04.Basic programming course
1. C language programming
  • 1. C language environment construction
  • 2. Print Hello World
2. Python programming
  • 1.Python usage
  • 2.Use APT to install Python packages
  • 3.Python virtual environment
  • 4.GPIO Zero
  • 5.Pin output high and low levels
  • 6.Pin reads high and low levels
  • 7.Pin output PWM
3.Jupyter lab programming
  • 1.Jupyter Lab environment construction
  • 2.Basic use of Jupyter Lab
  • 3.Jupyter Lab plug-in installation
  • 4.Basic use of Jupyter Widgets
05.Advanced AI course
5.Advanced AI gameplay
  • 1. Human pose estimation
  • 2. target detection
  • 3.yolov5
  • 4. Camera display
  • 5. QR code
  • 6. face detection
  • 7. Color recognition
2.Getting started with Open Source CV
  • 1. Introduction to Open Source CV
  • 2. Read and display Open Source CV images
  • 3. Open Source CV image writing
  • 4. Open Source CV image quality
  • 5.Open Source CV pixel operation
3.Open Source CV Geometric Transformations
  • 1. Image resizing
  • 2. Cut the image
  • 3. Image translation
  • 4. Image mirroring
  • 5. Affine transformation
  • 6. Rotate the image
  • 7. Perspective transformation
4.Text Picture Drawing Open Source CV image processing and drawing text line segments
  • 1、Grey Processing
  • 2、image binaryzation
  • 3、edge detection
  • 4、Line segment drawing
  • 5、Rectangle and circle drawing
  • 6、Text image drawing
1.Open Source CV environment setup
  • Open Source CV environment setup
6.YOLOv11 development
  • 1. YOLOv11 environment construction
  • 2. CLI Usage
  • 3. Object Detection
  • 4. Instance Segmentation
  • 5. Pose Estimation
  • 6. Image Classification
  • 7. Oriented Bounding Boxes Object Detection
  • 8. Model conversion
  • 9. Dataset Annotation
  • 10. Model training_conversion
  • 11. Model prediction
7.YOLO26 development
  • 01.YOLO26 environment
  • 02.CLI use
  • 03.Object detection
  • 04.Instance segmentation
  • 05.Pose estimation
  • 06.Image classification
  • 07.Oriented bounding box object detection
  • 08.Model conversion
  • 09.Dataset annotation
  • 10.Model training - conversion
  • 11.Model prediction
06.Mediapipe course
  • 1. Face special effects
  • 2. Face detection
  • 3. Three-dimensional object recognition
  • 4. Paintbrush
  • 5. Finger control
  • 6. Gesture recognition
07.Docker Tutorial
  • 1.Overview and installation
  • 2.Common commands
  • 3.Understand and publish images
  • 4.Hardware interaction data processing
  • 5.Enter docker container
  • 6.Update docker images
  • 7. docker container to install ROS using accessories
08.ROS1 advanced tutorial
1.ROS1 basic course
  • 1.ROS introduction
  • 2.ROS installation
  • 3.ROS common command tools
  • 4.ROS workspace
  • 5.ROS function package
  • 6.ROS node
  • 7.ROS topic publisher
  • 8.ROS topic subscribers
  • 9.ROS service client
  • 10.ROS service server
  • 11.ROS action client
  • 12.ROS action server
  • 13.ROS custom message reception
  • 14.ROS-launch file
  • 15.ROS-TF transformation
  • 16.ROS parameter service
  • 17.ROS-rviz use
  • 18.ROS-rqt tool usage
  • 19.Topic message recording and playback
  • 20.urdf model introduction
  • 21.gazebo introduction
  • 22.ROS distributed communication
2.ROS1 vision application
  • 0.Precautions
  • 1.AR vision
  • 2.AR QR code
  • 3.ROS+Opencv basics
  • 4.Face recognition
  • 5.harris corner detection
  • 6.Target tracking algorithm
  • 7.Contour moment
  • 8.Polygon outline
  • 9.Discrete fourier transform algorithm
  • 10.Edge detection algorithm
  • 11.Face detection algorithm
  • 12.Optical flow detection algorithm
  • 13.Contour detection
  • 14.General contour detection
  • 15.Feature point tracking
  • 16.HLS color filtering
  • 17.Hough circle detection
  • 18.Hough linear detection
  • 19.HSV color filtering
  • 20.LK optical flow algorithm
  • 21.detection algorithm
  • 22.Phase dependent displacement detection
  • 23.Image pyramid sampling algorithm
  • 24.RGB color filtering
  • 25.Clear background detection algorithm
  • 26.Simplified optical flow algorithm
  • 27.Simple filter
  • 28.Threshold image processing
  • 29.Watershed segmentation algorithm
09.ROS2 advanced tutorial
1.ROS2 basic course
  • 1. Introduction to ROS2
  • 2.ROS2 install Humble
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
2.ROS2 vision application
  • 0.Precautions
  • 1.Opencv basic course
  • 2.ROS+opencv application
  • 3.QR code creation and recognition
  • 4.AR vision
  • 5.Interesting gameplay of mediapipe
10.Offline AI model coursenew
Offline large model (Text Interaction)
  • 0. AI large model image description
  • 1. Deployment of large AI model environments
  • 2. Switch Chinese input method
  • 3. Installation of large model dialogue platform
  • 4. Meta AI Llama 3.2 model
  • 5. Alibaba Cloud Qwen3 Model
  • 6. Microsoft Phi-4-mini model
  • 7. DeepSeek DeepSeek-R1 model
  • 8. Alibaba Cloud Qwen2.5vl Visual Multimodal Large Model
  • 9. Google Gemma3 Visual Multimodal Large Model
  • 10. Llava Visual Multimodal Large Model
  • 11.MiniCPM-V Visual Multimodal Large Model
  • 12. Multimodal Visual Understanding Applications
  • 13. Multimodal Text-Based Image Application
  • 14. Multimodal Video Analysis Application
  • 15. Multimodal visual positioning applications
  • 16. Multimodal table scanning application
  • 17. Multimodal Autonomous Agent Application
Offline large model (Voice Interaction)
  • 0. Voice Interaction Hardware Connection (Must Read)
  • 1. Offline speech-to-text (ASR)
  • 2. Offline Text-to-Speech (TTS)
  • 3. AI large model voice interaction
  • 4. Multimodal visual understanding and voice interaction
  • 5. Multimodal Text-Based Image Application
  • 6. Multimodal Video Analysis Application
  • 7. Multimodal visual positioning applications
  • 8. Multimodal table scanning application
  • 9. Multimodal Autonomous Agent Applications
  • 10. AI large model offline voice assistant
11.Online AI model coursenew
Online large model (text interaction)
  • 1.OpenRouter Large Model API Aggregation Platform
  • 2. Multimodal Visual Understanding Applications
  • 3. Multimodal visual positioning applications
  • 4. Multimodal table scanning application
  • 5. Multimodal Autonomous Agent Applications
Online large model (voice interaction)
  • 0. Voice Interaction Hardware Connection (Must Read)
  • 1. Online speech-to-text (ASR)
  • 2. Online Text-to-Speech (TTS)
  • 3. AI large model voice interaction
  • 4. Multimodal visual and voice interaction
  • 5. Multimodal visual positioning applications
  • 6. Multimodal table scanning application
  • 7. Multimodal Autonomous Agent Applications
  • 8. AI large model online voice assistant
12.OpenClaw Deployment and Basic Usagenew
  • 01. OpenClaw Deployment
  • 02. OpenClaw WhatsApp Plugin Application
  • 03. OpenClaw WebChat Interaction
  • 04. OpenClaw TUI Interaction
  • 05. OpenClaw Tools Introduction
  • 06. OpenClawGate Gateway User Manual
  • 07. OpenClaw Features Overview
  • 08. OpenClawHub Introduction (Skill Installation)
  • 09. OpenClaw Application - File Management
  • 10. OpenClaw Application - Camera
  • 11. OpenClaw Application - Browser Control
  • 12. OpenClaw Application - Script Execution
  • 13. OpenClaw Application - AI Programming (Peripheral & GPIO Control)
  • 14. OpenClaw Application - Dedicated AI Assistant
13.OpenClaw Advanced Developmentnew
1.Preparation Before Use
  • 01. Peripheral Hardware Configuration
  • 02. OpenClaw API-KEY Configuration
  • 03. OpenClaw Model Switching
  • 04. OpenClaw Prompts
  • 05. AI Voice Interaction Configuration
  • 06. 3D Configuration Tests
2.OpenClaw AI Programming Peripheral Control
  • 1. Servo Control
  • 2. RGB Strip
  • 3. OLED Display
  • 4. Temperature and Humidity Sensor
  • 5. Camera Application
  • 6. AI Script Peripheral Control
3.OpenClaw Peripheral Integration Applications
  • 1. Plant Care Assistant
  • 2. AI Calorie Estimation
  • 3. AI Rock Paper Scissors Game
  • 4. AI Pet
  • 5. AI Weather Station
  • 6. Temperature and Humidity Dashboard
  • 7. Scheduled Tasks
Download
  • SystemFile
  • Code
  • SoftWare
  • 3D_Model_File
  • GuideManual
Download ZIP

Welcome to Raspberry Pi 5 repository

7. docker container to install ROS using accessories

7、Install ROS1/ROS2 in docker container

7、Install ROS1/ROS2 in docker container7.1 Install the corresponding images mirror (ROS environment)7.1.1 Method 1. Download from docke hub warehouse (requires internet connection)ROS1-(melodic)ROS2-(foxy)7.1.2 Method 2: Load from local file (offline)7.2 Usage tips7.3 Using accessories in docker container ROS1/ROS27.3.1 Install device udev rules rule file7.3.2 Write startup script7.3.3 Run the script to enter the container7.3.4 Incoming accessory function package

Raspberry Pi Pi 5 raspios-bookworm
DOCKER HUB repository: https://hub.docker.com/

7.1 Install the corresponding images mirror (ROS environment)

(Use our latest image to skip the 7.1 installation image part!!!)

xxxxxxxxxx
docker pull [latest image version number]
#(All version numbers of the tutorial are subject to the latest)

7.1.1 Method 1. Download from docke hub warehouse (requires internet connection)

ROS1-(melodic)

Use the command on the host:

xxxxxxxxxx
docker pull yahboomtechnology/ros-melodic:1.2 # The latest image version number here is based on the actual modifications seen
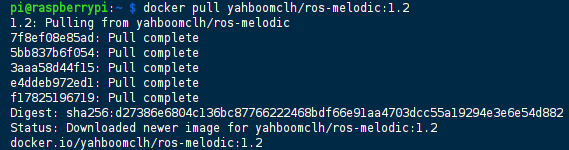
image-20231214194555725

ROS2-(foxy)

Use the command on the host:

xxxxxxxxxx
docker pull yahboomtechnology/ros2-foxy:2.0.1 # The latest image version number here is based on the actual modifications seen
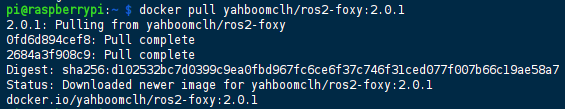
image-20231214194703351

After the installation is complete, enter the docker images command to see the image list.

xxxxxxxxxx
pi@raspberrypi:~ $ docker images
REPOSITORY TAG IMAGE ID CREATED SIZE
yahboomtechnology/ros2-foxy 2.0.1 4b8a5eee5110 7 days ago 5.61GB
yahboomtechnology/ros-melodic 1.2 1f3f7da97f2b 7 days ago 3.05GB
hello-world latest b038788ddb22 7 months ago 9.14kB

7.1.2 Method 2: Load from local file (offline)

Obtain the .tar compressed package from the network disk data and select the ROS environment you need. image-20231221165130082
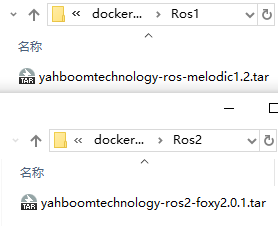
Use the command in the directory where the [xxx.tar] file of the host machine is located:

xxxxxxxxxx
docker load -i xxx.tar

This operation takes some time, but rarely fails. image-20231221162423740

After docker load execution is completed, execute:

xxxxxxxxxx
docker images

You can view the updated image and experience the new features image-20231215092406111
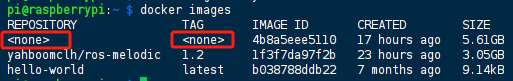
If you see the REPOSITORY TAG displayed as <_none>

In order to facilitate the use of subsequent scripts, we need to update the label of the image we pulled.

Command prototype: docker tag <IMAGE_ID> <REPOSITORY_NAME>:<TAG_NAME>

xxxxxxxxxx
docker tag 4b8a yahboomtechnology/ros2-foxy:2.0.1
docker tag 1f3f yahboomtechnology/ros-melodic:1.2
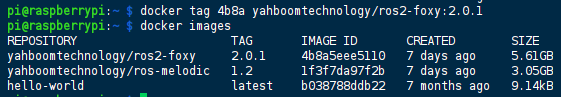
image-20231221163230757

7.2 Usage tips

At this point, the ros environment in docker has been set up. Follow the instructions for the corresponding accessories to enter the docker container and use it.

xxxxxxxxxx
Note: The environments inside the docker container and outside the container (host) are completely independent. If there is a lack of dependent environments, you need to install the relevant dependencies.


7.3 Using accessories in docker container ROS1/ROS2

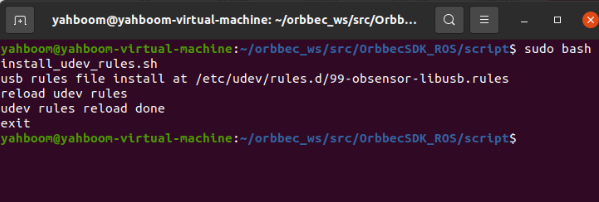
7.3.1 Install device udev rules rule file

xxxxxxxxxx
Note: This step needs to be used according to the tutorial (environment setup or preparation before use) of the corresponding accessory.
Whether you are using ROS1 or ROS2 environment, you only need to bind it once
The rule file .rules is in the /etc/udev/rules.d/ directory
->Here we take Astra camera binding as an example

Terminal input,

xxxxxxxxxx
cd ~/orbbec_ws/src/orbbec-ros-sdk/script
sudo chmod 777 install.sh
sudo bash install.sh

image-20231214144629620

After the installation is complete, it is best to restart.

Enter the following command to verify,

xxxxxxxxxx
#astraproplus
ls -l /dev/astro_pro_plus
#gemini2
ls -l /dev/OrbbecGemini2

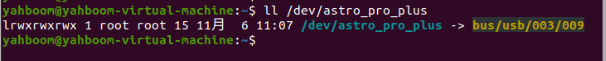
The following content appears, indicating that the binding is successful

astraproplusshow image-20231214144640807
gemini2display image-20231214144648832

7.3.2 Write startup script

xxxxxxxxxx
Places to add modifications: (After the Raspberry Pi is connected to accessories, all newly added device numbers need to be mapped to the container)
--device=/dev/xxx #Needs to be replaced with the bound device name
--device=/dev/videox #The video device number that needs to be replaced with the accessory
-v /dev/bus/usb/00x/0xx:/dev/bus/usb/00x/0xx #Needs to be replaced with the actual queried USB device number
->Add it to the script after modification

ROS1 example: docker_ros1.sh

xxxxxxxxxx
#!/bin/bash
xhost+
docker run -it \
--net=host \
--env="DISPLAY" \
--env="QT_X11_NO_MITSHM=1" \
-v /tmp/.X11-unix:/tmp/.X11-unix \
--security-opt apparmor:unconfined \
-v /home/pi/temp:/root/temp \
--device=/dev/xxx \
yahboomtechnology/ros-melodic:1.2 /bin/bash

ROS2 example: docker_ros2.sh

xxxxxxxxxx
#!/bin/bash
xhost+
docker run -it \
--net=host \
--env="DISPLAY" \
--env="QT_X11_NO_MITSHM=1" \
-v /tmp/.X11-unix:/tmp/.X11-unix \
--security-opt apparmor:unconfined \
-v /home/pi/temp:/root/temp \
--device=/dev/xxx \
yahboomtechnology/ros2-foxy:2.0.1 /bin/bash

Annotated script (not run directly)

xxxxxxxxxx
#!/bin/bash
xhost + # xhost is used to support GUI display in docker
docker run -it \ # Interactively run the docker image
--net=host \ # Container network is set to host mode
--env="DISPLAY" \ # Turn on the display GUI interface
--env="QT_X11_NO_MITSHM=1" \ # Use X11 port 1 for display
-v /tmp/.X11-unix:/tmp/.X11-unix \ # Mapping display service node directory
--security-opt apparmor:unconfined \
-v /home/pi/temp:/root/temp \ # As a directory for the host and container to temporarily transfer files. Later, the corresponding function package of the accessories needs to be imported for use. The directory name can be modified by yourself.
-v /dev/bus/usb/00x/0xx:/dev/bus/usb/00x/0xx \ # Add host device to the container, here is the xxx device port
--device=/dev/videox \ # Add host device to the container, here is x
--device=/dev/xxx \ # Add the host device to the container, here is xxx. If you don’t add it, the corresponding peripherals will not be recognized after entering the container.
-p 9090:9090 \ # Open port
-p 8888:8888 \
yahboomtechnology/ros2-foxy:2.0.1 /bin/bash # Mirror version number

7.3.3 Run the script to enter the container

Note: It must be executed on the VNC of the host machine or on the screen. It cannot be executed on the terminal that remotely accesses the Raspberry Pi through SSH. Otherwise, the GUI image may not be displayed in the container.

(If entering via ssh, this is an error message)
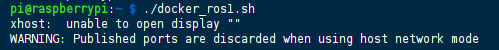
image-20231215093131203

xxxxxxxxxx
./run_docker.sh

image-20231215093309219

After entering the container, you can execute the rviz/rviz2 command to test whether the GUI is displayed normally.

xxxxxxxxxx
Test whether the device is mapped into the container: ls -l /dev

7.3.4 Incoming accessory function package

Pass the corresponding function package of the accessory into the temporary transfer file directory in the container (the shared directory set in the startup script).

For example: Use WINSCP software to transfer the function package to the host, and then copy it to the shared directory, that is, /home/pi/temp. The files in the /root/temp directory in the container are synchronized.
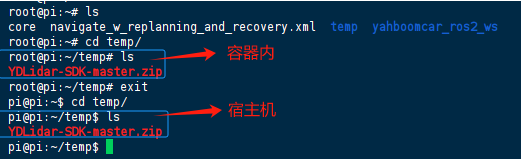
image-20231206122215971

Next, just follow the tutorial corresponding to the accessory in the container to use it.

Update docker images
ROS introduction

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文