yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
Raspberry Pi 5📖
00.Quick Start (Must See)
  • 1.Quick Start (Must See)
  • 2.TF card expand capacity
  • 3.Raspberry Pi 5 - 1GB Version Must - See Before Use
01.Introduction to Raspberry PI 5
  • 1. Introduction to Raspberry PI 5
  • 2. Raspberry PI system installation and backup
  • 3. Powering the Raspberry PI 5
  • 4. Startup of Raspberry PI 5
  • 5. Installation and introduction of shell and active radiator
  • 6. GPIO and 40-pin pins
  • 7. Tips for using Raspberry PI 5
  • 8. Raspberry PI PCIe connector
  • 9. MIPI CSI DSI connector
  • 10. UART connector
  • 11. Real-time clock
  • 12. Power over Ethernet (PoE) connector
02.Introduction to common mirror systems
  • 1. Official Raspberry PI system
  • 2. Ubuntu
03.Basic settings of Raspberry Pi
  • 1. Update and upgrade operating system
  • 2.Introduction to raspi-config tool
  • 3.config.txt file description
  • 4.Network Configuration
  • 5.remote access
  • 6.Transfer files remotely
  • 7.Set display resolution and rotation
  • 8.Set screen to sleep
  • 9.Get real-time temperature of Raspberry Pi
  • 10.Play audio and video
  • 11.Using USB camera
  • 12.Using MIPI camera
04.Basic programming course
1. C language programming
  • 1. C language environment construction
  • 2. Print Hello World
2. Python programming
  • 1.Python usage
  • 2.Use APT to install Python packages
  • 3.Python virtual environment
  • 4.GPIO Zero
  • 5.Pin output high and low levels
  • 6.Pin reads high and low levels
  • 7.Pin output PWM
3.Jupyter lab programming
  • 1.Jupyter Lab environment construction
  • 2.Basic use of Jupyter Lab
  • 3.Jupyter Lab plug-in installation
  • 4.Basic use of Jupyter Widgets
05.Advanced AI course
5.Advanced AI gameplay
  • 1. Human pose estimation
  • 2. target detection
  • 3.yolov5
  • 4. Camera display
  • 5. QR code
  • 6. face detection
  • 7. Color recognition
2.Getting started with Open Source CV
  • 1. Introduction to Open Source CV
  • 2. Read and display Open Source CV images
  • 3. Open Source CV image writing
  • 4. Open Source CV image quality
  • 5.Open Source CV pixel operation
3.Open Source CV Geometric Transformations
  • 1. Image resizing
  • 2. Cut the image
  • 3. Image translation
  • 4. Image mirroring
  • 5. Affine transformation
  • 6. Rotate the image
  • 7. Perspective transformation
4.Text Picture Drawing Open Source CV image processing and drawing text line segments
  • 1、Grey Processing
  • 2、image binaryzation
  • 3、edge detection
  • 4、Line segment drawing
  • 5、Rectangle and circle drawing
  • 6、Text image drawing
1.Open Source CV environment setup
  • Open Source CV environment setup
6.YOLOv11 development
  • 1. YOLOv11 environment construction
  • 2. CLI Usage
  • 3. Object Detection
  • 4. Instance Segmentation
  • 5. Pose Estimation
  • 6. Image Classification
  • 7. Oriented Bounding Boxes Object Detection
  • 8. Model conversion
  • 9. Dataset Annotation
  • 10. Model training_conversion
  • 11. Model prediction
7.YOLO26 development
  • 01.YOLO26 environment
  • 02.CLI use
  • 03.Object detection
  • 04.Instance segmentation
  • 05.Pose estimation
  • 06.Image classification
  • 07.Oriented bounding box object detection
  • 08.Model conversion
  • 09.Dataset annotation
  • 10.Model training - conversion
  • 11.Model prediction
06.Mediapipe course
  • 1. Face special effects
  • 2. Face detection
  • 3. Three-dimensional object recognition
  • 4. Paintbrush
  • 5. Finger control
  • 6. Gesture recognition
07.Docker Tutorial
  • 1.Overview and installation
  • 2.Common commands
  • 3.Understand and publish images
  • 4.Hardware interaction data processing
  • 5.Enter docker container
  • 6.Update docker images
  • 7. docker container to install ROS using accessories
08.ROS1 advanced tutorial
1.ROS1 basic course
  • 1.ROS introduction
  • 2.ROS installation
  • 3.ROS common command tools
  • 4.ROS workspace
  • 5.ROS function package
  • 6.ROS node
  • 7.ROS topic publisher
  • 8.ROS topic subscribers
  • 9.ROS service client
  • 10.ROS service server
  • 11.ROS action client
  • 12.ROS action server
  • 13.ROS custom message reception
  • 14.ROS-launch file
  • 15.ROS-TF transformation
  • 16.ROS parameter service
  • 17.ROS-rviz use
  • 18.ROS-rqt tool usage
  • 19.Topic message recording and playback
  • 20.urdf model introduction
  • 21.gazebo introduction
  • 22.ROS distributed communication
2.ROS1 vision application
  • 0.Precautions
  • 1.AR vision
  • 2.AR QR code
  • 3.ROS+Opencv basics
  • 4.Face recognition
  • 5.harris corner detection
  • 6.Target tracking algorithm
  • 7.Contour moment
  • 8.Polygon outline
  • 9.Discrete fourier transform algorithm
  • 10.Edge detection algorithm
  • 11.Face detection algorithm
  • 12.Optical flow detection algorithm
  • 13.Contour detection
  • 14.General contour detection
  • 15.Feature point tracking
  • 16.HLS color filtering
  • 17.Hough circle detection
  • 18.Hough linear detection
  • 19.HSV color filtering
  • 20.LK optical flow algorithm
  • 21.detection algorithm
  • 22.Phase dependent displacement detection
  • 23.Image pyramid sampling algorithm
  • 24.RGB color filtering
  • 25.Clear background detection algorithm
  • 26.Simplified optical flow algorithm
  • 27.Simple filter
  • 28.Threshold image processing
  • 29.Watershed segmentation algorithm
09.ROS2 advanced tutorial
1.ROS2 basic course
  • 1. Introduction to ROS2
  • 2.ROS2 install Humble
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
2.ROS2 vision application
  • 0.Precautions
  • 1.Opencv basic course
  • 2.ROS+opencv application
  • 3.QR code creation and recognition
  • 4.AR vision
  • 5.Interesting gameplay of mediapipe
10.Offline AI model coursenew
Offline large model (Text Interaction)
  • 0. AI large model image description
  • 1. Deployment of large AI model environments
  • 2. Switch Chinese input method
  • 3. Installation of large model dialogue platform
  • 4. Meta AI Llama 3.2 model
  • 5. Alibaba Cloud Qwen3 Model
  • 6. Microsoft Phi-4-mini model
  • 7. DeepSeek DeepSeek-R1 model
  • 8. Alibaba Cloud Qwen2.5vl Visual Multimodal Large Model
  • 9. Google Gemma3 Visual Multimodal Large Model
  • 10. Llava Visual Multimodal Large Model
  • 11.MiniCPM-V Visual Multimodal Large Model
  • 12. Multimodal Visual Understanding Applications
  • 13. Multimodal Text-Based Image Application
  • 14. Multimodal Video Analysis Application
  • 15. Multimodal visual positioning applications
  • 16. Multimodal table scanning application
  • 17. Multimodal Autonomous Agent Application
Offline large model (Voice Interaction)
  • 0. Voice Interaction Hardware Connection (Must Read)
  • 1. Offline speech-to-text (ASR)
  • 2. Offline Text-to-Speech (TTS)
  • 3. AI large model voice interaction
  • 4. Multimodal visual understanding and voice interaction
  • 5. Multimodal Text-Based Image Application
  • 6. Multimodal Video Analysis Application
  • 7. Multimodal visual positioning applications
  • 8. Multimodal table scanning application
  • 9. Multimodal Autonomous Agent Applications
  • 10. AI large model offline voice assistant
11.Online AI model coursenew
Online large model (text interaction)
  • 1.OpenRouter Large Model API Aggregation Platform
  • 2. Multimodal Visual Understanding Applications
  • 3. Multimodal visual positioning applications
  • 4. Multimodal table scanning application
  • 5. Multimodal Autonomous Agent Applications
Online large model (voice interaction)
  • 0. Voice Interaction Hardware Connection (Must Read)
  • 1. Online speech-to-text (ASR)
  • 2. Online Text-to-Speech (TTS)
  • 3. AI large model voice interaction
  • 4. Multimodal visual and voice interaction
  • 5. Multimodal visual positioning applications
  • 6. Multimodal table scanning application
  • 7. Multimodal Autonomous Agent Applications
  • 8. AI large model online voice assistant
12.OpenClaw Deployment and Basic Usagenew
  • 01. OpenClaw Deployment
  • 02. OpenClaw WhatsApp Plugin Application
  • 03. OpenClaw WebChat Interaction
  • 04. OpenClaw TUI Interaction
  • 05. OpenClaw Tools Introduction
  • 06. OpenClawGate Gateway User Manual
  • 07. OpenClaw Features Overview
  • 08. OpenClawHub Introduction (Skill Installation)
  • 09. OpenClaw Application - File Management
  • 10. OpenClaw Application - Camera
  • 11. OpenClaw Application - Browser Control
  • 12. OpenClaw Application - Script Execution
  • 13. OpenClaw Application - AI Programming (Peripheral & GPIO Control)
  • 14. OpenClaw Application - Dedicated AI Assistant
13.OpenClaw Advanced Developmentnew
1.Preparation Before Use
  • 01. Peripheral Hardware Configuration
  • 02. OpenClaw API-KEY Configuration
  • 03. OpenClaw Model Switching
  • 04. OpenClaw Prompts
  • 05. AI Voice Interaction Configuration
  • 06. 3D Configuration Tests
2.OpenClaw AI Programming Peripheral Control
  • 1. Servo Control
  • 2. RGB Strip
  • 3. OLED Display
  • 4. Temperature and Humidity Sensor
  • 5. Camera Application
  • 6. AI Script Peripheral Control
3.OpenClaw Peripheral Integration Applications
  • 1. Plant Care Assistant
  • 2. AI Calorie Estimation
  • 3. AI Rock Paper Scissors Game
  • 4. AI Pet
  • 5. AI Weather Station
  • 6. Temperature and Humidity Dashboard
  • 7. Scheduled Tasks
Download
  • SystemFile
  • Code
  • SoftWare
  • 3D_Model_File
  • GuideManual
Download ZIP

Welcome to Raspberry Pi 5 repository

19.Topic message recording and playback

19.Topic message recording and playback

ros provides the rosbag tool for recording and playing data. It records the data in the specified rostopic into a data package with a .bag suffix, which facilitates offline analysis and processing of the data.

19.1. rosbag command

The commands of rosbag are as follows:
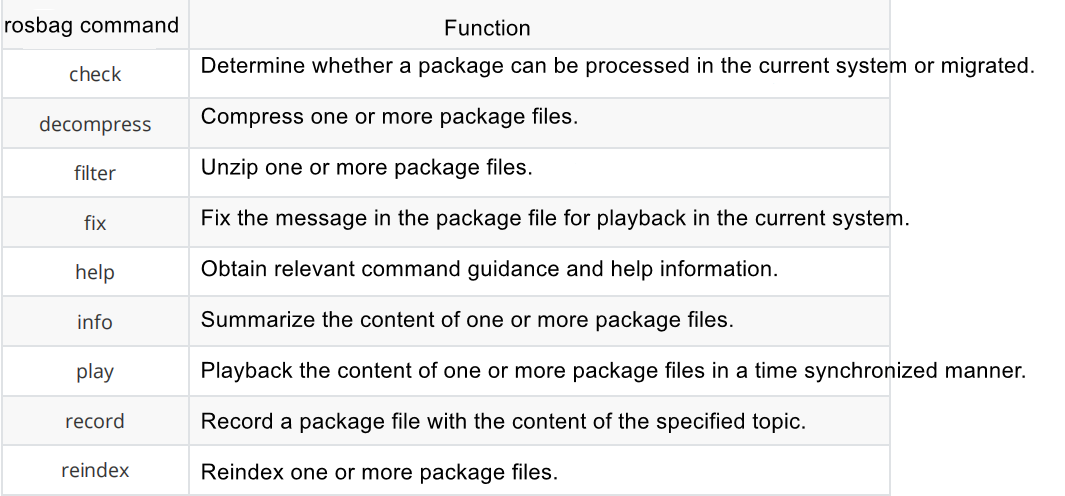
image-20231024192036060

Commonly used ones are record and play, which are recording messages and playing messages respectively.

19.1.2 record recording message

The command format of rosbag record recording message is,

rosbag record /topic_name

Among them, /topic_name is the name of the topic where the message needs to be recorded. If the parameter -a is provided, for example,

xxxxxxxxxx
rosbag record -a

With the parameter -a, it means recording all current topic data without specifying a certain topic. Of course, you can also record multiple topics that you are interested in, for example,

xxxxxxxxxx
rosbag record /topic_name1  /topic_name2 

When you want to stop recording, press ctrl c to stop. The data packet will be named after the current time, with the suffix .bag, and saved in the terminal directory where the recording command is run. If you want to specify the name of the generated data packet, add the parameter -O on the command line, for example,

xxxxxxxxxx
rosbag record -O save_topic.bag /topic_name

19.1.3 View packet information

The command format of rosbag info to view packet information is,

xxxxxxxxxx
rosbag info file_name.bag

Open the terminal in the folder where the data package is located, and then enter the above command to see the information of the data package, including topic name, size, data type, etc., for example,
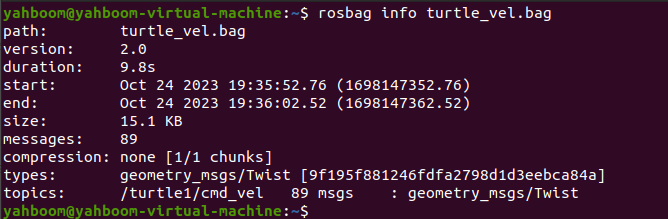
image-20231024193711156

You can also use the parameter -y to convert it into YAML format for viewing.

xxxxxxxxxx
rosbag info -y file_name.bag

for example,
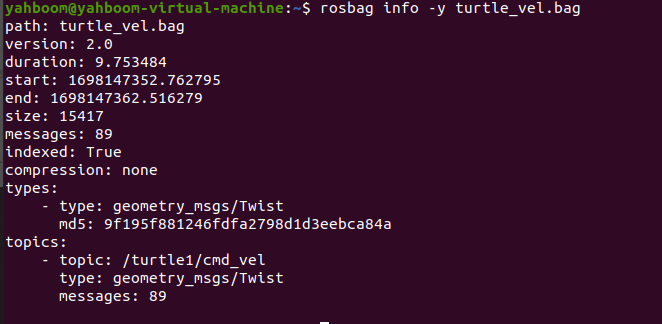
image-20231024193908356

19.1.4. Play data packets

The command format of rosbag play to play data packets is,

xxxxxxxxxx
rosbag play file_name.bag

Open the terminal in the folder where the data package is located, and then enter the above command to play the topic information recorded in the data package. It can be understood as a publisher publishing information according to the default frequency.If you want to change the rate of message publishing, you need to add -r, followed by a number corresponding to the playback rate.

xxxxxxxxxx
rosbag play -r 2 file_name.bag

If you want to loop playback, add the -l parameter.

xxxxxxxxxx
rosbag play -l  file_name.bag  

If the recorded data packet contains multiple data and you only want to play the topic of interest, you need to add the --topic command.

xxxxxxxxxx
rosbag play file_name.bag --topic /topic_name

During the playback command, if you want to pause playback midway, you can press the space bar to pause or continue playback.

19.2 rosbag instance operation

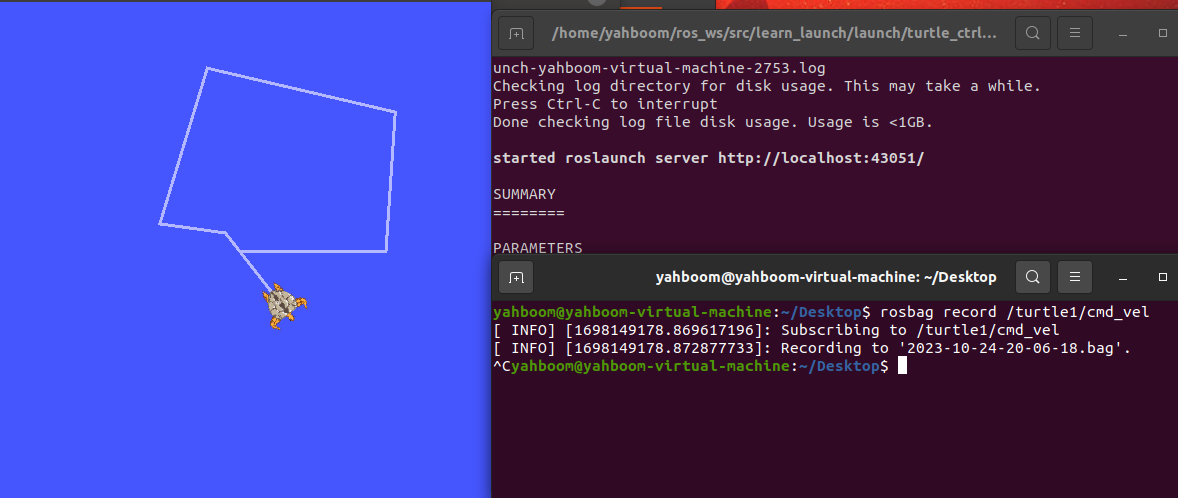
We first run the program to control the little turtle, and record the speed topic of the little turtle at this time, and then play it again and enter in the terminal,

xxxxxxxxxx
roslaunch learn_launch turtle_ctrl.launch

Then enter the following command to record the speed topic data of the little turtle,

xxxxxxxxxx
rosbag record /turtle1/cmd_vel

image-20231024200656639

Click on the terminal that starts the launch file, and press up, down, left, and right to control the movement of the little turtle. After the exercise is completed, click on the terminal to start the command to record the topic, ctrl c to close the recording, and a data packet (.bag suffix) with time as the unit will be generated in the terminal directory. Here I am in the ~/Desktop directory. The generated package name is 2023-10-24-20-06-18.bag.

Also use ctrl c to close turtle_ctrl.launch, then run only the small turtle node and enter in the terminal,

xxxxxxxxxx
roslaunch learn_launch turtle_node.launch

Open another terminal, use the cd command to switch to the directory of the data packet just recorded, and enter,

xxxxxxxxxx
rosbag play 2023-10-24-20-06-18.bag #Replace the bag here with the name you just recorded
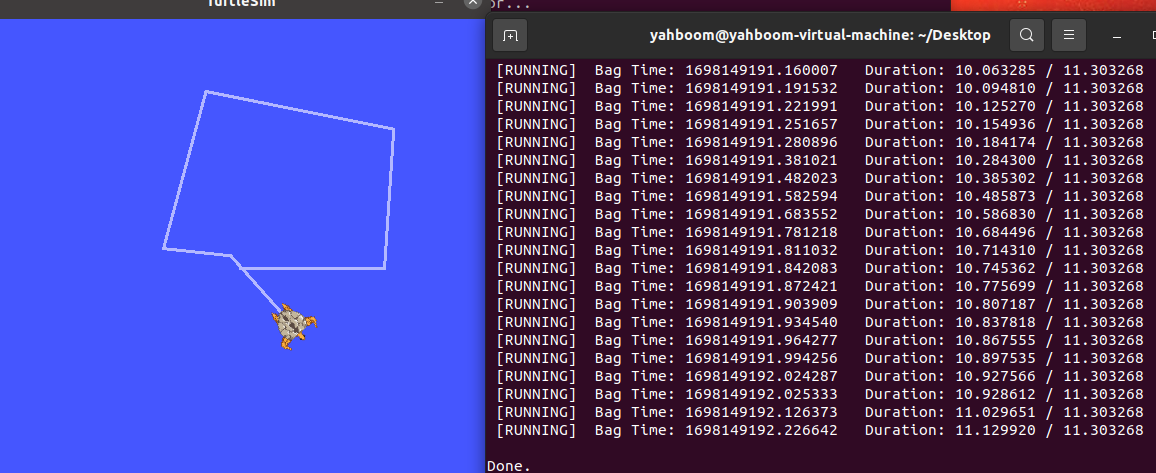
image-20231024202050356

As shown in the figure above, the terminal that plays the data packet will continue to play (publish) the data. After receiving the speed control instruction, the little turtle starts moving according to the speed value.

You can use rosbag info to check the relevant information of this data packet and enter it in the terminal.

xxxxxxxxxx
rosbag info 2023-10-24-20-06-18.bag #Replace the bag here with the name you just recorded
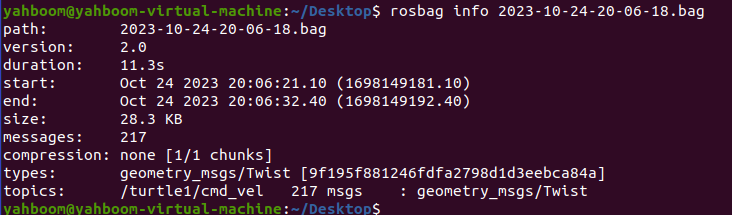
image-20231024202653591

ROS-rqt tool usage
urdf model introduction

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文