yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
Jetson AGX Thor📖
1.Get started
  • 01.Learning Route
  • 02.Getting Started Quickly
2.Jetson basic course
  • 01.Jetson board introduction
  • 02.Flashing a Pure Jetson System via SDK
  • 03.Flashing a Pure Jetson System via USB Drive
  • 04.Flashing the Jetson Bootloader using L4T
  • 05.Replacing the SSD
  • 06.Install Jetpack environment
  • 07.Backup SSD system
  • 08.Restore factory image system
  • 09.SSD expansion
  • 10.SSD Speed Test
3.Basic setting course
  • 01.Basic knowledge
  • 02.Network configuration
  • 03.SSH remote login
  • 04.VNC remote control
  • 05.Remote file transfer
  • 06.Jtop tool
  • 07.Exchange space expansion
  • 08.Use VSCode
  • 09.Use VMware
  • 10.Change screen resolution
  • 11.Virtual Desktop
  • 12.Set root user password
  • 13.Configure sudo passwordless operation
  • 14.Managing custom services
  • 15.View system version information
4.OpenCV basic course
  • 01.Image reading
  • 02.Image saving
  • 03.Image modification
  • 04.Image scaling
  • 05.Image cropping
  • 06.Image translation
  • 07.Image mirroring
  • 08.Image grayscale conversion
  • 09.Image binarization
  • 10.Image edge detection
  • 11.Add line segments
  • 12.Add rectangles
  • 13.Add circular shape
  • 14.Add ellipses
  • 15.Add polygons
  • 16.Add Text
5.Vision basic course
  • 01.USB camera preview
  • 02.Use Jupyter Lab
  • 03.Use JetCam
6.Vision advanced course
01.Environment construction
  • 01.TensorFlow
  • 02.PyTorch
  • 03.Torchvision
  • 04.Torchaudio
02.DeepStream development
  • 01.DeepStream environment
  • 02.Four types of detection(traffic)
03.YOLO26 development
  • 01.YOLO Environment Setup
  • 02.CLI Usage
  • 03.Object Detection
  • 04.Instance Segmentation
  • 05.Pose Estimation
  • 06.Image Classification
  • 07.Oriented Bounding Boxes Object Detection
  • 08.Model Conversion
  • 09.Dataset Annotation
  • 10.Model Training_Conversion
  • 11.Model Prediction
04.Mediapipe development
  • 01.Mediapipe environment
  • 02.Hand detection
  • 03.Face detection
  • 04.Face effects
  • 05.3D object recognition
  • 06.Virtual brush
  • 07.Gesture recognition
  • 08.Finger control
  • 09.Posture estimation
  • 10.Face mask
  • 11.Overall detection
  • 12.Green scene removal(Human)
05.QR code recognition
  • 01.Barcode Recognition
  • 02.QR Code Recognition
  • 03.Machine Code Recognition
  • 04.Handwritten Digit Recognition
7.Docker basic course
  • 01.Docker introduction
  • 02.Docker installation
  • 03.Docker command
  • 04.Docker usage
  • 05.Docker interaction
8.ROS2-jazzy
1.ROS2 basic course
  • 1.Introduction to ROS2
  • 2.ROS2 install Jazzy
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
2.ROS2 vision course
  • 01.Camera preview (USB)
  • 02.Camera calibration (USB)
  • 03.AR vision (USB)
9.Offline AI model course
Offline large model (Text Interaction)
  • 1.Al large model environment deployment
  • 2.Install large model dialogue platform
  • 3.Meta Al Llama3.2 model
  • 4.Alibaba Cloud Qwen3 model
  • 5.Microsoft Phi-4-mini model
  • 6.DeepSeek DeepSeek-R1 model
  • 7.Alibaba Cloud Qwen2.5v visual multimodal large model
  • 8.Google Gemma3 visual multimodal large model
  • 9.Lava visual multimodal large model
  • 10.MiniCPM-V visual multimodal large model
  • 11.Multimodal visual understand application
  • 12.Multimodal text image application
  • 13.Multimodal video analysis application
  • 14.Multi module visual position application
  • 15.Multimodal table scanning application
  • 16.Multimodal autonomous agent application
Offline large model (Voice Interaction)
  • 0.Voice interaction hardware connection (ReadMe)
  • 1.Offline speech to text (ASR)
  • 2.Offline text to speech (TTS)
  • 3.AI large model voice interaction
  • 4.Multimodal visual understand speech interaction
  • 5.Multimodal text and graphics application
  • 6.Multimodal video analysis application
  • 7.Multi module visual position application
  • 8.Multimodal table scanning application
  • 9.Multimodal autonomous proxy application
  • 10.AI large model offline voice assistant
10.Online AI model course
Online large model (Text Interaction)
  • 1.OpenRouter large model API aggregation platform
  • 2.Multimodal Video Analysis Applications
  • 3.Multimodal visual localization application
  • 4.Multimodal table scanning application
  • 5.Multimodal autonomous proxy application
Online large model (Voice Interaction)
  • 0.Voice interaction hardware connection (ReadMe)
  • 1.Online speech to text (ASR)
  • 2.Online text to speech (TTS)
  • 3.AI large model voice interaction
  • 4.Multimodal visual understand speech interaction
  • 5.Multi module visual position application
  • 6.Multimodal table scanning application
  • 7.Multimodal autonomous proxy application
  • 8.AI large model offline voice assistant
11.Generative AI Applications
12.OpenClaw Advanced Development
  • 00.OpenClaw Quick Start on Jetson Platform
  • 01.OpenClaw Installation
  • 02.OpenClaw Online Platform Deployment
  • 03.OpenClaw Local Model Deployment
  • 04.OpenClaw TUI Interaction
  • 05.OpenClaw WebChat Interaction
  • 06.OpenClaw Tools Introduction
  • 07.OpenClawGate Gateway User Manual
  • 08.OpenClaw Features Overview
  • 09.OpenClawClawHub Introduction (Skill Installation)
  • 10. OpenClaw Switching Models
  • 11.OpenClaw Application - File Management
  • 12.OpenClaw Application - Camera
  • 13.OpenClaw Application - Browser Control
  • 14.OpenClaw Application - Script Execution
  • 15.OpenClaw Application - AI Programming
  • 16.OpenClaw Application - Dedicated AI Assistant
  • 17.OpenClaw WhatsApp Plugin Application
  • 18.OpenClaw Voice Assistant
Download
  • Code
  • SystemFile
  • VM_File
  • Tools
  • Jetson boot files
Download ZIP

Welcome to Jetson AGX Thor repository

03.Flashing a Pure Jetson System via USB Drive

Flashing a Pure Jetson System via USB Drive

Flashing a Pure Jetson System via USB Drive1. Overview2. Prerequisites3. Creating the Jetson Bootable Drive3.1. Downloading the System ISO File3.2. Installing the Bootable Drive Creation Tool3.3. Creating a Bootable USB Drive4. Hardware Connections4.1. Installing the SSD4.2. Motherboard Connections4.3. Powering On5. Flashing the System via USB Drive6. System Configuration7. Booting the System

1. Overview

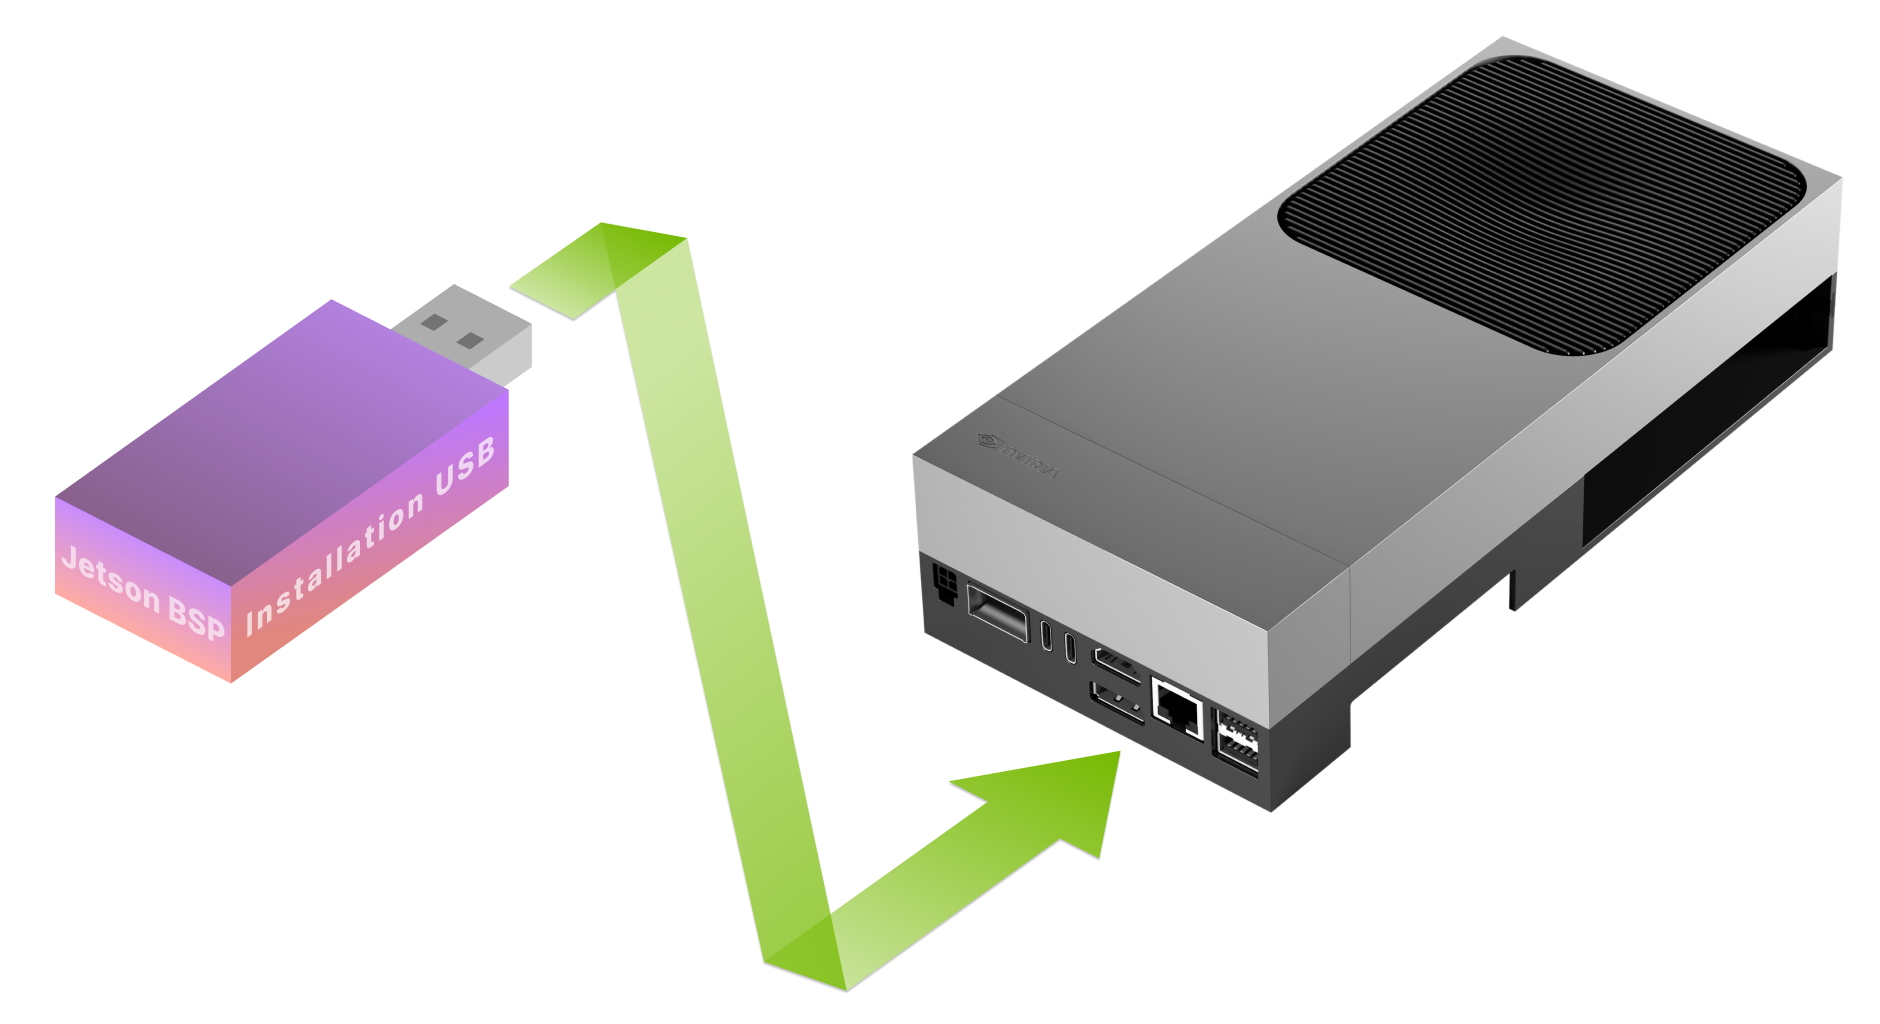
Since the introduction of JetPack 7.0, a new feature for system flashing via USB drive has been introduced. This allows you to flash the system onto the mainboard using a USB drive (which must be pre-configured as a Jetson bootable drive), eliminating the need to rely on an Ubuntu PC system for flashing. The entire process is similar to how you would install the Ubuntu operating system on a laptop or desktop PC.

The USB drive must be flashed with the Jetson system BSP boot files; once completed, it is referred to as a "Jetson bootable drive."


2. Prerequisites

  • A laptop or desktop PC (with at least 25GB of free storage space)

  • A USB drive (16GB or larger)

Jetson ISO USB inserted into Jetson AGX Thor Developer Kit

3. Creating the Jetson Bootable Drive

3.1. Downloading the System ISO File

Since the factory default image uses version r38.4.0, we will use downloading version r38.4.0 as an example here.

Open your web browser to download the r38.4.0 system ISO file:

https://developer.nvidia.com/downloads/embedded/L4T/r38_Release_v4.0/release/jetsoninstaller-r38.4.0-2025-12-30-17-00-37-arm64.iso

If you need to download the latest version, you can visit the official download link and click [Download JetPack ISO Image] to initiate the download.

xxxxxxxxxx
https://developer.nvidia.com/embedded/jetpack/downloads
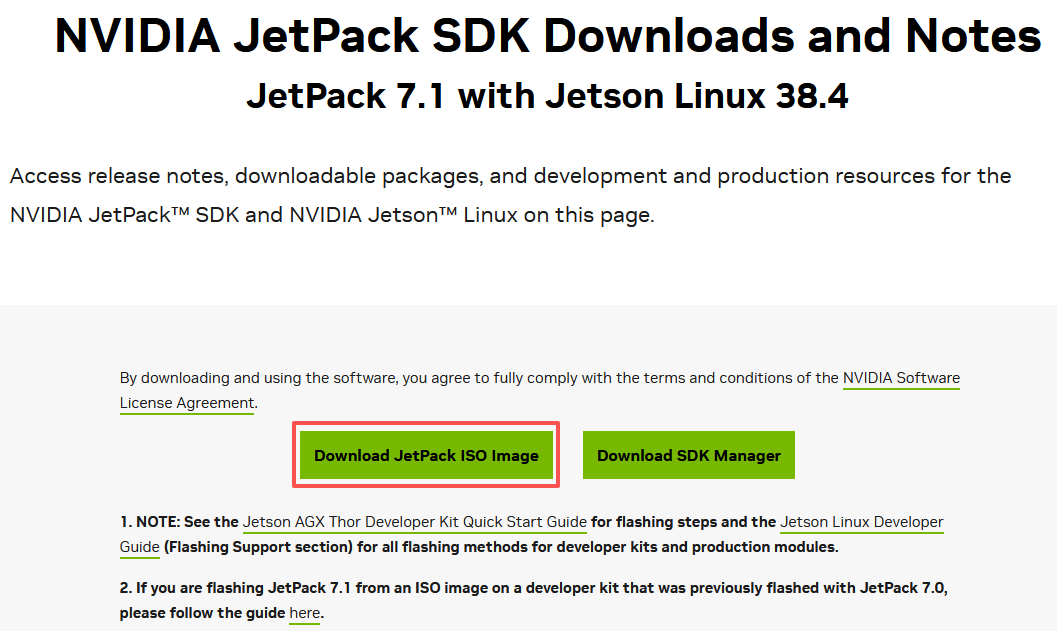
image-20260409095214655

3.2. Installing the Bootable Drive Creation Tool

Use the Balena Etcher tool to create the USB bootable drive. Open the following URL and locate the program file corresponding to your computer's operating system. Using the 64-bit Windows 10/11 system as an example, download the file balenaEtcher-2.1.4.Setup.exe, then double-click to launch the program.

xxxxxxxxxx
https://github.com/balena-io/etcher/releases/
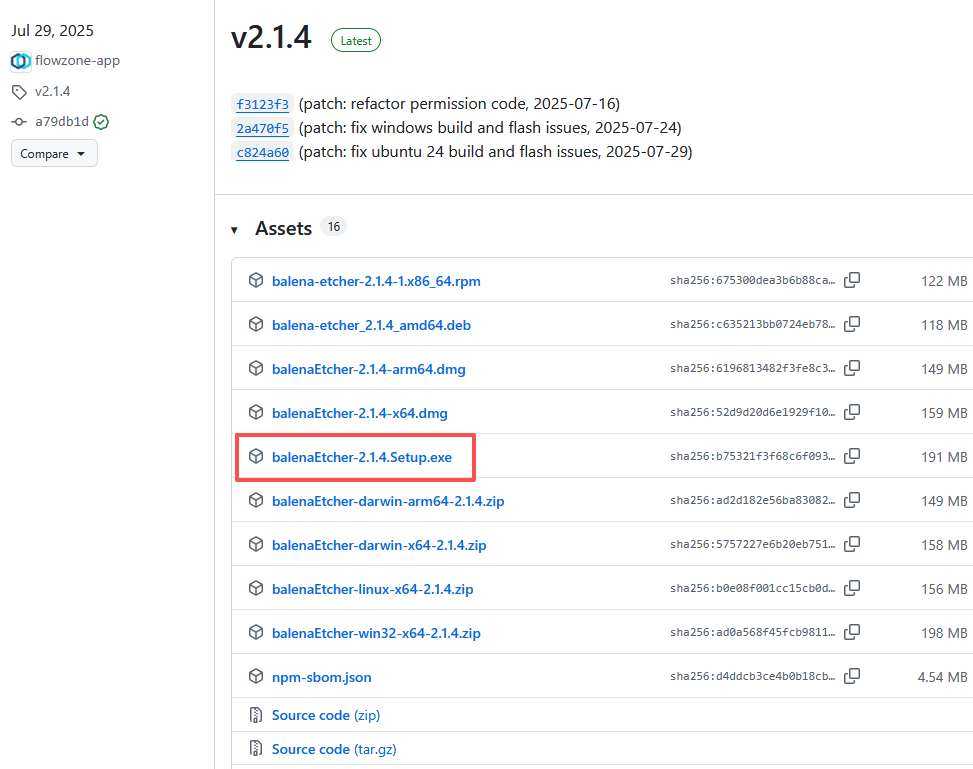
image-20260409100621572


3.3. Creating a Bootable USB Drive

Note:

This step will format the USB drive. Please ensure that the drive contains no data or files you wish to keep before proceeding with the following steps.

You must verify that the selected target disk is indeed the specific USB drive you have prepared; selecting the wrong disk will result in irreversible data loss.

Insert the USB drive into a USB port on your computer. Ensure that the drive letter appears in File Explorer, and make a note of this drive letter.
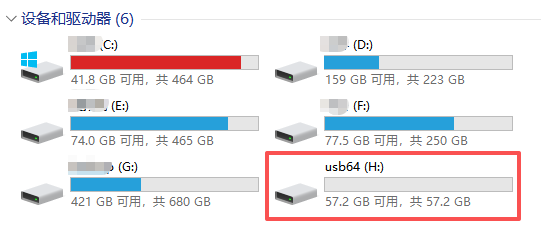
image-20260409102324393

Launch the Etcher software and select the ISO image file you previously downloaded.
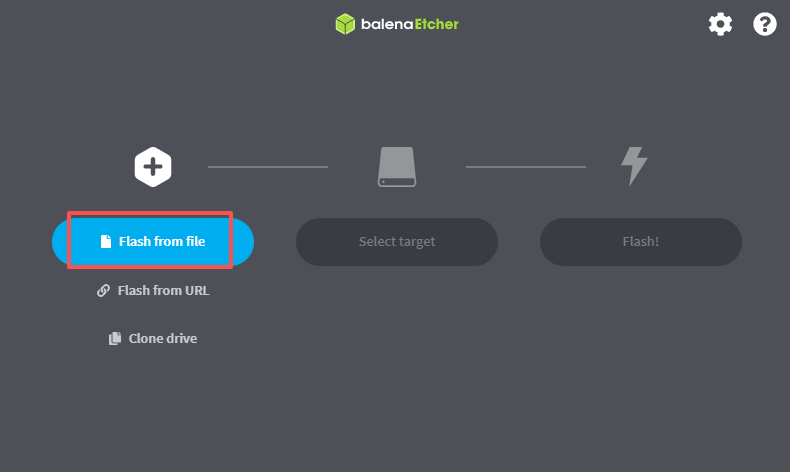
image-20260409101154194

In this example, we will use the file [jetsoninstaller-r38.4.0-2025-12-30-17-00-37-arm64.iso], which was just downloaded.
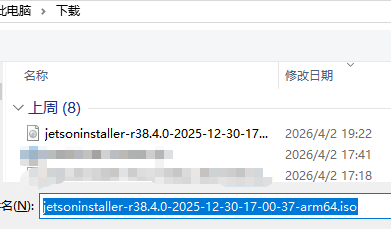
image-20260409101647191

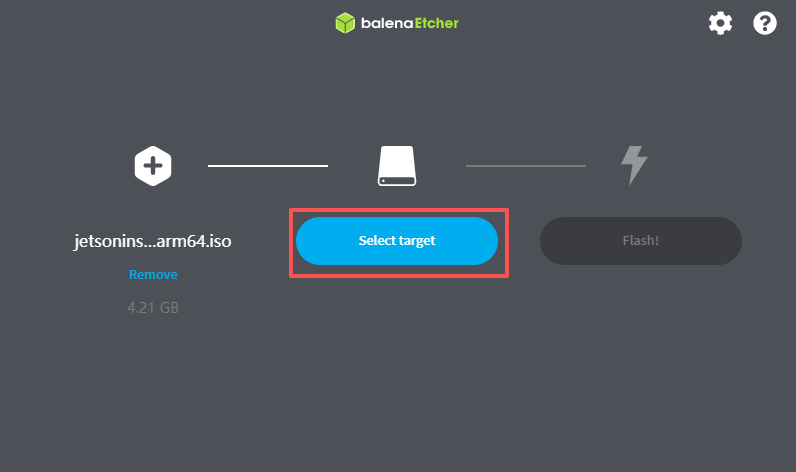
Click [Select target] to choose the USB drive to which you will write the image. image-20260409102354985
At this stage, you must carefully verify that you have selected only the inserted USB drive before clicking [Select (1)].
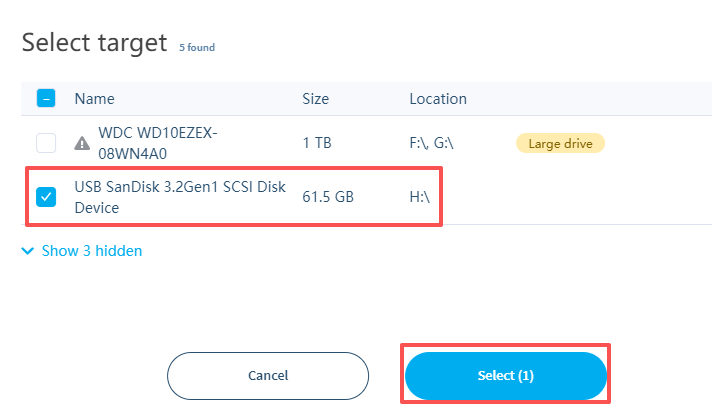
image-20260409102537393

Finally, click [Flash] to begin the flashing process.
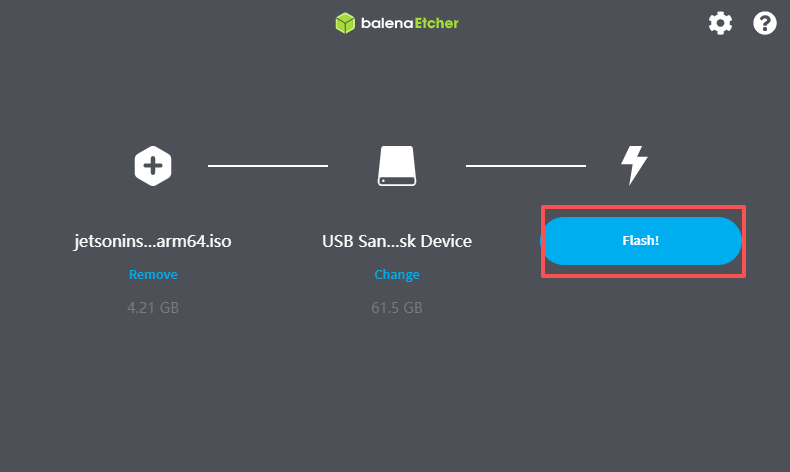
image-20260409102607893

Simply wait for the [Flashing...] progress bar to reach 100%.
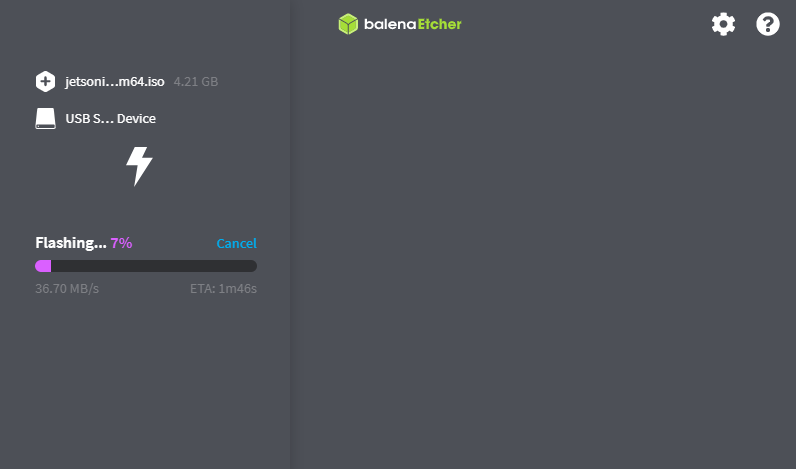
image-20260409103549833

Note: Upon completion, the process will automatically proceed to the verification stage. Due to the inability of Windows 10/11 systems to detect Linux partitions, the system will generate an error and prompt you to format the drive once the flashing is finished. Simply click "Cancel" and close the balenaEtcher tool.

Remove the USB drive.

At this point, the creation of the Jetson boot drive is complete.


4. Hardware Connections

4.1. Installing the SSD

The M.2 NVMe SSD interface is located on the underside of the Jetson AGX Thor; an SSD is pre-installed on the motherboard by default, as shown in the image below.
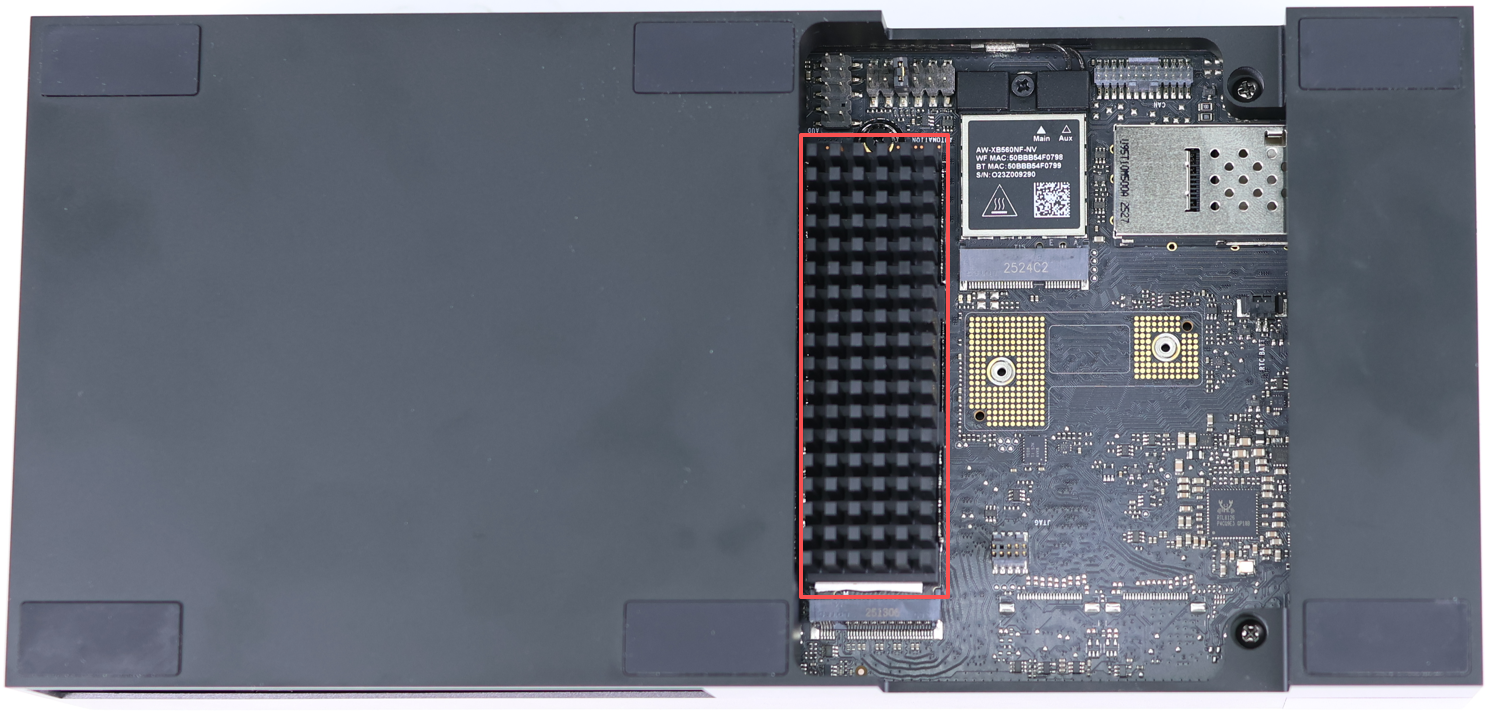
image-20260408194836578

4.2. Motherboard Connections

The Jetson AGX Thor motherboard requires connections for a power adapter, a display monitor, a mouse, and a keyboard. image-20260409112655804
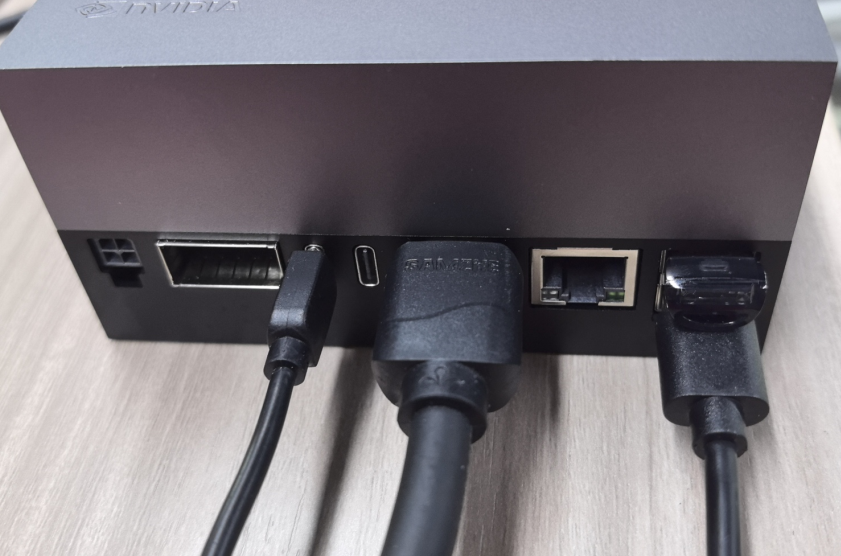
4.3. Powering On

The Jetson AGX Thor mainboard is configured to power on automatically by default when connected to a power source. If the device does not power on automatically, please press the Power button to turn it on.

As shown in the figure below, the three buttons—arranged from left to right—are the Power button, the Flash button, and the Reset button.
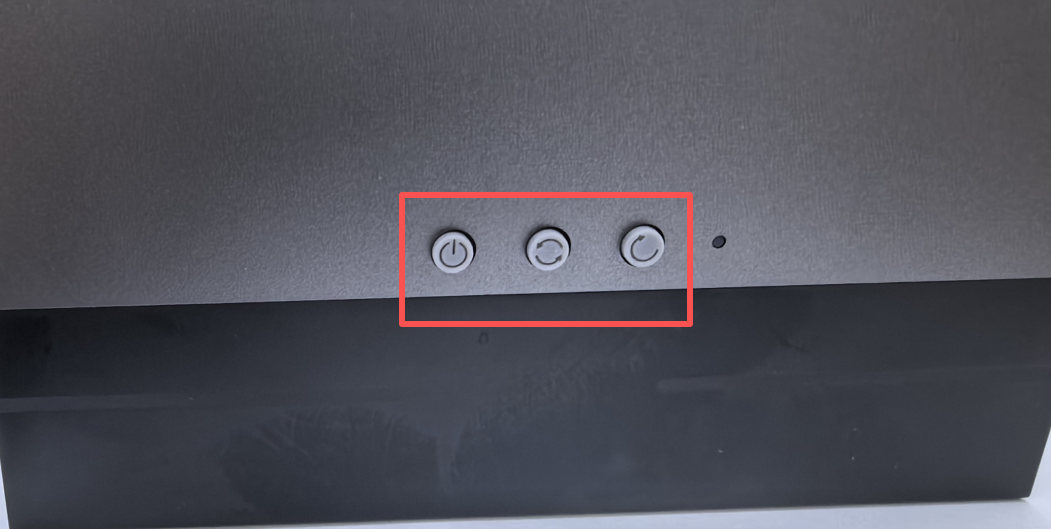
image-20260408195617792


5. Flashing the System via USB Drive

To view the compatibility matrix between the system version on the Jetson boot drive and the corresponding bootloader version, please visit the following URL. Currently, the USB drive utilizes system version r38.4.0, which is compatible with all UEFI bootloader versions.

xxxxxxxxxx
https://docs.nvidia.com/jetson/agx-thor-devkit/user-guide/latest/twa_uefi_iso_compatibility.html
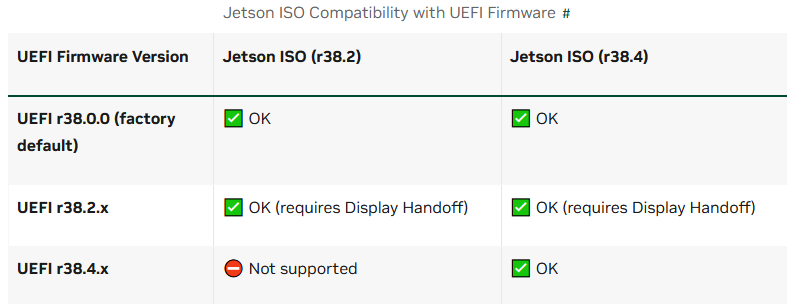
image-20260409121836623

  1. When the Jetson AGX Thor starts up, it first displays the pre-boot options. After a brief waiting period—or upon pressing the Enter key—the system will proceed to boot from the USB drive.
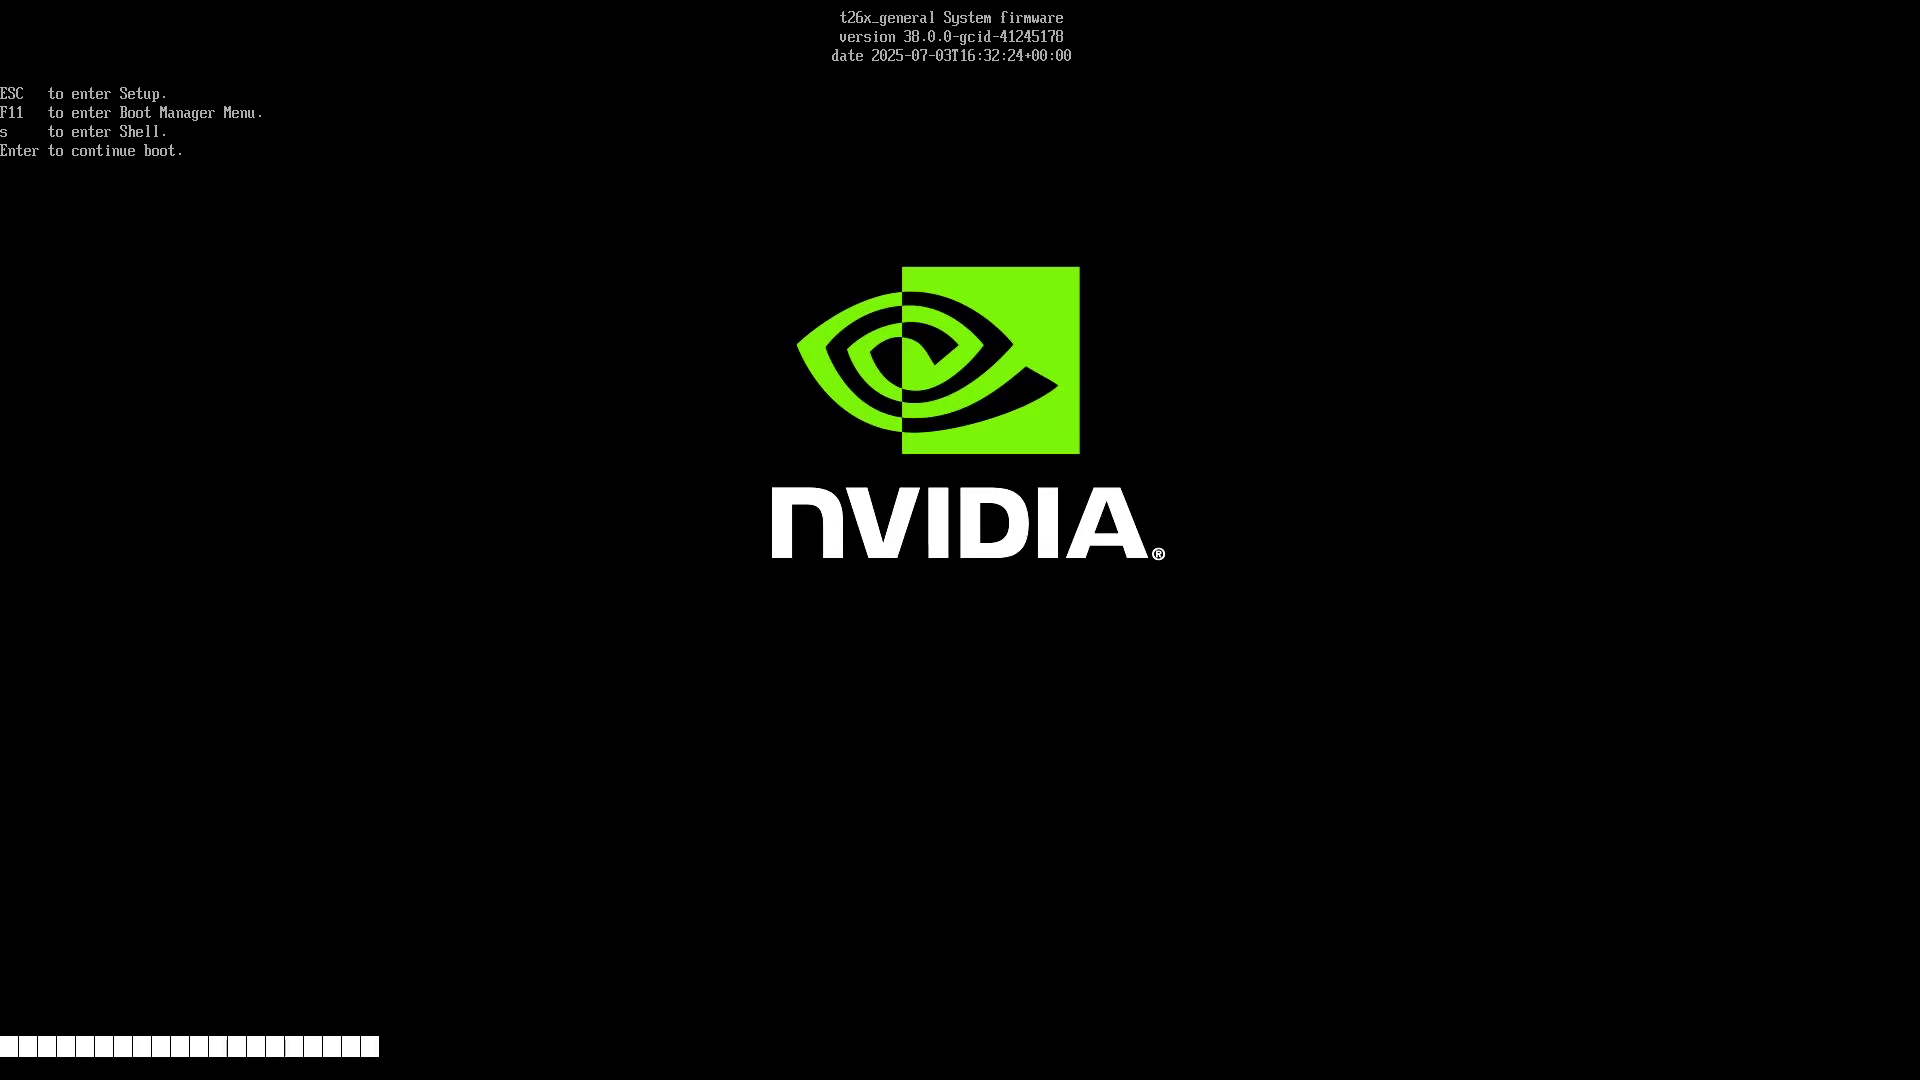
UEFI firmware update screen right after Jetson ISO installation

  1. The interface displayed after booting from the Jetson boot drive is shown in the figure below. Select [Jetson Thor options].
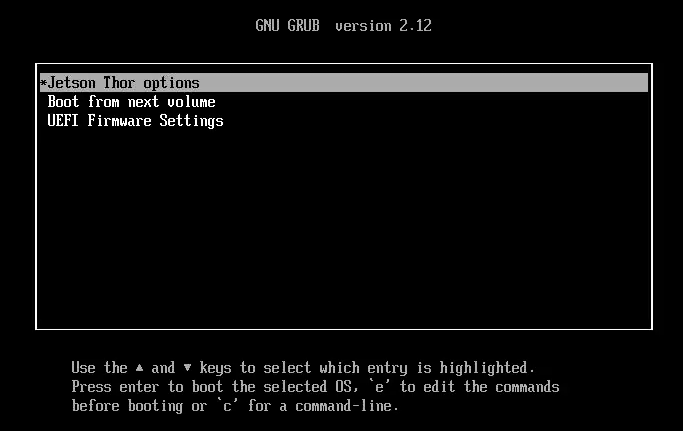
Jetson ISO GRUB top menu

  1. Select [Flash Jetson AGX Thor Developer Kit on NVMe r48.4.0]
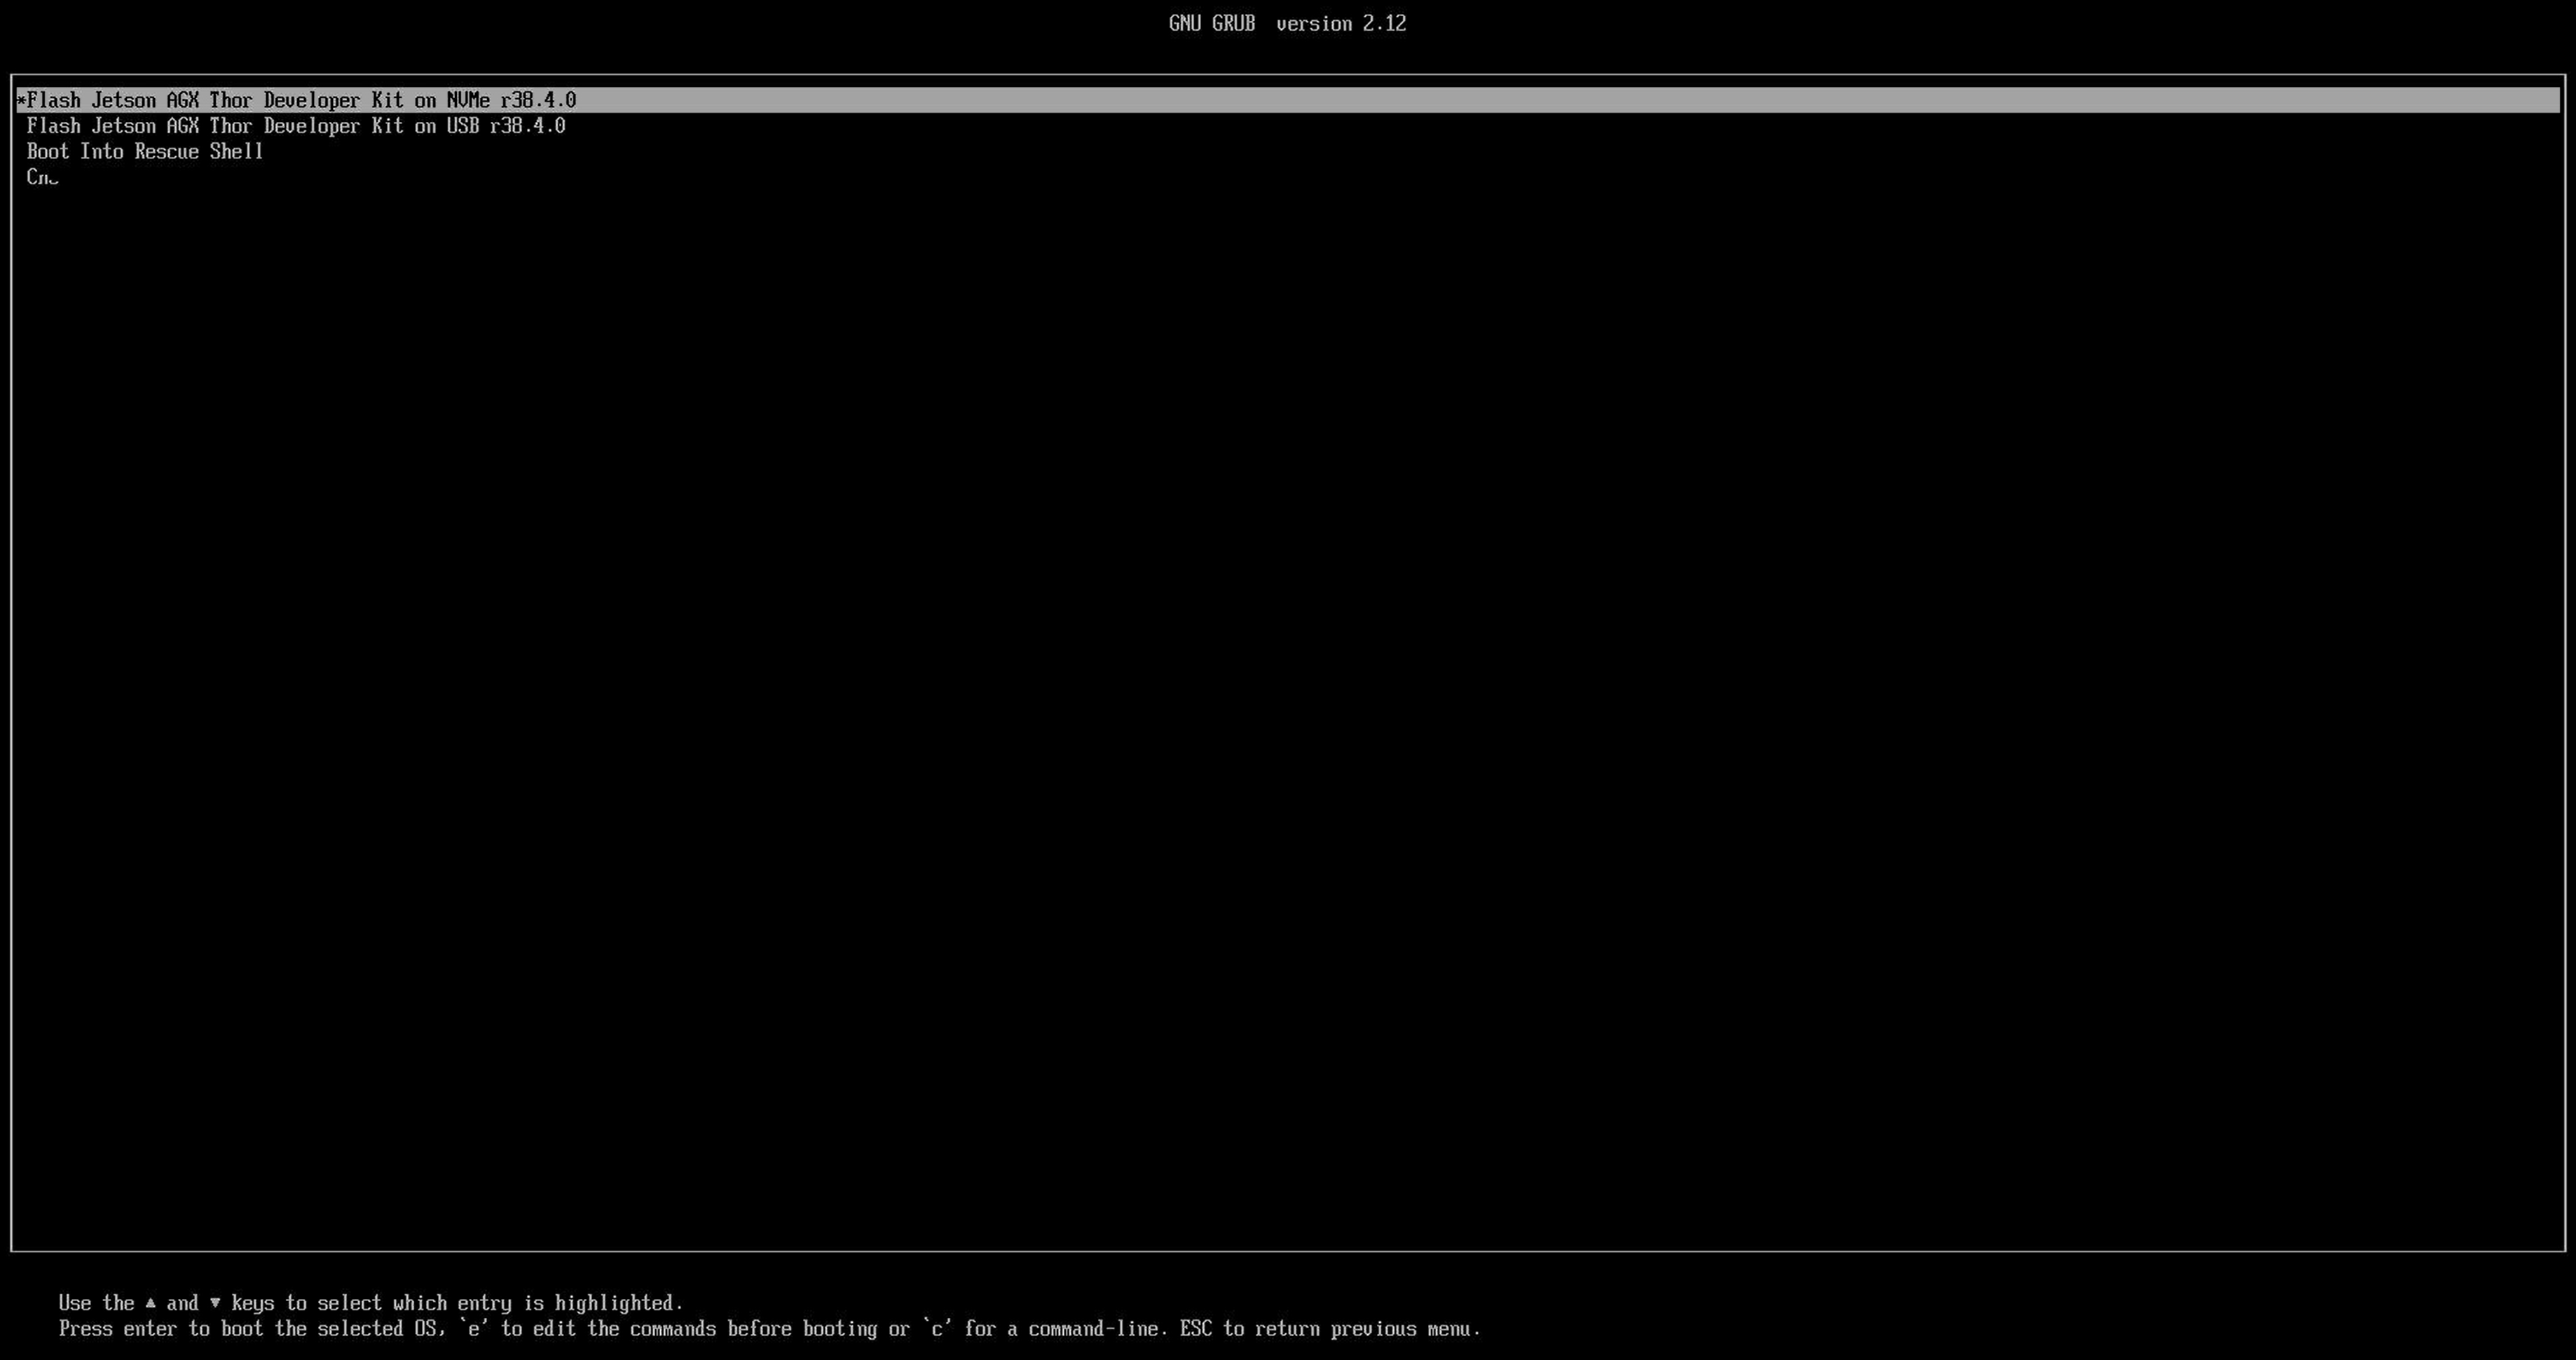
Jetson ISO GRUB Thor option menu

  1. Then, wait for the installation to complete; the entire process takes approximately 15 minutes.
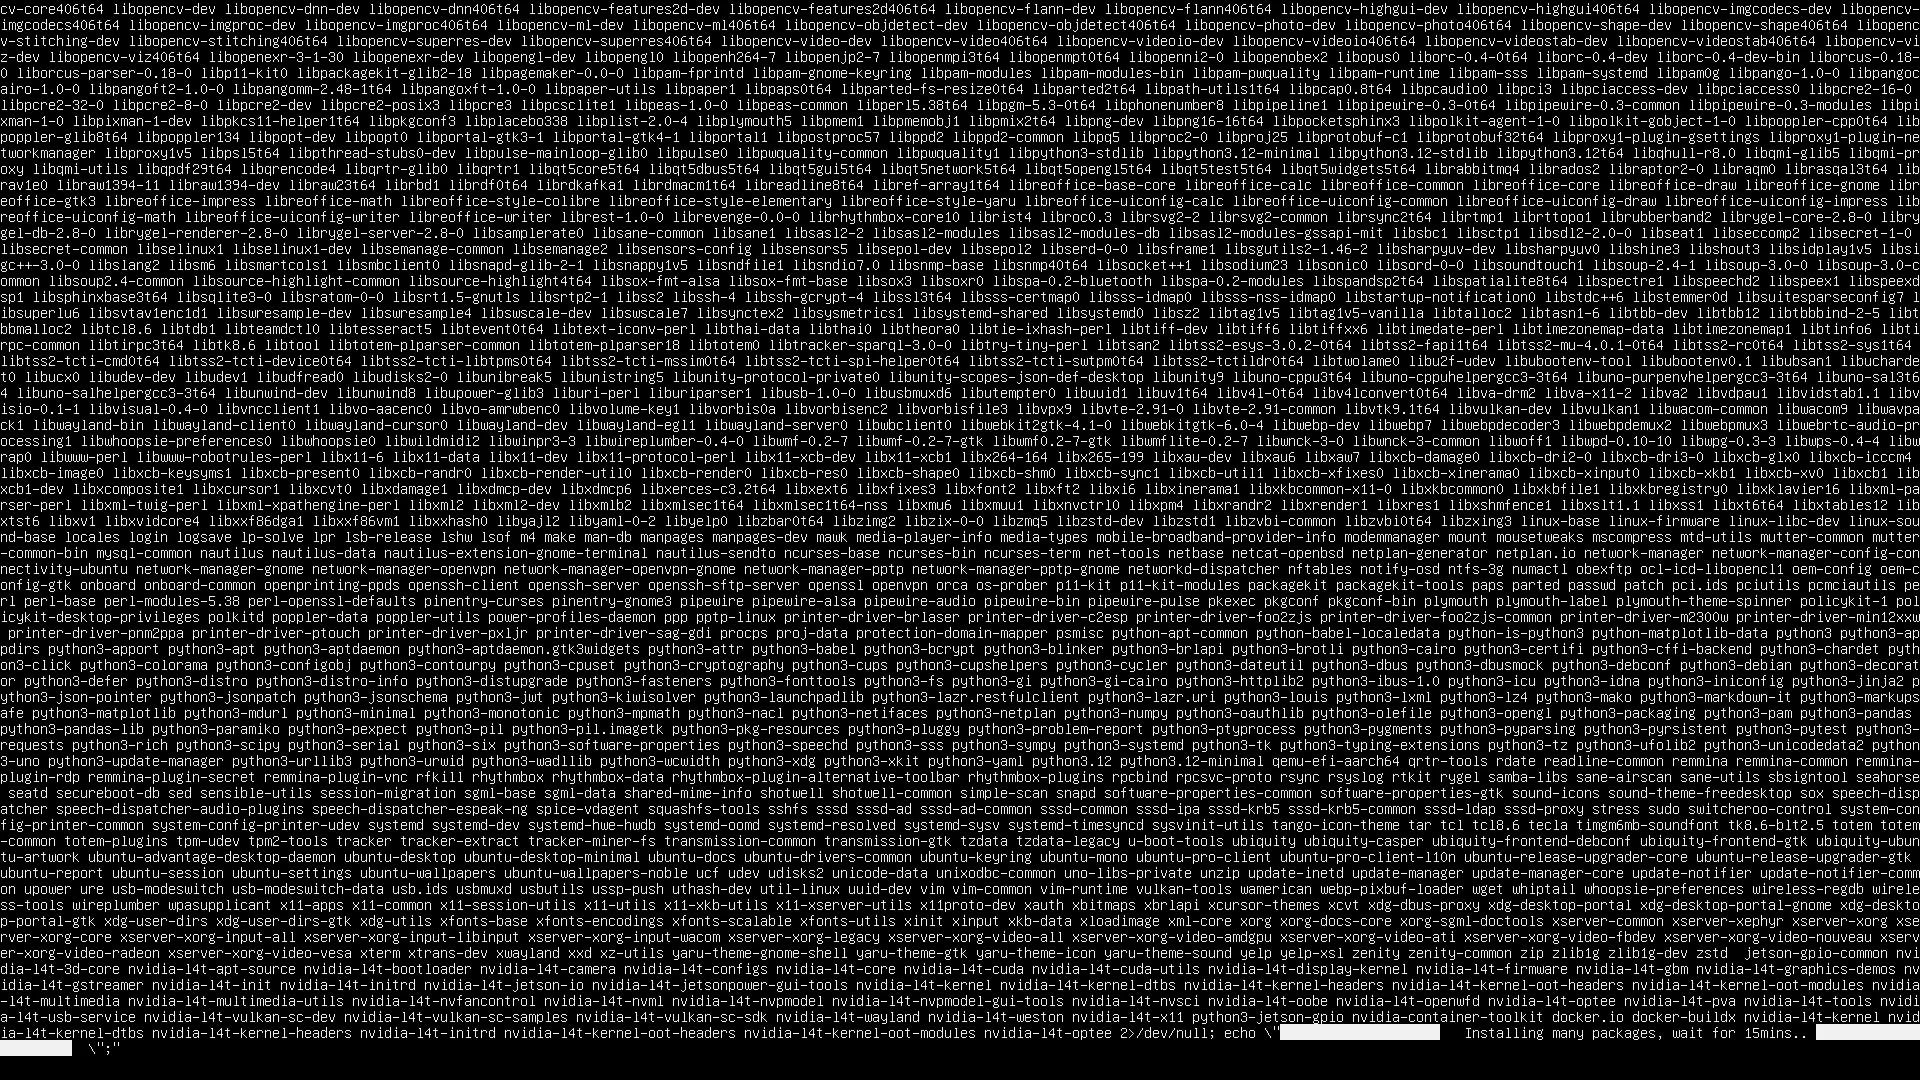
Jetson ISO progress showing wait for 15 minutes

  1. After installing the Jetson ISO, restart the system.

If this is your first time flashing the system, the UEFI boot version will be updated. Once the UEFI boot update is complete, the device will restart automatically.
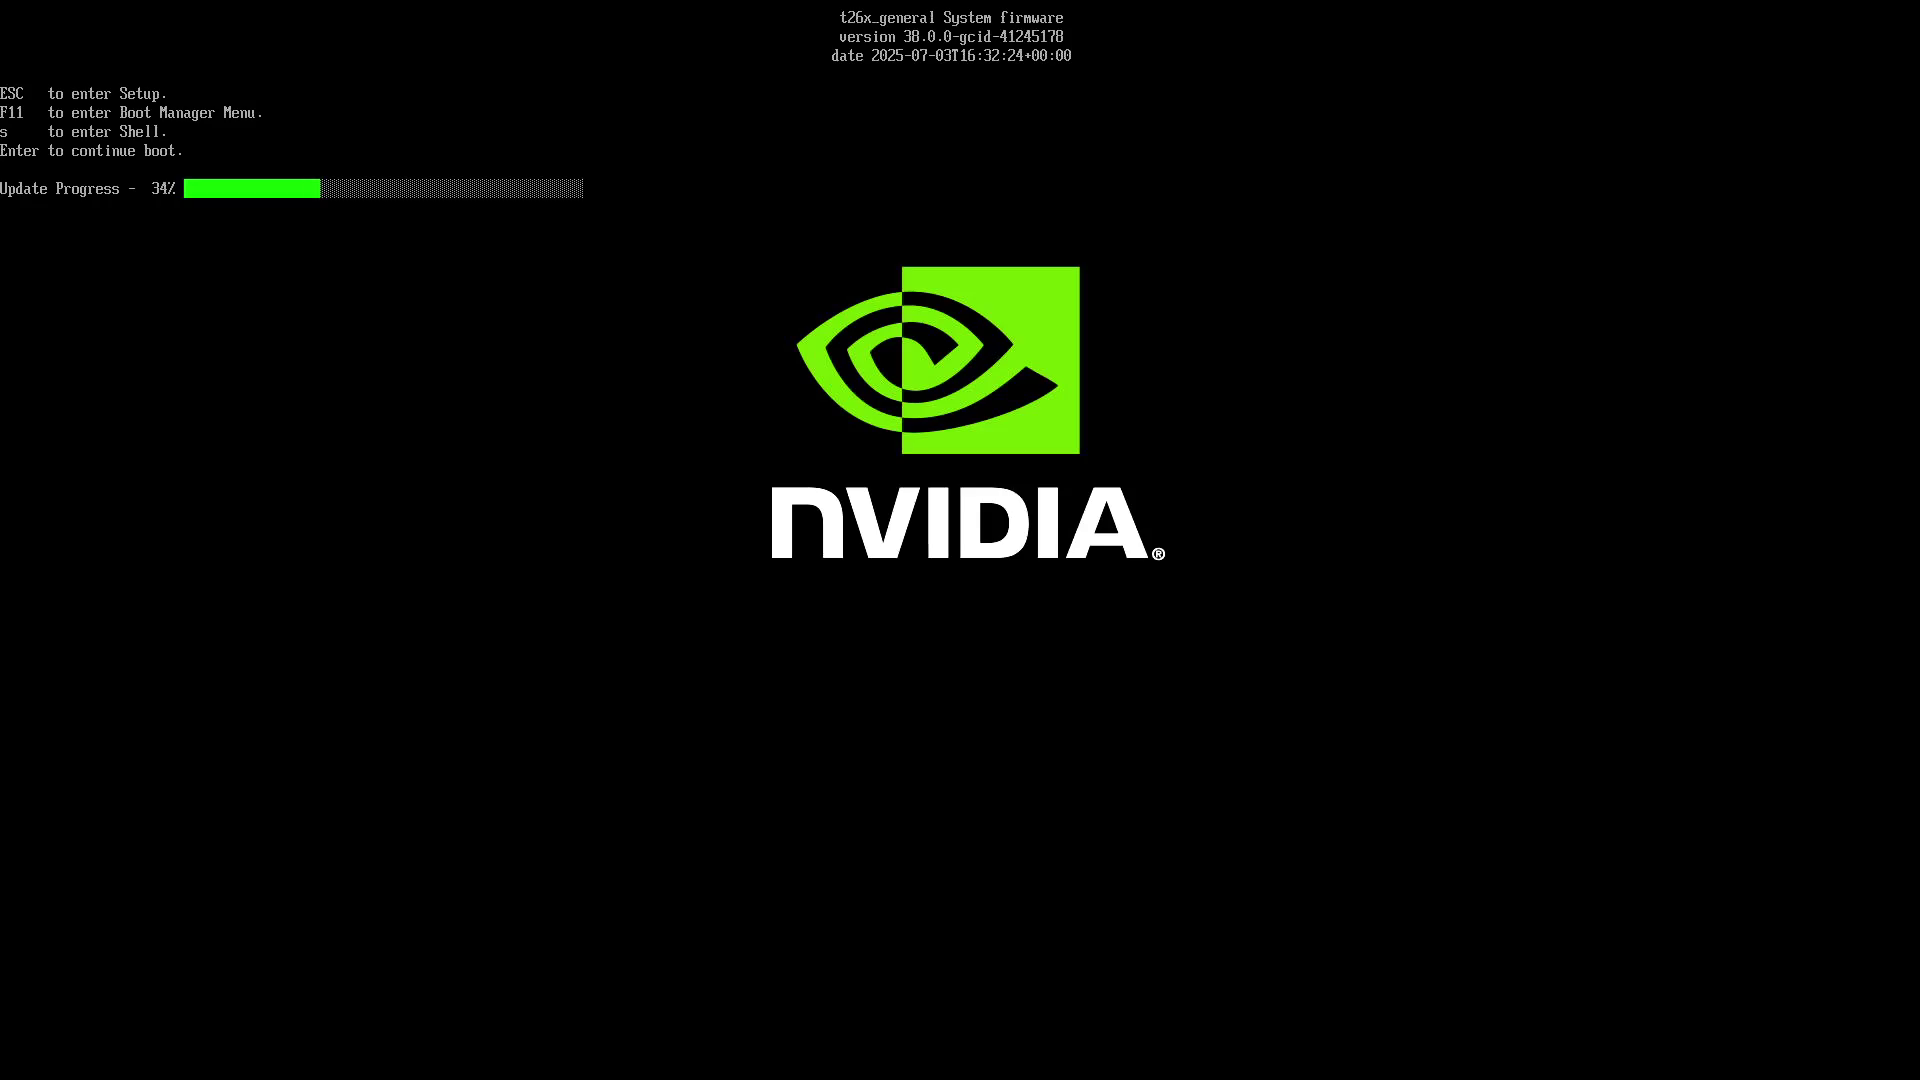
UEFI firmware update screen right after Jetson ISO installation

  1. Remove the USB drive, then power on the device again.

Starting with Jetson ISO version r38.4.0, the UEFI boot order is automatically configured to prioritize the USB drive after installation is complete. If you do not remove the USB drive, the system will boot back into the Jetson boot menu interface. Therefore, you must remove the USB drive before powering on the device again.


6. System Configuration

After removing the USB drive and powering on the device, you can now begin the initial Ubuntu configuration process ("oem-config"). Follow the on-screen prompts to create a default user account and configure other relevant settings.
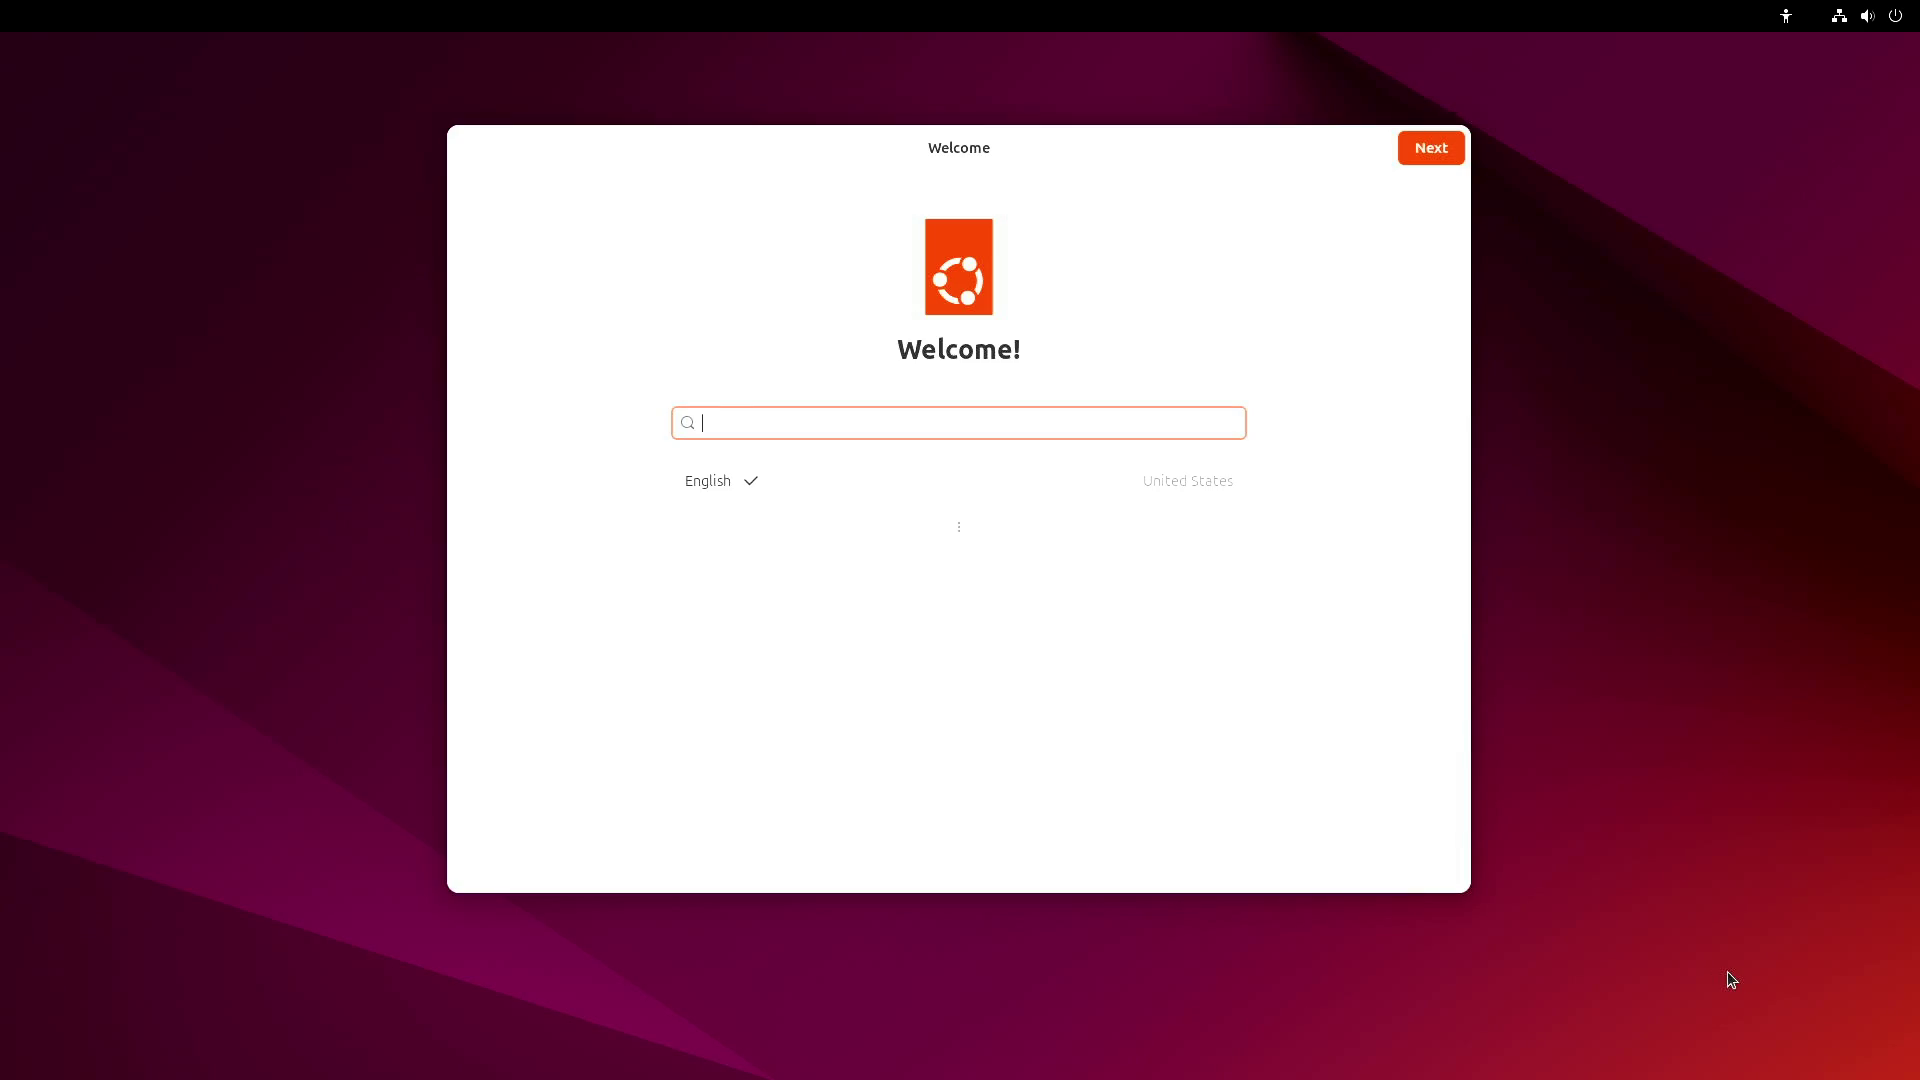
GUI oem-config top

Note: You must remember the username and password you set during this configuration process, as they will be required to access and use the system.

7. Booting the System

Once the configuration is complete, the system will restart again. The process of flashing the pure Jetson system via USB drive is now finished.
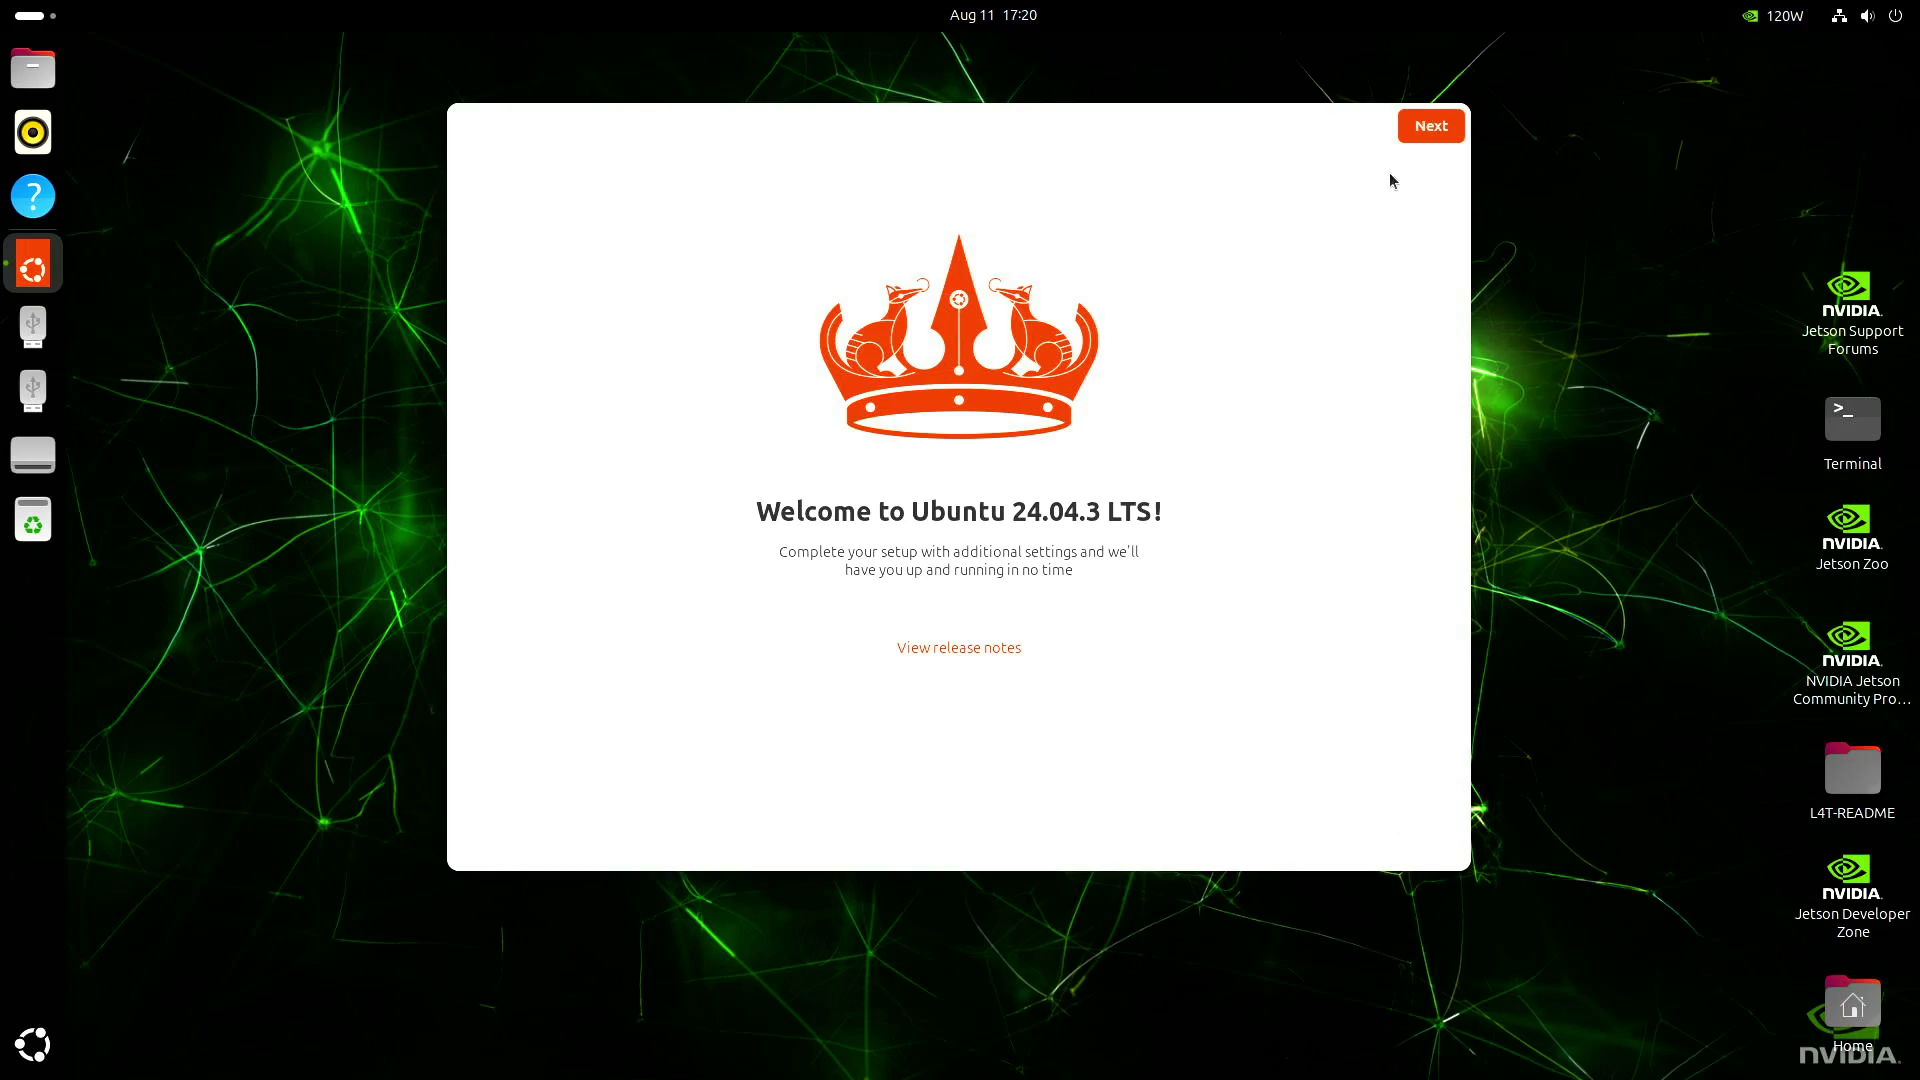
Ubuntu welcome screen


Official Reference Guide: https://docs.nvidia.com/jetson/agx-thor-devkit/user-guide/latest/quick_start.html#

Flashing a Pure Jetson System via SDK
Flashing the Jetson Bootloader using L4T

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文