yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
Jetson AGX Thor📖
1.Get started
  • 01.Learning Route
  • 02.Getting Started Quickly
2.Jetson basic course
  • 01.Jetson board introduction
  • 02.Flashing a Pure Jetson System via SDK
  • 03.Flashing a Pure Jetson System via USB Drive
  • 04.Flashing the Jetson Bootloader using L4T
  • 05.Replacing the SSD
  • 06.Install Jetpack environment
  • 07.Backup SSD system
  • 08.Restore factory image system
  • 09.SSD expansion
  • 10.SSD Speed Test
3.Basic setting course
  • 01.Basic knowledge
  • 02.Network configuration
  • 03.SSH remote login
  • 04.VNC remote control
  • 05.Remote file transfer
  • 06.Jtop tool
  • 07.Exchange space expansion
  • 08.Use VSCode
  • 09.Use VMware
  • 10.Change screen resolution
  • 11.Virtual Desktop
  • 12.Set root user password
  • 13.Configure sudo passwordless operation
  • 14.Managing custom services
  • 15.View system version information
4.OpenCV basic course
  • 01.Image reading
  • 02.Image saving
  • 03.Image modification
  • 04.Image scaling
  • 05.Image cropping
  • 06.Image translation
  • 07.Image mirroring
  • 08.Image grayscale conversion
  • 09.Image binarization
  • 10.Image edge detection
  • 11.Add line segments
  • 12.Add rectangles
  • 13.Add circular shape
  • 14.Add ellipses
  • 15.Add polygons
  • 16.Add Text
5.Vision basic course
  • 01.USB camera preview
  • 02.Use Jupyter Lab
  • 03.Use JetCam
6.Vision advanced course
01.Environment construction
  • 01.TensorFlow
  • 02.PyTorch
  • 03.Torchvision
  • 04.Torchaudio
02.DeepStream development
  • 01.DeepStream environment
  • 02.Four types of detection(traffic)
03.YOLO26 development
  • 01.YOLO Environment Setup
  • 02.CLI Usage
  • 03.Object Detection
  • 04.Instance Segmentation
  • 05.Pose Estimation
  • 06.Image Classification
  • 07.Oriented Bounding Boxes Object Detection
  • 08.Model Conversion
  • 09.Dataset Annotation
  • 10.Model Training_Conversion
  • 11.Model Prediction
04.Mediapipe development
  • 01.Mediapipe environment
  • 02.Hand detection
  • 03.Face detection
  • 04.Face effects
  • 05.3D object recognition
  • 06.Virtual brush
  • 07.Gesture recognition
  • 08.Finger control
  • 09.Posture estimation
  • 10.Face mask
  • 11.Overall detection
  • 12.Green scene removal(Human)
05.QR code recognition
  • 01.Barcode Recognition
  • 02.QR Code Recognition
  • 03.Machine Code Recognition
  • 04.Handwritten Digit Recognition
7.Docker basic course
  • 01.Docker introduction
  • 02.Docker installation
  • 03.Docker command
  • 04.Docker usage
  • 05.Docker interaction
8.ROS2-jazzy
1.ROS2 basic course
  • 1.Introduction to ROS2
  • 2.ROS2 install Jazzy
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
2.ROS2 vision course
  • 01.Camera preview (USB)
  • 02.Camera calibration (USB)
  • 03.AR vision (USB)
9.Offline AI model course
Offline large model (Text Interaction)
  • 1.Al large model environment deployment
  • 2.Install large model dialogue platform
  • 3.Meta Al Llama3.2 model
  • 4.Alibaba Cloud Qwen3 model
  • 5.Microsoft Phi-4-mini model
  • 6.DeepSeek DeepSeek-R1 model
  • 7.Alibaba Cloud Qwen2.5v visual multimodal large model
  • 8.Google Gemma3 visual multimodal large model
  • 9.Lava visual multimodal large model
  • 10.MiniCPM-V visual multimodal large model
  • 11.Multimodal visual understand application
  • 12.Multimodal text image application
  • 13.Multimodal video analysis application
  • 14.Multi module visual position application
  • 15.Multimodal table scanning application
  • 16.Multimodal autonomous agent application
Offline large model (Voice Interaction)
  • 0.Voice interaction hardware connection (ReadMe)
  • 1.Offline speech to text (ASR)
  • 2.Offline text to speech (TTS)
  • 3.AI large model voice interaction
  • 4.Multimodal visual understand speech interaction
  • 5.Multimodal text and graphics application
  • 6.Multimodal video analysis application
  • 7.Multi module visual position application
  • 8.Multimodal table scanning application
  • 9.Multimodal autonomous proxy application
  • 10.AI large model offline voice assistant
10.Online AI model course
Online large model (Text Interaction)
  • 1.OpenRouter large model API aggregation platform
  • 2.Multimodal Video Analysis Applications
  • 3.Multimodal visual localization application
  • 4.Multimodal table scanning application
  • 5.Multimodal autonomous proxy application
Online large model (Voice Interaction)
  • 0.Voice interaction hardware connection (ReadMe)
  • 1.Online speech to text (ASR)
  • 2.Online text to speech (TTS)
  • 3.AI large model voice interaction
  • 4.Multimodal visual understand speech interaction
  • 5.Multi module visual position application
  • 6.Multimodal table scanning application
  • 7.Multimodal autonomous proxy application
  • 8.AI large model offline voice assistant
11.Generative AI Applications
12.OpenClaw Advanced Development
  • 00.OpenClaw Quick Start on Jetson Platform
  • 01.OpenClaw Installation
  • 02.OpenClaw Online Platform Deployment
  • 03.OpenClaw Local Model Deployment
  • 04.OpenClaw TUI Interaction
  • 05.OpenClaw WebChat Interaction
  • 06.OpenClaw Tools Introduction
  • 07.OpenClawGate Gateway User Manual
  • 08.OpenClaw Features Overview
  • 09.OpenClawClawHub Introduction (Skill Installation)
  • 10. OpenClaw Switching Models
  • 11.OpenClaw Application - File Management
  • 12.OpenClaw Application - Camera
  • 13.OpenClaw Application - Browser Control
  • 14.OpenClaw Application - Script Execution
  • 15.OpenClaw Application - AI Programming
  • 16.OpenClaw Application - Dedicated AI Assistant
  • 17.OpenClaw WhatsApp Plugin Application
  • 18.OpenClaw Voice Assistant
Download
  • Code
  • SystemFile
  • VM_File
  • Tools
  • Jetson boot files
Download ZIP

Welcome to Jetson AGX Thor repository

05.Docker interaction

Docker interaction

Docker interaction1. Bash script1.1, Basic use (Docker)1.2, Run the script2. Shared data2.1. Shared folder2.2. Shared network3. Shared hardware3.1. Shared graphical interface3.2, ordinary camera3.3, Depth Camera

The tutorial mainly introduces the data and hardware interaction between the host and Docker.

1. Bash script

Bash (Bourne Again SHell) is a scripting language for automated tasks. Users can combine multiple commands and execute them in sequence!

Docker commands provide optional parameters to start containers, but too many parameters will affect the reading and understanding of the command

1.1, Basic use (Docker)

Basic script

​x
#!/bin/bash
​
docker run -it \
<image_name>:<tag> /bin/bash

Sample script

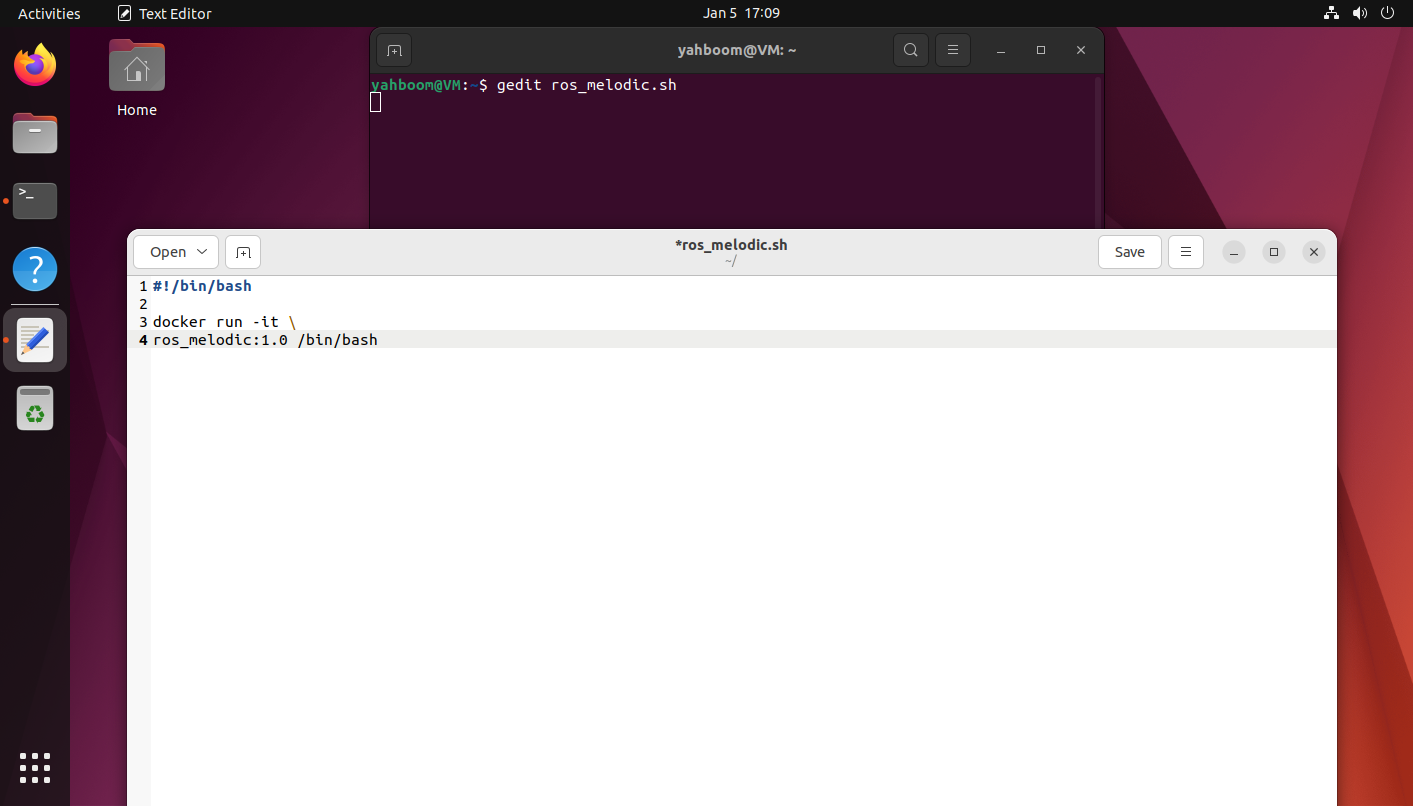
Write the example to the ros_melodic.sh file:

xxxxxxxxxx
gedit ros_melodic.sh
xxxxxxxxxx
#!/bin/bash
​
docker run -it \
ros_melodic:1.0 /bin/bash

image-20250105170938054

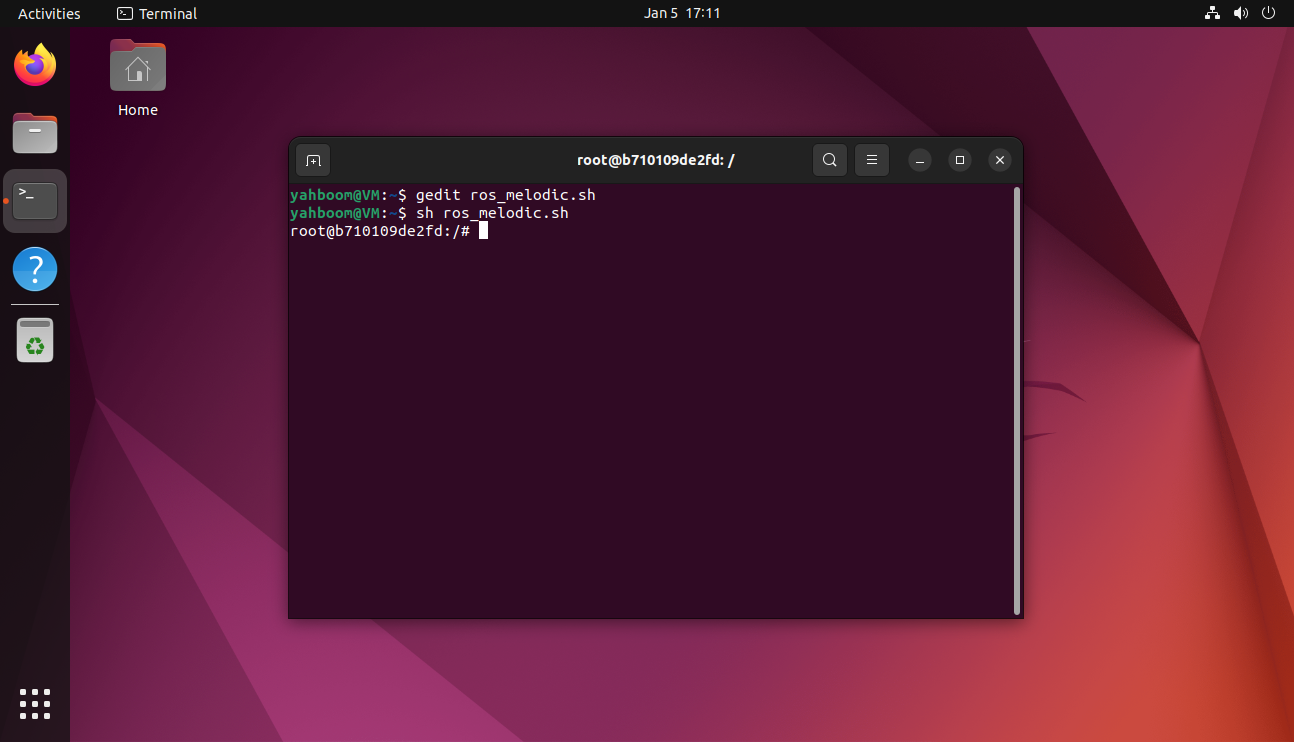
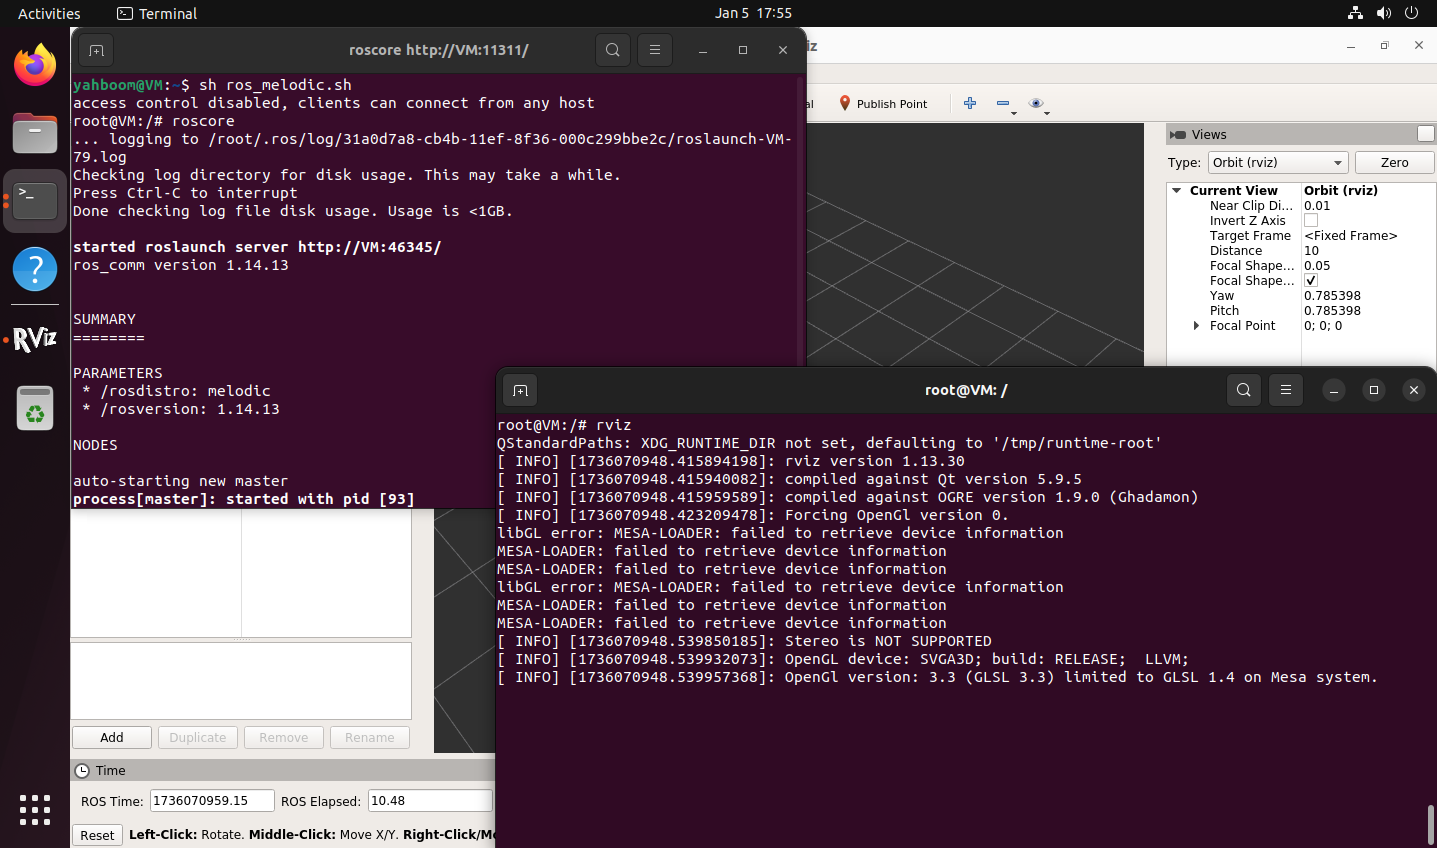
1.2, Run the script

xxxxxxxxxx
sh ros_melodic.sh

image-20250105171102690

2. Shared data

2.1. Shared folder

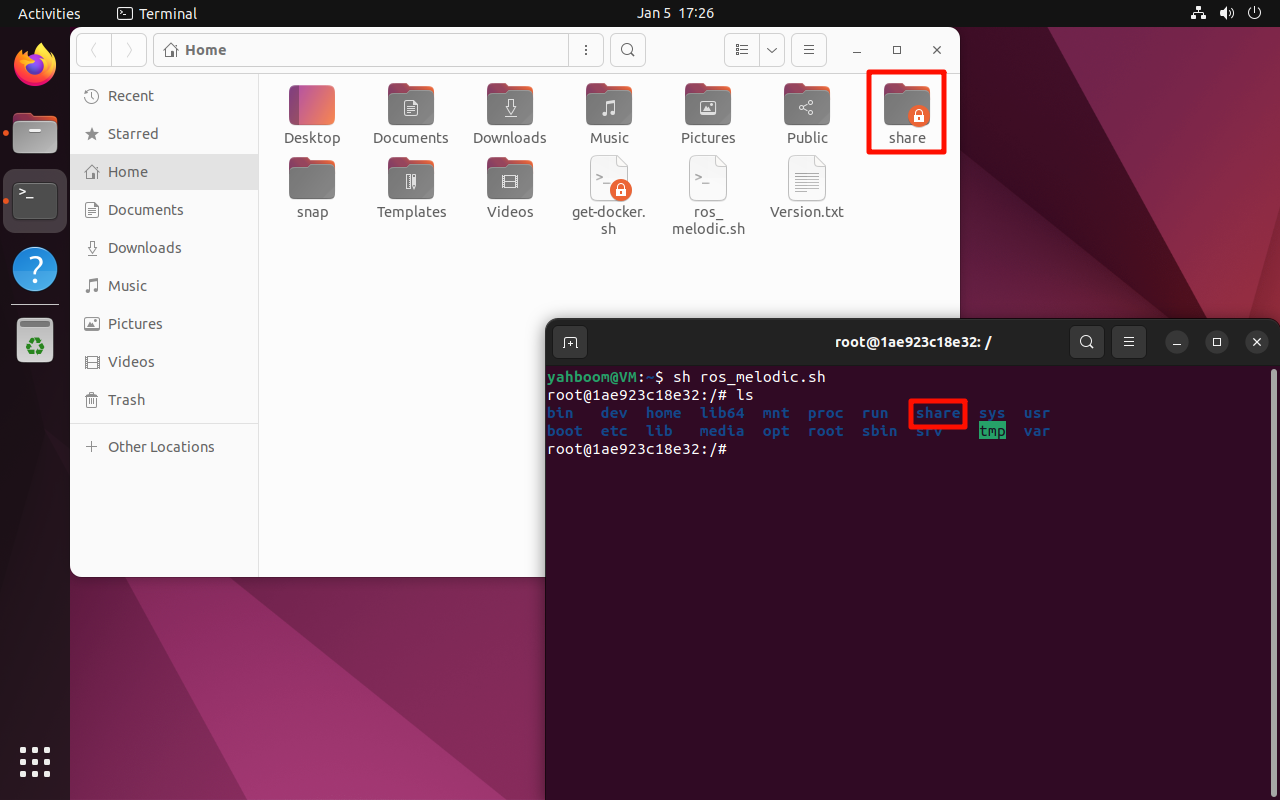
Share the host's share folder to Docker.

Sample script

xxxxxxxxxx
#!/bin/bash
​
docker run -it \
-v /home/yahboom/share:/share \
ros_melodic:1.0 /bin/bash

image-20250105172654529

2.2. Shared network

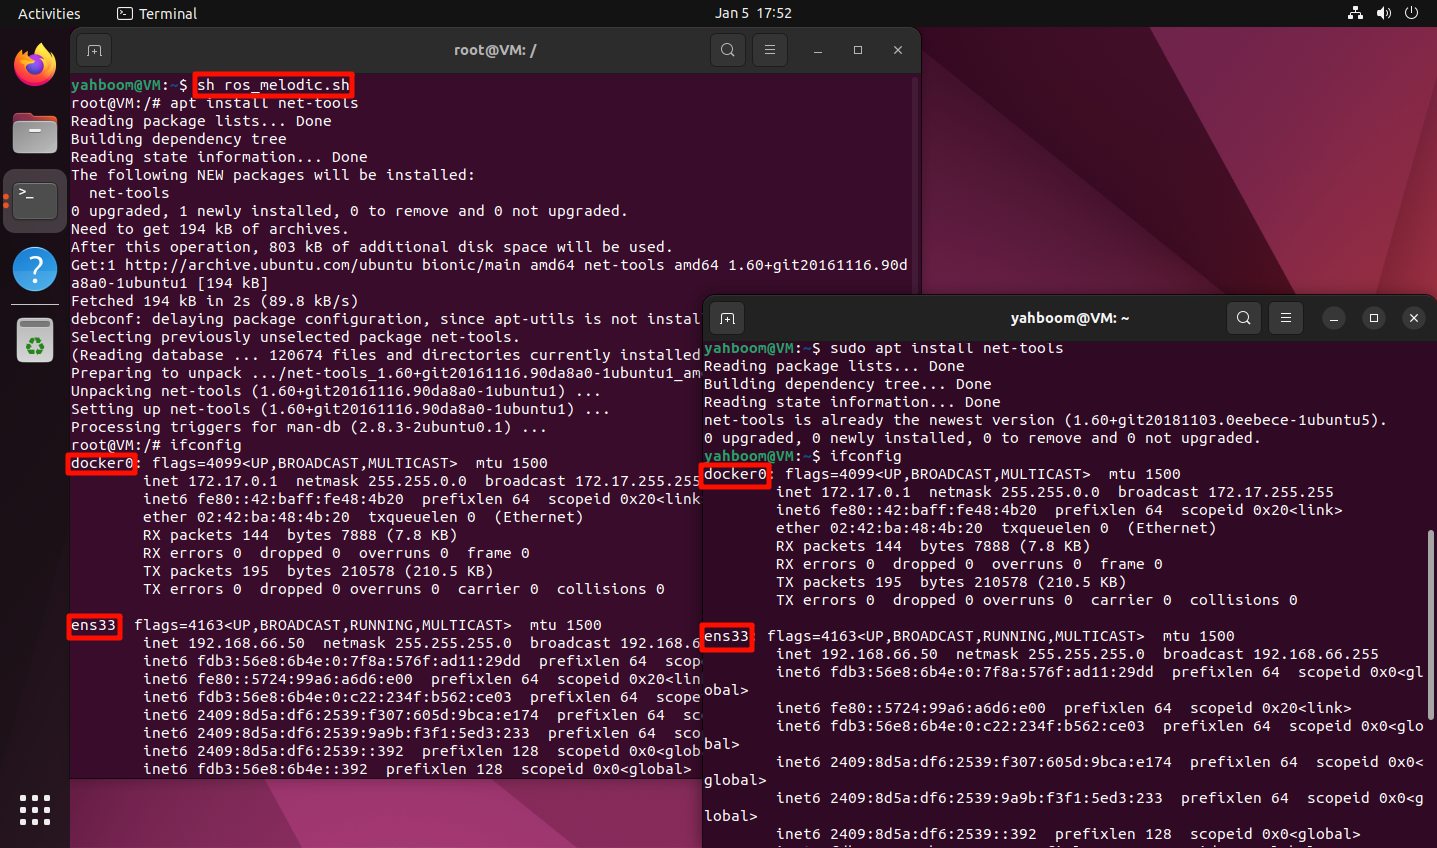
Share the host's network to Docker.

Sample script

xxxxxxxxxx
#!/bin/bash
​
docker run -it \
--net=host \
-v /home/yahboom/share:/share \
ros_melodic:1.0 /bin/bash

If you cannot use the ifconfig command, install net-tools:

xxxxxxxxxx
sudo apt install net-tools -y
xxxxxxxxxx
ifconfig

image-20250105175324374

3. Shared hardware

3.1. Shared graphical interface

Docker runs graphical interface programs and needs to output to the local display graphical interface.

Sample script

xxxxxxxxxx
#!/bin/bash
​
xhost +
​
docker run -it \
--net=host \
-e DISPLAY=$DISPLAY \
-e "QT_X11_NO_MITSHM=1" \
-v /tmp/.X11-unix:/tmp/.X11-unix \
-v /home/yahboom/share:/share \
ros_melodic:1.0 /bin/bash

image-20250105175603885

3.2, ordinary camera

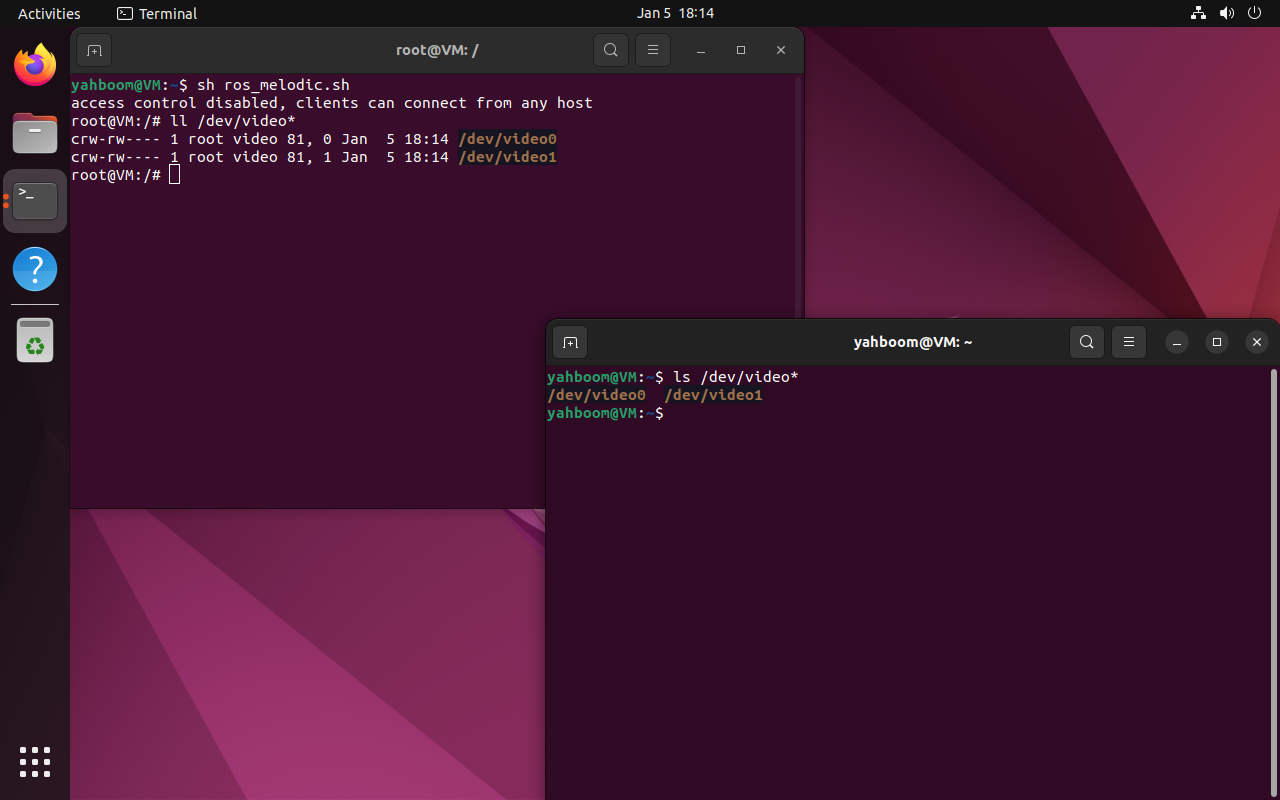
Ordinary camera mapping to Docker: just need to add the /dev/video* device number corresponding to the camera

xxxxxxxxxx
If only one camera is connected, it generally corresponds to /dev/video0
​

Sample script

xxxxxxxxxx
#!/bin/bash
​
xhost +
​
docker run -it \
--net=host \
-e DISPLAY=$DISPLAY \
-e "QT_X11_NO_MITSHM=1" \
-v /tmp/.X11-unix:/tmp/.X11-unix \
-v /home/yahboom/share:/share \
--device=/dev/video0 \
ros_melodic:1.0 /bin/bash

image-20250105181500835

3.3, Depth Camera

Compared with ordinary cameras, depth cameras require additional information to call the camera: Take Astra Pro as an example

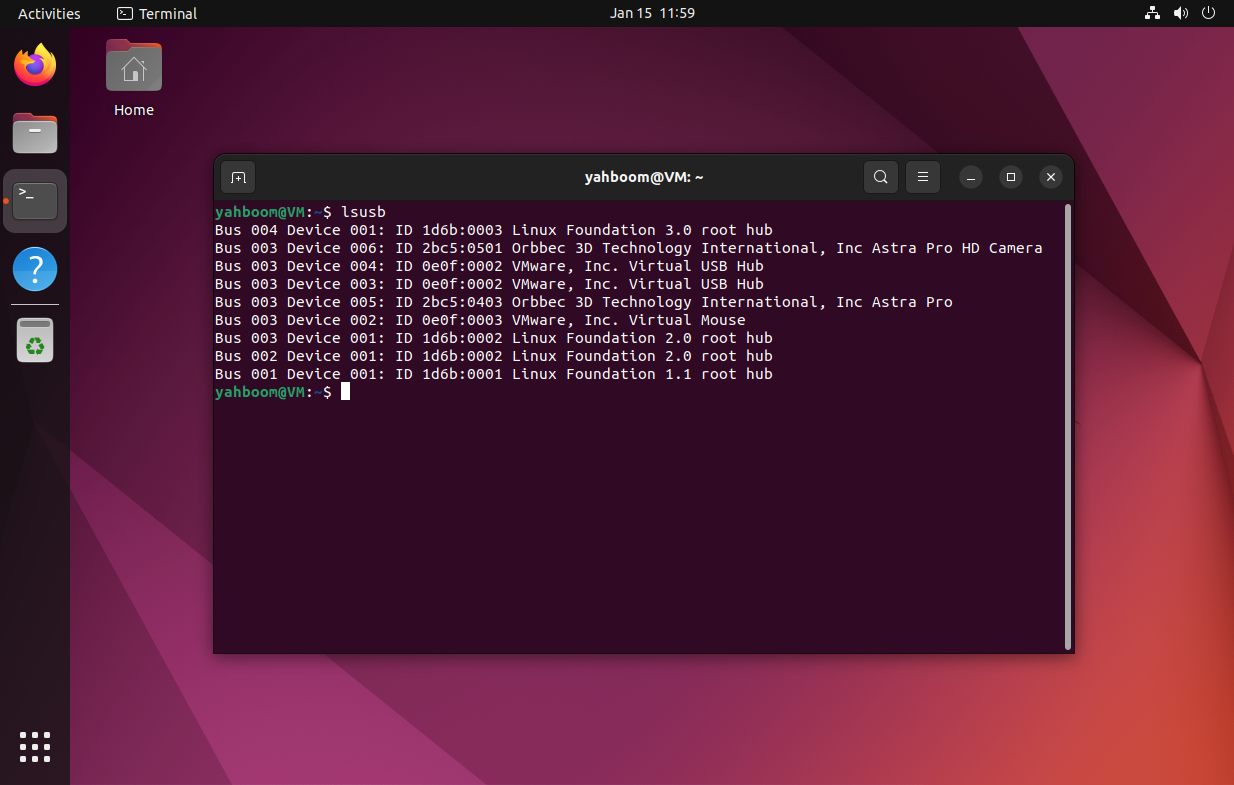
View USB device information

xxxxxxxxxx
lsusb

image-20250115115928531

Information we need to pay attention to: USB bus number, device number on the USB bus, device vendor ID, product ID

xxxxxxxxxx
Bus 003 Device 005: ID 2bc5:0403 Orbbec 3D Technology International, Inc Astra Pro
Bus 003 Device 006: ID 2bc5:0501 Orbbec 3D Technology International, Inc Astra Pro HD Camera

USB bus number: Bus 003

Device number on the USB bus: Device 005, Device 006

Vendor ID of the device: 2bc5

Product ID: 0403, 0501

Device can be located and device ID remapped based on vendor ID and product ID, where USB bus number and device number on USB bus affect the device connected in Docker.

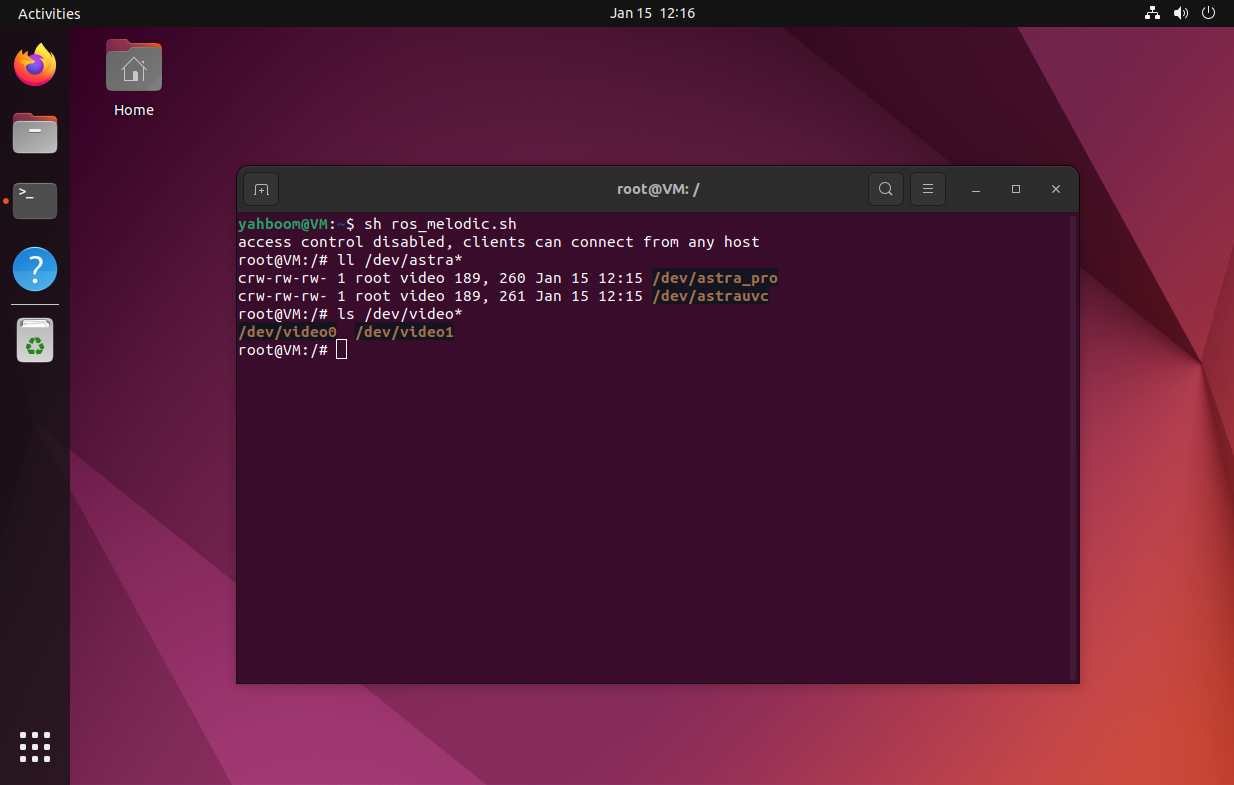
Device ID remap

The binding process and method are not introduced here, and the results are directly displayed. Device ID remap is not part of this tutorial.

Every time you start docker, you need to pay attention to the USB bus number and device number on USB bus corresponding to the depth camera. If the two are inconsistent, the camera will always prompt that the device cannot be connected when it is started in Docker.
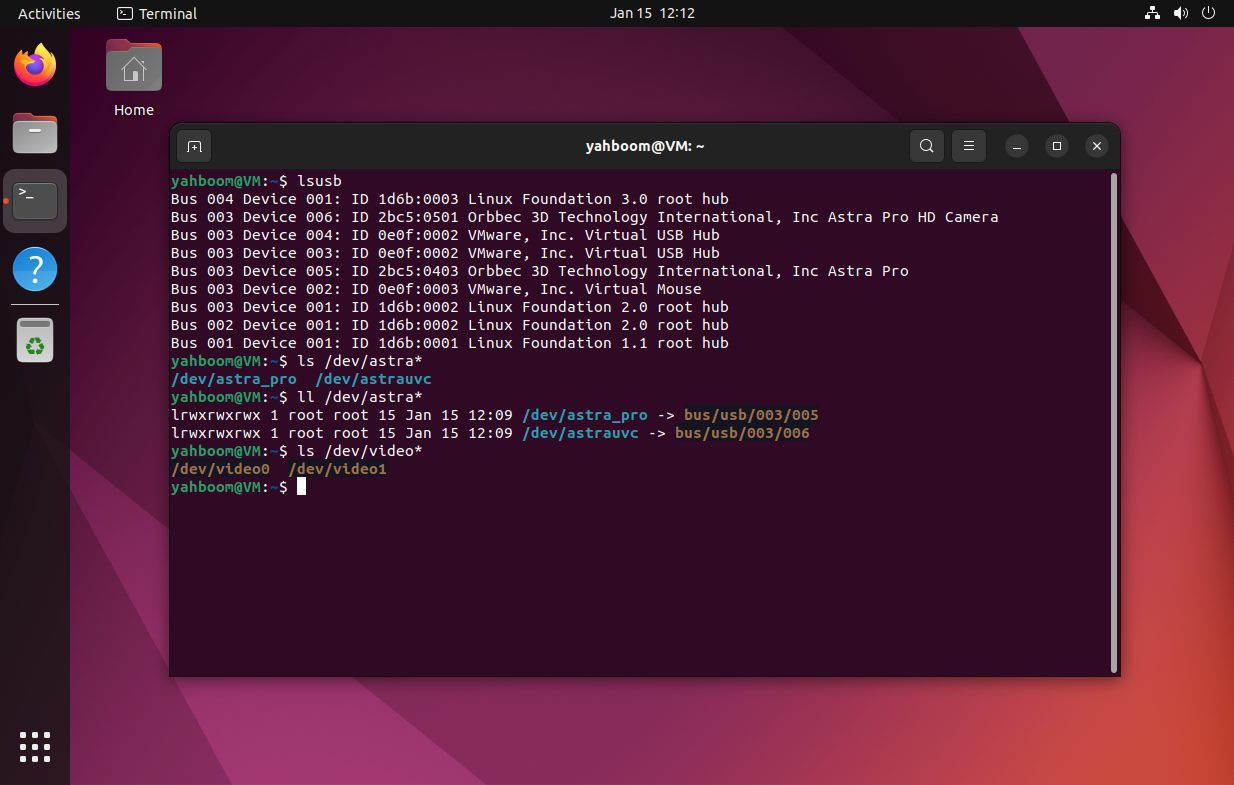
image-20250115121302577

Sample Script

xxxxxxxxxx
#!/bin/bash
​
xhost +
​
docker run -it \
--net=host \
-e DISPLAY=$DISPLAY \
-e "QT_X11_NO_MITSHM=1" \
-v /tmp/.X11-unix:/tmp/.X11-unix \
-v /home/yahboom/share:/share \
-v /dev/bus/usb/003/005:/dev/bus/usb/003/005 \
-v /dev/bus/usb/003/006:/dev/bus/usb/003/006 \
--device=/dev/astra_pro \
--device=/dev/astrauvc \
--device=/dev/video0 \
--device=/dev/video1 \
ros_melodic:1.0 /bin/bash

image-20250115121659566

Docker usage
Introduction to ROS2

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文