Welcome to Raspbot V2 repository
当製品の日本語版マニュアル資料は、こちらからご取得ください。
3. URDF Model
URDF Model
1. Program function description
Start the car, run the program in the terminal, and the URDF model will be displayed in rviz.
2. Enter the car docker
Open the terminal and enter the following command to enter the docker,
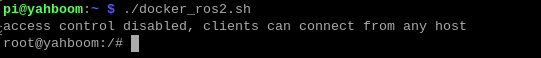
./docker_ros2.sh
The following interface appears, which means that you have successfully entered Docker. Now you can control the car through commands.
4. Program startup
Load URDF and generate a simulation controller and start rviz, input in the terminal,
xxxxxxxxxxros2 launch yahboomcar_description display_launch.py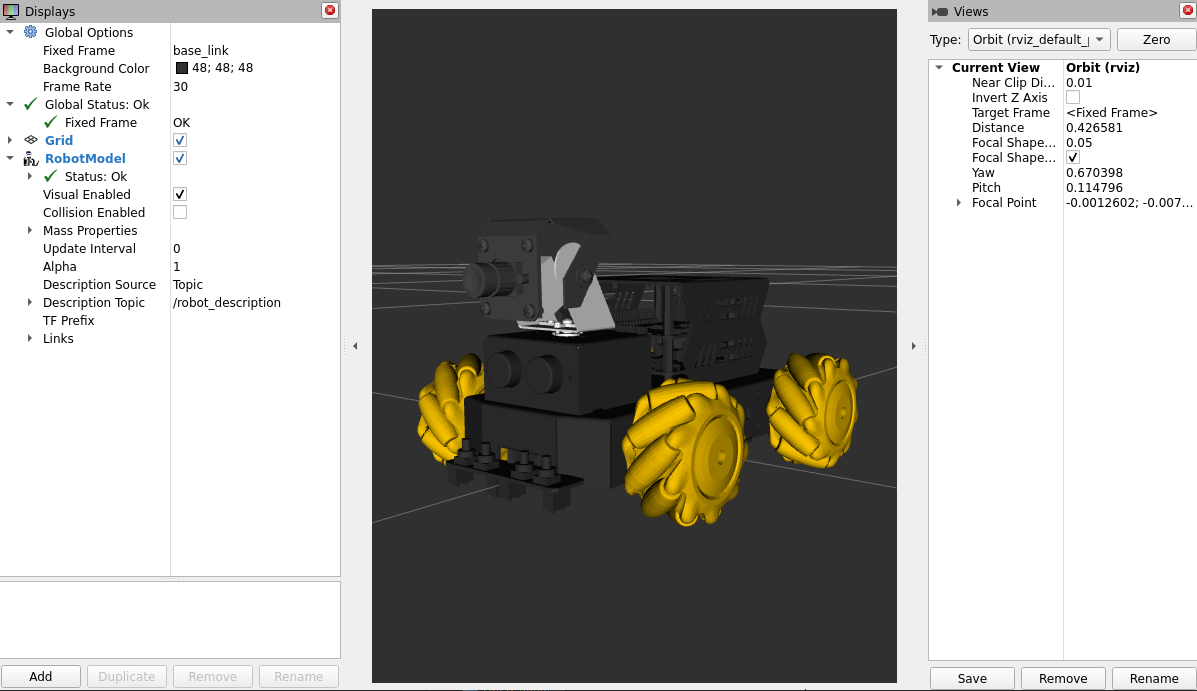
Then, use the mouse to adjust the viewing angle and slide the simulated controller just created, and you can see the tires/camera of the car changing.
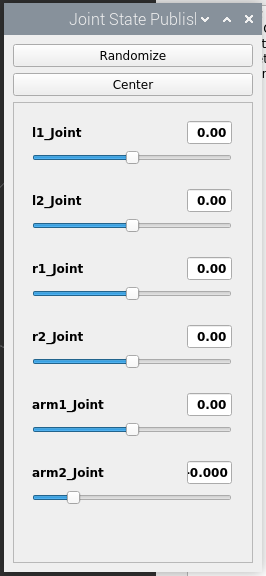
l1_Joint: Control the left front wheel
l2_Joint: Control the left rear wheel
r1_Joint: Control the right front wheel
r2_Joint: Control the right rear wheel
arm1_Joint: Control gimbal 1
arm2_Joint: Control gimbal 2
Randomize: Randomly publish values to each joint
Center: All joints return to the center
5. Code analysis
Code location,
xxxxxxxxxx/root/yahboomcar_ws/src/yahboomcar_description/launch
display_launch.py
xfrom ament_index_python.packages import get_package_share_path
from launch import LaunchDescriptionfrom launch.actions import DeclareLaunchArgumentfrom launch.substitutions import Command, LaunchConfiguration
from launch_ros.actions import Nodefrom launch_ros.parameter_descriptions import ParameterValue
def generate_launch_description(): urdf_tutorial_path = get_package_share_path('yahboomcar_description') default_model_path = urdf_tutorial_path / 'urdf/Raspbot-V2.urdf' default_rviz_config_path = urdf_tutorial_path / 'rviz/raspbotv2.rviz'
model_arg = DeclareLaunchArgument(name='model', default_value=str(default_model_path), description='Absolute path to robot urdf file') robot_description = ParameterValue(Command(['xacro ', LaunchConfiguration('model')]), value_type=str) rviz_arg = DeclareLaunchArgument(name='rvizconfig', default_value=str(default_rviz_config_path), description='Absolute path to rviz config file') robot_state_publisher_node = Node( package='robot_state_publisher', executable='robot_state_publisher', parameters=[{'robot_description': robot_description}] )
joint_state_publisher_gui_node = Node( package='joint_state_publisher_gui', executable='joint_state_publisher_gui' )
tf_base_footprint_to_base_link = Node( package='tf2_ros', executable='static_transform_publisher', arguments=['0', '0', '0.05', '0.0', '0.0', '0.0', 'base_footprint', 'base_link'], ) rviz_node = Node( package='rviz2', executable='rviz2', name='rviz2', output='screen', arguments=['-d', LaunchConfiguration('rvizconfig')], ) return LaunchDescription([ model_arg, joint_state_publisher_gui_node, robot_state_publisher_node, tf_base_footprint_to_base_link, rviz_arg, rviz_node ])
- model_arg: load model parameters, the loaded model is Raspbot-V2.urdf, the location is
/root/yahboomcar_ws/src/yahboomcar_description/urdf/Raspbot-V2.urdf - joint_state_publisher_gui_node: publish sensor_msgs/JointState message
- robot_state_publisher_node: robot state publishing
- tf_base_footprint_to_base_link: publish static transformation from base_footprint to base_link
6. URDF model
URDF, the full name is Unified Robot Description Format, translated into Chinese as Unified Robot Description Format, is a robot model file described in XML format, similar to D-H parameters.
xxxxxxxxxx<?xml version="1.0" encoding="utf-8"?>
The first line is a required field for XML and describes the version information of XML.
xxxxxxxxxx<robot name="RaspbotV2"></robot>The second line describes the current robot name; all information about the current robot is included in the [robot] tag.
6.1. Components
- Link, connecting rod, can be imagined as a human arm
- Joint, joint, can be imagined as a human elbow joint
Relationship between link and joint: two links are connected by joints, imagine that the arm has a forearm (link) and an upper arm (link) connected by an elbow joint (joint).
6.1.1. Link
1), Introduction
In the URDF descriptive language, link is used to describe physical properties,
- Describe visual display, label.
- Describe collision properties, label.
- Describe physical inertia, label is not commonly used.
Links can also describe the size of the connecting rod (size)\color (color)\shape (shape)\inertial matrix (inertial matrix)\collision parameters (collision properties), etc. Each Link will become a coordinate system.
2), Sample code
xxxxxxxxxx<link name="base_link"> <inertial> <origin xyz="0.013209067968915 0.000305835286849597 0.034565647785585" rpy="0 0 0" /> <mass value="0.315736522899678" /> <inertia ixx="0.000126930677782624" ixy="-1.93570093947537E-07" ixz="-3.2159760519397E-08" iyy="0.000217028578454845" iyz="3.16386759318505E-07" izz="0.000309637617387382" /> </inertial> <visual> <origin xyz="0 0 0" rpy="0 0 0" /> <geometry> <mesh filename="package://yahboomcar_description/meshes/base_link.STL" /> </geometry> <material name=""> <color rgba="0.203921568627451 0.203921568627451 0.203921568627451 1" /> </material> </visual> <collision> <origin xyz="0 0 0" rpy="0 0 0" /> <geometry> <mesh filename="package://yahboomcar_description/meshes/base_link.STL" /> </geometry> </collision> </link>- Tag introduction
- origin: describes the position information; the xyz attribute describes the coordinate position in the environment, and the rpy attribute describes its own posture.
- mess: describes the quality of the link.
- inertia: inertial reference system. Due to the symmetry of the rotational inertia matrix, only 6 upper triangular elements ixx, ixy, ixz, iyy, iyz, izz are required as attributes.
- geometry: the tag describes the shape; the main function of the mesh attribute is to load the texture file, and the filename attribute is the file address of the texture path
- material: the tag describes the material; the name attribute is a required item, which can be empty and can be repeated. The rgba attribute in the [color] tag is used to describe red, green, blue, and transparency, separated by spaces.
6.1.2, joints
- Introduction
Describes the relationship between two joints, motion position and speed limits, kinematic and dynamic properties. There are several types of joints:
- fixed: fixed joints. No movement is allowed, it serves as a connection.
- continuous: revolute joint. It can rotate continuously, without rotation angle limit.
- revolute: revolute joint. Similar to continuous, with rotation angle limit.
- prismatic: sliding joint. It moves along a certain axis, with position limit.
- floating: floating joint. It has six degrees of freedom, 3T3R.
- planar: planar joint. It allows translation or rotation above the plane orthogonal to the plane.
2), sample code
xxxxxxxxxx <joint name="arm1_Joint" type="revolute"> <limit effort="100" velocity="1" lower="-1.57" upper="1.57"/> <origin xyz="0.058 0 0.0575" rpy="0 0 0" /> <parent link="base_link" /> <child link="arm1_Link" /> <axis xyz="0 0 1" /> <limit lower="0" upper="0" effort="0" velocity="0" /> </joint>In the [joint] tag, the name attribute is a required item, describing the name of the joint, and it is unique. In the [joint] tag, the type attribute is filled in with the six major joint types.
3), Tag introduction
- origin: sub-tag, refers to the relative position of the rotation joint in the parent coordinate system.
- parent, child: parent, child sub-tags represent two links to be connected; parent is a reference object, and child rotates around the parent.
- axis: sub-tag indicates which axis (xyz) the link corresponding to the child rotates around and the amount of rotation around the fixed axis.
- limit: sub-tag is mainly used to limit the child. The lower attribute and upper attribute limit the range of rotation, and the effort attribute limits the force range during the rotation process. (positive and negative value, in Newton or N), the velocity attribute limits the speed of rotation, in meters/second or m/s.
- mimic: describes the relationship between this joint and the existing joints.
- safety_controller: describes the safety controller parameters. Protect the movement of the robot joints.