yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
ROSMASTER M3📖
00.Configuration and Operation Guide
  • 1.Quick start handle to control the car
  • 2.Log in to the car and view the code
  • 3.Enter the Docker (For RPI5)
  • 4.Camera and Radar Configuration (Must Read)
  • 5.Assembly video
  • 6.Modify Control Board Firmware Parameters
01.Chassis Control Course
  • 01.ROS control
  • 02.Handle control
  • 03.Keyboard control
  • 04.Robot state estimation
  • 05.Data remote visualization
  • 06.Line velocity calibration
  • 07.Angular velocity calibration
  • 08.Robot URDF model
  • 09.Line patrol automatic driving
  • 10.Patrol
02.Lidar Course
  • 01.Lidar introduction and use
  • 02.Lidar point cloud fusion and filtering
  • 03.Lidar obstacle avoidance
  • 04.Lidar tracking
  • 05.Lidar guard
  • 06.Gmapping-SLAM mapping
  • 07.Cartographer-SLAM mapping
  • 08.slam_toolbox mapping
  • 09.Lifelong mapping
  • 10.Navigation2 single-point navigation avoid
  • 11.Navigation2 multi-point navigation avoid
  • 12.Cartographer relocalization navigation
  • 13.slam_toolbox localization and navigation
  • 14.Synchronous mapping and navigation
  • 15.RTAB-Map mapping
  • 16.RTAB-Map navigation
  • 17.APP mapping and navigation
03.AI Model Basics
  • 1.AI large model types and principles
  • 2.RAG retrieval enhancement and model training samples
  • 3.Embodied intelligent robot system architecture
  • 4.Embodied intelligent functions core source code
04.AI Model Development
  • 01.Register a model service provider account
  • 02.Configuring API-KEY
  • 03.Introduction to Dify
  • 04.Basic Dify Features
  • 05.AI Large Model Development - chatbot
  • 06.Deploy the RAG knowledge base
  • 07.RAG knowledge base + chatbot
  • 08.AI agent workflow
  • 09.Custom wake-up response
  • 10.Core module testing tools
05.AI Model - Voice Version
  • 1.Semantic understand and command follow
  • 2.Multimodal visual understanding
  • 3.Multimodal visual understanding+SLAM navigation
  • 4.Intention estimation
06.AI Model - Text Version
  • 1.Semantic understand and command follow
  • 2.Multimodal visual understanding
  • 3.Multimodal visual understanding+SLAM navigation
  • 4.Intention estimation
07.Road Network Planning and Navigation
  • 1.Introduction and Quick Start
  • 2.Constructing a Pose Map
  • 3.Road Network Labelling
  • 4.Inter-Road Network Planning and Navigation
  • 5.Free-Pose Road Network Navigation
  • 6.Path Replanning
08.Autonomous Driving expand(Need purchase track map)
  • 01.Environment Setup & Precautions
  • 02.YOLO Environment Configuration
  • 03.Data Collection
  • 04.Data Annotation
  • 05.YOLOv11 Model Training
  • 06.Model Format Conversion
  • 07.Vehicle Centerline Calibration
  • 08.Lane Detection
  • 09.Lane-Keeping Autonomous Driving
  • 10.Traffic Sign Recognition
  • 11.Comprehensive Autonomous Driving Applications
  • 12.Autonomous Driving Debugging Module
  • 13.Road Network Planning with Track Map
  • 14.Road Network Planning with Traffic Sign Recognition
  • 15.AI Model with Road Network Planning
  • 16.AI Model with Track Map and SLAM Navigation
  • 17.AI Model with Road Network Planning and Autonomous Driving
09.Depth Camera Course
  • 01.Dabai_DCW2 Camera Introduction
  • 02.Nuwa-HP60C Camera Introduction
  • 03.Depth Pseudo-Color Image
  • 04.Depth Camera Distance Measurement
  • 05.Wood Block Volume Measurement
  • 06.Edge Detection
  • 07.YOLOv11 Object Detection
  • 08.YOLOv11 Object Tracking
  • 09.Color Following
  • 10.Face Following
  • 11.QR Code Following
  • 12.Machine Code Following
  • 13.KCF Object Tracking
  • 14.QR Code Motion Control
  • 15.AR Vision
10.Mediapipe Visual Course
  • 01.Hand Detection
  • 02.Posture Detection
  • 03.Overall Detection
  • 04.Facial Landmark Detection
  • 05.3D Object Recognition
  • 06.Face Detection
  • 07.Gesture Recognition
  • 08.Face Special Effects
  • 09.Brush
  • 10.Finger Control
  • 11.Palm Target Positioning
  • 12.Fingertip Trajectory Recognition
  • 13.Gesture Following
  • 14.Posture Following
  • 15.Gesture Motion Control
11.Multi-vehicle Course
  • 1.Multi-vehicle Control
  • 2.Multi-vehicle Navigation
  • 3.Multi-vehicle Platoon
12.AI Large Model Basic Course
Offline large model (Text Interaction)
  • 0. AI Large Model Mirroring Explanation
  • 1. Deployment of large-scale AI models
  • 2. Installation of the large model dialogue platform
  • 3. Meta AI Llama 3.2 model
  • 4. Alibaba Cloud Qwen3 Model
  • 5. DeepSeek DeepSeek-R1 model
  • 6. Microsoft Phi-4 mini model
  • 7. Alibaba Cloud Qwen2.5vl Visual Multimodal Large Model
  • 8. Google Gemma3 Visual Multimodal Large Model
  • 9. Llava Visual Multimodal Large Model
  • 10. Multimodal Visual Understanding Applications
  • 11.MiniCPM-V Visual Multimodal Large Model
  • 12. Multimodal Text-Based Image Application
  • 13. Multimodal Video Analysis Application
  • 14. Multimodal table scanning application
  • 15. Multimodal visual positioning applications
  • 16. Multimodal Autonomous Agent Application
Offline large model (Voice Interaction)
  • 0. Voice Interaction Hardware Connection (Must Read)
  • 1. Offline speech-to-text (ASR)
  • 2. Offline Text-to-Speech (TTS)
  • 3. AI large model voice interaction
  • 4. Multimodal visual understanding and voice interaction
  • 5. Multimodal Text-Based Image Application
  • 6. Multimodal Video Analysis Application
  • 7. Multimodal visual positioning applications
  • 8. Multimodal table scanning application
  • 9. Multimodal Autonomous Agent Applications
  • 10. AI large model offline voice assistant
Online large model (Text Interaction)
  • 1. OpenRouter Large Model API Aggregation Platform
  • 2. Multimodal visual understanding applications
  • 3. Multimodal visual positioning applications
  • 4. Multimodal table scanning application
  • 5. Multimodal Autonomous Agent Applications
Online large model (Voice Interaction)
  • 0. Voice Interaction Hardware Connection (Must Read)
  • 1. Online speech-to-text (ASR)
  • 2. Online Text-to-Speech (TTS)
  • 3. AI large model voice interaction
  • 4. Multimodal visual and voice interaction
  • 5. Multimodal visual positioning applications
  • 6. Multimodal table scanning application
  • 7. Multimodal Autonomous Agent Applications
  • 8. AI large model online voice assistant
13.Control Board Course
1.Development environment setup
  • 1.Introduction to the Control Board
  • 2.Set up the STM32CUBEIDE development environment
  • 3.Burning STM32 firmware using SWD
  • 4.Burning STM32 firmware using serial port
  • 5.Compile the microros driver library
  • 6.Install and start the microros agent
  • 7.Import Project
2.Control board STM32 basic routine
  • 1.Turn on the LED light
  • 2.Button functions
  • 3.Drive the buzzer
  • 4.Serial communication
  • 5.Battery voltage detection
  • 6.Driving PWM Servo
  • 7.Drive motor
  • 8.Read motor encoder data
  • 9.PID control of motor speed
  • 10.Robot kinematics analysis theory
  • 11.Read IMU data
  • 12.Read Lidar data
  • 13.Flash access data
  • 14.Driving OLED Displays
  • 15.Driving RGB light strip
  • 16.SBUS model aircraft remote control
  • 17.USB controller remote control
  • 18.CAN bus communication
3.Control board micro_ros basic routine
  • 1.Post a topic
  • 2.Subscribe to a topic
  • 3.Multi-topic subscription and publishing
  • 4.Subscribe to the buzzer topic
  • 5.Subscribe to the bus servo topic
  • 6.Subscribe to the rate control topic
  • 7.Release Speed Topic
  • 8.Publish IMU data topic
  • 9.Publish radar data topic
14.Main Control Course
Jetson Orin Nano_NX
  • 1.Jetson Orin board introduction
  • 2.Restore the factory image system
  • 3.Backup SSD system
  • 4.SSD expansion
  • 5.Network configuration
  • 6.SSH remote login
  • 7.VNC remote control
  • 8.Remote file transfer
  • 9.Jtop tool
  • 10.Exchange space expansion
Raspberry Pi
  • 1. Introduction to Raspberry PI 5
  • 2. Raspberry PI system installation and backup
  • 3. Powering the Raspberry PI 5
  • 4. Startup of Raspberry PI 5
  • 5. Update and upgrade operating system
  • 6. Introduction to raspi-config tool
  • 7. config.txt file description
  • 8. Network Configuration
  • 9. remote access
  • 10. Transfer files remotely
  • 11. Set display resolution and rotation
  • 12. Set screen to sleep
  • 13. Play audio and video
  • 14. Using USB camera
  • 15. Using MIPI camera
  • 16. Get real-time temperature of Raspberry Pi
RDKX5
  • 1.Introduction to RDK X5 board
  • 2.Write system file
  • 3.Hardware interface description
  • 4.Install case and other accessories
  • 5.Network configuration
  • 6.Remote login
  • 7.Update system
  • 8.srpi-config user guide
  • 9.config. txt configuration file
  • 10.Self-startup setting
  • 11.RDK exclusive command usage
  • 12.Linux command usage
  • 13.GPIO readwrite operation
  • 14.Image classification algorithm
  • 15.Use USB camera
  • 16.Use MIPI camera
  • 17.Binocular camera depth algorithm
15.YOLOv11 Development (ORIN)
  • 1.YOLO environment construction
  • 2.CLI use
  • 3.Object detection
  • 4.Instance segmentation
  • 5.Pose estimation
  • 6.Image classification
  • 7.Oriented object detection
  • 8.Model conversion
  • 9.Dataset annotation
  • 10.Model Training_Conversion
  • 11.Model prediction
16.YOLOv11 Development(RDKX5)
  • 1.YOLO environment construction
  • 2.CLI use
  • 3.Object detection
  • 4.Instance segmentation
  • 5.Pose estimation
  • 6.Image classification
  • 7.Oriented object detection
  • 8.Model prediction
  • 9.Model Quantization
17.YOLOv11 Development (RPI)
  • 1.YOLO environment construction
  • 2.CLI use
  • 3.Object detection
  • 4.Instance segmentation
  • 5.Pose estimation
  • 6.Image classification
  • 7.Oriented object detection
  • 8.Model conversion
  • 9.Model prediction
18.Linux Operating System
  • 1.Introduction to Linux system
  • 2.Ubuntu file system
  • 3.Ubuntu common commands
  • 4.Ubuntu common editors
  • 5.Ubuntu software operation commands
  • 6.Virtual machine installation
  • 7.SSH remote control
  • 8.VNC remote control
  • 9.Transfer files remotely
  • 10.Driver library and communication
  • 11.Static IP and hotspot mode
  • 12.Bind device ID
  • 13.Capacity expansion and resource allocation
  • 14.Update system software sources
  • 15.Set root user password
  • 16.sudo free password
  • 17.Connect to WiFi network
  • 18.View system version
  • 19.Customized service management
  • 20.Back up system image
19.ROS2 Basic Course
  • 1.Introduction to ROS2
  • 2.ROS2 install Humble
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
20.Docker Course
  • 1、Docker overview and docker installation
  • 2、Common commands for docker image containers
  • 3、Docker images deeply understand and publish images
  • 4、Docker hardware interaction and data processing
  • 5、Enter the bot's docker container
  • 6、Robot development environment construction in Docker
21.Image Processing Basics Course
  • 1. Introduction to Open Source CV
  • 2. Image reading and display
  • 3. Image writing
  • 4. Image quality
  • 5. Pixel Operation
  • 6. Image zoom
  • 7. Image cutting
  • 8. Image translation
  • 9. Image Mirroring
  • 10. Affine Transformation
  • 11. Image Rotation
  • 12. Perspective Transformation
  • 13. Grayscale processing
  • 14. Image Binarization
  • 15. Edge Detection
  • 16. Line drawing
  • 17. Rectangle and circle drawing
  • 18. Drawing text and pictures
Download
  • Mapping_APP(iOS_Android)
  • MainBoard_AI_Pure_System
  • Robot_Image_System_File
  • Code-Firmware
  • Instruction_Manual
  • VM_File
  • Software_Tools
  • Firmware_DriverFile
  • 3D_Model_File
  • ROS2_Basic_VM
  • Other_Annex
Download ZIP

Welcome to ROSMASTER M3 repository

08.Face Special Effects

Face Special Effects

Face Special Effects1. Course Content2. Program Startup3. Core Code Analysis

1. Course Content

  • Run example programs using the dlib library to implement face detection and face special effects functionality.

2. Program Startup

For Raspberry Pi 5 users, if the ROS container is not started, you need to start the container first,

xxxxxxxxxx
bringup_m3

Open a terminal inside the container,

xxxxxxxxxx
exec_m3
  • Run face special effects node in terminal
xxxxxxxxxx
ros2 launch m3_bringup mediapipe_demo.launch.py demo:=FaceLandmarks

After the program runs, as shown in the figure below, it will first detect faces, then apply special effects to the eyebrows, eyes, and mouth areas,
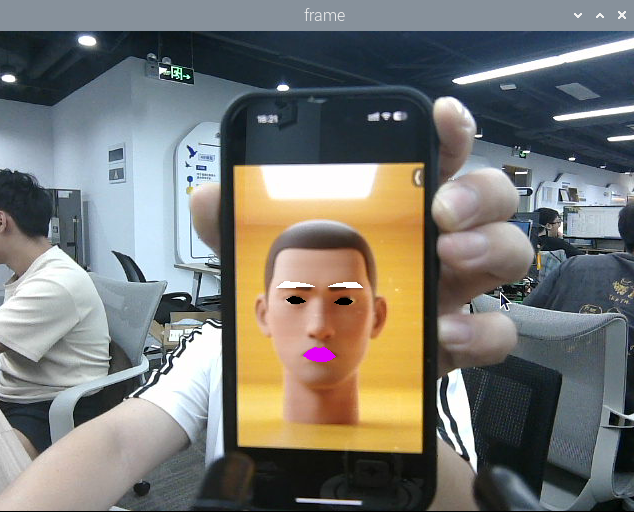
image-20250617182346133


3. Core Code Analysis

Program code path:

xxxxxxxxxx
~/yahboomM3_ws/code_ws/src/m3_common_demo/m3_common_demo/mediapipe/06_FaceLandmarks.py

Import the required library files,

xxxxxxxxxx
import time
#import dlib library
import dlib
import cv2 as cv
import numpy as np
import rclpy
from rclpy.node import Node
from cv_bridge import CvBridge
from sensor_msgs.msg import Image
from arm_msgs.msg import ArmJoints
import cv2

dlib library introduction:

DLIB is a modern C++ toolkit containing machine learning algorithms and tools for creating complex software in C++ to solve real-world problems. It is widely used in industry and academia in fields such as robotics, embedded devices, mobile phones, and large high-performance computing environments. The dlib library uses 68-point landmarks to mark important parts of the face, for example, points 18-22 mark the right eyebrow, and 51-68 mark the mouth. The dlib library's get_frontal_face_detector module is used to detect faces, and the shape_predictor_68_face_landmarks.dat feature data is used to predict face feature values.

The 68-point facial landmarks of dlib are arranged in the following order:

  • 0-16: Jaw contour
  • 17-21: Right eyebrow
  • 22-26: Left eyebrow
  • 27-35: Nose bridge and tip
  • 36-41: Right eye
  • 42-47: Left eye
  • 48-67: Lip contour

Initialize data and define publishers and subscribers,

xxxxxxxxxx
    def __init__(self, name):
        super().__init__(name)
        #Parameter declaration and acquisition
        self.declare_parameter('rgb_topic','/ascamera_hp60c/camera_publisher/rgb0/image')
        rgb_topic=self.get_parameter("rgb_topic").get_parameter_value().string_value
        self.dat_file =os.path.join(os.path.expanduser('~'), 'MODELS','mediapipe','shape_predictor_68_face_landmarks.dat')
        self.hog_face_detector = dlib.get_frontal_face_detector()
​
        self.dlib_facelandmark = dlib.shape_predictor(self.dat_file)
​
        self.rgb_bridge = CvBridge()
​
        self.sub_rgb = self.create_subscription(
            Image, rgb_topic, self.get_RGBImageCallBack, 5)

Color image topic callback function,

xxxxxxxxxx
def get_RGBImageCallBack(self,msg):
    rgb_image = self.rgb_bridge.imgmsg_to_cv2(msg, "bgr8")
    #Pass the obtained image to the defined get_face function and return the detected image
    frame = self.get_face(rgb_image, draw=False)
    #Call the prettify_face function to apply special effects to the image
    frame = self.prettify_face(frame, eye=True, lips=True, eyebrow=True, draw=True)     
    key = cv2.waitKey(1)
    cv.imshow('frame', frame)

get_face function, detect faces,

xxxxxxxxxx
def get_face(self, frame, draw=True):
    #Convert image space, convert bgr to grayscale for subsequent image processing
    gray = cv.cvtColor(frame, cv.COLOR_BGR2GRAY)
    #Pass grayscale image to detect faces
    self.faces = self.hog_face_detector(gray)
    for face in self.faces:
        self.face_landmarks = self.dlib_facelandmark(gray, face)
        if draw:
            for n in range(68):
                x = self.face_landmarks.part(n).x
                y = self.face_landmarks.part(n).y
                cv.circle(frame, (x, y), 2, (0, 255, 255), 2)
                cv.putText(frame, str(n), (x, y), cv.FONT_HERSHEY_SIMPLEX, 0.6, (0, 255, 255), 2)
    return frame

prettify_face function, add special effects to the face,

xxxxxxxxxx
def prettify_face(self, frame, eye=True, lips=True, eyebrow=True, draw=True):
    #Eyes
    if eye:
        leftEye = self.get_lmList(frame, 36, 42)
        rightEye = self.get_lmList(frame, 42, 48)
        if draw:
            if len(leftEye) != 0: frame = cv.fillConvexPoly(frame, np.mat(leftEye), (0, 0, 0))
            if len(rightEye) != 0: frame = cv.fillConvexPoly(frame, np.mat(rightEye), (0, 0, 0))
    #Lips
    if lips:
        lipIndexlistA = [51, 52, 53, 54, 64, 63, 62]
        lipIndexlistB = [48, 49, 50, 51, 62, 61, 60]
        lipsUpA = self.get_lipList(frame, lipIndexlistA, draw=True)
        lipsUpB = self.get_lipList(frame, lipIndexlistB, draw=True)
        lipIndexlistA = [57, 58, 59, 48, 67, 66]
        lipIndexlistB = [54, 55, 56, 57, 66, 65, 64]
        lipsDownA = self.get_lipList(frame, lipIndexlistA, draw=True)
        lipsDownB = self.get_lipList(frame, lipIndexlistB, draw=True)
        if draw:
            if len(lipsUpA) != 0: frame = cv.fillConvexPoly(frame, np.mat(lipsUpA), (249, 0, 226))
            if len(lipsUpB) != 0: frame = cv.fillConvexPoly(frame, np.mat(lipsUpB), (249, 0, 226))
            if len(lipsDownA) != 0: frame = cv.fillConvexPoly(frame, np.mat(lipsDownA), (249, 0, 226))
            if len(lipsDownB) != 0: frame = cv.fillConvexPoly(frame, np.mat(lipsDownB), (249, 0, 226))
    #Eyebrows
    if eyebrow:
        lefteyebrow = self.get_lmList(frame, 17, 22)
        righteyebrow = self.get_lmList(frame, 22, 27)
        if draw:
            if len(lefteyebrow) != 0: frame = cv.fillConvexPoly(frame, np.mat(lefteyebrow), (255, 255, 255))
            if len(righteyebrow) != 0: frame = cv.fillConvexPoly(frame, np.mat(righteyebrow), (255, 255, 255))
    return frame

get_lmList function to get face coordinates,

xxxxxxxxxx
def get_lmList(self, frame, p1, p2, draw=True):
    #Define an empty list
    lmList = []
    #Check if face is detected
    if len(self.faces) != 0:
        #Iterate through the face list to get the xy coordinates of points within each interval
        for n in range(p1, p2):
            x = self.face_landmarks.part(n).x
            y = self.face_landmarks.part(n).y
            #Add the point coordinates on the face to the list
            lmList.append([x, y])
            if draw:
                next_point = n + 1
                if n == p2 - 1: next_point = p1
                x2 = self.face_landmarks.part(next_point).x
                y2 = self.face_landmarks.part(next_point).y
                cv.line(frame, (x, y), (x2, y2), (0, 255, 0), 1)
    return lmList


Gesture Recognition
Brush

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文