yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
ROSMASTER M1📖
01.Robot Configuration and Operation Guide
  • 0. Assembly video
  • 1. Servo PTZ calibration
  • 2. Quick start guide handle control
  • 3. First trial
  • 4. Enter Docker (For JETSON Nano and RPi 5)
  • 1.5 Quick Start video
02.AI Model Preparation
  • AI Model Preparation
03.AI Model Basics course
  • 1.AI large model types and principles
  • 2.RAG retrieval enhancement and model training samples
  • 3.Embodied intelligent robot system architecture
  • 4.Embodied intelligent functions core source code
04.AI Model Developmentnew
  • 1.Register a model service provider account
  • 2. Configuring API-KEY
  • 3. Introduction to Dify
  • 4. Basic Dify Features
  • 5. Deploy the RAG knowledge base
  • 6. AI Large Model Development - chatbot
  • 7. RAG knowledge base + chatbot
  • 8. AI agent workflow
  • 9. Custom wake-up response
  • 10. Core module testing tools
05.AI Model - Text Version
  • 1.Semantic understand and command follow
  • 2.Multimodal visual understand
  • 3.Multimodal visual understand + PTZ tracking
  • 4.Multimodal visual understand + visual following
  • 5.Multimodal visual understand + visual line patroling
  • 6.Multimodal visual understand + Depth Camera Distance Question Answering
  • 7.Multimodal visual understand+SLAM navigation
  • 8.Multimodal visual understand+SLAM navigation + visual line patroling
  • 9.Intention estimation + Multimodal visual understand + SLAM navigation + visual functions
06.AI Model - Voice Version
  • 1.Semantic understand and command follow
  • 2.Multimodal visual understand
  • 3.Multimodal visual understand + PTZ tracking
  • 4.Multimodal visual understand + visual following
  • 5.Multimodal visual understand + visual line patroling
  • 6.Multimodal visual understand + Depth Camera Distance Question Answering
  • 7.Multimodal visual understand+SLAM navigation
  • 8.Multimodal visual understand+SLAM navigation + visual line patroling
  • 9.Intention estimation + Multimodal visual understand + SLAM navigation + visual functions
07.Chassis Control Course
  • 1. ROS control
  • 2. Handle control
  • 3. Keyboard control
  • 4. Linear velocity calibration
  • 5. Angular velocity calibration
  • 6. URDF model
08.Mediapipe Visual Course
  • 1.Hand detection
  • 2.Posture detection
  • 3.Overall detection
  • 4.Facial landmark detection
  • 5.Face detection
  • 6.Face special effects
  • 7.3D object recognition
  • 8.Brush
  • 9.Finger control
  • 10.Gesture recognition
  • 11.Palm target positioning
  • 12.Fingertip trajectory recognition
09.Advanced Vision Course
  • 1.QR code
  • 2.Human Pose Estimation
  • 3.Object Detection
  • 4.AR Vision
  • 5.ROS+Opencv Basics
  • 6.Yolov8 Object Detection (ORIN)
  • 7.Deep Learning Object Tracking (ORIN)
10.HD Camera Vision Course(Standard Version)
  • 01.Color tracking
  • 02.Face Tracking
  • 03.AprilTag machine code tracking
  • 04.KCF Object Tracking
  • 05.QR code tracking
  • 06.Mediapipe gesture tracking
  • 07.Meidpipe human posture tracking
  • 08.Color Follow
  • 09.Face Following
  • 10.AprilTag machine code following
  • 11.QR code follow
  • 12.Mediapipe gesture recognition and following
  • 13.Meidpipe human posture following
  • 14.Visual tracking autonomous driving
  • 15.QR code motion control
  • 16.Gesture motion control
11.Depth Camera Vision Course(Superior Version)
  • 1.Basic use of depth camera
  • 2.Deep pseudo-color image
  • 3.Depth camera ranging
  • 4.Color block volume measurement
  • 5.Color Following
  • 6.Face Following
  • 7.QR code follow
  • 8.Machine code following
  • 9.KCF Object Following
  • 10.Mediapipe gesture following
  • 11.Mediapipe Posture Following
  • 12.Visual tracking autonomous driving
  • 13.Edge Detection
12.LiDAR Course
  • 1.Basic use of Lidar
  • 2.Lidar obstacle avoidance
  • 3.Lidar following
  • 4.Lidar patrol
  • 5.Gmapping-SLAM mapping
  • 6.Cartographer-SLAM mapping
  • 7.slam_toolbox mapping
  • 8.Navigation2 single-point navigation avoid
  • 9.Navigation2 multi-point navigation avoid
  • 10.Cartographer Repositioning navigation
  • 11.RTAB-Map mapping
  • 12.RTAB-Map navigation
  • 13.APP mapping navigation
13.Multi-Vehicle Course
  • 1.Multi-vehicle control
  • 2.Multi-vehicle navigation
  • 3.Multi-vehicle platoon
14.Autonomous Driving expand(Need purchase track map)
【Track Map】Multimodal visual understand+SLAM navigation
  • 1. Multimodal visual understand+SLAM navigation
【Track Map】Autonomous driving (RDKX5 & Orin)
  • 1. Venue placement and precautions
  • 2. Start testing
  • 3. Identify and debug
  • 4. Lane keeping
  • 5. Road sign detection
  • 6. Traffic light recognition
  • 7. Fixed point parking
  • 8. Steering decision
  • 9. Horn sounding
  • 10. Deceleration
  • 11. Speed limit
  • 12. Autonomous parking
  • 13. Comprehensive application
  • 14. Unmanned driving integrated AI large model
【Track Map】Autonomous driving (Jetson Nano)
  • 1. Venue placement and precautions
  • 2. Start testing
  • 3. Identify and debug
  • 4. Lane keeping
  • 5. Road sign detection
  • 6. Traffic light recognition
  • 7. Fixed point parking
  • 8. Steering decision
  • 9. Horn sounding
  • 10. Deceleration
  • 11. Speed limit
  • 12. Autonomous parking
  • 13. Comprehensive application
【Track Map】Road network planning
  • 1. Introduction to Road Network Planning and Navigation
  • 2. Constructing a Pose Map
  • 3. Road Network Labelling
  • 4. Road Network Planning Combined with Sand Table Map
  • 5. Path Replanning
【Track Map】Model Training
  • 1. Data Collection
  • 2. Dataset Annotation
  • 3. YOLOv11 Model Training
  • 4. Model Format Conversion
15.YOLOV11 development course (ORIN)
  • 1.YOLO environment construction
  • 2.CLI use
  • 3.Object detection
  • 4.Instance segmentation
  • 5.Pose estimation
  • 6.Image classification
  • 7.Oriented object detection
  • 8.Model conversion
  • 9.Dataset annotation
  • 10.Model Training_Conversion
  • 11.Model prediction
16.YOLOV11 development course(RPi&Jetson NANO)
  • 1.YOLO environment construction
  • 2.CLI use
  • 3.Object detection
  • 4.Instance segmentation
  • 5.Pose estimation
  • 6.Image classification
  • 7.Oriented object detection
  • 8.Model conversion
  • 9.Model prediction
17.YOLOV11 development course(RDK X5)
  • 1.YOLO environment construction
  • 2.CLI use
  • 3.Object detection
  • 4.Instance segmentation
  • 5.Pose estimation
  • 6.Image classification
  • 7.Oriented object detection
  • 8.Model prediction
  • 9.Model Quantization
18.Main control board course
Jetson Nano B01
  • 1. Introduction to the Jetson Nano B01 SUB Board
  • 2. Burn the system image
  • 3. Re-read the memory card or USB drive that has been burned
  • 4. Startup system
  • 5. Jetson Nano B01 System and Desktop Introduction
  • 6. Memory card or USB flash drive expansion
  • 7. Network Configuration
  • 8. SSH remote login & file transfer
  • 9. VNC Remote Login
  • 10. Jetson Nano B01 system backup
  • 11. Jetson Nano Swap space increased
  • 12. Installation and use of Jtop
  • 13. Third-party board + USB drive to start the car
Jetson Orin Nano_NX
  • 1.Jetson Orin board introduction
  • 2.Restore the factory image system
  • 3.Backup SSD system
  • 4.SSD expansion
  • 5.Network configuration
  • 6.SSH remote login
  • 7.VNC remote control
  • 8.Remote file transfer
  • 9.Jtop tool
  • 10.Exchange space expansion
Raspberry Pi
  • 1. Introduction to Raspberry PI 5
  • 2. Raspberry PI system installation and backup
  • 3. Powering the Raspberry PI 5
  • 4. Startup of Raspberry PI 5
  • 5. Update and upgrade operating system
  • 6. Introduction to raspi-config tool
  • 7. config.txt file description
  • 8. Network Configuration
  • 9. remote access
  • 10. Transfer files remotely
  • 11. Set display resolution and rotation
  • 12. Set screen to sleep
  • 13. Play audio and video
  • 14. Using USB camera
  • 15. Using MIPI camera
  • 16. Get real-time temperature of Raspberry Pi
RDK X5
  • 1.Introduction to RDK X5 board
  • 2.Write system file
  • 3.Hardware interface description
  • 4.Install case and other accessories
  • 5.Network configuration
  • 6.Remote login
  • 7.Update system
  • 8.srpi-config user guide
  • 9.config. txt configuration file
  • 10.Self-startup setting
  • 11.RDK exclusive command usage
  • 12.Linux command usage
  • 13.GPIO readwrite operation
  • 14.Image classification algorithm
  • 15.Use USB camera
  • 16.Use MIPI camera
  • 17.Binocular camera depth algorithm
19.AI large model course(ORIN-Pi-RDK X5)
Offline large model (Text Interaction)
  • 0. AI Large Model Mirroring Explanation
  • 1. Deployment of large-scale AI models
  • 2.Installation of the large-scale model dialogue platform
  • 3. Meta AI Llama 3.2 model
  • 4. Alibaba Cloud Qwen3 Model
  • 5. Microsoft Phi-4 mini model
  • 6. DeepSeek DeepSeek-R1 model
  • 7. Alibaba Cloud Qwen2.5vl Visual Multimodal Large Model
  • 8. Google Gemma3 Visual Multimodal Large Model
  • 9. Llava Visual Multimodal Large Model
  • 10.MiniCPM-V Visual Multimodal Large Model
  • 11. Multimodal Visual Understanding Applications
  • 12. Multimodal Text-Based Image Application
  • 13. Multimodal Video Analysis Application
  • 14. Multimodal visual positioning applications
  • 15. Multimodal table scanning application
  • 16. Multimodal Autonomous Agent Application
Offline large model (Voice Interaction)
  • 0. Voice Interaction Hardware Connection (Must Read)
  • 1. Offline speech-to-text (ASR)
  • 2. Offline Text-to-Speech (TTS)
  • 3. AI large model voice interaction
  • 4. Multimodal visual understanding and voice interaction
  • 5. Multimodal Text-Based Image Application
  • 6. Multimodal Video Analysis Application
  • 7. Multimodal visual positioning applications
  • 8. Multimodal table scanning application
  • 9. Multimodal Autonomous Agent Applications
  • 10. AI large model offline voice assistant
Online large model (Text Interaction)
  • 1. OpenRouter Large Model API Aggregation Platform
  • 2. Multimodal visual understanding applications
  • 3. Multimodal visual positioning applications
  • 4. Multimodal table scanning application
  • 5. Multimodal Autonomous Agent Applications
Online large model (Voice Interaction)
  • 0. Voice Interaction Hardware Connection (Must Read)
  • 1. Online speech-to-text (ASR)
  • 2. Online Text-to-Speech (TTS)
  • 3. AI large model voice interaction
  • 4. Multimodal visual and voice interaction
  • 5. Multimodal visual positioning applications
  • 6. Multimodal table scanning application
  • 7. Multimodal Autonomous Agent Applications
  • 8. AI large model online voice assistant
20.AI large model course(Jetson NANO)
Offline large model (Text Interaction)
  • 4.Multimodal visual understand speech interaction
  • 0.AI large model system image instructions
  • 1.AI large model environment deployment
  • 2.Install large model dialogue platform
  • 3.Meta AI llama 3.2 model
  • 4.Alibaba Cloud Qwen2 model
  • 5.Alibaba Cloud Qwen3 model
  • 6.SUTD TinyLlama
  • 7.DeepSeek DeepSeek-R1 model
  • 8.Microsoft Phi-3
  • 9.Microsoft Orca Mini
  • 10.NVIDIA StarCoder2
  • 11.Google Gemma3 Visual Multimodal Large Model
  • 12.Offline Text to Speech (TTS)
  • 13.Offline Speech to Text (ASR)
Online large model (Text Interaction)
  • 1.OpenRouter large model API aggregation platform
  • 2.Multimodal visual understand application
  • 3.Multimodal visual localization application
  • 4.Multimodal table scanning application
  • 5.Multimodal autonomous proxy application
Online large model (Voice Interaction)
  • 0.Voice interaction hardware connection (ReadMe)
  • 1.Online speech-to-text (ASR)
  • 2.Online Text-to-Speech (TTS)
  • 3.AI large model voice interaction
  • 5.Multimodal visual position application
  • 6.Multimodal table scanning application
  • 7.Multimodal autonomous proxy application
  • 8.AI large model online voice assistant
21.Linux operating system course
  • 1.Introduction to Linux system
  • 2.Ubuntu file system
  • 3.Ubuntu common commands
  • 4.Ubuntu common editors
  • 5.Ubuntu software operation commands
  • 6.Virtual machine installation
  • 7.SSH remote control
  • 8.VNC remote control
  • 9.Transfer files remotely
  • 10.Driver library and communication
  • 11.Static IP and hotspot mode
  • 12.Bind device ID
  • 13.Capacity expansion and resource allocation
  • 14.Update system software sources
  • 15.Set root user password
  • 16.sudo free password
  • 17.Connect to WiFi network
  • 18.View system version
  • 19.Customized service management
  • 20.Back up system image
22.Docker course
  • 1.Docker Introduction and Installation
  • 2.Docker basic commands
  • 3.Docker Submission and Multi-Terminal Access
  • 4.Docker Startup Script
  • 5.Docker-Vscode environment construction
23.ROS2 basic course
  • 1.Introduction to ROS2
  • 2.ROS2 install Humble
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
24.Image processing course
  • 1. Introduction to Open Source CV
  • 2. Image reading and display
  • 3. Image writing
  • 4. Image quality
  • 5. Pixel Operation
  • 6. Image zoom
  • 7. Image cutting
  • 8. Image translation
  • 9. Image Mirroring
  • 10. Affine Transformation
  • 11. Image Rotation
  • 12. Perspective Transformation
  • 13. Grayscale processing
  • 14. Image Binarization
  • 15. Edge Detection
  • 16. Line drawing
  • 17. Rectangle and circle drawing
  • 18. Drawing text and pictures
25.STM32 driver course
  • 0. Notes (must read)
  • 1. About expansion board
  • 2. STM32 Development environment
  • 3. Button control
  • 4. FreeRTOS application
  • 5. Serial communication
  • 6. SBUS model aircraft remote control
  • 7. CAN bus communication
  • 8. RGB colorful light bar
  • 9. Timer interrupt to control PWM servo
  • 10. Control serial port servos
  • 11. Nine-axis attitude sensor to obtain data
  • 12. Control motor
  • 13. Timer captures the encoder data
  • 14. Robot kinematics analysis theory
  • 15. PID control robot movement
26.Main control communication course
  • 1. Update the expansion board firmware
  • 2. Install Rosmaster driver library
  • 3. Jupyter lab basic usage tutorial
  • 4. Buzzer whistle
  • 5. Control PWM servo
  • 6. RGB colorful light bar special effects display
  • 7. Control motor
  • 8. Control robot movement
  • 9. Control Serial Servo
Download
  • Mapping_APP(iOS_Android)
  • Robot_Image_System_File
  • Code-Firmware
  • Instruction_Manual
  • MainBoard_AI_Pure_System
  • VM_File
  • Software_Tools
  • Hardware_Info
  • 3D_Model_File
Download ZIP

Welcome to ROSMASTER M1 repository

2. Install Rosmaster driver library

Installing the Rosmaster Driver Library

Installing the Rosmaster Driver Library3.1. Pre-installation Notice3.2. Downloading the Python Driver Library File3.3. Transferring Files to Jetson Nano3.4. Start the Installation3.5. Importing the Library File3.6 Basic Driver Library Usage3.7 API Introduction

3.1. Pre-installation Notice

The factory image of the car already has the latest driver library installed, so you don't need to install it again. Installing the driver library is only necessary if you're using a different image or if the driver library has been updated.

The factory driver library is stored in: ~/yahboomcar_ros2_ws/software/py_install_V3.3.9

Please refer to the following steps to install the driver library. This example uses version V3.3.9.

3.2. Downloading the Python Driver Library File

The latest version of the Rosmaster Python driver library is provided in this course material, named py_install.zip.

The compressed package contains the following files:
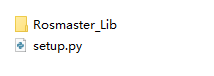
image-20220316160547427

Or, in the Rosmaster download area on the Yahboom official website, click [Code] to download the latest version, py_install_V3.3.9.zip.

3.3. Transferring Files to Jetson Nano

If you are using the Jetson Nano's built-in browser to download files from the Yabo Intelligent official website, please download the files to a user-accessible location, such as the desktop.

If you are using the driver library compressed package file included in the documentation, or downloading the driver library file using a computer browser, you can use WinSCP to drag the compressed driver library file to the Jetson Nano desktop.

After successful installation, the driver library file can be deleted.
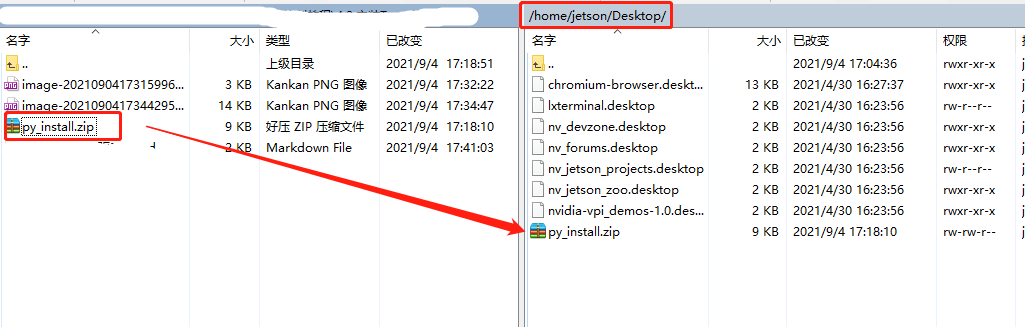
image-20210904174213656

3.4. Start the Installation

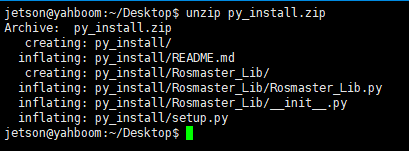
Open the Jetson Nano terminal and enter the following command to decompress the file.

Go to the desktop and check if the file exists. The target file is in the red box.

xxxxxxxxxx
cd ~/Desktop && ls

Decompress the file

xxxxxxxxxx
unzip py_install.zip

image-20220325101116150

Note: The examples throughout this document assume that the py_install.zip compressed file is placed on the Jetson Nano system desktop. If you store the compressed file in a different directory, please navigate to the corresponding directory based on your actual location.

Enter the driver library folder.

xxxxxxxxxx
cd py_install

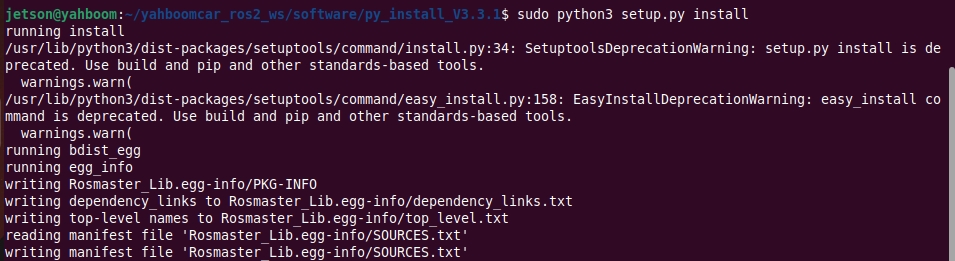
Run the installation command. If you see the installed version number at the end, the installation is successful. This command will overwrite the previously installed Rosmaster_Lib driver library.

xxxxxxxxxx
sudo python3 setup.py install

image-20220325101329200

3.5. Importing the Library File

The Rosmaster driver library is named Rosmaster_Lib. Use Rosmaster_Lib in your program to import the library.

xxxxxxxxxx
from Rosmaster_Lib import Rosmaster

3.6 Basic Driver Library Usage

Source code path: Rosmaster/Samples/3.test_rosmaster.ipynb

3.7 API Introduction

The following is an introduction to the driver library API. Function usage and parameter contents will be explained in the control course later.

xxxxxxxxxx
 |  __del__(self)
 |  
 |  __init__(self, car_type=1, com='/dev/myserial', delay=0.002, debug=False)
 |      Initialize self.  See help(type(self)) for accurate signature.
 |  
 |  clear_auto_report_data(self)
 |      # 清除单片机自动发送过来的缓存数据
 |      # Clear the cache data automatically sent by the MCU
 |  
 |  create_receive_threading(self)
 |      # 开启接收和处理数据的线程
 |      # Start the thread that receives and processes data
 |  
 |  get_accelerometer_data(self)
 |      # 获取加速度计三轴数据,返回a_x, a_y, a_z
 |      # Get accelerometer triaxial data, return a_x, a_y, a_z
 |  
 |  get_battery_voltage(self)
 |      # 获取电池电压值
 |      # Get the battery voltage
 |  
 |  get_gyroscope_data(self)
 |      # 获取陀螺仪三轴数据,返回g_x, g_y, g_z
 |      # Get the gyro triaxial data, return g_x, g_y, g_z
 |  
 |  get_magnetometer_data(self)
 |      # 获取磁力计三轴数据,返回m_x, m_y, m_z
 |  
 |  get_motion_data(self)
 |      # 获取小车速度,val_vx, val_vy, val_vz
 |      # Get the car speed, val_vx, val_vy, val_vz
 |  
 |  get_motion_pid(self)
 |      # 获取小车的运动PID参数, 返回[kp, ki, kd]
 |      # Get the motion PID parameters of the dolly and return [kp, ki, kd]
 |  
 |  get_motor_encoder(self)
 |      # 获取四路电机编码器数据
 |      # Obtain data of four-channel motor encoder
 |  
 |  get_uart_servo_angle(self, s_id)
 |      # 读取总线舵机的角度,s_id表示要读取的舵机的ID号,s_id=[1-6]
 |      # Read the Angle of the bus steering gear, s_id indicates the ID number of the steering gear to be 
read, s_id=[1-6]
 |  
 |  get_uart_servo_angle_array(self)
 |      # 一次性读取六个舵机的角度[xx, xx, xx, xx, xx, xx],如果某个舵机错误则那一位为-1
 |      # Read the angles of three steering gear [xx, xx, xx, xx, xx, xx] at one time. If one steering gear
 is wrong, that one is -1
 |  
 |  get_uart_servo_value(self, servo_id)
 |      # 读取总线舵机位置参数, servo_id=[1-250], 返回:读到的ID,当前位置参数
 |      # Read bus servo position parameters, servo_id=[1-250], return: read ID, current position parameter
s
 |  
 |  get_version(self)
 |      # 获取底层单片机版本号,如1.1
 |      # Get the underlying microcontroller version number, such as 1.1
 |  
 |  reset_flash_value(self)
 |      # 重置小车flash保存的数据,恢复出厂默认值。
 |      # Reset the car flash saved data, restore the factory default value
 |  
 |  set_auto_report_state(self, enable, forever=False)
 |      # 单片机自动返回数据状态位,默认为开启,如果设置关闭会影响部分读取数据功能。
 |      # enable=True,底层扩展板会每隔10毫秒发送一包数据,总共四包不同数据,所以每包数据每40毫秒刷新一次。e
nable=False,则不发送。
 |      # forever=True永久保存,=False临时作用。
 |      # The MCU automatically returns the data status bit, which is enabled by default. If the switch is 
closed, the data reading function will be affected.  
 |      # enable=True, The underlying expansion board sends four different packets of data every 10 millise
conds, so each packet is refreshed every 40 milliseconds. 
 |      # If enable=False, the report is not sent.  
 |      # forever=True for permanent, =False for temporary
 |  
 |  set_beep(self, on_time)
 |      # 蜂鸣器开关,on_time=0:关闭,on_time=1:一直响,
 |      # on_time>=10:响xx毫秒后自动关闭(on_time是10的倍数)。
 |      # Buzzer switch. On_time =0: the buzzer is off. On_time =1: the buzzer keeps ringing
 |      # On_time >=10: automatically closes after xx milliseconds (on_time is a multiple of 10)
 |  
 |  set_car_motion(self, v_x, v_y, v_z)
 |      # 小车运动控制,v_x=[-1.0, 1.0], v_y=[-1.0, 1.0], v_z=[-5.0, 5.0]
 |      # Car movement control, v_x = [-1.0, 1.0], v_y = [-1.0, 1.0], v_z = [-5.0, 5.0]
 |  
 |  set_car_run(self, state, speed, adjust=False)
 |      # 控制小车向前、向后、向左、向右等运动。
 |      # state=[0~6],=0停止,=1前进,=2后退,=3向左,=4向右,=5左旋,=6右旋
 |      # speed=[-100, 100],=0停止。
 |      # adjust=True开启陀螺仪辅助运动方向。=False则不开启。
 |      # Control the car forward, backward, left, right and other movements.
 |      # State =[0~6],=0 stop,=1 forward,=2 backward,=3 left,=4 right,=5 spin left,=6 spin right
 |      # Speed =[-100, 100], =0 Stop.
 |      # Adjust =True Activate the gyroscope auxiliary motion direction.  If =False, the function is disab
led.
 |  
 |  set_car_type(self, car_type)
 |      # 设置小车类型
 |      # Set car Type
 |  
 |  set_colorful_effect(self, effect, speed=255, parm=255)
 |      # RGB可编程灯带特效展示。
 |      # effect=[0, 6],0:停止灯效,1:流水灯,2:跑马灯,3:呼吸灯,4:渐变灯,5:星光点点,6:电量显示
 |      # speed=[1, 10],数值越小速度变化越快。
 |      # parm,可不填,作为附加参数。用法1:呼吸灯效果传入[0, 6]可修改呼吸灯颜色。
 |      # RGB programmable light band special effects display.
 |      # Effect =[0, 6], 0: stop light effect, 1: running light, 2: running horse light, 3: breathing ligh
t, 4: gradient light, 5: starlight, 6: power display 
 |      # Speed =[1, 10], the smaller the value, the faster the speed changes
 |      # Parm, left blank, as an additional argument.  Usage 1: The color of breathing lamp can be modifie
d by the effect of breathing lamp [0, 6]
 |  
 |  set_colorful_lamps(self, led_id, red, green, blue)
 |      # RGB可编程灯带控制,可单独控制或全体控制,控制前需要先停止RGB灯特效。
 |      # led_id=[0, 13],控制对应编号的RGB灯;led_id=0xFF, 控制所有灯。
 |      # red,green,blue=[0, 255],表示颜色RGB值。
 |      # RGB programmable light belt control, can be controlled individually or collectively, before contr
ol need to stop THE RGB light effect.
 |      # Led_id =[0, 13], control the CORRESPONDING numbered RGB lights;  Led_id =0xFF, controls all light
s.
 |      # Red,green,blue=[0, 255], indicating the RGB value of the color.
 |  
 |  set_motor(self, speed_1, speed_2, speed_3, speed_4)
 |      # 控制电机PWM脉冲,从而控制速度(未使用编码器测速)。speed_X=[-100, 100]
 |      # Control PWM pulse of motor to control speed (speed measurement without encoder). speed_X=[-100, 1
00]
 |  
 |  set_pid_param(self, kp, ki, kd, forever=False)
 |      # PID 参数控制,会影响set_car_motion函数控制小车的运动速度变化情况。默认情况下可不调整。
 |      # kp ki kd = [0, 10.00], 可输入小数。
 |      # forever=True永久保存,=False临时作用。
 |      # 由于永久保存需要写入芯片flash中,操作时间较长,所以加入delay延迟时间,避免导致单片机丢包的问题。
 |      # 临时作用反应快,单次有效,重启单片后数据不再保持。
 |      # PID parameter control will affect the set_CAR_motion function to control the speed change of the 
car.  This parameter is optional by default.  
 |      # KP ki kd = [0, 10.00]  
 |      # forever=True for permanent, =False for temporary.  
 |      # Since permanent storage needs to be written into the chip flash, which takes a long time to opera
te, delay is added to avoid packet loss caused by MCU.  
 |      # Temporary effect fast response, single effective, data will not be maintained after restarting th
e single chip
 |  
 |  set_pwm_servo(self, servo_id, angle)
 |      # 舵机控制,servo_id:对应ID编号,angle:对应舵机角度值
 |      # servo_id=[1, 4], angle=[0, 180]
 |      # Servo control, servo_id: corresponding, Angle: corresponding servo Angle value
 |  
 |  set_pwm_servo_all(self, angle_s1, angle_s2, angle_s3, angle_s4)
 |      # 同时控制四路PWM的角度,angle_sX=[0, 180]
 |      # At the same time control four PWM Angle, angle_sX=[0, 180]
 |  
 |  set_uart_servo(self, servo_id, pulse_value, run_time=500)
 |      # 控制总线舵机。servo_id:[1-255],表示要控制的舵机的ID号, id=254时, 控制所有已连接舵机。
 |      # pulse_value=[96,4000]表示舵机要运行到的位置。
 |      # run_time表示运行的时间(ms),时间越短,舵机转动越快。最小为0,最大为2000
 |      # Control bus steering gear.  Servo_id :[1-255], indicating the ID of the steering gear to be contr
olled. If ID =254, control all connected steering gear.  
 |      # pulse_value=[96,4000] indicates the position to which the steering gear will run.  
 |      # run_time indicates the running time (ms). The shorter the time, the faster the steering gear rota
tes.  The minimum value is 0 and the maximum value is 2000
 |  
 |  set_uart_servo_angle(self, s_id, s_angle, run_time=500)
 |      # 设置总线舵机角度接口:id:7-9, angle: 7:[0, 225], 8:[30, 270], 9:[30, 180], 设置舵机要运动到的角度
。
 |      # 设直立向上夹紧状态,三个舵机都为180度,7/8号顺时针(向下)转为减,逆时针(向上)转为增,夹子松开
为减,夹紧为增。
 |      # run_time表示运行的时间(ms),时间越短,舵机转动越快。最小为0,最大为2000
 |      # Set bus steering gear Angle interface: ID :7-9, Angle :7 :[0, 225], 8:[30, 270], 9:[30, 180], set
 steering gear to move to the Angle.  
 |      # Set up the vertical clamping state, the three steering gear are 180 degrees, 7/8 clockwise (down)
 to decrease, counterclockwise (up) to increase, clip release to decrease, clamping to increase.  
 |      # run_time indicates the running time (ms). The shorter the time, the faster the steering gear rota
tes.  The minimum value is 0 and the maximum value is 2000
 |  
 |  set_uart_servo_angle_array(self, angle_s=[90, 90, 90, 90, 90, 180], run_time=500)
 |      # 同时控制机械臂所有舵机的角度。
 |      # Meanwhile, the Angle of all steering gear of the manipulator is controlled
 |  
 |  set_uart_servo_id(self, servo_id)
 |      # 设置总线舵机的ID号,servo_id=[1-250]。
 |      # 运行此函数前请确认只连接一个总线舵机,否则会把所有已连接的总线舵机都设置成同一个ID,造成控制混乱
。
 |      # Set the bus servo ID, servo_id=[1-250].  
 |      # Before running this function, please confirm that only one bus actuator is connected. Otherwise, 
all connected bus actuators will be set to the same ID, resulting in confusion of control
 |  
 |  set_uart_servo_offset(self, servo_id)
 |      # 设置机械臂的中位偏差,servo_id=0~6, =0全部恢复出厂默认值
 |      # Run the following command to set the mid-bit deviation of the manipulator: servo_id=0 to 6, =0 Re
store the factory default values
 |  
 |  set_uart_servo_torque(self, enable)
 |      # 关闭/打开总线舵机扭矩力, enable=[0, 1]。
 |      # enable=0:关闭舵机扭矩力,可以用手转动舵机,但命令无法控制转动;
 |      # enable=1:打开扭矩力,命令可以控制转动,不可以用手转动舵机。
 |      # Turn off/on the bus steering gear torque force, enable=[0, 1].  
 |      # enable=0: Turn off the torque force of the steering gear, the steering gear can be turned by hand
, but the command cannot control the rotation;  
 |      # enable=1: Turn on torque force, command can control rotation, can not turn steering gear by hand
​
​


Update the expansion board firmware
Jupyter lab basic usage tutorial

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文