yahboom
HomeLearn
Solution
Blog
Online Store
About Us
EN/中文
ROSMASTER M3 PRO📖
0.Configuration and Operation Guide
  • 1. Quick start handle to control the car
  • 2. Log in to the car and view the code
  • 3. Robotic Arm Calibration
  • 4. Enter the Docker (Jetson-Nano and Raspberry Pi 5 users, see here)
  • 5. Assembly video
  • 6. Modify the firmware parameters of the car control board
  • 7. Frequently Asked Questions and Precautions
  • 8. Precautions for DIY Robotic Arm
1.Chassis Control Course
  • 1.ROS control
  • 2.Handle control
  • 3.Keyboard control
  • 4.Angular velocity calibration
  • 5.Line velocity calibration
  • 6.Line patrol automatic driving
  • 7.Patrol
2.Lidar Course
  • 1.Lidar introduction and use
  • 2.Dual Lidar fusion
  • 3.Lidar obstacle avoidance
  • 4.Lidar tracking
  • 5.Lidar guard
  • 6.Gmapping-SLAM mapping
  • 7.Cartographer-SLAM mapping
  • 8.slam_toolbox mapping
  • 9.Navigation2 single-point navigation avoid
  • 10.Navigation2 multi-point navigation avoid
  • 11.Repositioning navigation
  • 12.RTAB-Map mapping
  • 13.RTAB-Map navigation
  • 14.APP mapping navigation
  • 15.Machine code handling
  • 16.Color block transport
  • 17.Navigation via Pose-Constrained Visual Relocalizationnew
3.Depth Camera Course
  • 1.Dabai_DCW2 camera introduction
  • 2.Depth pseudo-color image
  • 3.Depth camera distance measurement
  • 4.Wood block volume measurement
  • 5.Mediapipe gesture recognition
  • 6.Edge detection
  • 7.YOLOv8 object detection
  • 8.Deep learning object tracking
  • 9. Transformer Model Tracking Algorithmnew
4.Robotic Arm and 3D Space Gripping Course
  • 1.Robotic arm solution
  • 2.Robotic arm chassis linkage control
  • 3.Machine code ID sorting
  • 4.Sorting height abnormality machine code
  • 5.Tracking and gripping machine code
  • 6.Color block color sorting
  • 7.Sorting height abnormality color block
  • 8.Tracking and gripping color block
  • 9.Wood block shape sorting
  • 10.KCF tracking and gripping objects
  • 11.Medipipe gesture ID sorting machine code
  • 12.Mediapipe gesture height sorting machine code
  • 13.Desktop tracking and gripping machine code
  • 14.3D tracking machine code
  • 15.Line patrol and obstacle removal
5.Road network planning and navigationnew
  • 1. Introduction To Road Network Planning
  • 2. Build A Pose Map
  • 3. Road Network Annotation
  • 4. Planning And Navigation Between Waypoints
  • 5. Road Network Navigation In Any Pose
  • 6. Path Re-planning
6.OpenClaw Basic Coursenew
  • 1. Introduction to OpenClaw
  • 2. OpenClaw Core Concepts
  • 3. OpenClaw API-KEY Configuration
  • 4. OpenClaw Switch Models
  • 5. OpenClaw System Prompt Words
  • 6. OpenClaw Common CLI Commands
7.OpenClaw Interaction Methodnew
  • 1. OpenClaw Webchat Interaction
  • 2. OpenClaw Tui Interaction
  • 3. OpenClaw Voice Dialogue Interaction
  • 4. OpenClaw WhatsApp Interaction
8.OpenClaw Developmentnew
  • 1. OpenClaw connects to the MCP interface of the robot
  • 2. Robot CLI Command Tool
  • 3. Robot control plugin tool
  • 4. Reply bridge plugin tool
  • 5. OpenClaw multimodal vision
  • 6. OpenClaw chassis control
  • 7. OpenClaw robotic arm control
  • 8. OpenClaw skills development
  • 9. OpenClaw timed tasks
  • 10. OpenClaw multi-agent intelligent agent
  • 11. OpenClaw active interaction
  • 12. OpenClaw vector memory
9.OpenClaw Embodied intelligent applicationnew
  • 1. OpenClaw target tracking
  • 2. OpenClaw robotic arm tracking and grasping
  • 3. OpenClaw robotic arm fixed-point placement
  • 4. OpenClaw garbage sorting
  • 5. OpenClaw slam mapping and navigation
  • 6. OpenClaw navigation transfer
  • 7. OpenClaw machine code clip
  • 8. OpenClaw color line patrol
  • 9. OpenClaw visual distance measurement
10.OpenClaw scenario sandboxnew
  • 1. Map description and prop placement
  • 2. Build sand table map
  • 3. Visual relocation markers
  • 4. Map mapping markers
  • 5. OpenClaw scenario sandbox comprehensive case
11.AI Model Basics
  • 1.AI large model types and principles
  • 2.RAG retrieval enhancement and model training samples
  • 3.Embodied intelligent robot system architecture
  • 4.Embodied intelligent functions core source code
12.AI Model Development
  • 01.Register a model service provider account
  • 02. Configuring API-KEY
  • 03. Introduction to Dify
  • 04. Basic Dify Features
  • 05. AI Large Model Development - chatbot
  • 06. Deploy the RAG knowledge base
  • 07. RAG knowledge base + chatbot
  • 08. AI agent workflow
  • 09. Custom wake-up response
  • 10. Core module testing tools
13.AI Large Model (Text Version)
  • 1.Semantic understand instruction following
  • 2.Multimodal visual understand
  • 3.Multimodal visual understand+robotic arm grab
  • 4.Multimodal visual understand+SLAM navigation
  • 5.Robotic arm grab+Multimodal visual understand+SLAM navigation
  • 6.Intention estimation
14.AI Large Model(Voice Version)
  • 1.Semantic understand instruction following
  • 2.Multimodal visual understand
  • 3.Multimodal visual understand+robotic arm grab
  • 4.Multimodal visual understand+SLAM navigation
  • 5.Robotic arm grab+Multimodal visual understand+SLAM navigation
  • 6.Intention estimation
15.Mediapipe Visual Course
  • 1.Hand detection
  • 2.Posture detection
  • 3.Overall detection
  • 4.Facial Landmark Detection
  • 5.Face detection
  • 6.Face special effects
  • 7.3D object recognition
  • 8.Brush
  • 9.Finger control
  • 10.Palm target positioning
  • 11.Fingertip trajectory recognition
  • 12.Fingertip gesture control robotic arm
  • 13.Gesture grabbing and releasing objects
  • 14.Finger control robotic arm
  • 15.Medipipe gesture control robotic arm action group
16.MoveIt2 Simulation Course
  • 1.MovelT2 configuration
  • 2.MovelT2 simulation-reality linkage
  • 3.Random movement
  • 4.Forward kinematics design
  • 5.Inverse kinematics design
  • 6.Cartesian path
  • 7.Trajectory planning
  • 8.Collision detection
  • 9.Scene design
17.Multi-vehicle Course
  • 1.Multi-vehicle chassis control
  • 2.Multi-vehicle robotic arm control
  • 3.Multi-vehicle navigation
  • 4.Multi-vehicle formation
18.Control Board Course
  • 1.Development environment setup
  • 2.Control board STM32 basic routine
  • 3.Control board micro_ros basic routine
19.Docker Course
  • 1、Docker overview and docker installation
  • 2、Common commands for docker image containers
  • 3、Docker images deeply understand and publish images
  • 4、Docker hardware interaction and data processing
  • 5、Enter the bot's docker container
  • 6、Robot development environment construction in Docker
20.Image Processing Basics Course
  • 1. Introduction to Open Source CV
  • 2. Image reading and display
  • 3. Image writing
  • 4. Image quality
  • 5. Pixel Operation
  • 6. Image zoom
  • 7. Image cutting
  • 8. Image translation
  • 9. Image Mirroring
  • 10. Affine Transformation
  • 11. Image Rotation
  • 12. Perspective Transformation
  • 13. Grayscale processing
  • 14. Image Binarization
  • 15. Edge Detection
  • 16. Line drawing
  • 17. Rectangle and circle drawing
  • 18. Drawing text and pictures
21.Main Control Course
Jetson Nano B01
  • 1. Introduction to the Jetson Nano B01 SUB Board
  • 2. Burn the system image
  • 3. Re-read the memory card or USB drive that has been burned
  • 4. Startup system
  • 5. Jetson Nano B01 System and Desktop Introduction
  • 6. Memory card or USB flash drive expansion
  • 7. Network Configuration
  • 8. SSH remote login & file transfer
  • 9. VNC Remote Login
  • 10. Jetson Nano B01 system backup
  • 11. Jetson Nano Swap space increased
  • 12. Installation and use of Jtop
Jetson Orin Nano_NX
  • 1.Jetson Orin board introduction
  • 2.Restore the factory image system
  • 3.Backup SSD system
  • 4.SSD expansion
  • 5.Network configuration
  • 6.SSH remote login
  • 7.VNC remote control
  • 8.Remote file transfer
  • 9.Jtop tool
  • 10.Exchange space expansion
Raspberry Pi
  • 1. Introduction to Raspberry PI 5
  • 2. Raspberry PI system installation and backup
  • 3. Powering the Raspberry PI 5
  • 4. Startup of Raspberry PI 5
  • 5. Update and upgrade operating system
  • 6. Introduction to raspi-config tool
  • 7. config.txt file description
  • 8. Network Configuration
  • 9. remote access
  • 10. Transfer files remotely
  • 11. Set display resolution and rotation
  • 12. Set screen to sleep
  • 13. Play audio and video
  • 14. Using USB camera
  • 15. Using MIPI camera
  • 16. Get real-time temperature of Raspberry Pi
22.Linux System Course
  • 1.Introduction to Linux system
  • 2.Ubuntu file system
  • 3.Ubuntu common commands
  • 4.Ubuntu common editors
  • 5.Ubuntu software operation commands
  • 6.Virtual machine installation
  • 7.SSH remote control
  • 8.VNC remote control
  • 9.Transfer files remotely
  • 10.Driver library and communication
  • 11.Static IP and hotspot mode
  • 12.Bind device ID
  • 13.Capacity expansion and resource allocation
  • 14.Update system software sources
  • 15.Set root user password
  • 16.sudo free password
  • 17.Connect to WiFi network
  • 18.View system version
  • 19.Customized service management
  • 20.Back up system image
23.ROS2 Basic Course
  • 1.Introduction to ROS2
  • 2.ROS2 install Humble
  • 3.ROS2 development environment
  • 4.ROS2 workspace
  • 5.ROS2 function package
  • 6.ROS2 node
  • 7.ROS2 topic communication
  • 8.ROS2 service communication
  • 9.ROS2 action communication
  • 10.ROS2 custom interface message
  • 11.ROS2 parameter service case
  • 12.ROS2 meta-function package
  • 13.ROS2 distributed communication
  • 14.ROS2 DDS
  • 15.ROS2 time related API
  • 16.ROS2 common command tools
  • 17.ROS2 rviz2 use
  • 18.ROS2 rqt toolbox
  • 19.ROS2 Launch startup file configuration
  • 20.ROS2 recording and playback tool
  • 21.ROS2 URDF model
  • 22.ROS2 Gazebo simulation platform
  • 23.ROS2 TF2 coordinate transformation
Download
  • Mapping_APP(iOS_Android)
  • Robot_Image_System_File
  • Code-Firmware
  • Instruction_Manual
  • VM_File
  • Software_Tools
  • Firmware_DriverFile
  • 3D_Model_File
  • ROS2_Basic_VM
  • Other_Annex
Download ZIP

Welcome to ROSMASTER M3 PRO repository

2. Log in to the car and view the code

Connect the car and view the code

This section introduces several ways to connect the car to your computer and how to view the code.

The recommended operation process in this section is: connect to the car's hotspot/insert the network cable to obtain the IP → check the OLED screen's IP → log in via VNC → turn off the self-heating point and connect to your own wifi (to facilitate the subsequent operation of large model functions) → check the updated IP of the OLED → reconnect to VNC → view the source code.

The default hotspot name of the factory image is: ROSMASTER, the password is: 12345678, and the default IP is: 192.168.8.88 .

1. Connect the car

Regardless of the method used to connect to the car, the computer and the car need to be in the same local area network. The simplest condition to meet the same LAN is to connect to the same WiFi or hotspot. First, connect to the car's default hotspot ROSMASTER, the WiFi password is 12345678. After the connection is successful, you can use the following method to log in.

You can also directly connect the motherboard to the network cable. After connecting the network cable, the OLED screen will automatically update the IP address. The following text will demonstrate various operations using the IP address after connecting the network cable.

1.1、SSH connection (optional, only for customers who need to use it)

We can use putty or MobaXterm or other SSH login tools to connect to the car. Here we take putty as an example. The download address of putty is as follows: Download PuTTY: latest release (0.83)

Select the installation according to your computer version. After successful installation, double-click to open. The putty interface is as shown below.
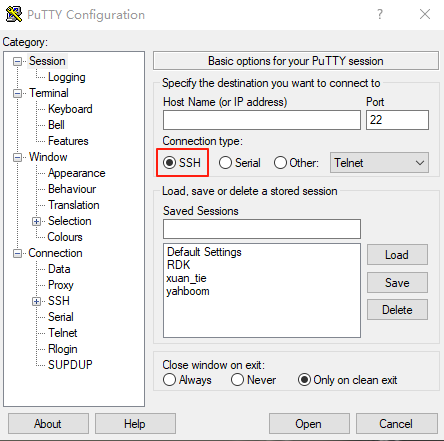
image-20250725102432201

Select SSH here , then enter the IP address displayed by OLED in the Host Name (or IP address) column. My IP address here is 192.168.2.92, so enter the IP address as shown in the figure below.
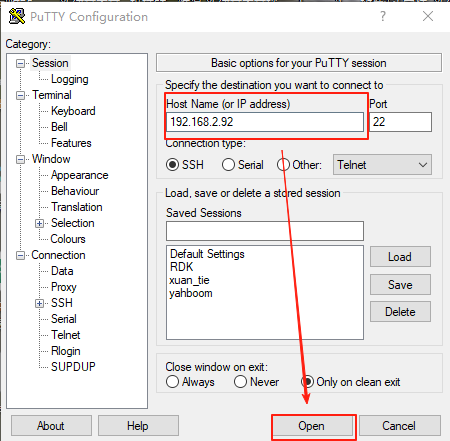
image-20250725102719479

Then click Open, you will enter a terminal interface and a pop-up window, we click Accept to select receive, as shown below,
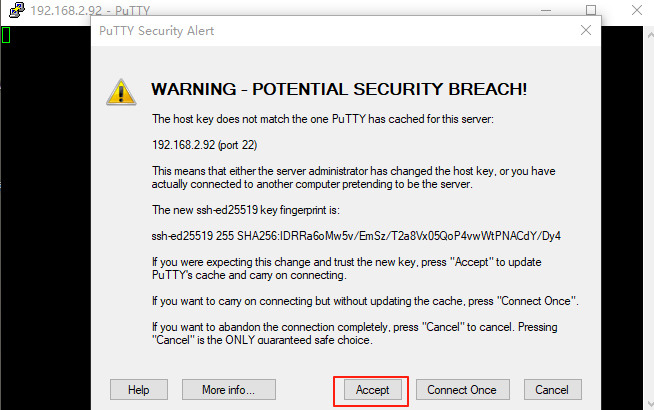
image-20250725102823043

Then the terminal will display login as , here enter the user name of the car motherboard, and then press Enter, then it will prompt you to enter the password, then we enter the password, the user name and password of each motherboard are as follows:

motherboardusernamepassword
Raspberry Pi 5piyahboom
Jetson-NanoJetsonyahboom
Orin-NanoJetsonyahboom
Orin-NXJetsonyahboom

Assuming that my motherboard here is Orin-Nano, then enter jetson, then press Enter, and then enter the password. Nothing is displayed when entering the password . Enter yahboom and press Enter.
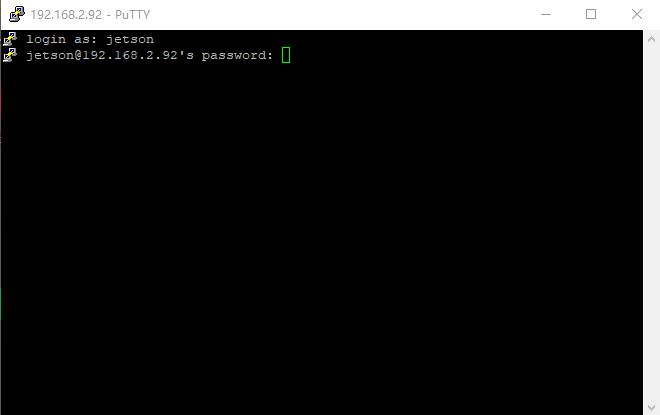
image-20250725103109017

The interface of successfully connecting to the car is as follows:
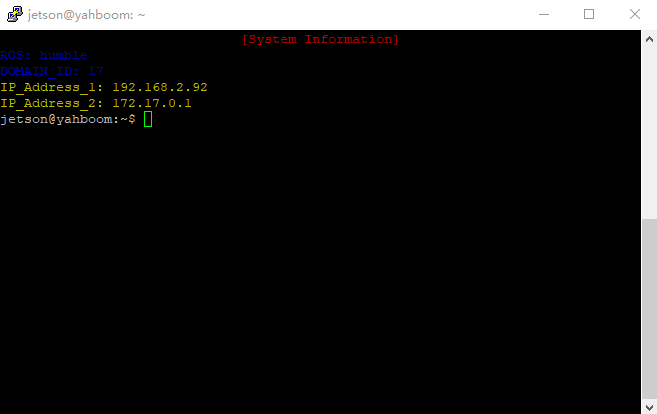
image-20250725103601663

Only one terminal will be opened here, and the graphical interface cannot be displayed. Therefore, ssh is suitable for logging in without starting the graphical program.

1.2 VNC login

1.2.1 Orin motherboard without screen (Users of Orin motherboard without screen need to configure this section for visualization. Other users do not need to configure this section and can directly proceed to 1.2.2)

Since the Orin motherboard system is Ubuntu 22.04, this system needs to be connected to a monitor to enter visualization. Users who have not purchased a monitor package may not be able to open visualization. Here is a method to display visualization on a virtual desktop. It is only for users who have not connected a monitor to the Orin motherboard. Orin motherboard users who have purchased a monitor and Jetson Nano and Raspberry Pi users can skip this step.

Open Document 19. Attachment - Virtual Desktop Files and copy xorg.conf.backup_dp and xorg.conf.backup_vnc to the /etc/X11 directory.

Install the virtual desktop environment xserver-xorg-video-dummy:

xxxxxxxxxx
sudo apt-get install xserver-xorg-video-dummy

Open the terminal and enter the following command to open the virtual desktop and switch to VNC mode.

xxxxxxxxxx
sudo cp /etc/X11/xorg.conf.backup_vnc /etc/X11/xorg.conf

Restart the system and you can enter the desktop without a screen (continue with tutorial 1.2.2 to connect to VNC).

xxxxxxxxxx
sudo reboot

Note: After switching to VNC mode, the DP connection cable will become invalid (even if the monitor is connected to the motherboard, no display will be displayed). You need to modify the configuration back before you can use the DP interface to connect to the display normally.

To shut down a virtual desktop:

If you need to connect a DP display, open the terminal and enter the following command to switch to the DP interface connection display mode.

xxxxxxxxxx
sudo cp /etc/X11/xorg.conf.backup_dp /etc/X11/xorg.conf

Restart the system and you can use the DP cable to connect the display.

xxxxxxxxxx
sudo reboot

1.2.2

VNC allows users to remotely access and control the desktop environment of another computer through the network. So when we need to access the desktop environment of the car, for example, when we want to start the image display, we can use VNC to connect and log in to the car. The download address of VNC is as follows: Download VNC Viewer by RealVNC®

Download and install according to your computer version. After successful installation, double-click to open it. The displayed screen is as follows:
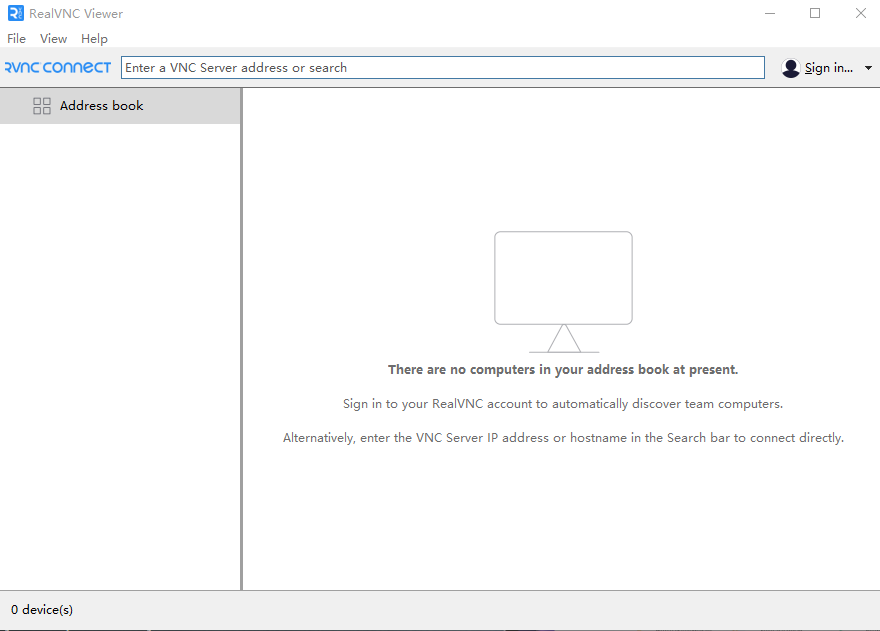
image-20250725105127650

Enter the IP address of the car. Here my IP address is 192.168.2.92, as shown below.
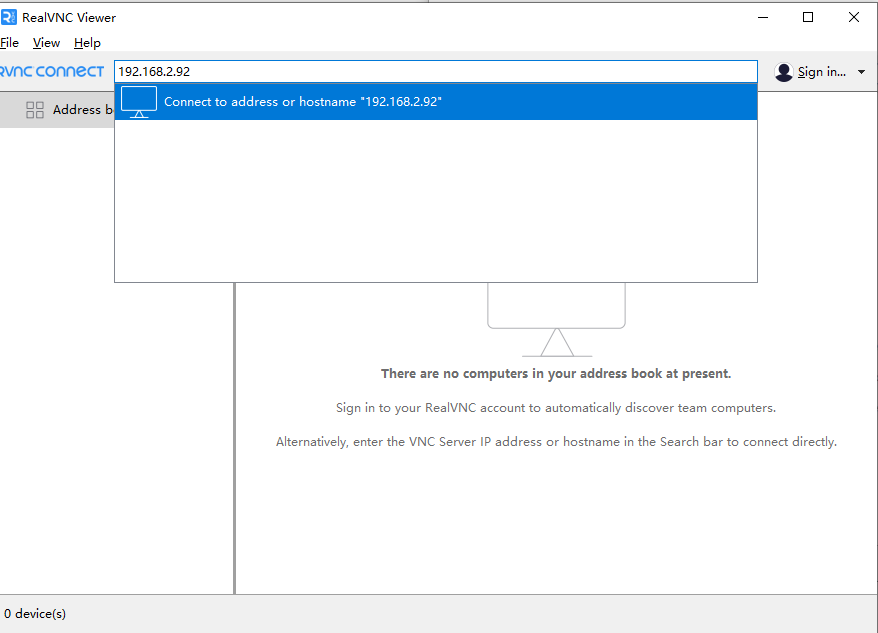
image-20250725105232162

Then press Enter,

image-20250725105315827

Enter the user name in Username and the password in Password. Refer to the table in 1.1. The password for all motherboards is yahboom. Then click OK to enter the desktop, as shown below.
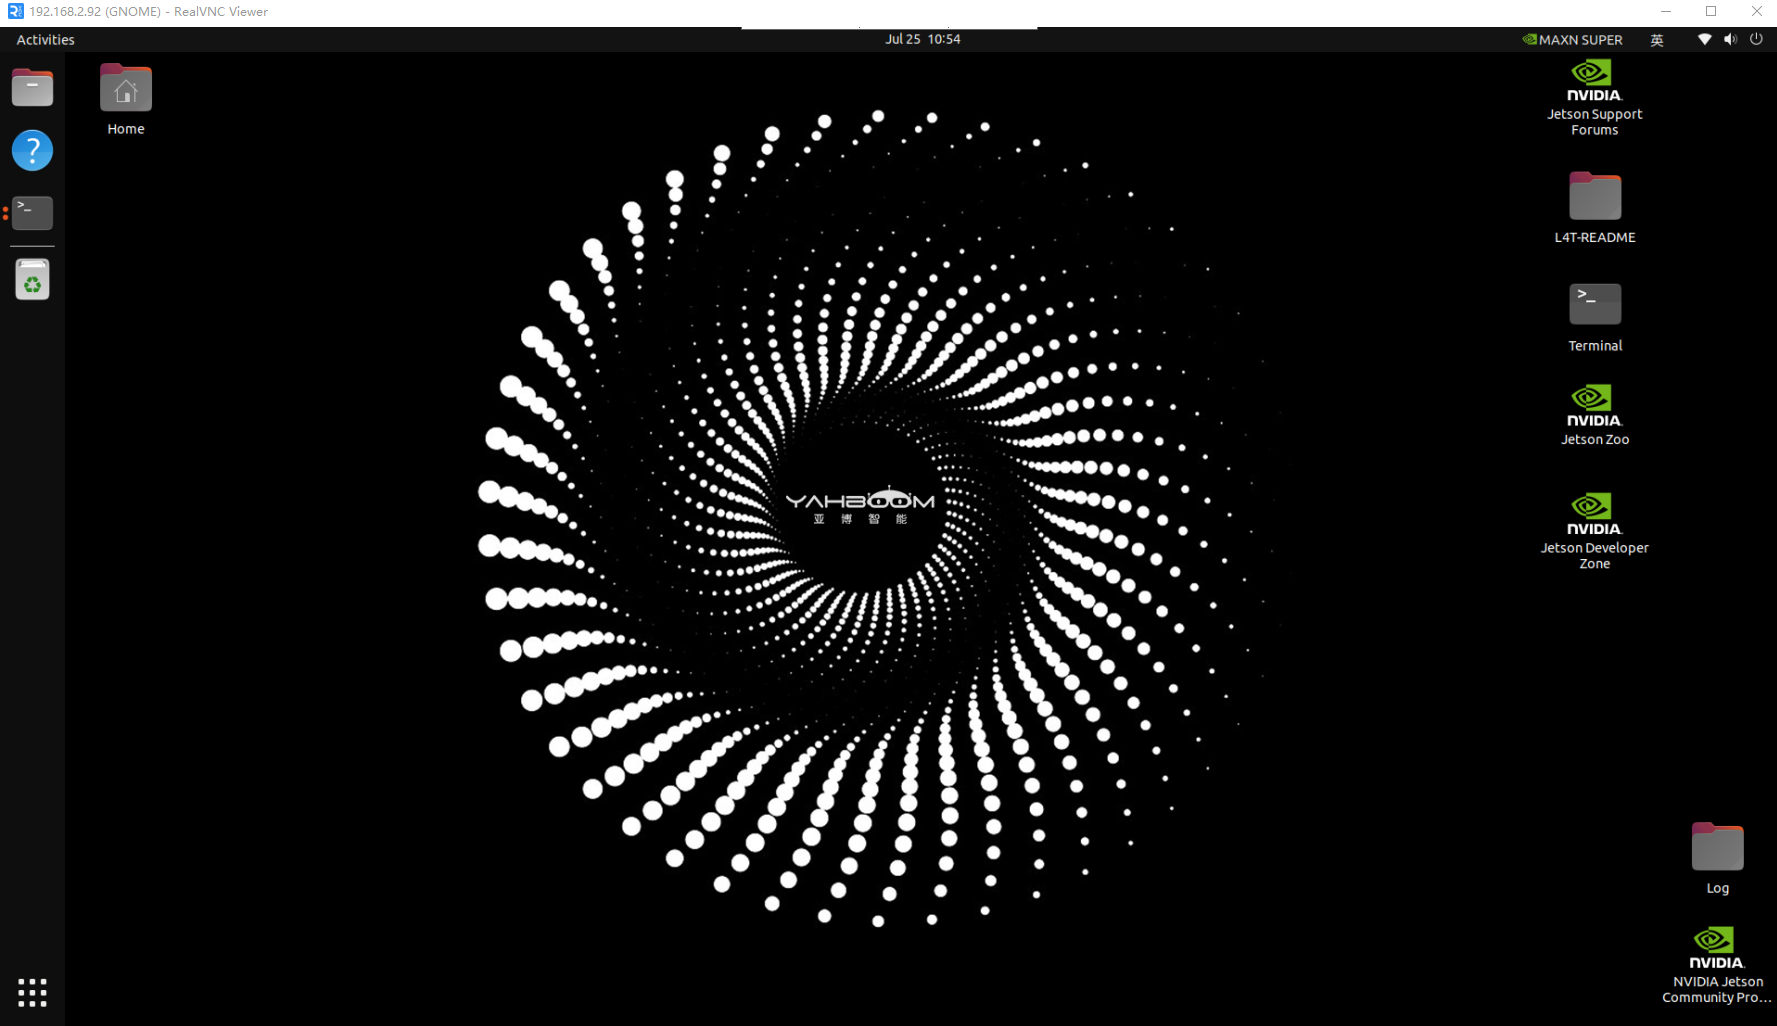
image-20250725105510621

If an abnormal screen is displayed, such as the following situation,
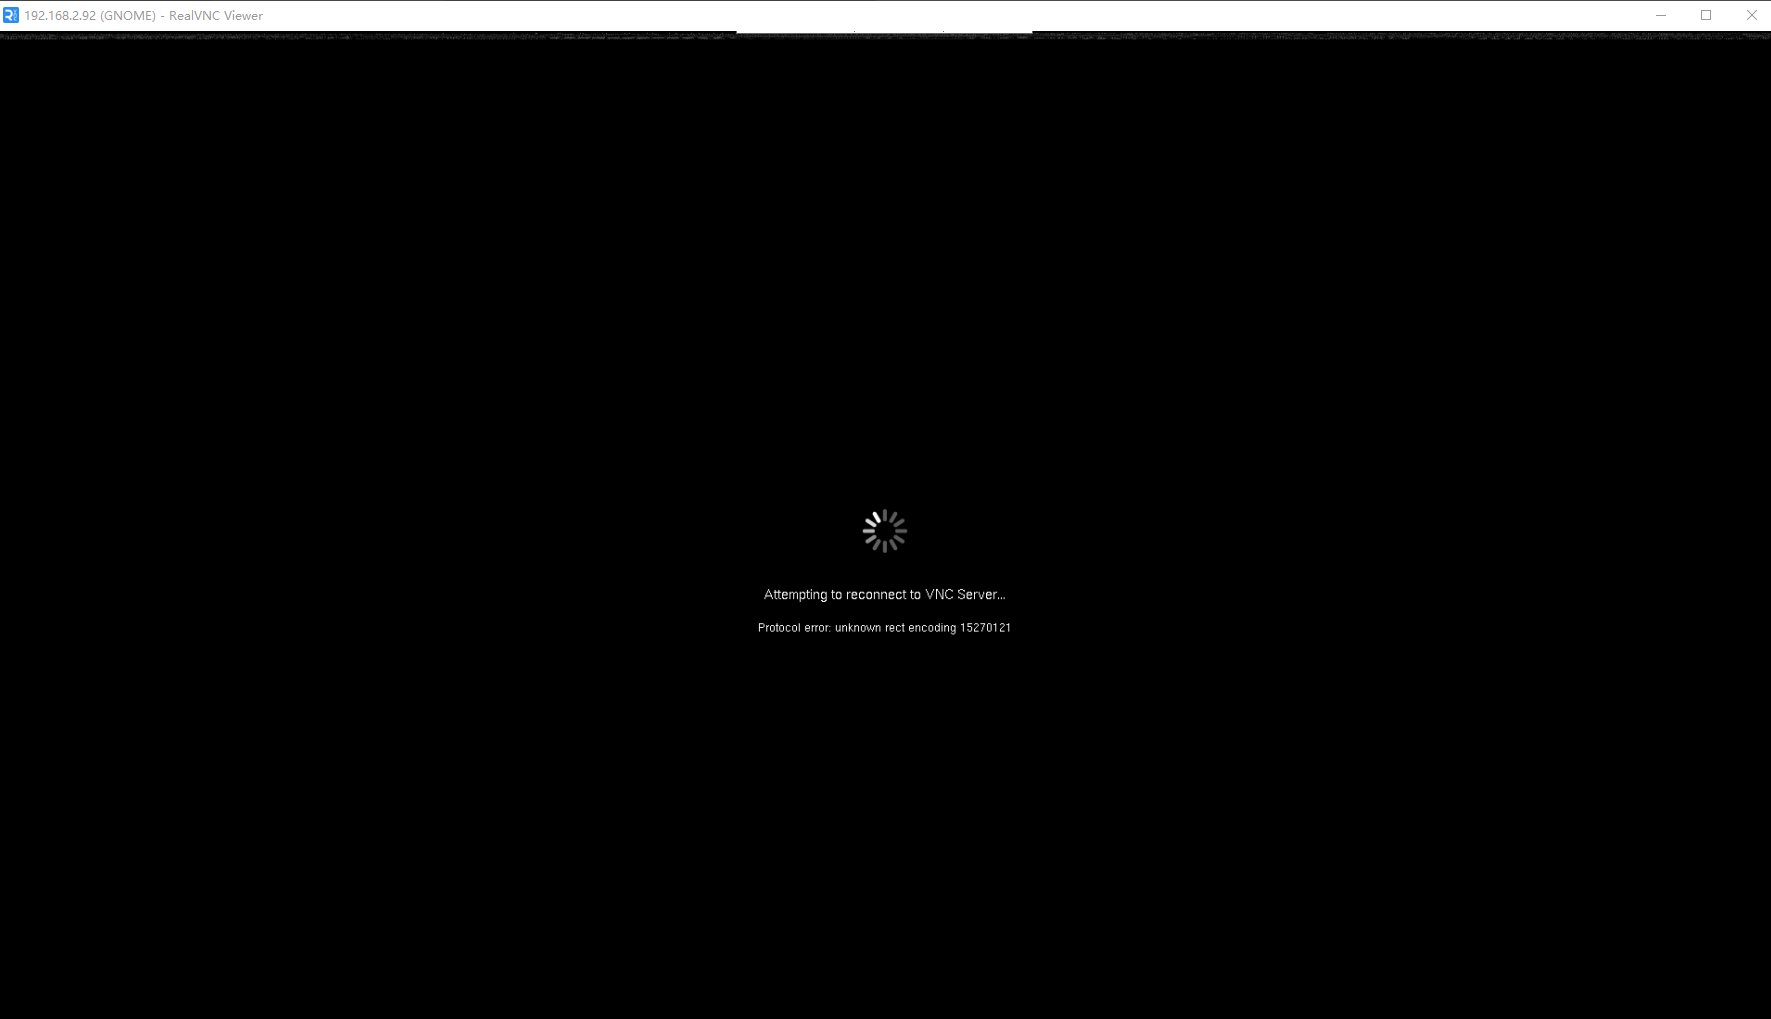
image-20250725105612931

If it keeps flashing back, you need to set it up as shown in the figure below.
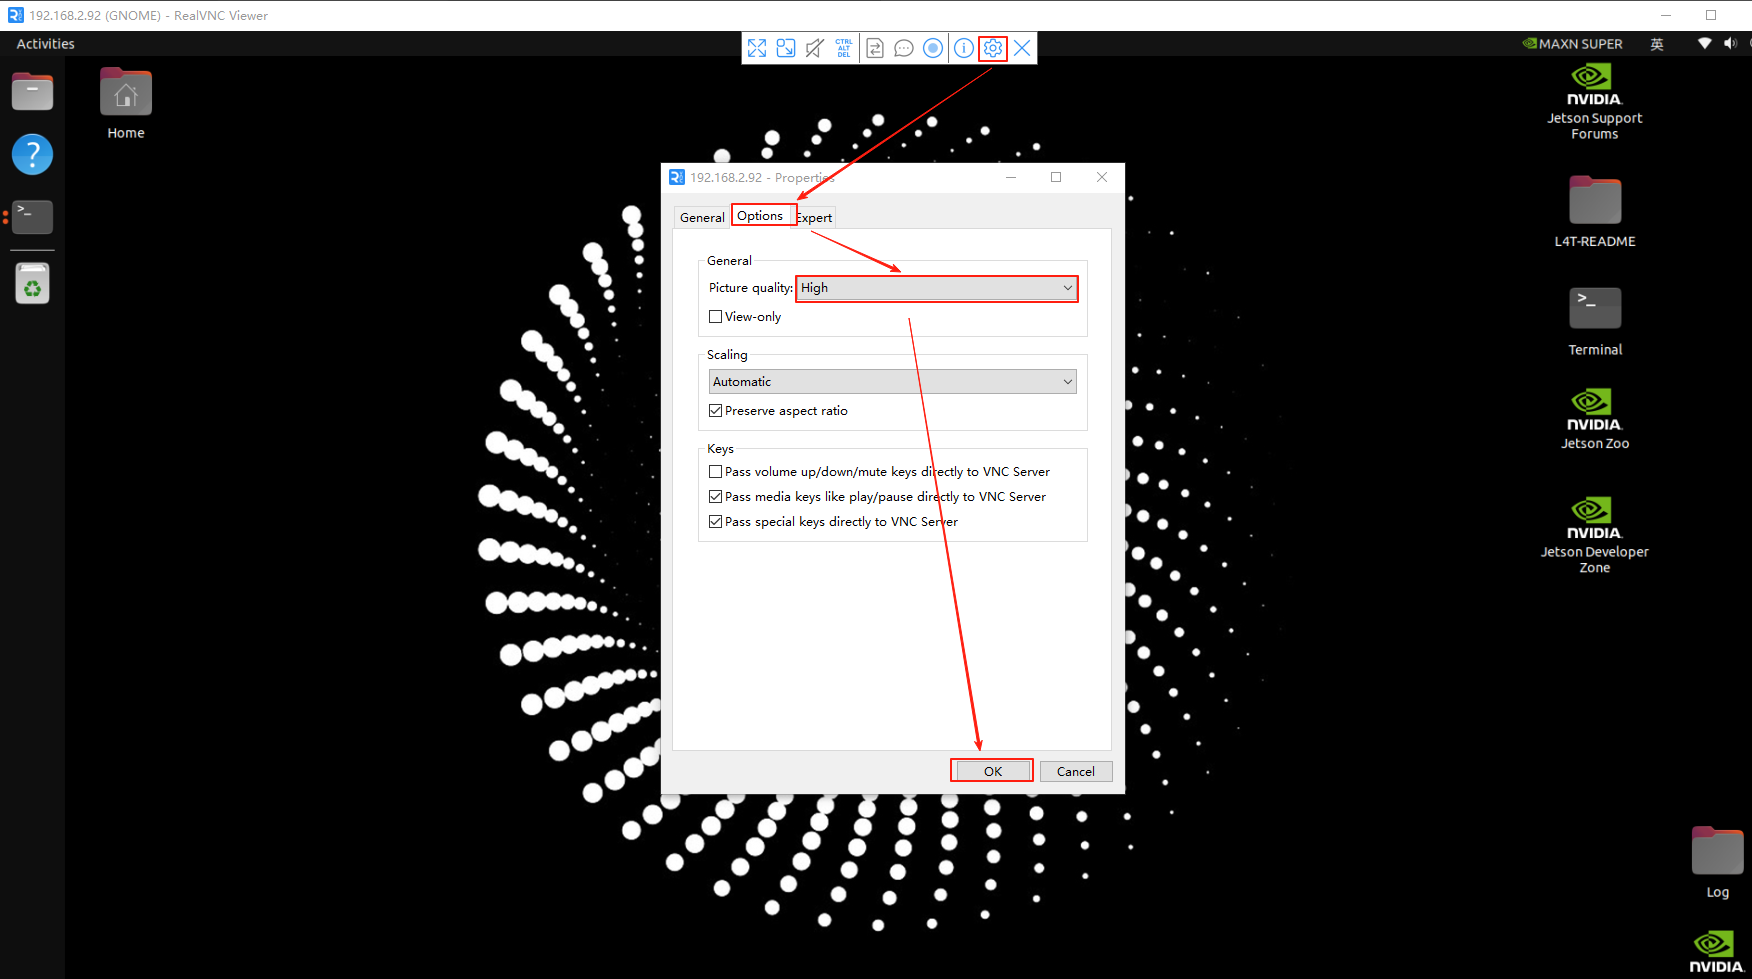
image-20250725105853102

Then reconnect. The Orin motherboard can only connect to one remote desktop at a time. If the connection fails, you need to check whether the remote desktop is already connected.

After connecting, since the AI large model needs to be used online, the hotspot is only the local area network and has no actual data, so you need to switch the network to facilitate the use of the AI large model function later.

2. View the code

The code for the Orin motherboard is in the /home/jetson directory, so as long as we can connect to the car, we can see the code; the code for the Raspberry Pi 5 and jetson-nano motherboard is in the started Docker container, so we need to enter the container first to see the code.

The following introduces several ways to view the code, which will facilitate our subsequent editing and modification of the code.

2.1、jupyter-lab

2.1.1: Orin motherboard (it is not recommended to use jupyter-lab to view and modify code)

Jupyter-lab will be started directly after booting up, so you only need to enter ip+:8888 in the browser to use jupyter to view the code. My ip address here is 192.168.2.92, so I enter the following content in the browser,

image-20250725111737793

Then press Enter to display the password. Enter yahboom in the same way, and then you can enter the jupyter-lab interface, as shown below.
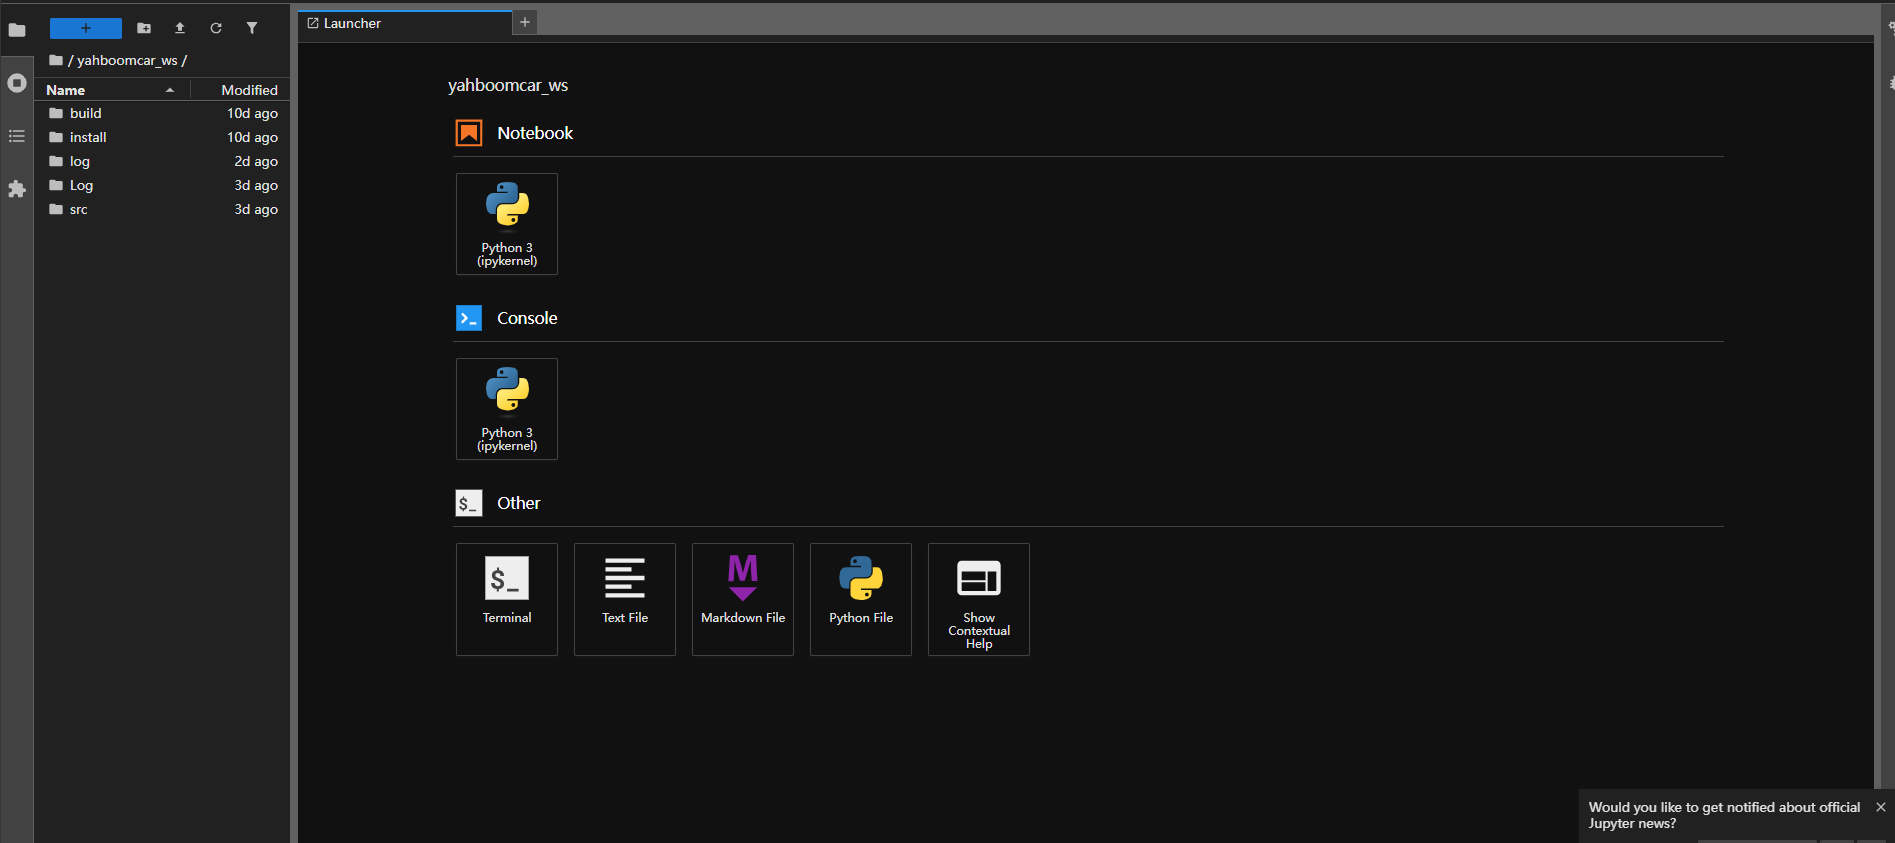
image-20250725112817507

Select the contents of the folder on the left to view the code.

2.1.2 Raspberry Pi 5 and Jetson-Nano motherboard:

You need to enter the docker container and enter the command jupyter-lab --allow-root, then enter the car ip+:8888 in the browser to start jupyter-lab to view the car code. As shown in the figure below, I enter the car container and cd to the /root directory, and then enter jupyter-lab --allow-root in the terminal.
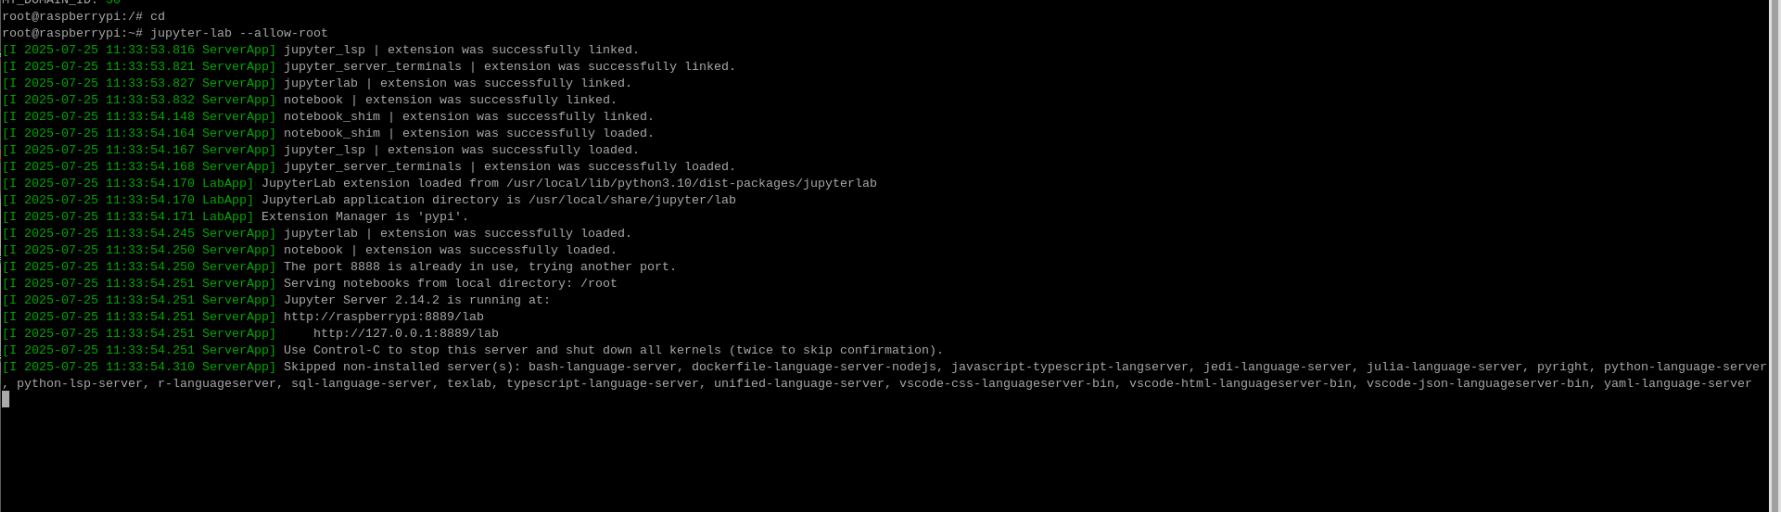
image-20250725113426816

Then enter the car's ip+:8888 in the browser. The ip of my Raspberry Pi motherboard is 192.168.2.22, so enter 192.168.2.22:8888, as shown below.

image-20250725113602612

Press Enter. If you need to enter a password, enter yahboom to enter jupyter-lab to view the code.

Quick start handle to control the car
Robotic Arm Calibration

COMPANY

  • About us
  • Team Style
  • Blog

LEARNING & EXPLORATION

  • Tutorials
  • Edge AI hardware
  • Educational robots
  • Embedded intelligent hardware

WHERE TO BUY

  • Yahboom Online Store
  • Amazon
  • Alibaba
  • AliExpress
  • Mercado

TECHNOLOGY SUPPORT

  • Email: support@yahboom.com

BE A DISTRIBUTOR

  • Email: sales@yahboom.com
QR Code
QR Code

Copyright © 2017-2026 Yahboom. All Rights Reserved.

EN/中文